Related Experiment Video
Updated: Feb 24, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Exoskeleton for gait rehabilitation of children: Conceptual design

Abstract:
This paper presents the conceptual design of an exoskeleton for gait rehabilitation of children. This system has electronics, mechanicals and software sections, which are implemented and tested using a mannequin of a child. The prototype uses servomotors to move robotic joints that are attached to simulated patient's legs. The design has 4 DOF (degrees of freedom) two for hip joints and other two for knee joints, in the sagittal plane. A microcontroller measures sensor signals, controls motors and exchanges data with a computer. The user interacts with a graphical interface to configure, control and monitor the exoskeleton activities. The laboratory tests show soften movements in joint angle tracking.
More Related Videos
 06:00
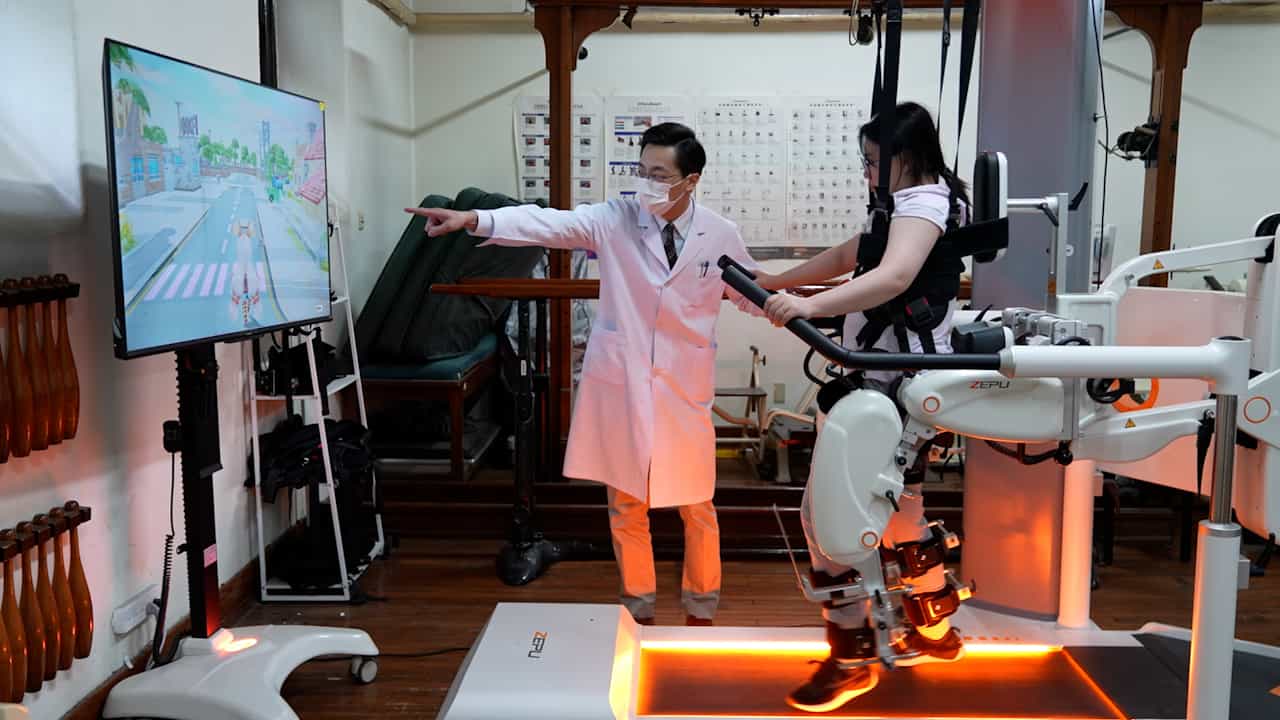
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 06:44
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020