Related Experiment Video
Updated: Feb 24, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Visuo-manual tracking: does intermittent control with aperiodic sampling explain linear power and non-linear remnant
Henrik Gollee1, Peter J Gawthrop1,2, Martin Lakie3
1School of Engineering, University of Glasgow, Glasgow, UK.

Key Points:
A human controlling an external system is described most easily and conventionally as linearly and continuously translating sensory input to motor output, with the inevitable output remnant, non-linearly related to the input, attributed to sensorimotor noise. Recent experiments show sustained manual tracking involves repeated refractoriness (insensitivity to sensory information for a certain duration), with the temporary 200-500 ms periods of irresponsiveness to sensory input making the control process intrinsically non-linear. This evidence calls for re-examination of the extent to which random sensorimotor noise is required to explain the non-linear remnant. This investigation of manual tracking shows how the full motor output (linear component and remnant) can be explained mechanistically by aperiodic sampling triggered by prediction error thresholds. Whereas broadband physiological noise is general to all processes, aperiodic sampling is associated with sensorimotor decision making within specific frontal, striatal and parietal networks; we conclude that manual tracking utilises such slow serial decision making pathways up to several times per second.
Abstract:
The human operator is described adequately by linear translation of sensory input to motor output. Motor output also always includes a non-linear remnant resulting from random sensorimotor noise from multiple sources, and non-linear input transformations, for example thresholds or refractory periods. Recent evidence showed that manual tracking incurs substantial, serial, refractoriness (insensitivity to sensory information of 350 and 550 ms for 1st and 2nd order systems respectively). Our two questions are: (i) What are the comparative merits of explaining the non-linear remnant using noise or non-linear transformations? (ii) Can non-linear transformations represent serial motor decision making within the sensorimotor feedback loop intrinsic to tracking? Twelve participants (instructed to act in three prescribed ways) manually controlled two systems (1st and 2nd order) subject to a periodic multi-sine disturbance. Joystick power was analysed using three models, continuous-linear-control (CC), continuous-linear-control with calculated noise spectrum (CCN), and intermittent control with aperiodic sampling triggered by prediction error thresholds (IC). Unlike the linear mechanism, the intermittent control mechanism explained the majority of total power (linear and remnant) (77-87% vs. 8-48%, IC vs. CC). Between conditions, IC used thresholds and distributions of open loop intervals consistent with, respectively, instructions and previous measured, model independent values; whereas CCN required changes in noise spectrum deviating from broadband, signal dependent noise. We conclude that manual tracking uses open loop predictive control with aperiodic sampling. Because aperiodic sampling is inherent to serial decision making within previously identified, specific frontal, striatal and parietal networks we suggest that these structures are intimately involved in visuo-manual tracking.
More Related Videos
 11:54
Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Control Systems
At the heart...
 01:13
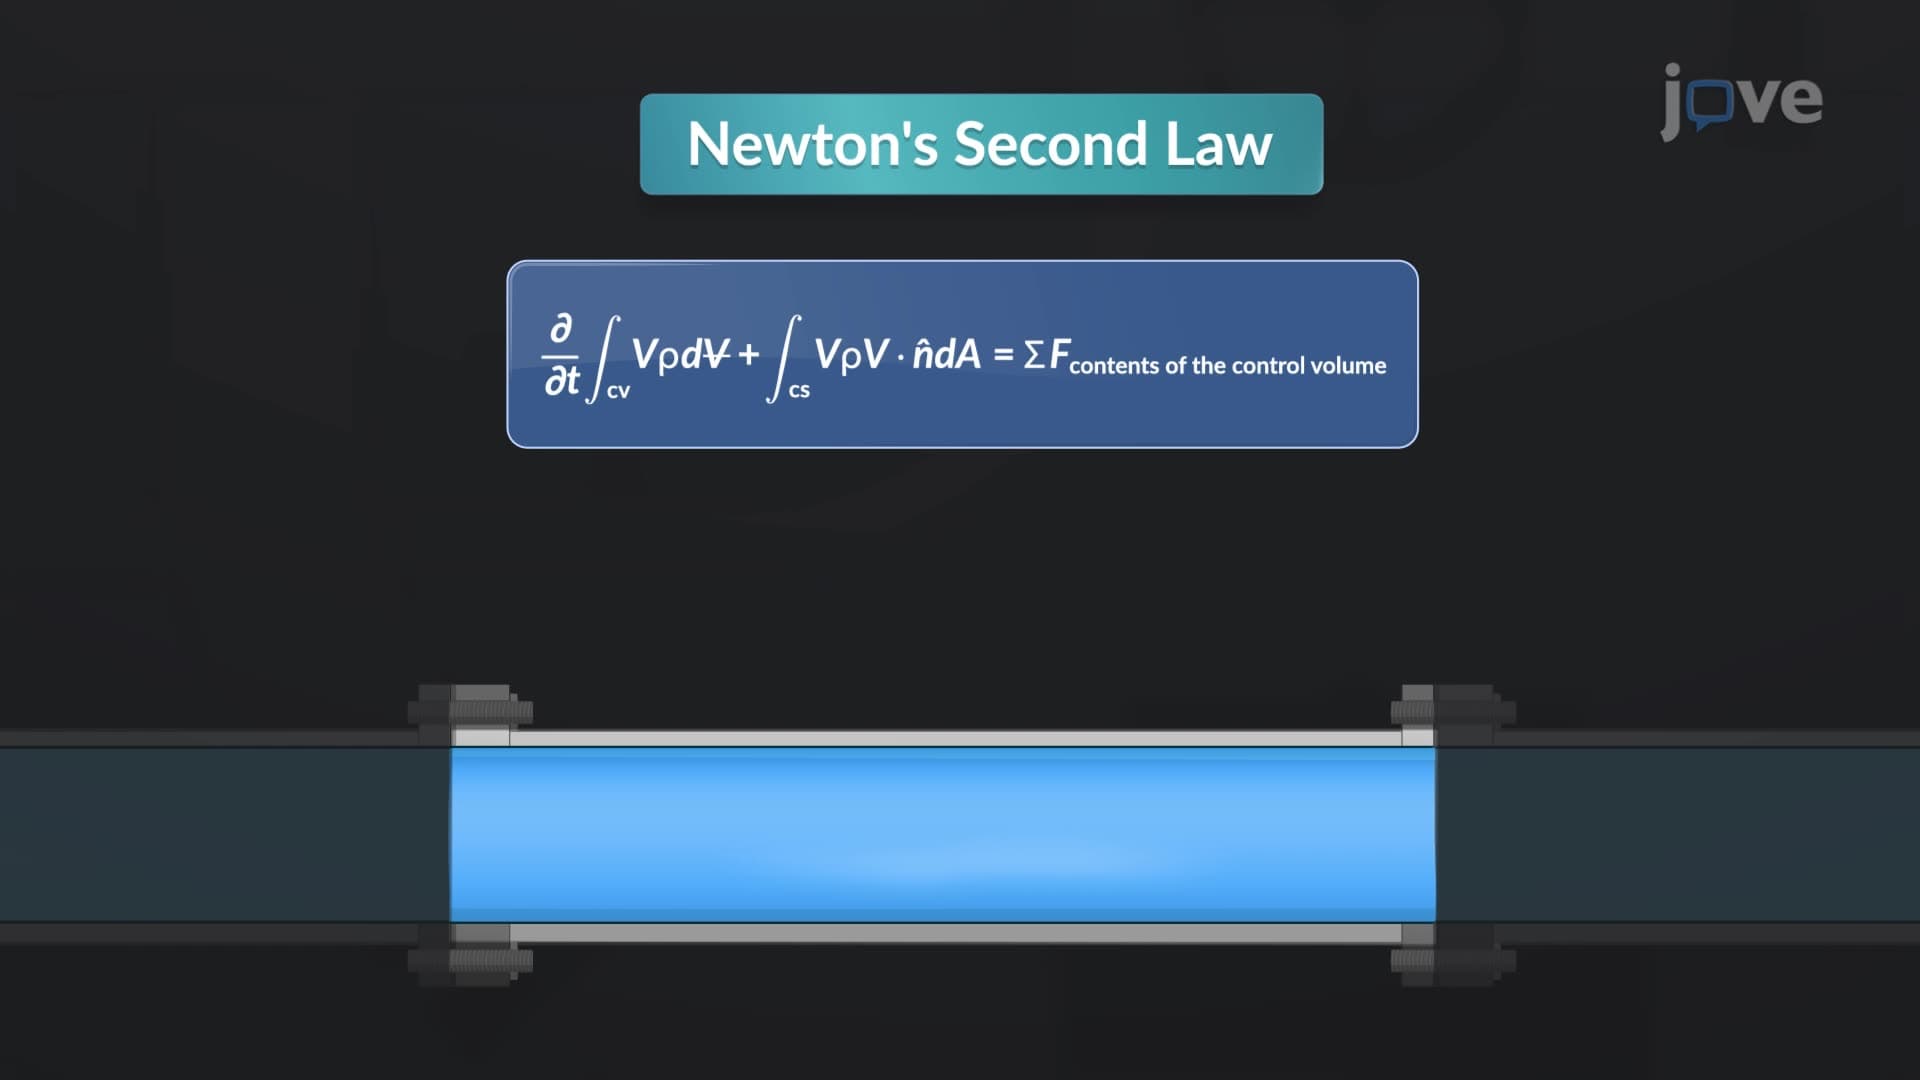
Linear Momentum in Control Volume
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the...