Related Experiment Video
Updated: Feb 23, 2026
Emergency Undocking in Robotic Surgery: A Simulation Curriculum
Published on: May 20, 2018
Novel simulator for robotic surgery
Francisco Schlottmann1, Marco G Patti2,3
1Department of Surgery, University of North Carolina, 4030 Burnett Womack Building, 101 Manning Drive, CB 7081, Chapel Hill, NC, 27599-7081, USA. fschlott@med.unc.edu.

Abstract:
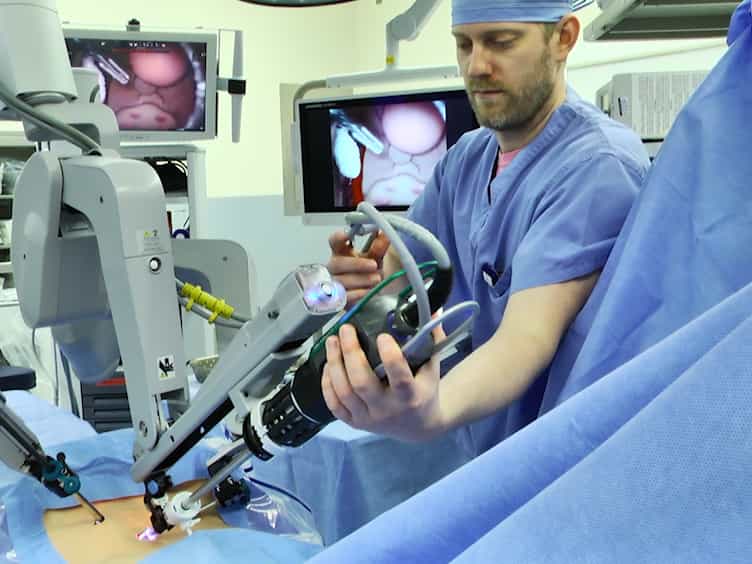
Surgical simulation avoids practicing skills in patients, allowing trainees to learn in a safe, controlled, and standardized environment. Current robotic surgical simulators available include virtual reality simulators, human cadavers, and live animals. The use of cadavers has the highest possible fidelity available to practice entire operations. Nevertheless, their cost, availability, tissue compliance, and infection risk outweigh the advantages of cadaver models. Drawbacks of using live animals include anatomical differences with humans, high costs due to their housing and handling requirements, and ethical concerns. We designed a novel robotic surgical simulator based on porcine perfused tissue blocks that allows the simulation of entire surgical procedures. Our simulation allows trainees to increase familiarity with the robotic console and its controls, as well as with the docking process. It provides an opportunity to learn not only universal skills needed in robotic surgery, such as camera and instrument targeting, but also to perform complete surgical procedures such as an antireflux procedure. The adoption of robotic simulation curricula with realistic models will decrease overall operative time while increasing resident participation.