Highly Articulated Kinematic Structure Estimation Combining Motion and Skeleton Information
Related Experiment Video
Updated: Feb 23, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023

Abstract:
In this paper, we present a novel framework for unsupervised kinematic structure learning of complex articulated objects from a single-view 2D image sequence. In contrast to prior motion-based methods, which estimate relatively simple articulations, our method can generate arbitrarily complex kinematic structures with skeletal topology via a successive iterative merging strategy. The iterative merge process is guided by a density weighted skeleton map which is generated from a novel object boundary generation method from sparse 2D feature points. Our main contributions can be summarised as follows: (i) An unsupervised complex articulated kinematic structure estimation method that combines motion segments with skeleton information. (ii) An iterative fine-to-coarse merging strategy for adaptive motion segmentation and structural topology embedding. (iii) A skeleton estimation method based on a novel silhouette boundary generation from sparse feature points using an adaptive model selection method. (iv) A new highly articulated object dataset with ground truth annotation. We have verified the effectiveness of our proposed method in terms of computational time and estimation accuracy through rigorous experiments with multiple datasets. Our experiments show that the proposed method outperforms state-of-the-art methods both quantitatively and qualitatively.
Related Concept Videos
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
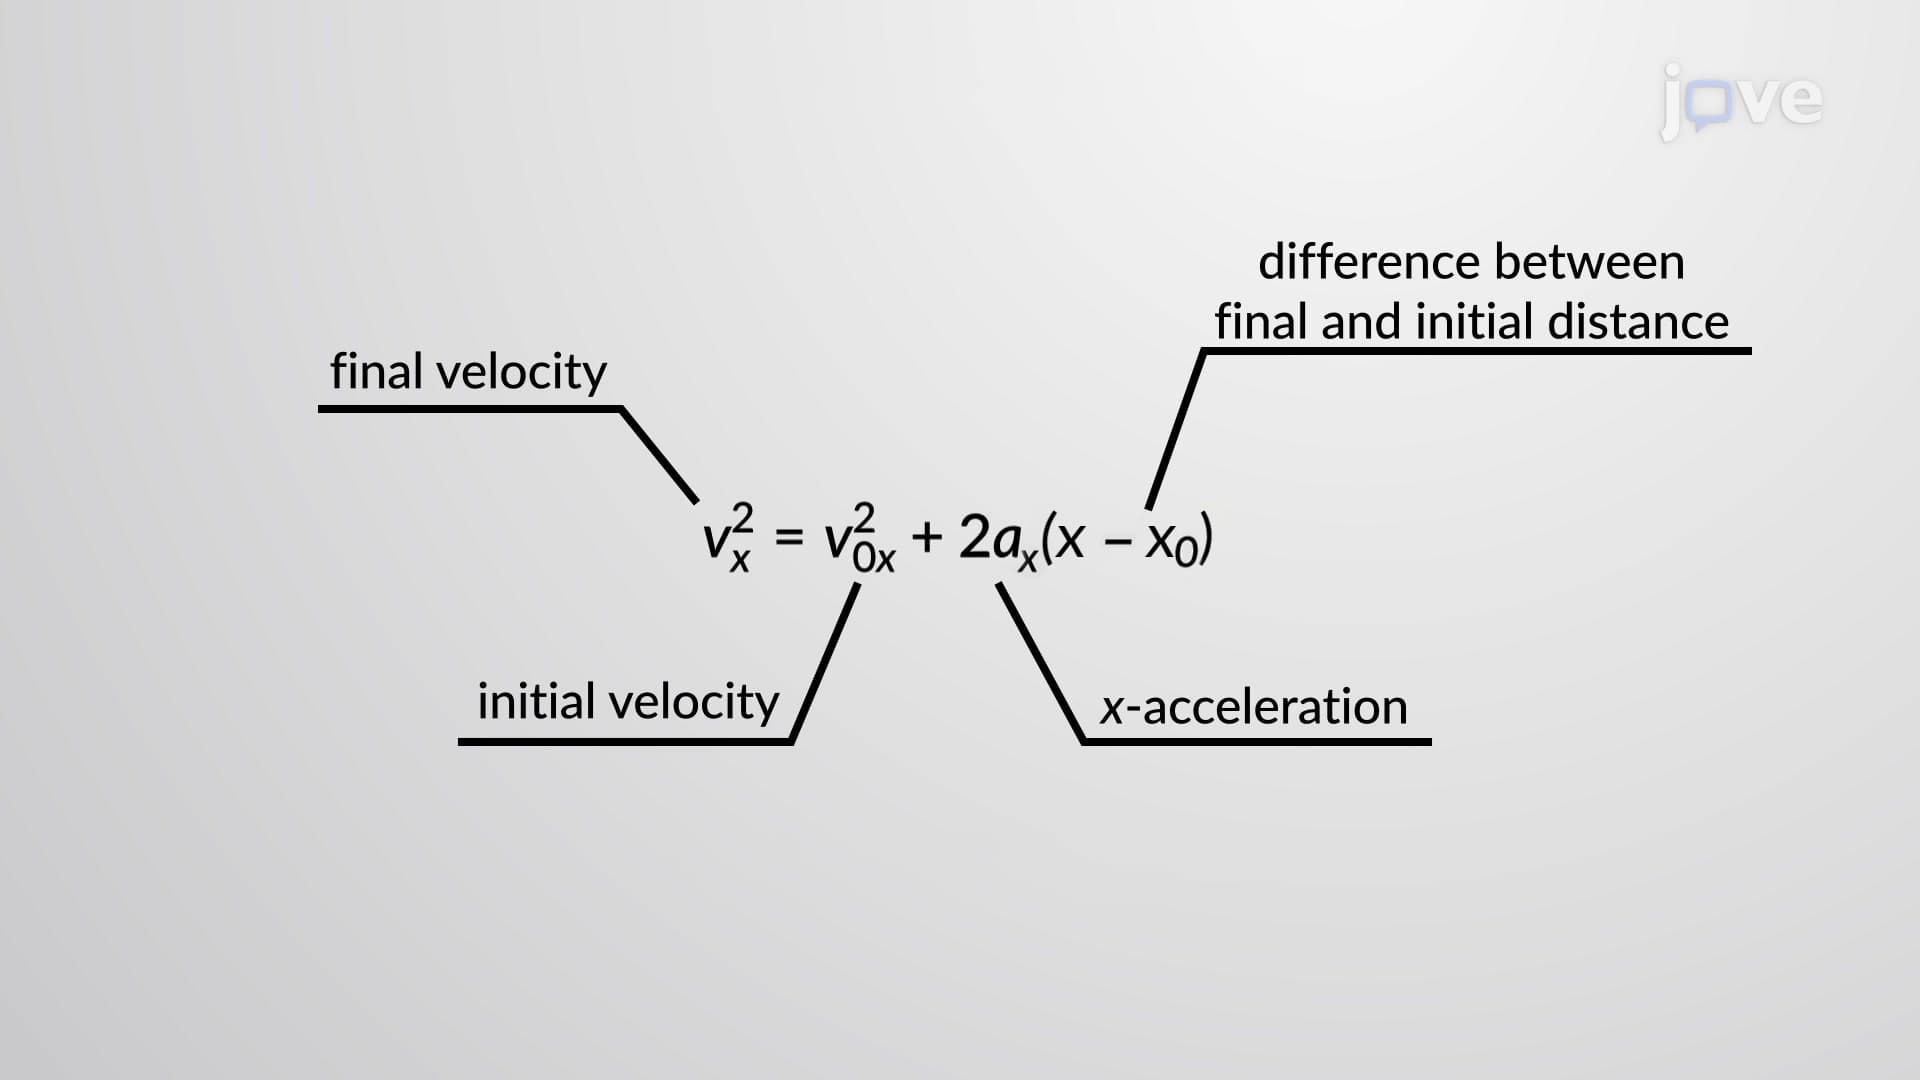
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 00:58
Introduction to Joints