Related Experiment Video
Updated: Feb 22, 2026

Effects of a Novel Neuromuscular Training Intervention on Jump, Sprint, and Change of Direction in Adult Female Soccer Players
Published on: June 10, 2025
Jump stabilization and landing control by wing-spreading of a locust-inspired jumper
Avishai Beck1, Valentin Zaitsev, Uri Ben Hanan
1Mechanical Engineering, Tel Aviv University, Tel Aviv, Israel.

Abstract:
Bio-inspired robotics is a promising design strategy for mobile robots. Jumping is an energy efficient locomotion gait for traversing difficult terrain. Inspired by the jumping and flying behavior of the desert locust, we have recently developed a miniature jumping robot that can jump over 3.5 m high. However, much like the non-adult locust, it rotates while in the air and lands uncontrollably. Inspired by the winged adult locust, we have added spreading wings and a tail to the jumper. After the robot leaps, at the apex of the trajectory, the wings unfold and it glides to the ground. The advantages of this maneuver are the stabilization of the robot when airborne, the reduction of velocity at landing, the control of the landing angle and the potential to change the robot's orientation and control its flight trajectory. The new upgraded robot is capable of jumping to a still impressive height of 1.7 m eliminating airborne rotation and reducing landing velocity. Here, we analyze the dynamic and aerodynamic models of the robot, discuss the robot's design, and validate its ability to perform a jump-glide in a stable trajectory, land safely and change its orientation while in the air.

Related Concept Videos
 01:29
Hydraulic Jump
 01:16
Hydraulic Jump: Problem Solving
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:13
Maximum Deflection
The maximum deflection occurs at a specific point, known as point O, where the tangent to the deflection curve is horizontal. To find point O, the slope of the tangent at any...
 01:03
Anchoring Junctions
 01:13
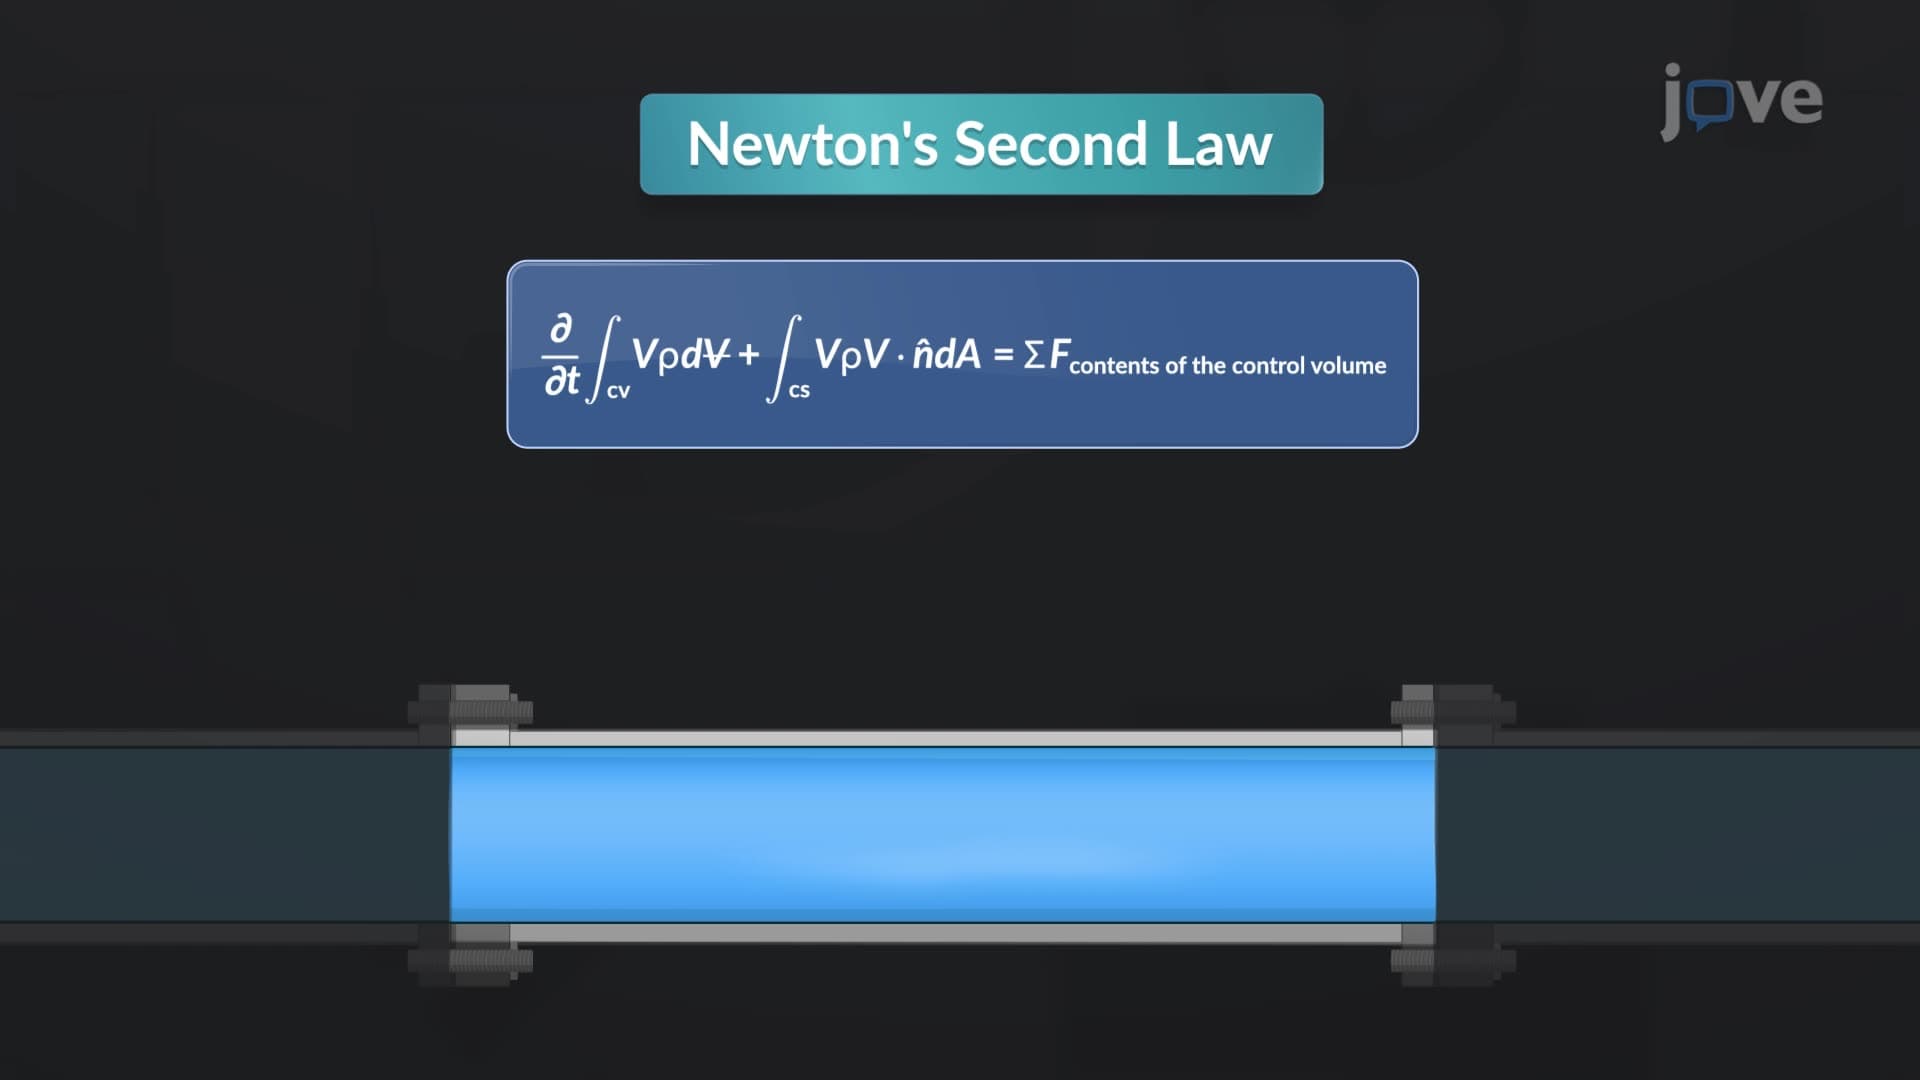
Linear Momentum in Control Volume