Related Experiment Video
Updated: Feb 22, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Simultaneous Recognition and Relative Pose Estimation of 3D Objects Using 4D Orthonormal Moments
1Centre for Automation and Robotics UPM-CSIC, Universidad Politécnica de Madrid, Jose Gutierrez Abascal, 2, 28006 Madrid, Spain. sergio.dominguez@upm.es.

Abstract:
Both three-dimensional (3D) object recognition and pose estimation are open topics in the research community. These tasks are required for a wide range of applications, sometimes separately, sometimes concurrently. Many different algorithms have been presented in the literature to solve these problems separately, and some to solve them jointly. In this paper, an algorithm to solve them simultaneously is introduced. It is based on the definition of a four-dimensional (4D) tensor that gathers and organizes the projections of a 3D object from different points of view. This 4D tensor is then represented by a set of 4D orthonormal moments. Once these moments are arranged in a matrix that can be computed off-line, recognition and pose estimation is reduced to the solution of a linear least squares problem, involving that matrix and the 2D moments of the observed projection of an unknown object. The abilities of this method for 3D object recognition and pose estimation is analytically proved, demonstrating that it does not rely on experimental work to apply a generic technique to these problems. An additional strength of the algorithm is that the required projection is textureless and defined at a very low resolution. This method is computationally simple and shows very good performance in both tasks, allowing its use in applications where real-time constraints have to be fulfilled. Three different kinds of experiments have been conducted in order to perform a thorough validation of the proposed approach: recognition and pose estimation under z axis (yaw) rotations, the same estimation but with the addition of y axis rotations (pitch), and estimation of the pose of objects in real images downloaded from the Internet. In all these cases, results are encouraging, at a similar level to those of state-of-the art algorithms.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:20
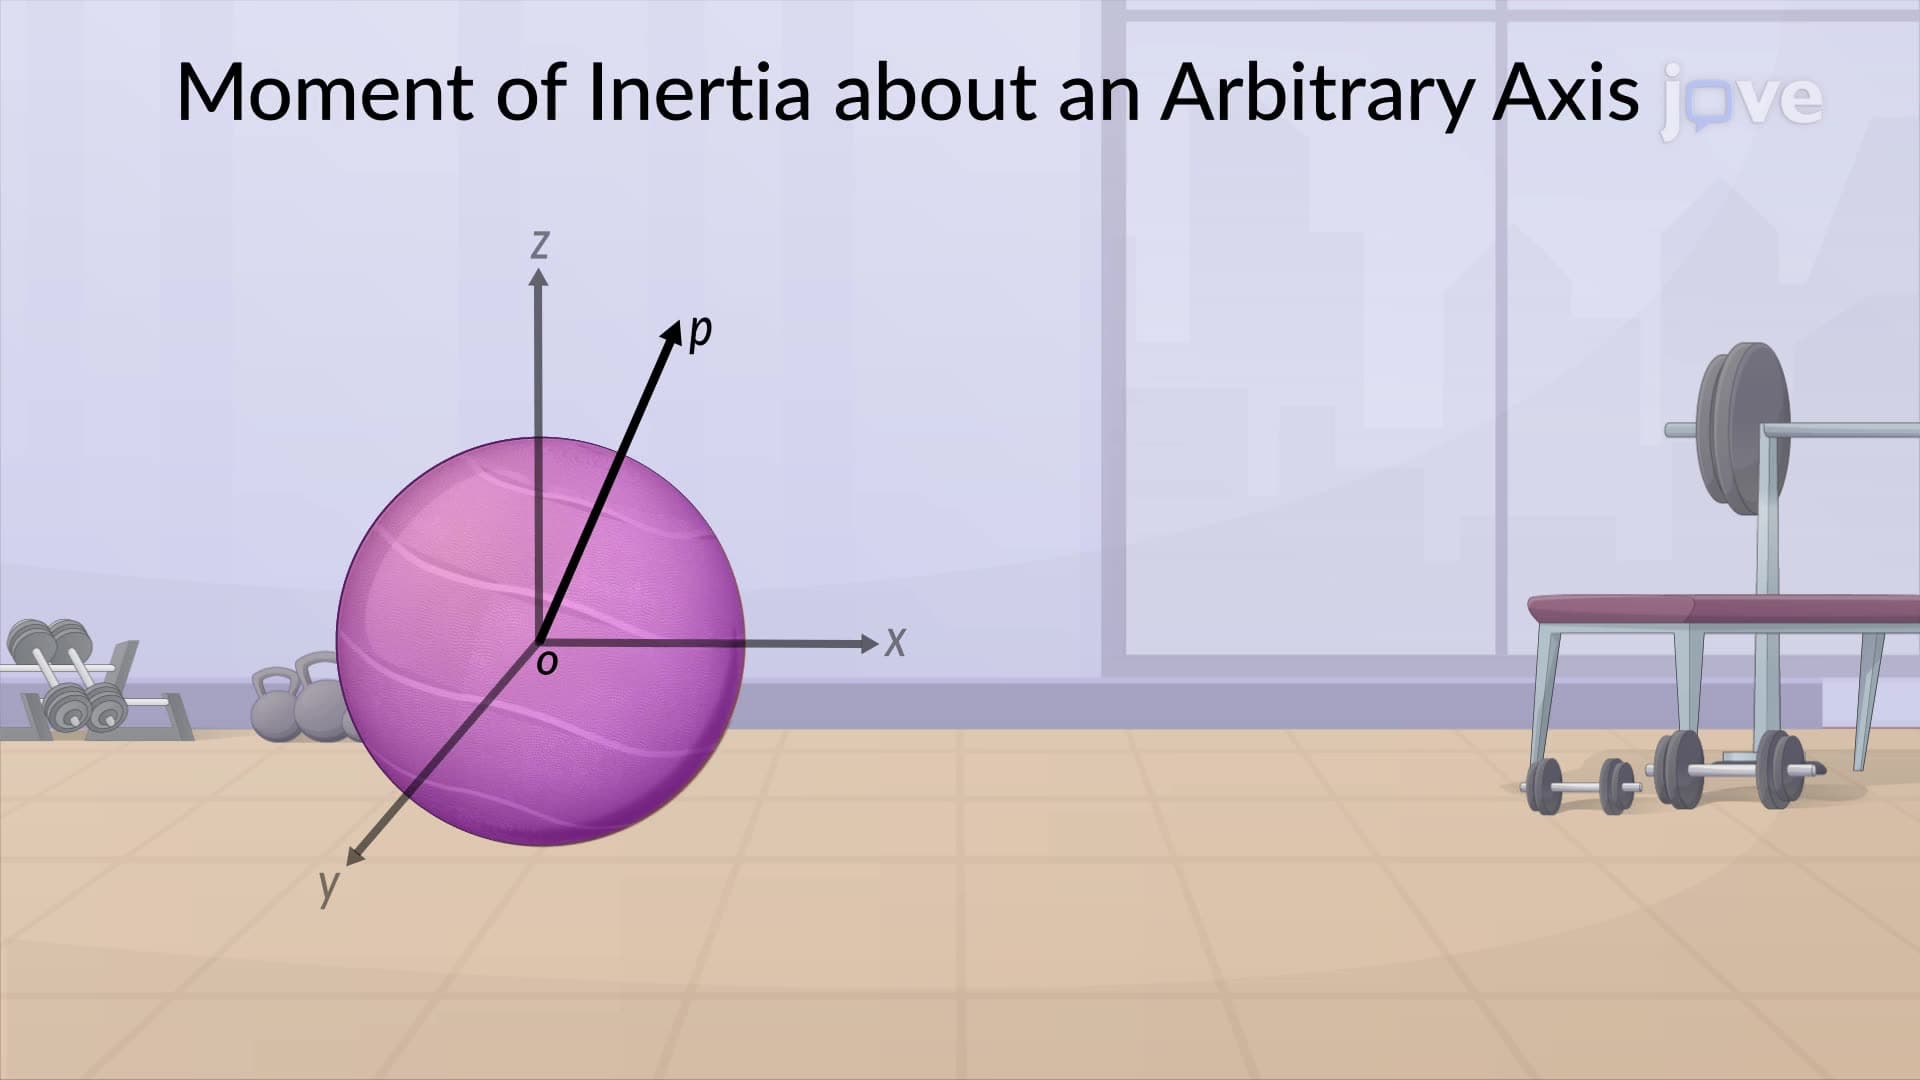
Moment of Inertia about an Arbitrary Axis
In this scenario, the perpendicular distance between the chosen arbitrary axis...
 01:07
Moment of Inertia of Compound Objects
Consider a child of mass (mc) 25 kg standing at a distance (rc) of 1 m from the axis of a rotating...
 01:16
Perpendicular-Axis Theorem
Consider a circular disc of mass M and radius R lying along an x-y plane. The origin lies at the center of the disc, and the z-axis is perpendicular to the disc's plane. All three axes coincide at the disc's center. The moment of inertia of this...
 01:20
Principle of Moments
The moment is calculated by multiplying the magnitude of the force by the perpendicular distance from the point of application to the point about...