Grip force when reaching with target uncertainty provides evidence for motor optimization over averaging
Related Experiment Video
Updated: Feb 22, 2026
Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
Published on: January 15, 2018
Joseph Y Nashed1, Jonathan S Diamond1, Jason P Gallivan1,2,2
1Centre for Neuroscience Studies, Queen's University, Kingston, Ontario, Canada.

Abstract:
When presented with competing potential reach targets and required to launch a movement before knowing which one will be cued as the target, people initially reach in the average target direction. Although this spatial averaging could arise from executing a weighted average of motor plans for the potential targets, it could also arise from planning a single, optimal movement. To test between these alternatives we used a task in which participants were required to reach to either a single target or towards two potential targets while grasping an object. A robotic device applied a lateral elastic load to the object requiring large grip forces for reaches to targets either side of midline and a minimal grip force for midline movements. As expected, in trials with two targets located either side of midline, participants initially reached straight ahead. Critically, on these trials the initial grip force was minimal, appropriate for the midline movement, and not the average of the large grip forces required for movements to the individual targets. These results indicate that under conditions of target uncertainty, people do not execute an average of planned actions but rather a single movement that optimizes motor costs.
Related Concept Videos
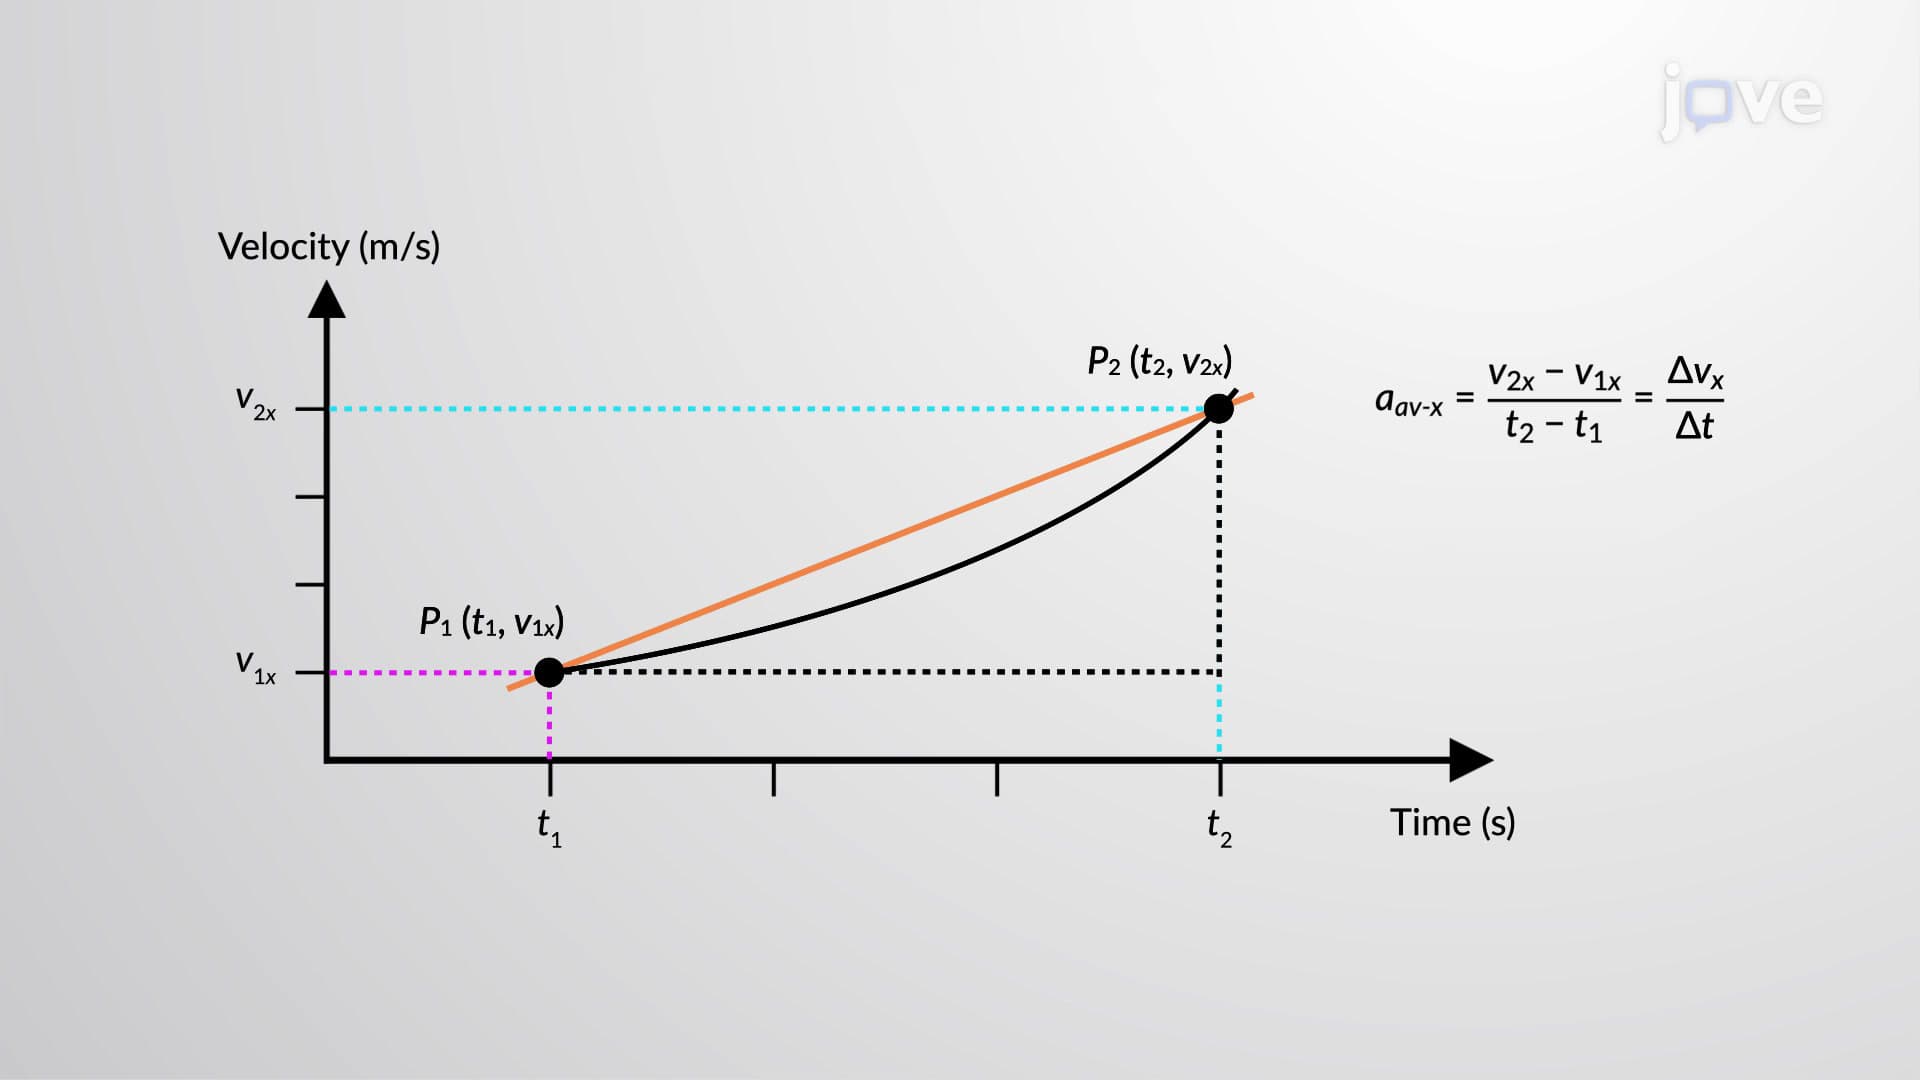 01:30
Average Acceleration
 01:25
The Anchoring-and-Adjustment Heuristic
 00:59
Uncertainty: Overview
 01:28
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...