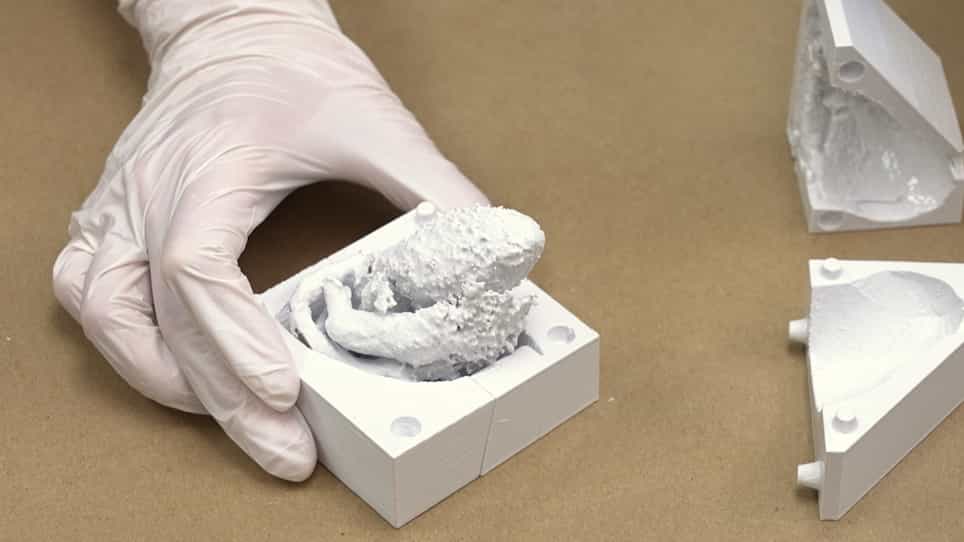
Simulation-based Education for Endoscopic Third Ventriculostomy: A Comparison Between Virtual and Physical Training Models
Related Experiment Video
Updated: Feb 22, 2026
Simulator Training for Endovascular Neurosurgery
Published on: May 6, 2020
Gerben E Breimer1,2,3, Faizal A Haji4,5,6, Vivek Bodani1,2
1Centre for Image Guided Innovation and Therapeutic Intervention (CIGITI), The Hospital for Sick Children, Toronto, Ontario, Canada.

Background:
The relative educational benefits of virtual reality (VR) and physical simulation models for endoscopic third ventriculostomy (ETV) have not been evaluated "head to head."
Objective:
To compare and identify the relative utility of a physical and VR ETV simulation model for use in neurosurgical training.
Methods:
Twenty-three neurosurgical residents and 3 fellows performed an ETV on both a physical and VR simulation model. Trainees rated the models using 5-point Likert scales evaluating the domains of anatomy, instrument handling, procedural content, and the overall fidelity of the simulation. Paired t tests were performed for each domain's mean overall score and individual items.
Results:
The VR model has relative benefits compared with the physical model with respect to realistic representation of intraventricular anatomy at the foramen of Monro (4.5, standard deviation [SD] = 0.7 vs 4.1, SD = 0.6; P = .04) and the third ventricle floor (4.4, SD = 0.6 vs 4.0, SD = 0.9; P = .03), although the overall anatomy score was similar (4.2, SD = 0.6 vs 4.0, SD = 0.6; P = .11). For overall instrument handling and procedural content, the physical simulator outperformed the VR model (3.7, SD = 0.8 vs 4.5; SD = 0.5, P < .001 and 3.9; SD = 0.8 vs 4.2, SD = 0.6; P = .02, respectively). Overall task fidelity across the 2 simulators was not perceived as significantly different.
Conclusion:
Simulation model selection should be based on educational objectives. Training focused on learning anatomy or decision-making for anatomic cues may be aided with the VR simulation model. A focus on developing manual dexterity and technical skills using endoscopic equipment in the operating room may be better learned on the physical simulation model.