Related Experiment Video
Updated: Feb 22, 2026


Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
A Three Revolute-Revolute-Spherical Wearable Fingertip Cutaneous Device for Stiffness Rendering

Abstract:
We present a novel three Revolute-Revolute-Spherical (3RRS) wearable fingertip device for the rendering of stiffness information. It is composed of a static upper body and a mobile end-effector. The upper body is located on the nail side of the finger, supporting three small servo motors, and the mobile end-effector is in contact with the finger pulp. The two parts are connected by three articulated legs, actuated by the motors. The end-effector can move toward the user's fingertip and rotate it to simulate contacts with arbitrarily-oriented surfaces. Moreover, a vibrotactile motor placed below the end-effector conveys vibrations to the fingertip. The proposed device weights 25 g for 35 x 50 x 48 mm dimensions. To test the effectiveness of our wearable haptic device and its level of wearability, we carried out two experiments, enrolling 30 human subjects in total. The first experiment tested the capability of our device in differentiating stiffness information, while the second one focused on evaluating its applicability in an immersive virtual reality scenario. Results showed the effectiveness of the proposed wearable solution, with a JND for stiffness of 208.5 17.2 N/m. Moreover, all subjects preferred the virtual interaction experience when provided with wearable cutaneous feedback, even if results also showed that subjects found our device still a bit difficult to use.
More Related Videos
 08:55
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
 11:06
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Related Concept Videos
 01:10
Deformation in a Circular Shaft
 01:30
Three-Dimensional Force System
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:05
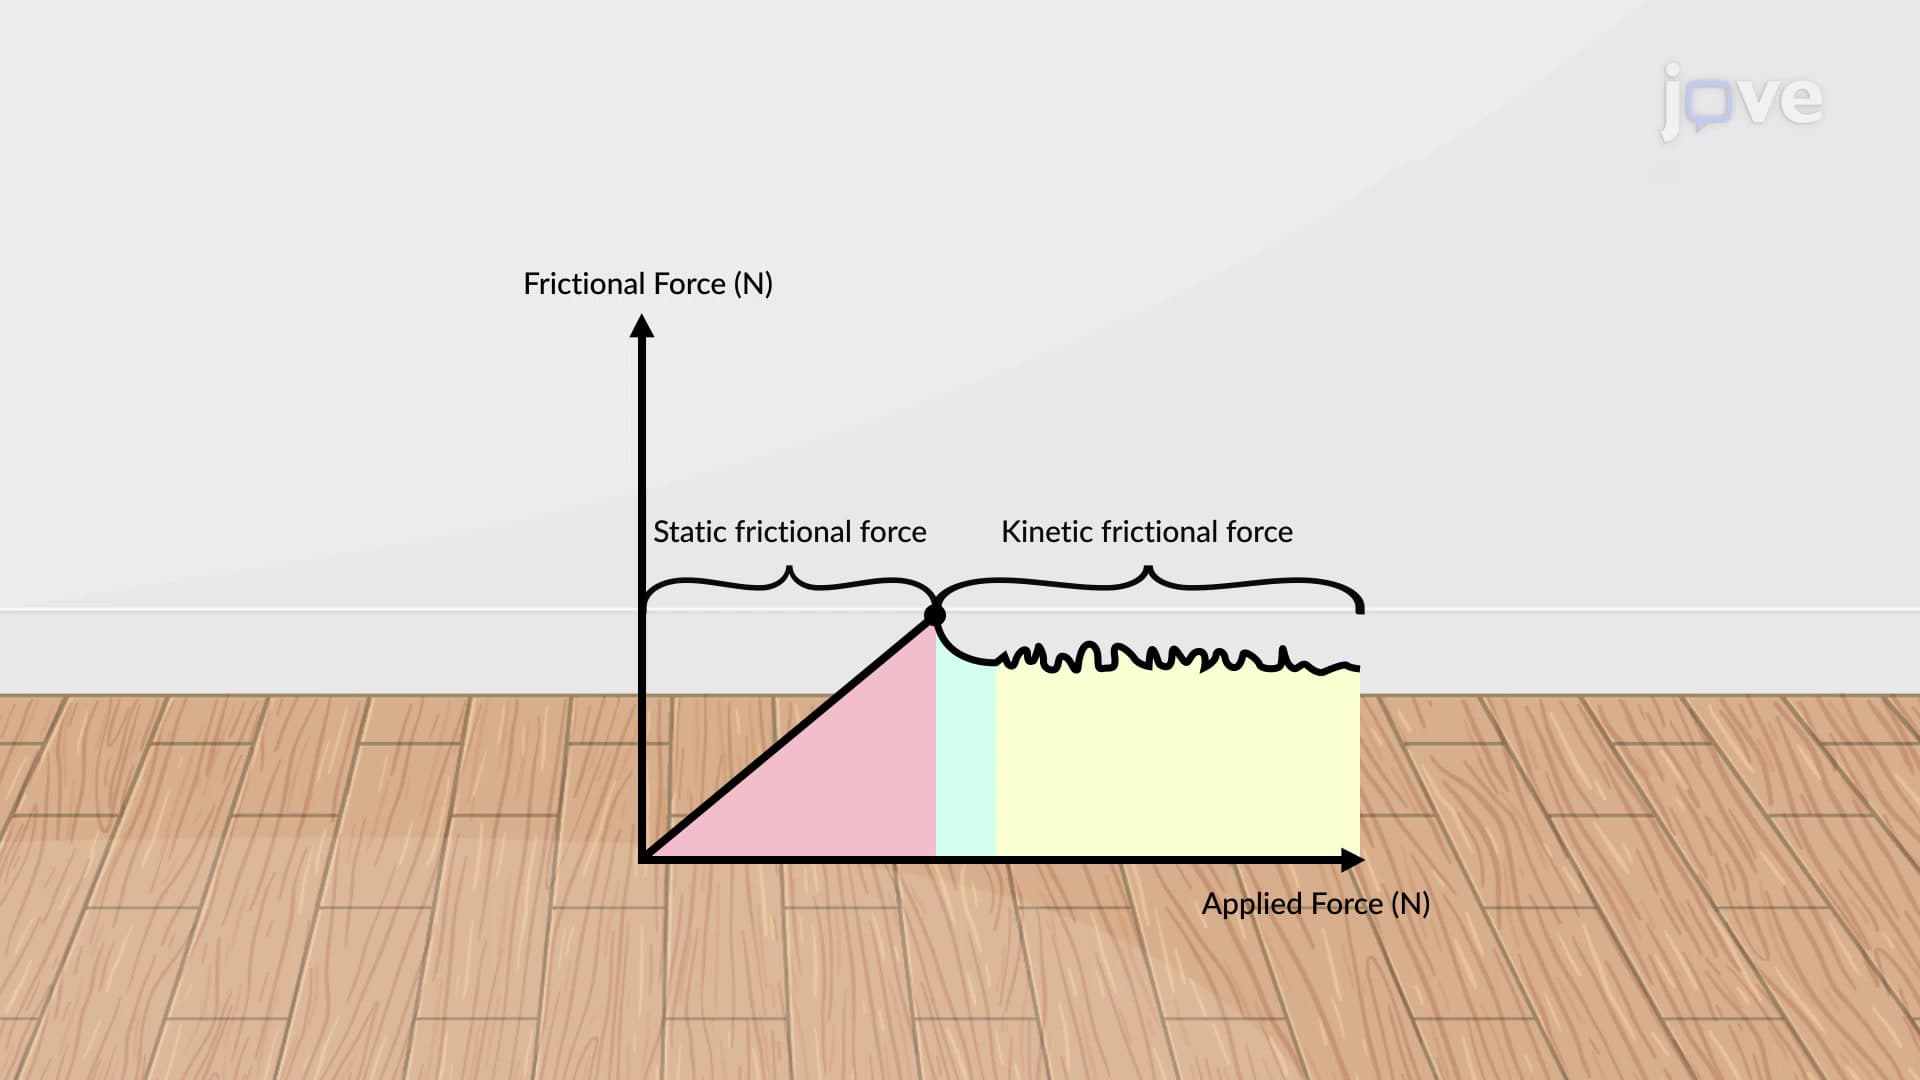
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...