Related Experiment Video
Updated: Aug 1, 2026

Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
The equivalent internal orientation and position noise for contour integration
Alex S Baldwin1, Minnie Fu2, Reza Farivar2
1McGill Vision Research, Department of Ophthalmology, McGill University, Montreal, Quebec, Canada. alexsbaldwin@googlemail.com.

Abstract:
Contour integration is the joining-up of local responses to parts of a contour into a continuous percept. In typical studies observers detect contours formed of discrete wavelets, presented against a background of random wavelets. This measures performance for detecting contours in the limiting external noise that background provides. Our novel task measures contour integration without requiring any background noise. This allowed us to perform noise-masking experiments using orientation and position noise. From these we measure the equivalent internal noise for contour integration. We found an orientation noise of 6° and position noise of 3 arcmin. Orientation noise was 2.6x higher in contour integration compared to an orientation discrimination control task. Comparing against a position discrimination task found position noise in contours to be 2.4x lower. This suggests contour integration involves intermediate processing that enhances the quality of element position representation at the expense of element orientation. Efficiency relative to the ideal observer was lower for the contour tasks (36% in orientation noise, 21% in position noise) compared to the controls (54% and 57%).
Related Concept Videos
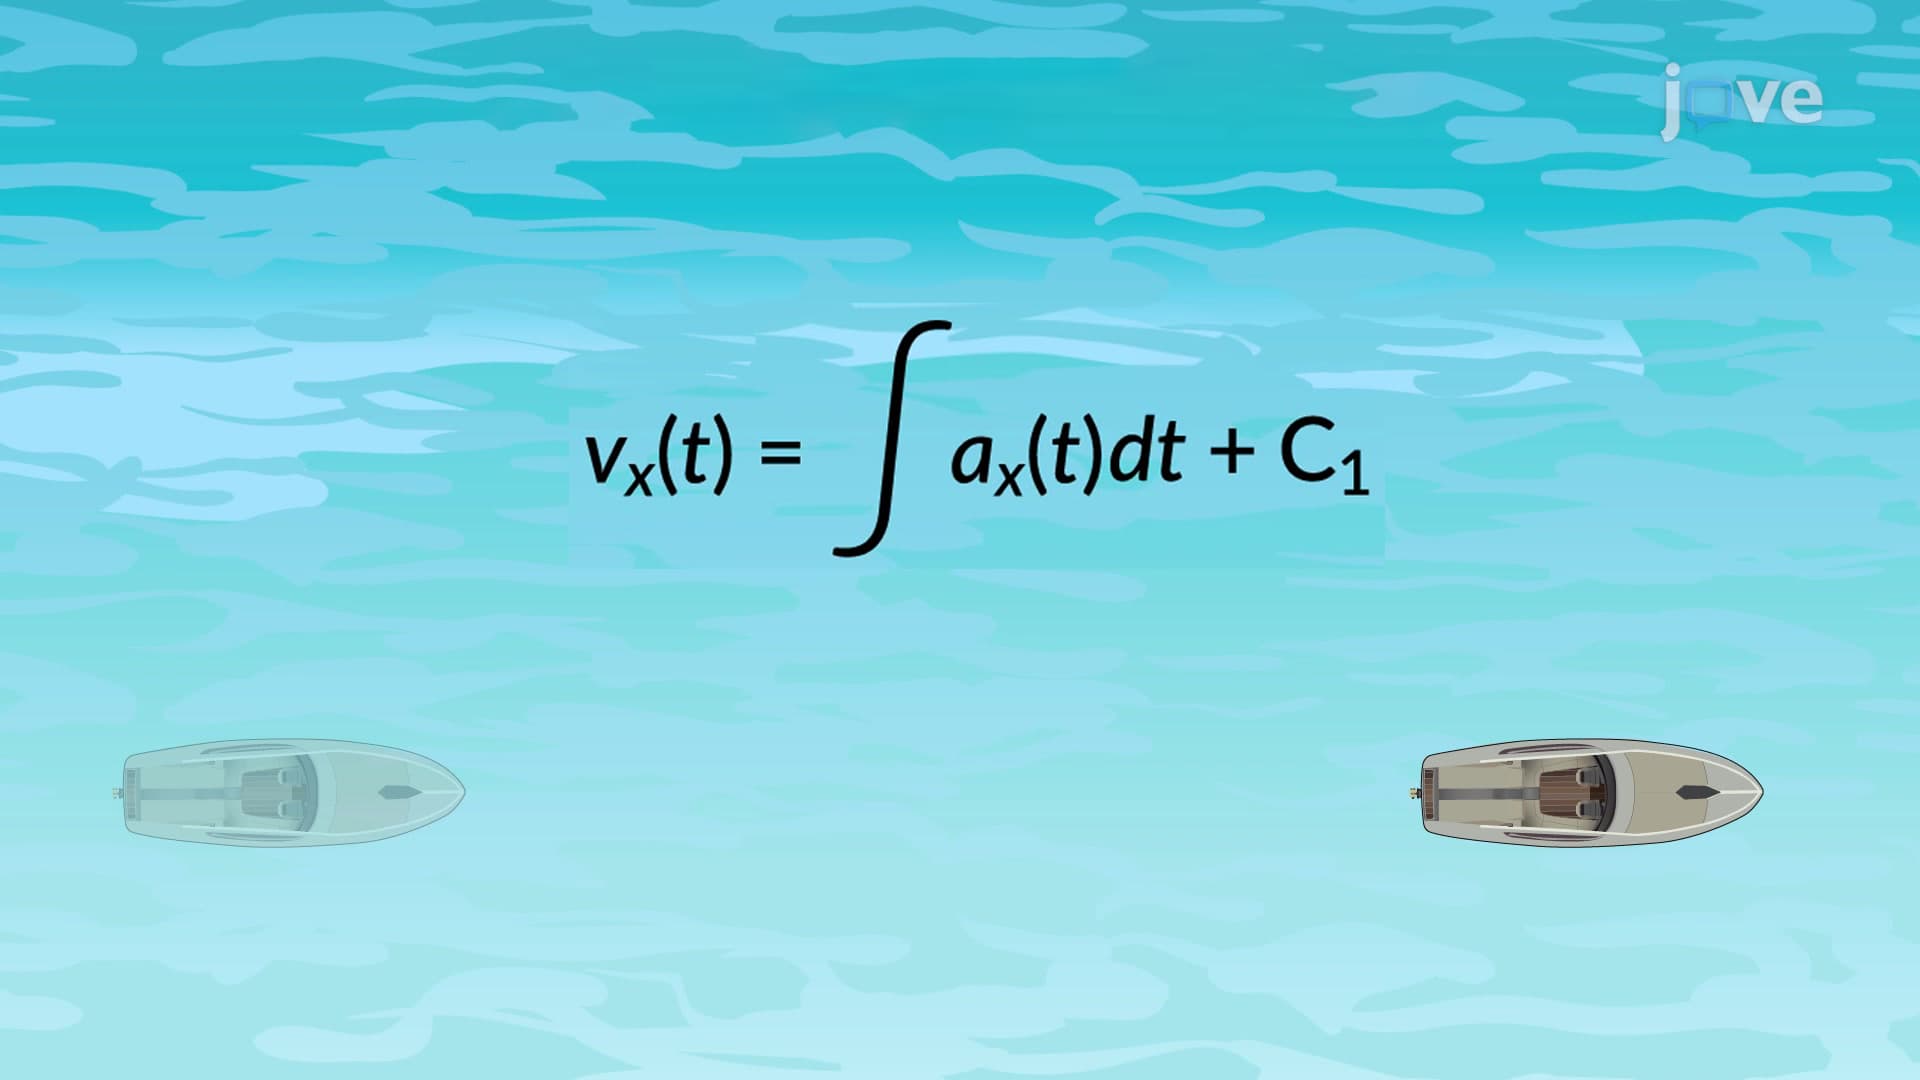 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 00:58
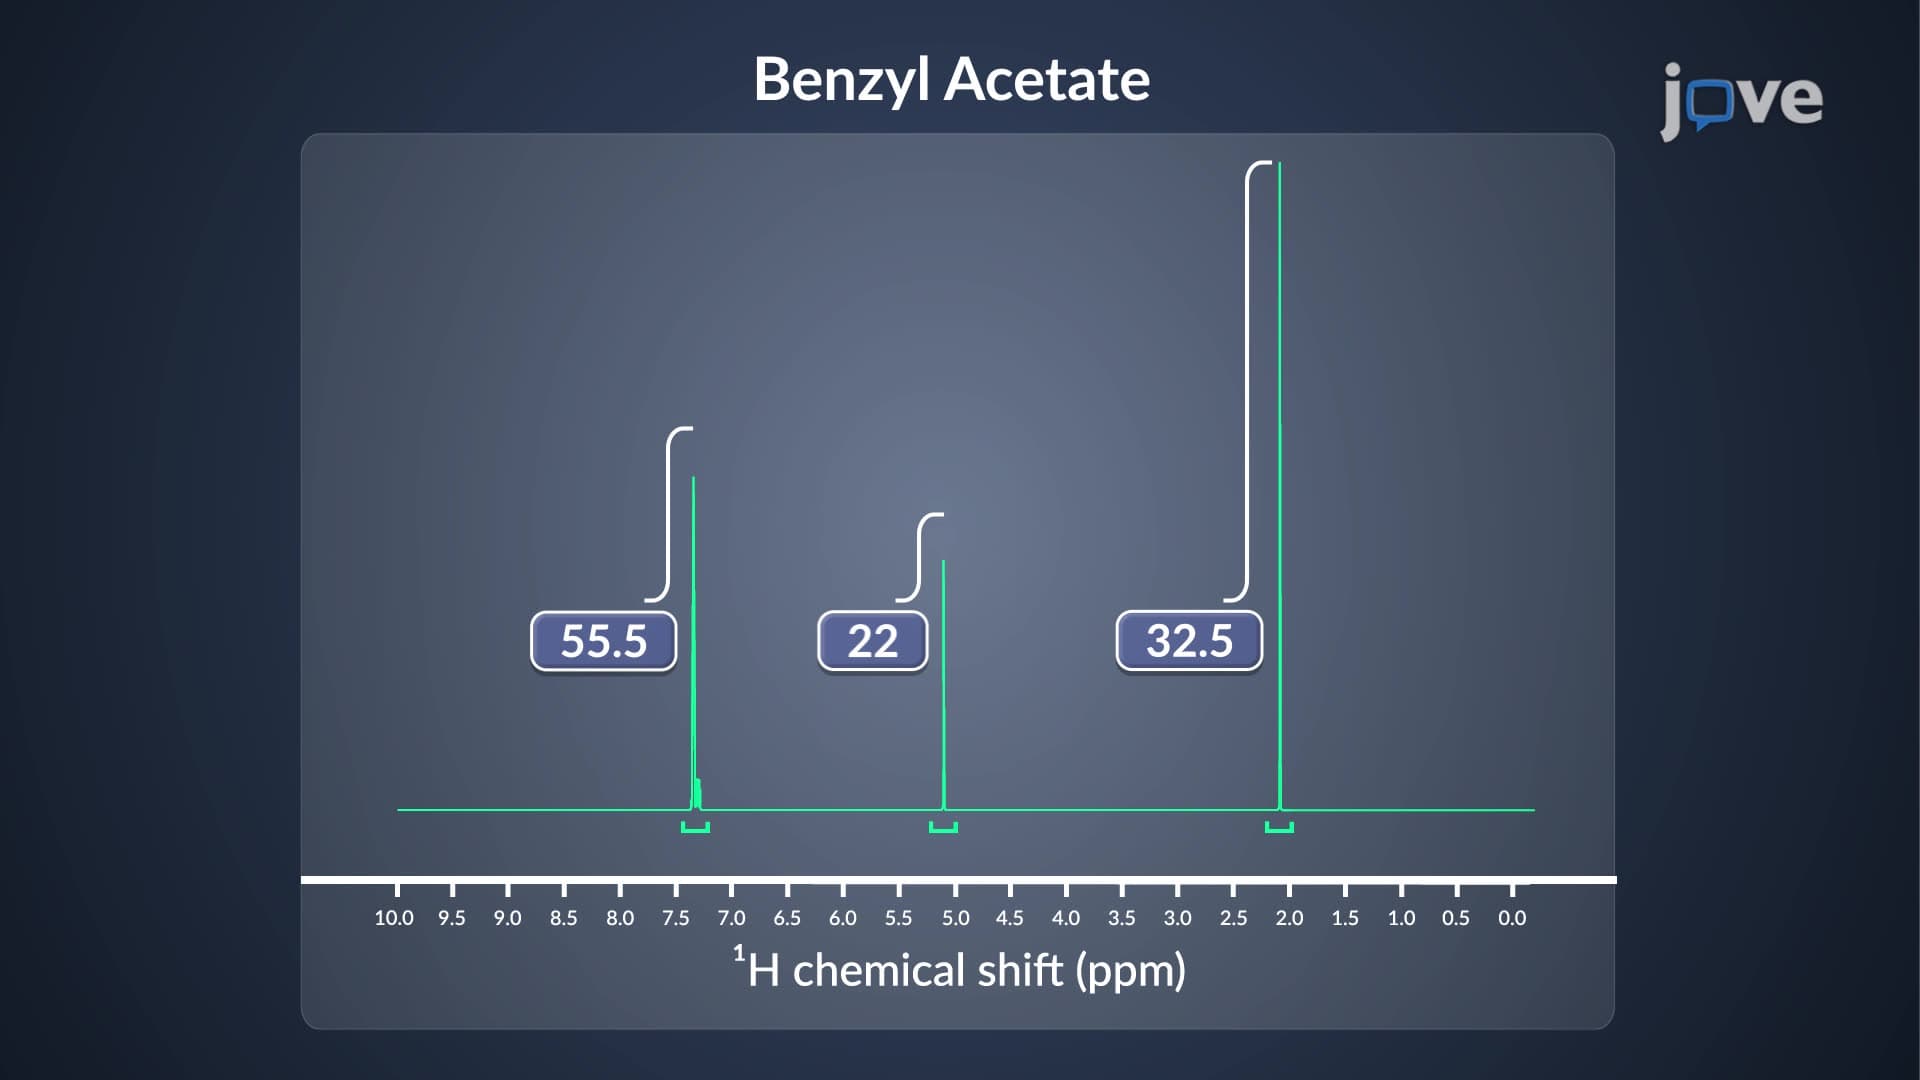
¹H NMR Signal Integration: Overview
 01:27
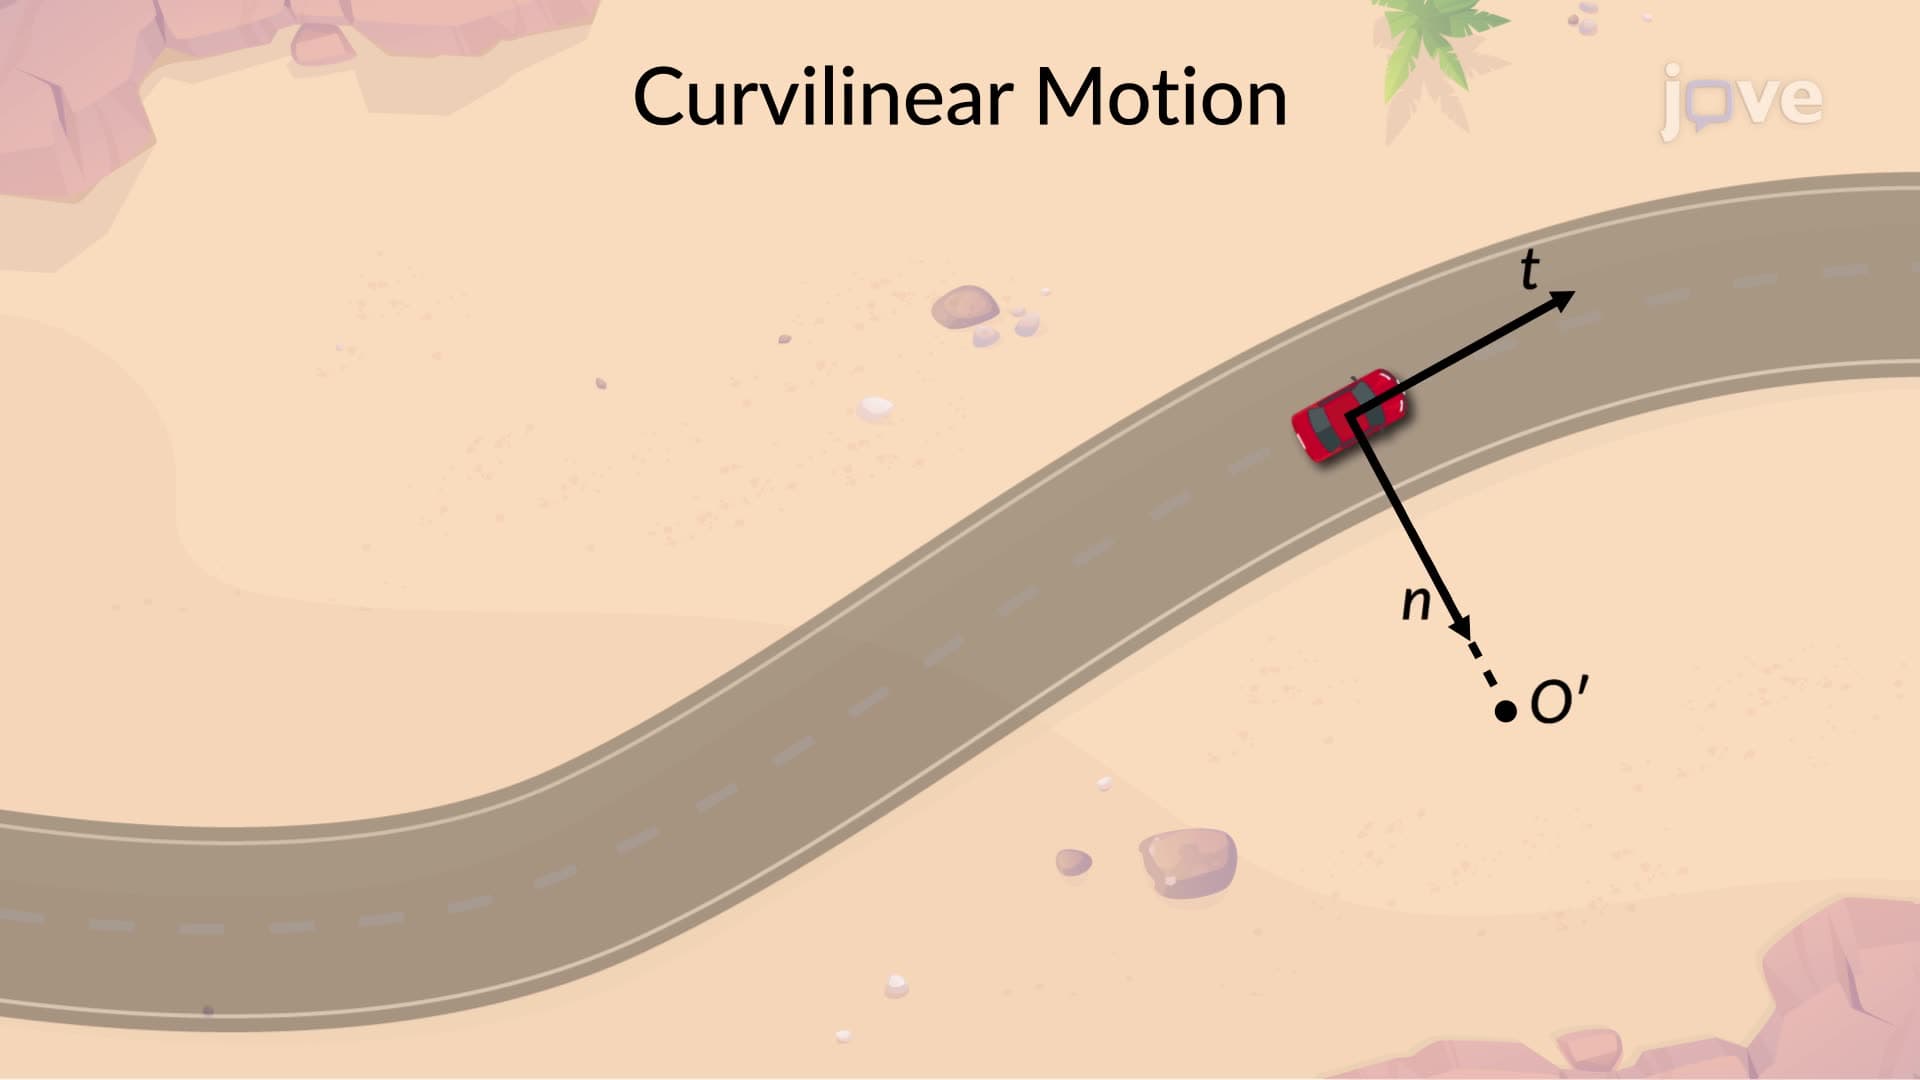
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:30
Derivatives of Inverse Trigonometric Functions
 01:23
Integrals of Vector Functions
 01:21
Changing the Order of Integration in Double Integrals