Related Experiment Video
Updated: Feb 19, 2026
Quantum State Engineering of Light with Continuous-wave Optical Parametric Oscillators
Published on: May 30, 2014
Simpplified extended Kalman filter phase noise estimation for CO-OFDM transmissions

Abstract:
We propose a flexible simplified extended Kalman filter (S-EKF) scheme that can be applied in both pilot-aided and blind modes for phase noise compensation in 16-QAM CO-OFDM transmission systems employing a small-to-moderate number of subcarriers. The performance of the proposed algorithm is evaluated and compared with conventional pilot-aided (PA) and blind phase search (BPS) methods via extensive an Monte Carlo simulation in a back-to-back configuration and with a dual polarization fiber transmission. For 64 subcarrier 32 Gbaud 16-QAM CO-OFDM systems with 200 kHz combined laser linewidths, an optical signal-to-noise ratio penalty as low as 1 dB can be achieved with the proposed S-EKF scheme using only 2 pilots in the pilot-aided mode and just 4 inputs in the blind mode, resulting in a spectrally efficient enhancement by a factor of 3 and a computational effort reduction by a factor of more than 50 in comparison with the conventional PA and the BPS methods, respectively.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 10:00
Calibration of Vector Network Analyzer for Measurements in Radio Frequency Propagation Channels
Published on: June 2, 2020
Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:16
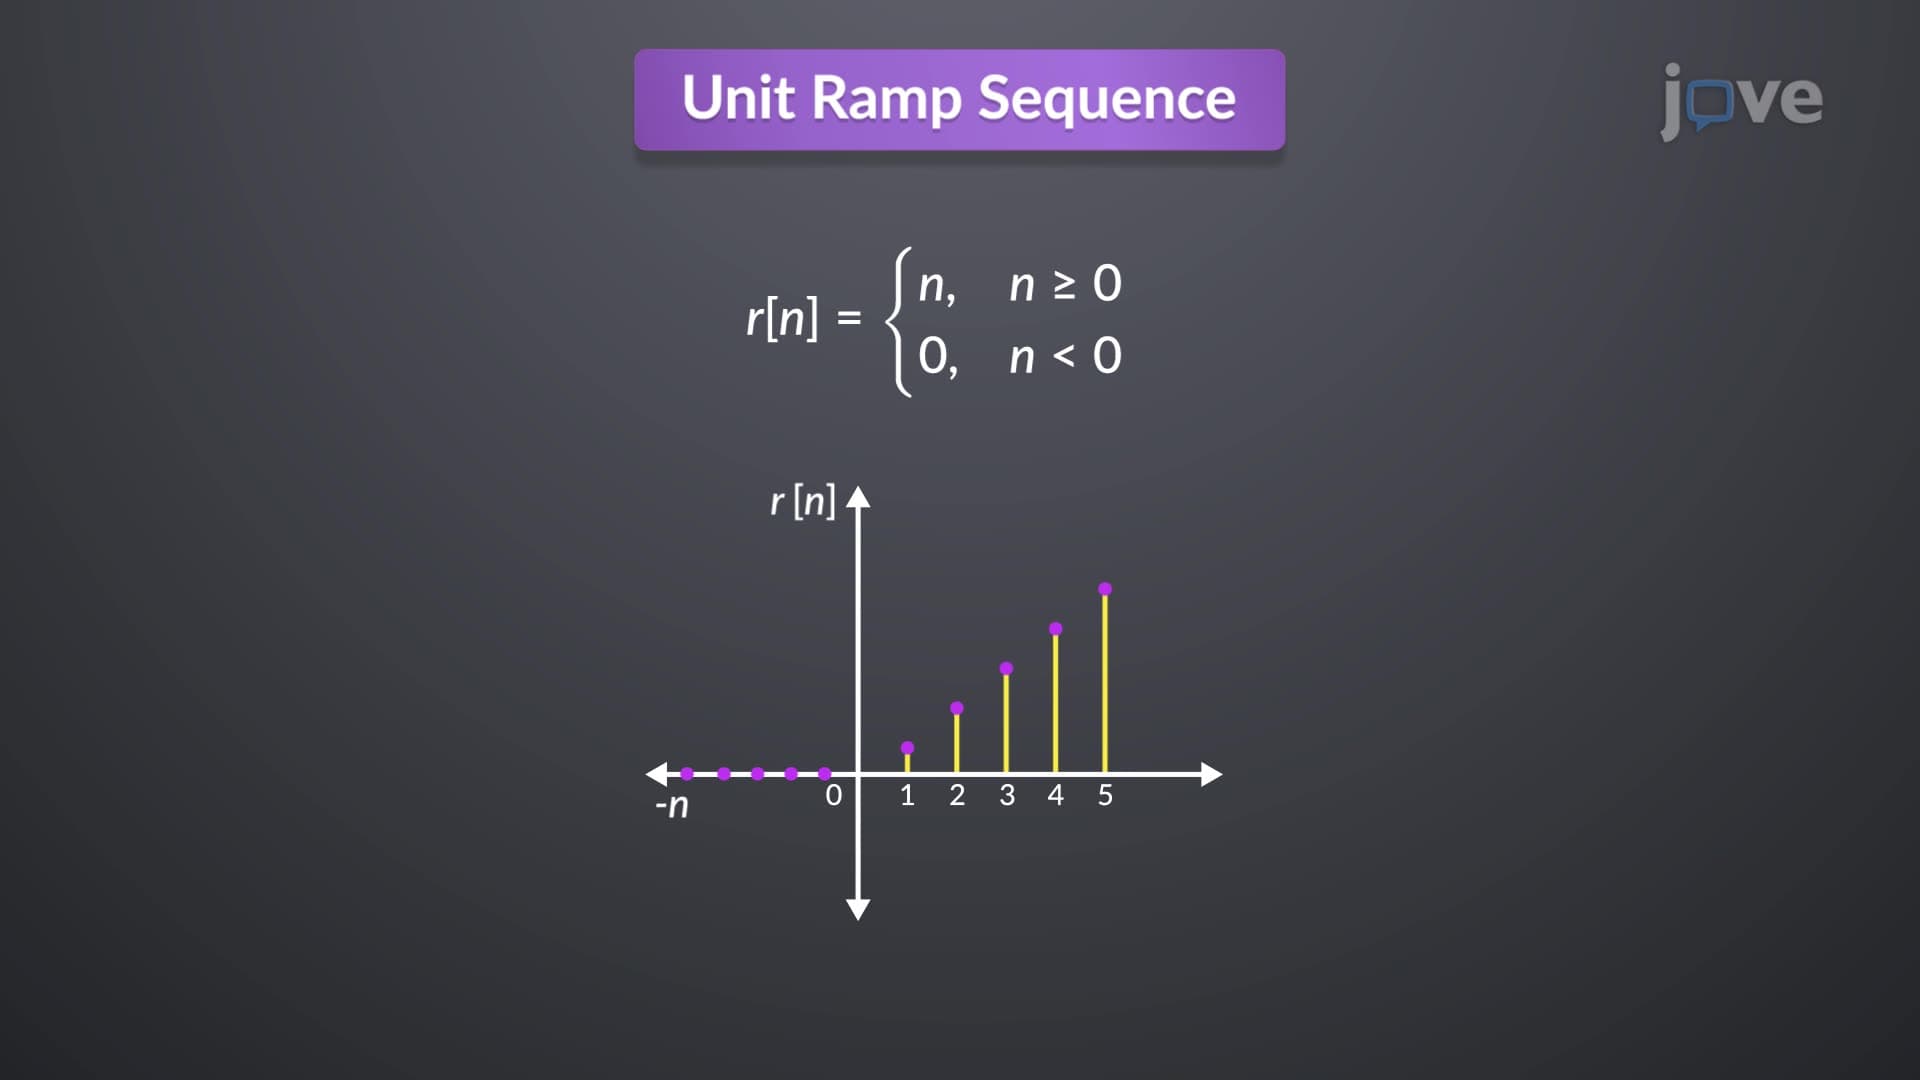
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:11
Sampling Continuous Time Signal
In the...