Vectorization of a classical trajectory code on a floating point systems, Inc. Model 164 attached processor
Related Experiment Video
Updated: Feb 18, 2026

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Wayne A Kraus1, Albert F Wagner1
1Theoretical Chemistry Group, Chemistry Division, Argonne National Laboratory, Argonne, Illinois 60439.

Abstract:
A triatomic classical trajectory code has been modified by extensive vectorization of the algorithms to achieve much improved performance on an FPS 164 attached processor. Extensive timings on both the FPS 164 and a VAX 11/780 with floating point accelerator are presented as a function of the number of trajectories simultaneously run. The timing tests involve a potential energy surface of the LEPS variety and trajectories with 1000 time steps. The results indicate that vectorization results in timing improvements on both the VAX and the FPS. For larger numbers of trajectories run simultaneously, up to a factor of 25 improvement in speed occurs between VAX and FPS vectorized code.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:16
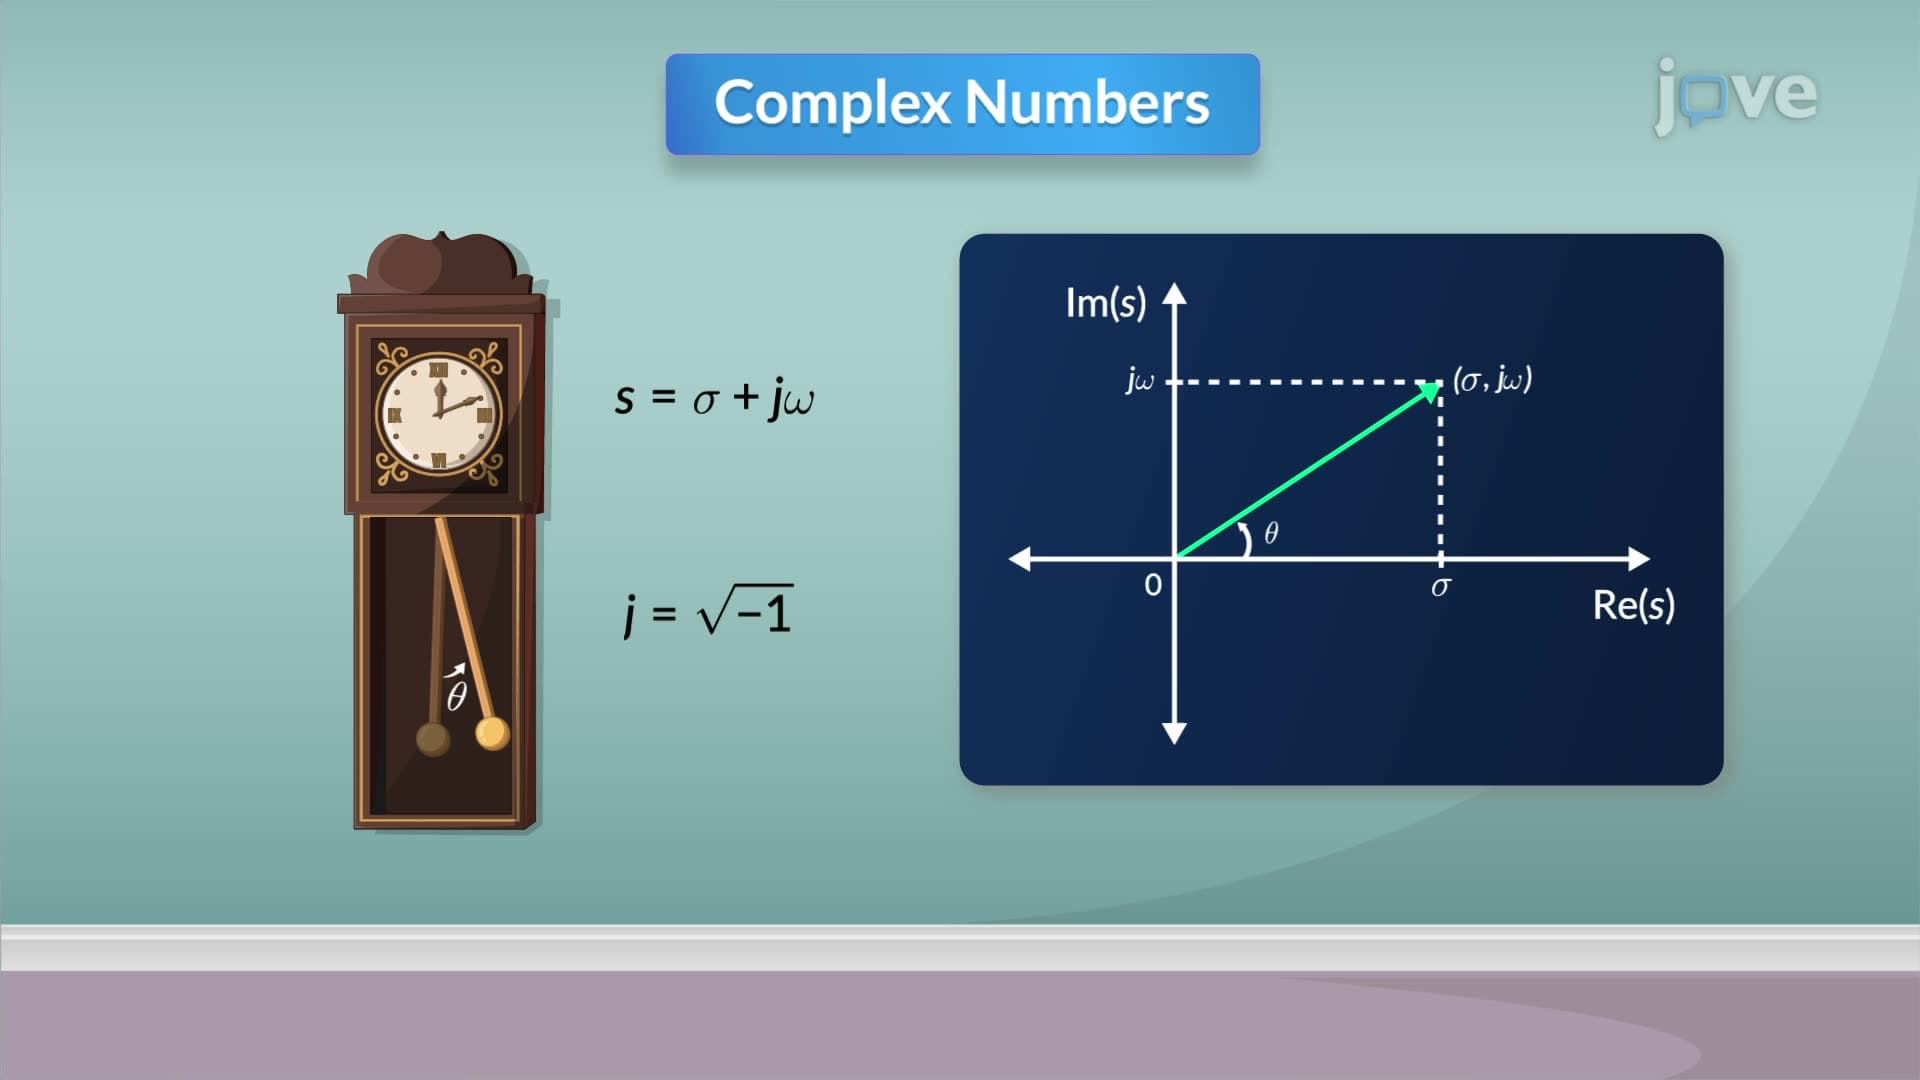
Vector Representation of Complex Numbers
Consider a function defined as the product of the complex factors in the numerator divided by the product of the complex factors in the...
 01:26
Orthogonal Trajectories
 01:19
Euler Equations of Motion
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:30
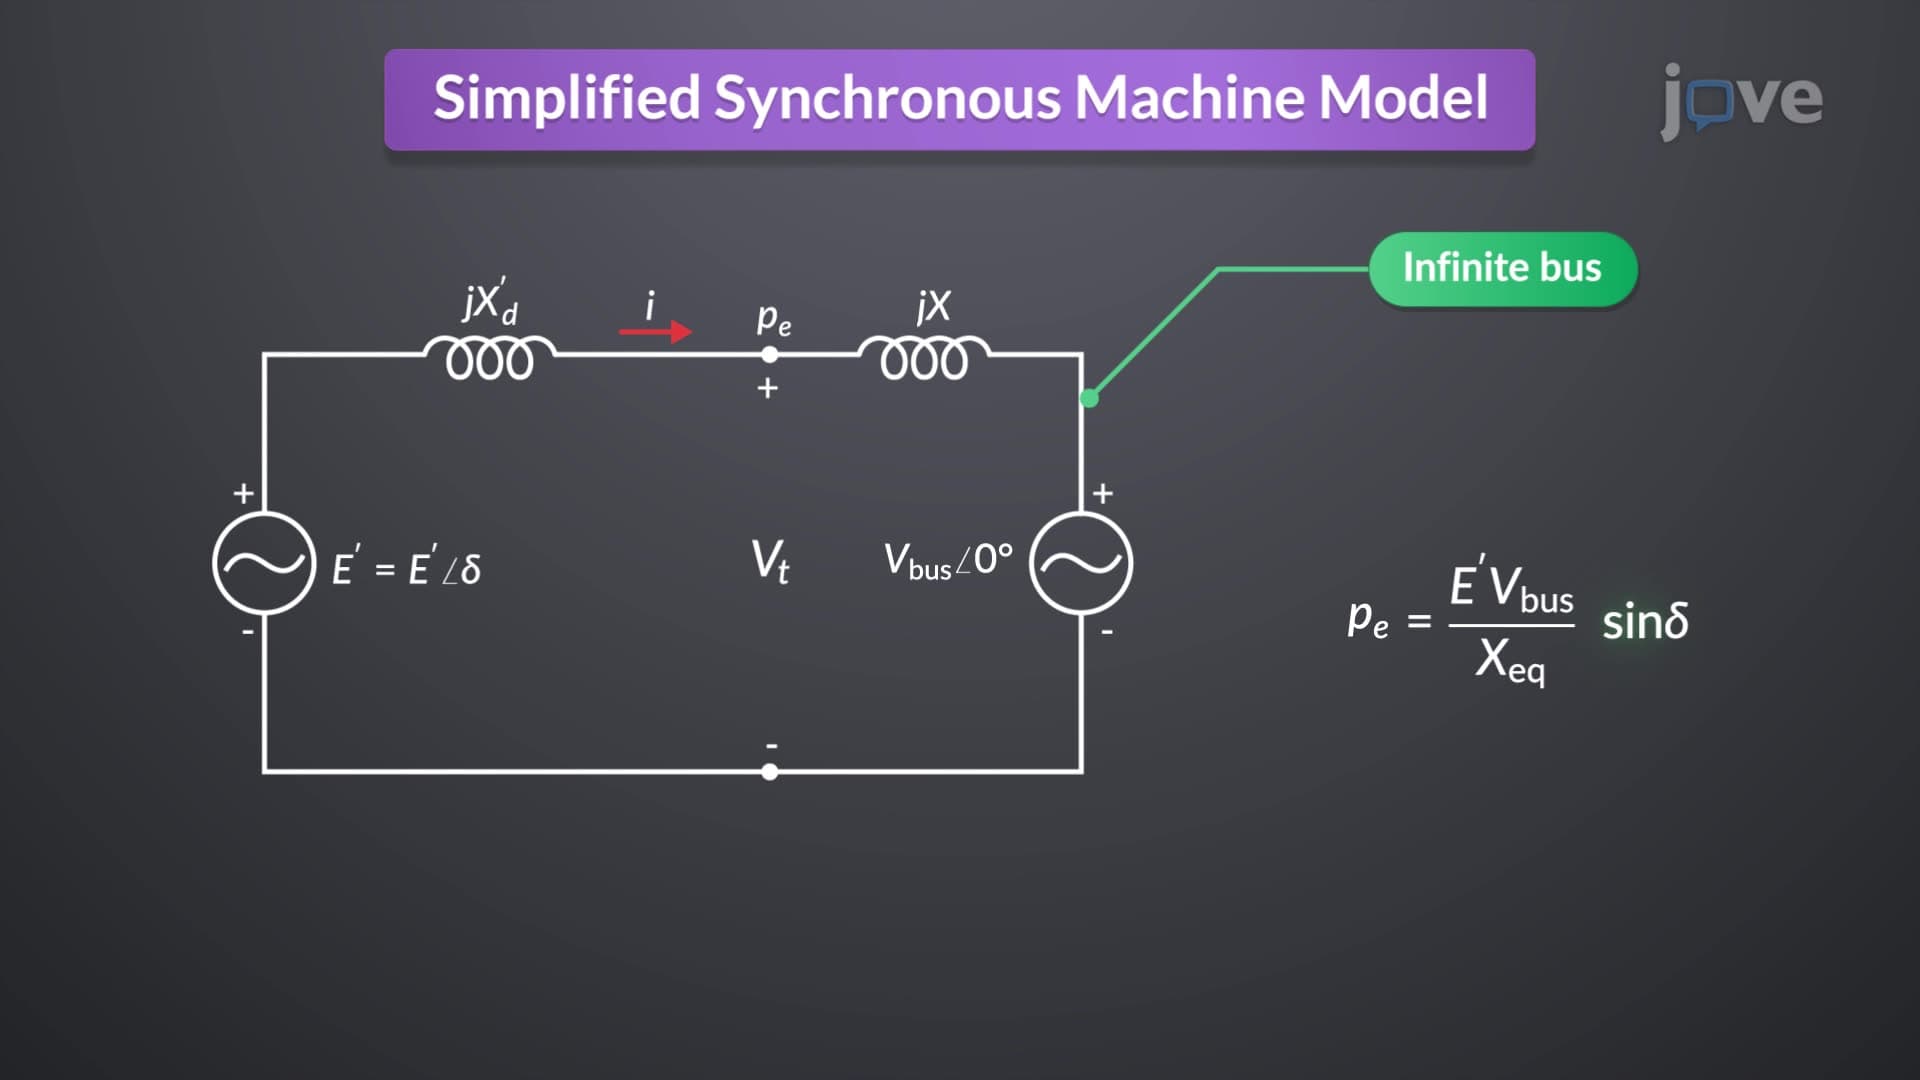
Simplified Synchronous Machine Model
In this model, each generator is connected to a...