A practical step length algorithm using lower limb angular velocities
Related Experiment Video
Updated: Feb 17, 2026
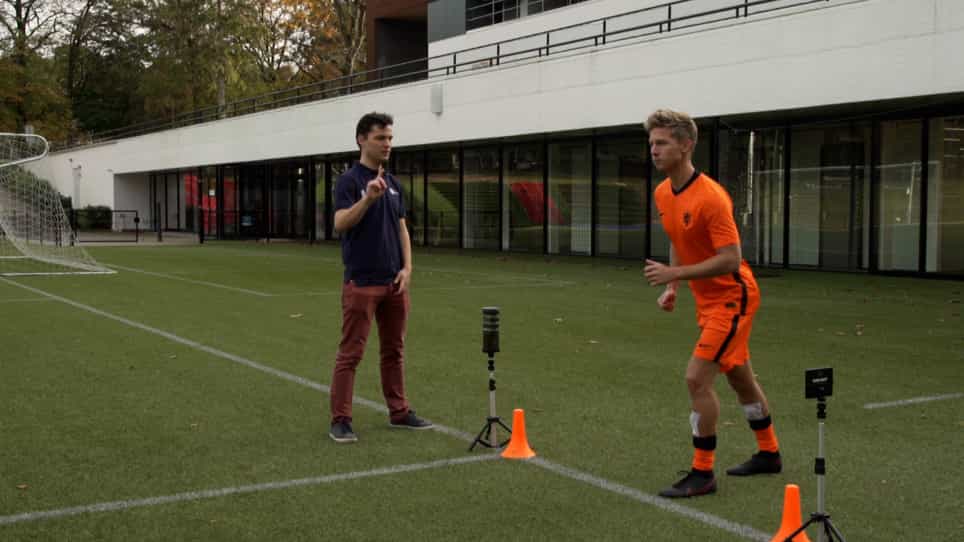
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
E Allseits1, V Agrawal2, J Lučarević3
1University of Miami, Department of Biomedical Engineering, Coral Gables, FL, USA.

Abstract:
The use of Inertial Measurement Units (IMUs) for spatial gait analysis has opened the door to unconstrained measurements within the home and community. Bandwidth, cost limitations, and ease of use has historically restricted the number and location of sensors worn on the body. In this paper, we describe a four-sensor configuration of IMUs placed on the shanks and thighs that is sufficient to provide an accurate measure of temporal gait parameters, spatial gait parameters, and joint angle dynamics during ambulation. Estimating spatial gait parameters solely from gyroscope data is preferred because gyroscopes are less susceptible to sensor noise and a system comprised of only gyroscopes uses decreased bandwidth compared to a typical 9 degree-of-freedom IMU. The purpose of this study was to determine the validity of a novel method of step length estimation using gyroscopes attached to the shanks and thighs. An Inverted Pendulum Model algorithm (IPM) was proposed to calculate step length, stride length, and gait speed. The algorithm incorporates heel-strike events and average forward velocity per step to make these assessments. IMU algorithm accuracy was determined via concurrent validity with an instrumented walkway and results explained via the collision model of gait. The IPM produced accurate estimates of step length, stride length, and gait speed with a mean difference of 3 cm and an RMSE of 6.6 cm for step length, thus establishing a new approach for spatial gait parameter calculation. The lack of numerical integration in IPM makes it well suited for use in continuous monitoring applications where sensor sampling rates are restricted.
Related Concept Videos
 01:11
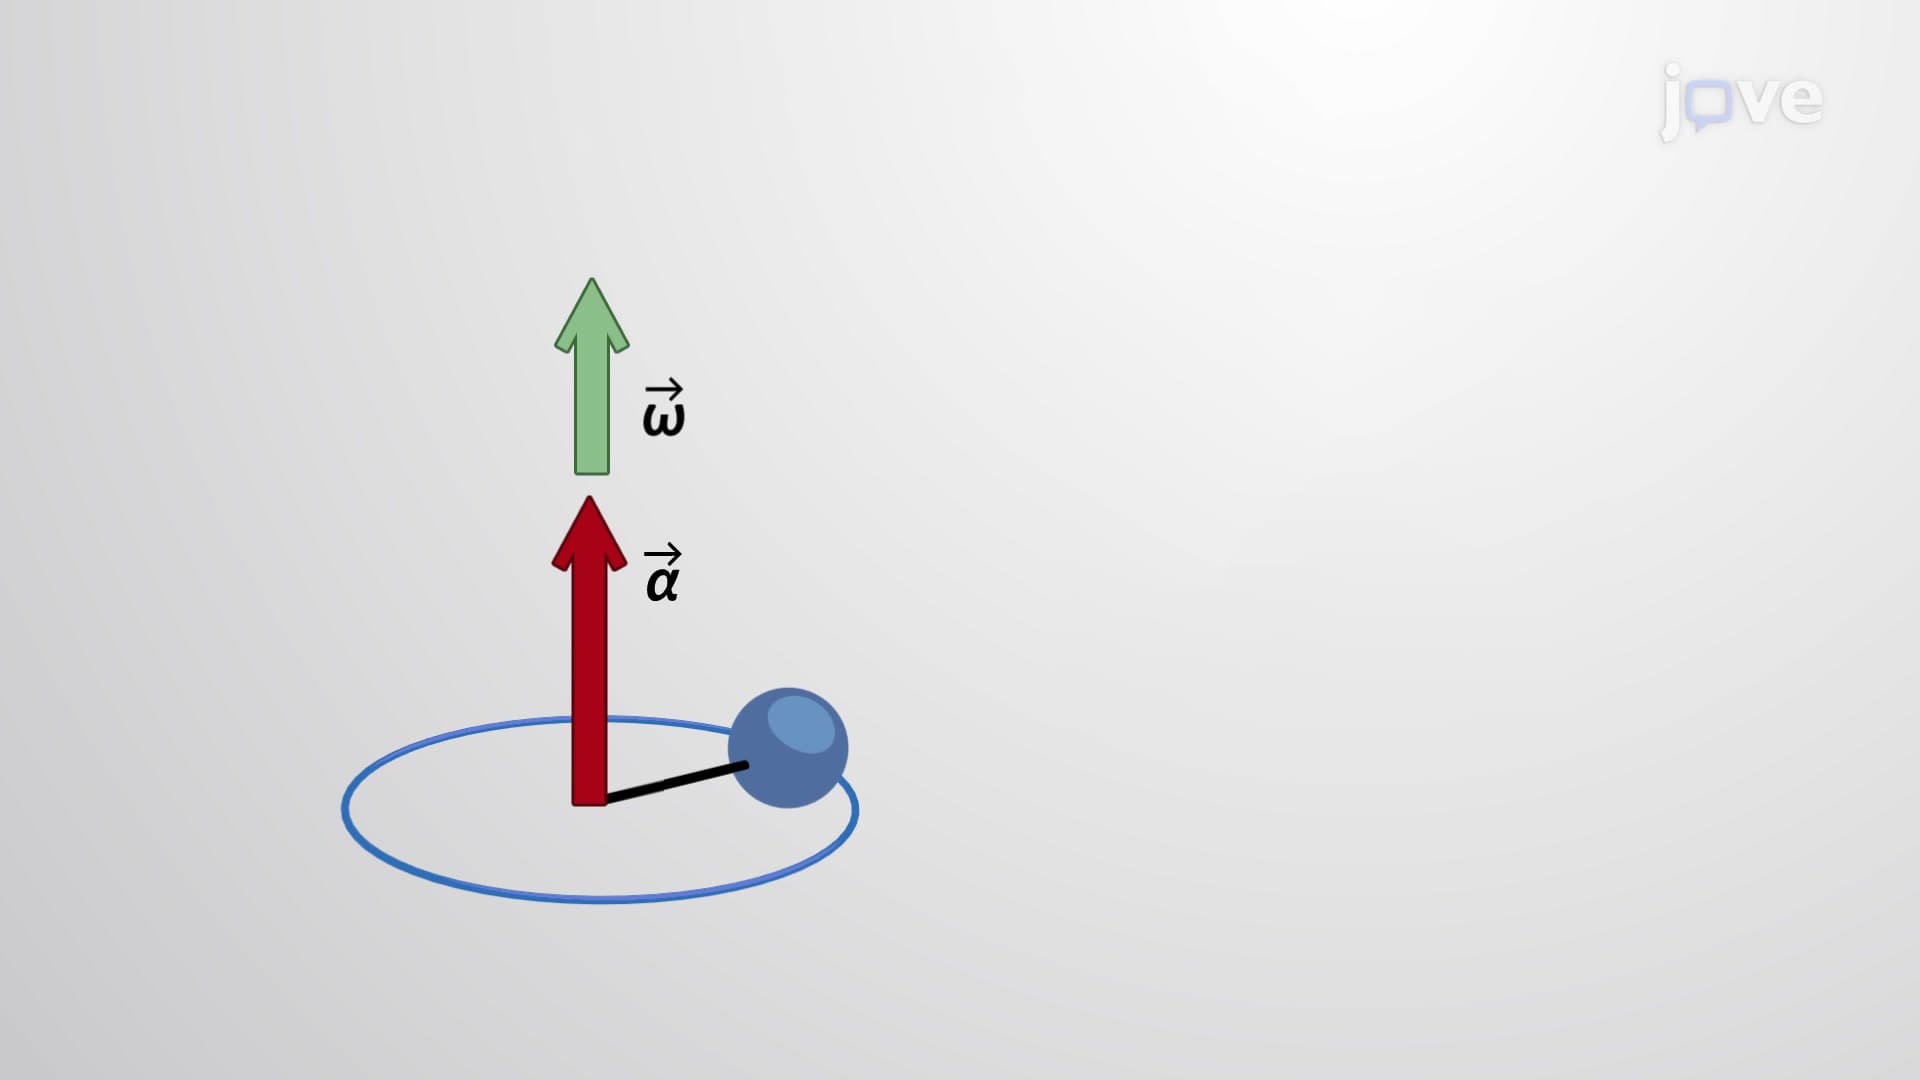
Angular Velocity and Acceleration
 01:15
Kinematic Equations: Problem Solving
 01:37
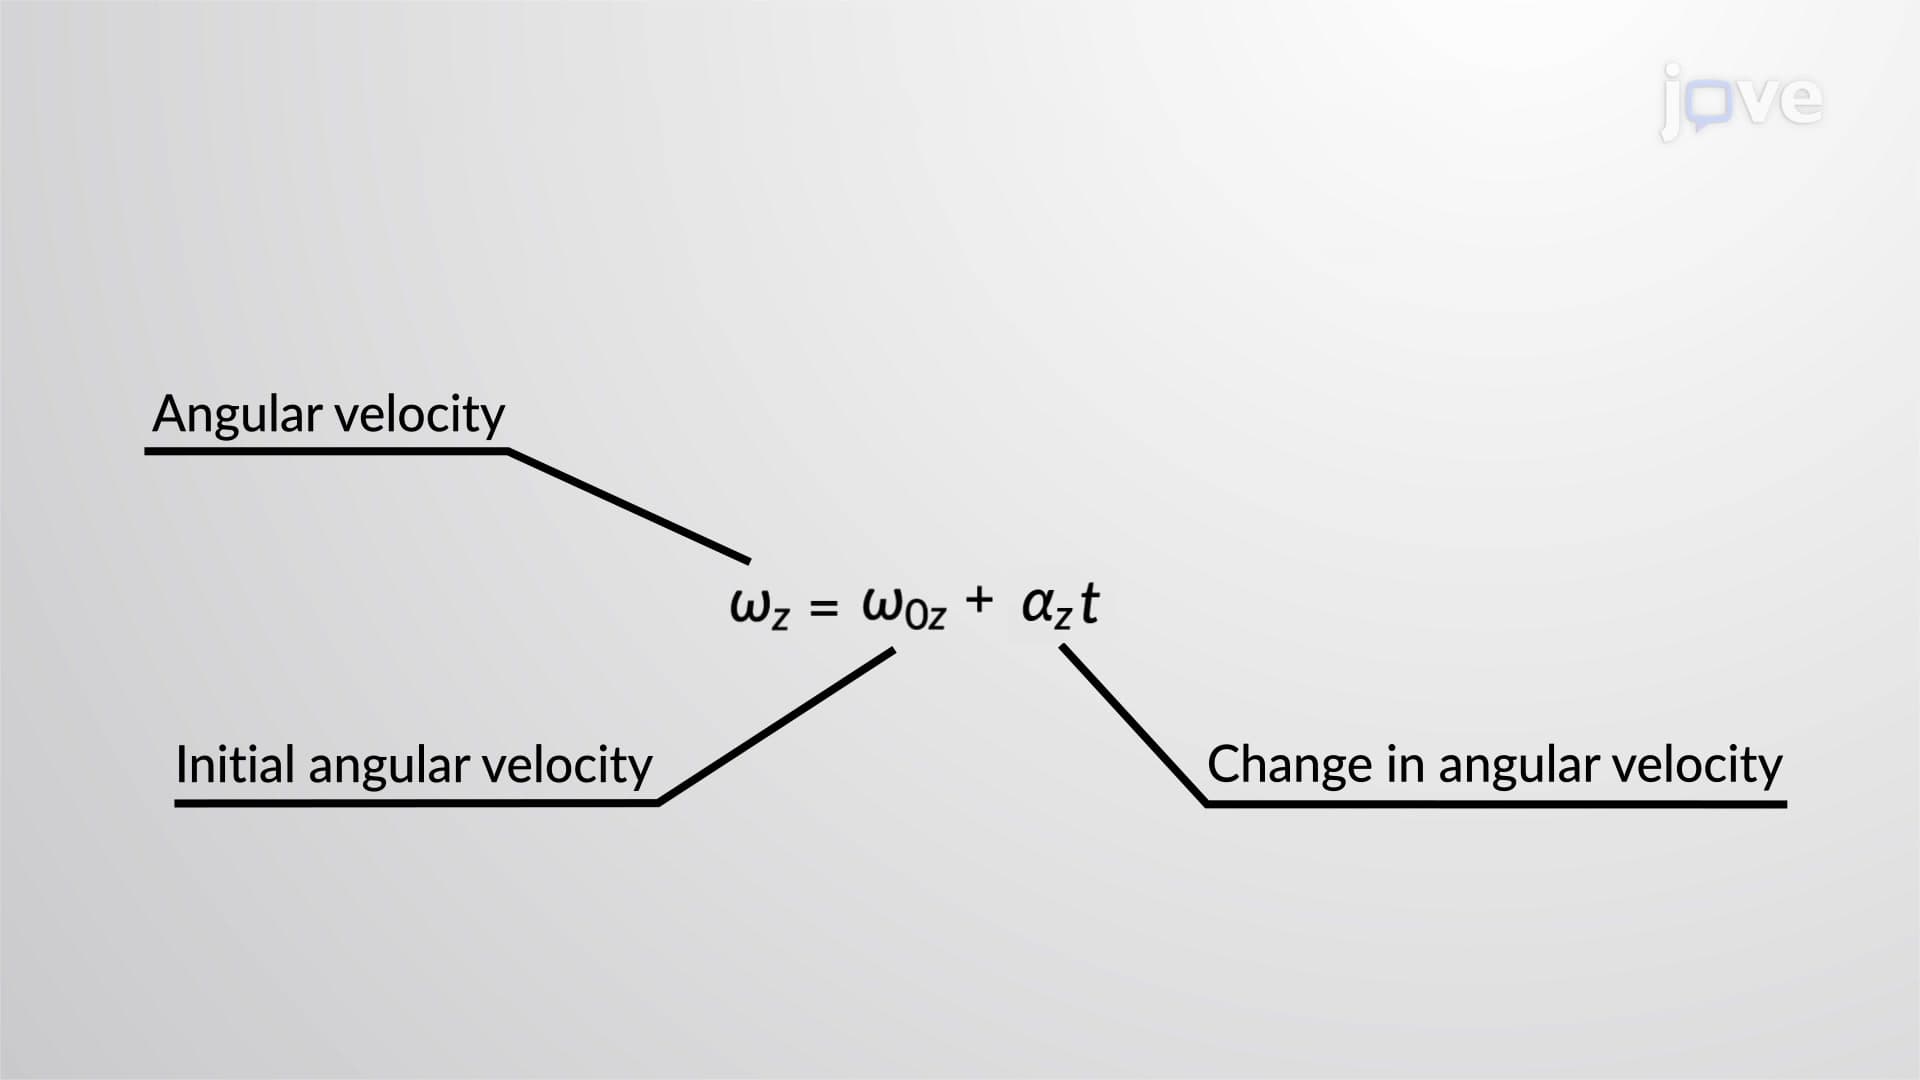
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:09
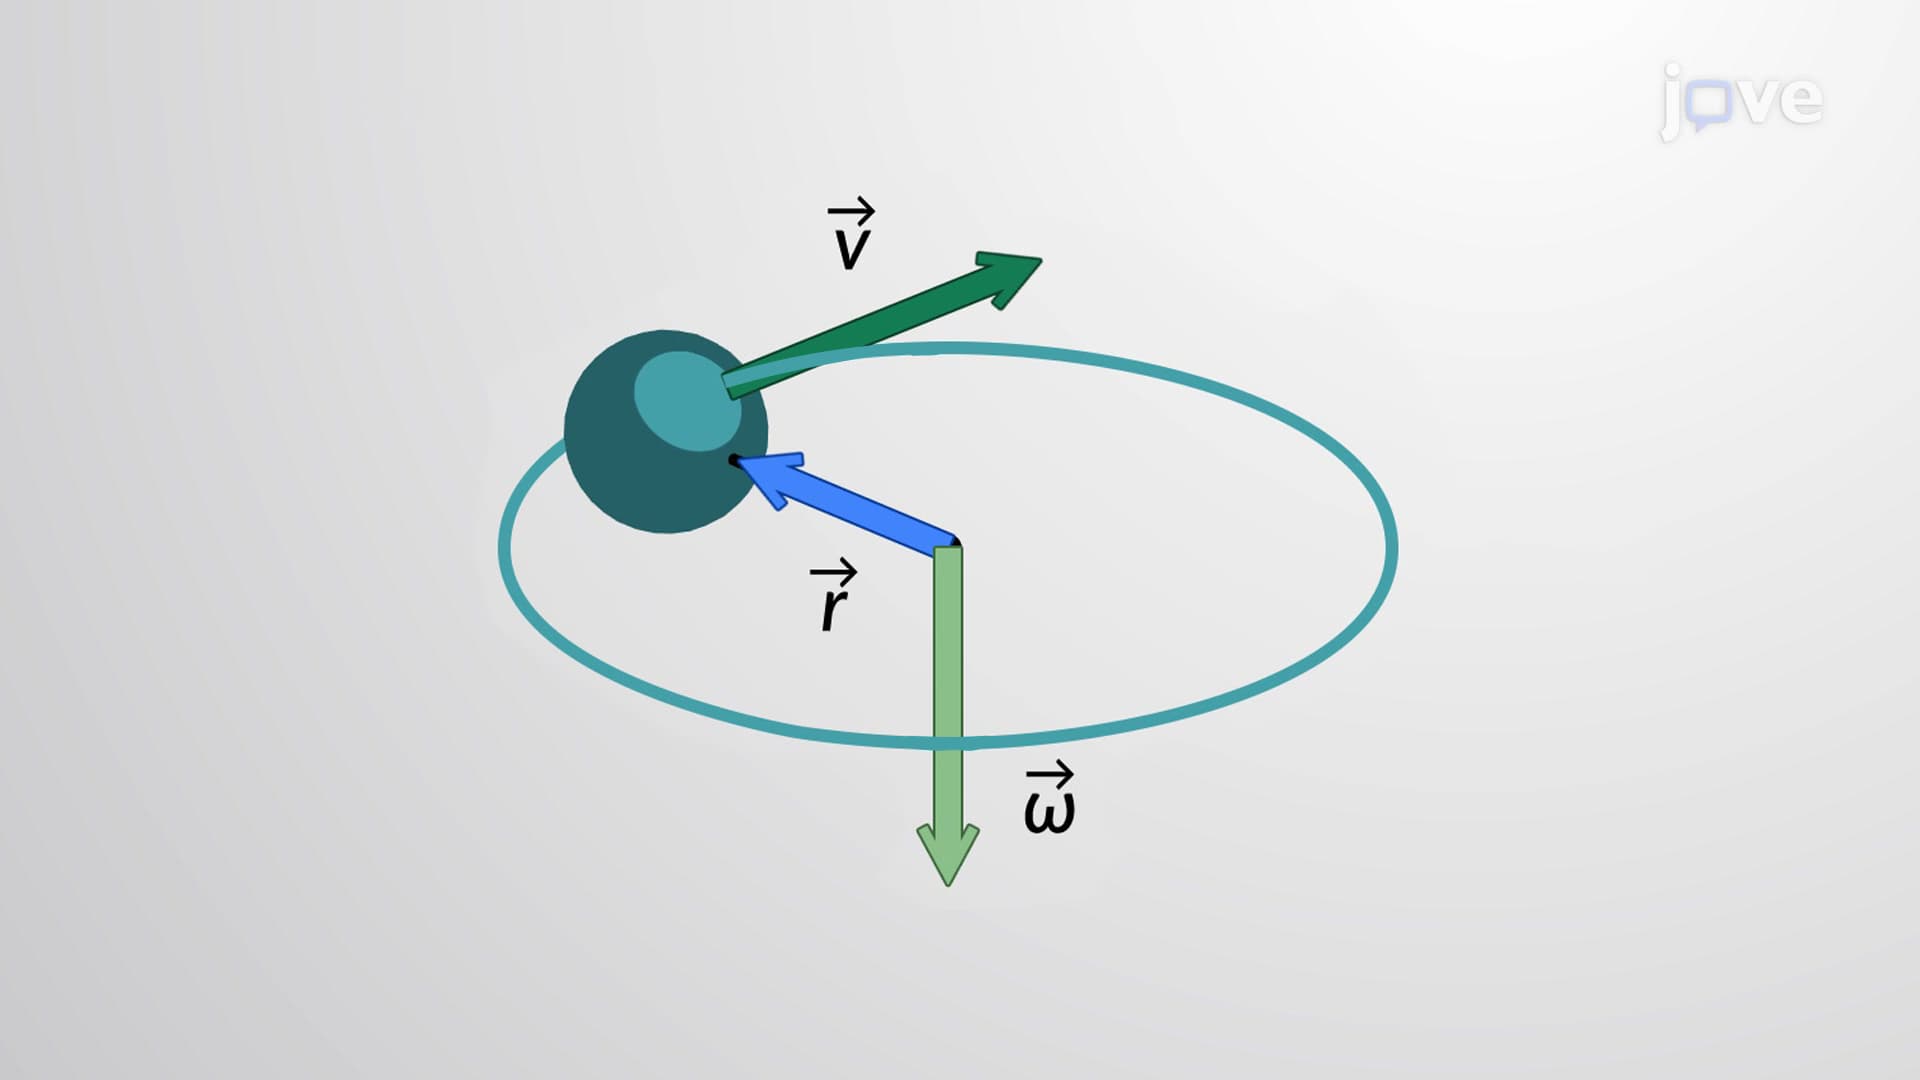
Relating Angular And Linear Quantities - I
When comparing the linear and rotational variables individually, the linear variable of position has physical units of meters, whereas the angular position variable has dimensionless units of radians, as it is the ratio of two lengths. The linear velocity...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration