Related Experiment Video
Updated: Feb 17, 2026


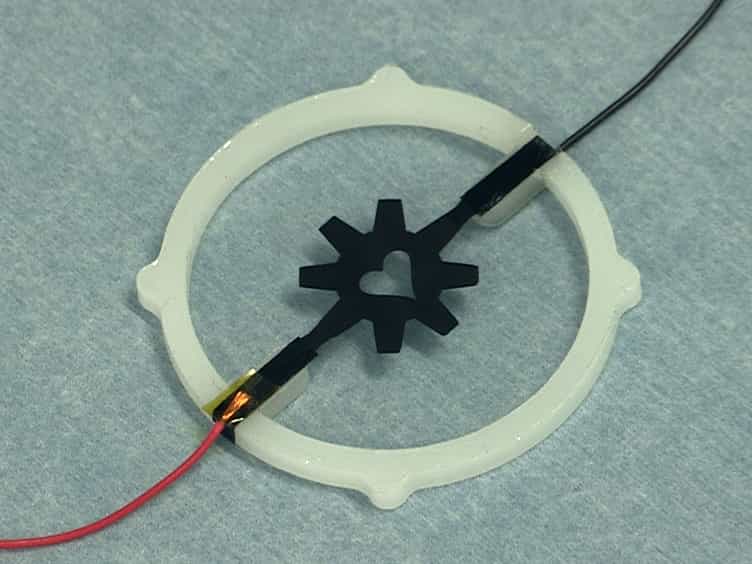
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Custom 3D Printable Silicones with Tunable Stiffness
Matthew M Durban1, Jeremy M Lenhardt1, Amanda S Wu1
1Lawrence Livermore National Laboratory, Livermore, CA, 94550, USA.

Abstract:
Silicone elastomers have broad versatility within a variety of potential advanced materials applications, such as soft robotics, biomedical devices, and metamaterials. A series of custom 3D printable silicone inks with tunable stiffness is developed, formulated, and characterized. The silicone inks exhibit excellent rheological behavior for 3D printing, as observed from the printing of porous structures with controlled architectures. Herein, the capability to tune the stiffness of printable silicone materials via careful control over the chemistry, network formation, and crosslink density of the ink formulations in order to overcome the challenging interplay between ink development, post-processing, material properties, and performance is demonstrated.