Related Experiment Video
Updated: Feb 16, 2026
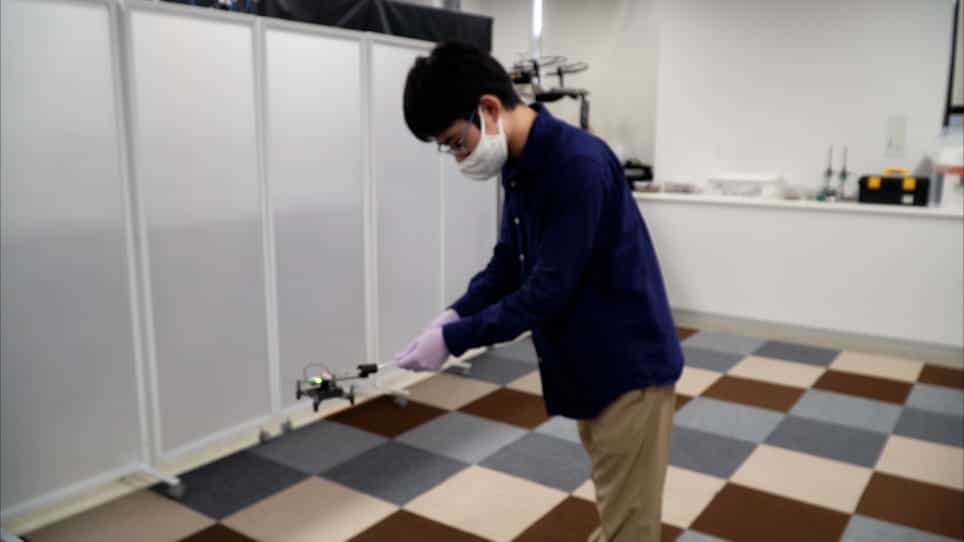

Electroantennography-based Bio-hybrid Odor-detecting Drone using Silkmoth Antennae for Odor Source Localization
Published on: August 27, 2021
Relative position control design of receiver UAV in flying-boom aerial refueling phase
1College of Automation Engineering, Nanjing University of Aeronautics and Astronautics, Nanjing 211106, People's Republic of China.

Abstract:
This paper proposes the design of the relative position-keeping control of the receiver unmanned aerial vehicle (UAV) with the time-varying mass in the refueling phase utilizing an inner-outer loop structure. Firstly, the model of the receiver in the refueling phase is established. And then tank model is set up to analyze the influence of fuel transfer on the receiver. Subsequently, double power reaching law based sliding mode controller is designed to control receiver translational motion relative to tanker aircraft in the outer loop while active disturbance rejection control technique is applied to the inner loop to stabilize the receiver. In addition, the closed-loop stabilities of the subsystems are established, respectively. Finally, an aerial refueling model under various refueling strategies is utilized. Simulations and comparative analysis demonstrate the effectiveness and robustness of the proposed controllers.
More Related Videos

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:22
Phase-lead and Phase-lag Controllers
 01:22
Multi-input and Multi-variable systems
In the absence of...