Related Experiment Video
Updated: Feb 16, 2026
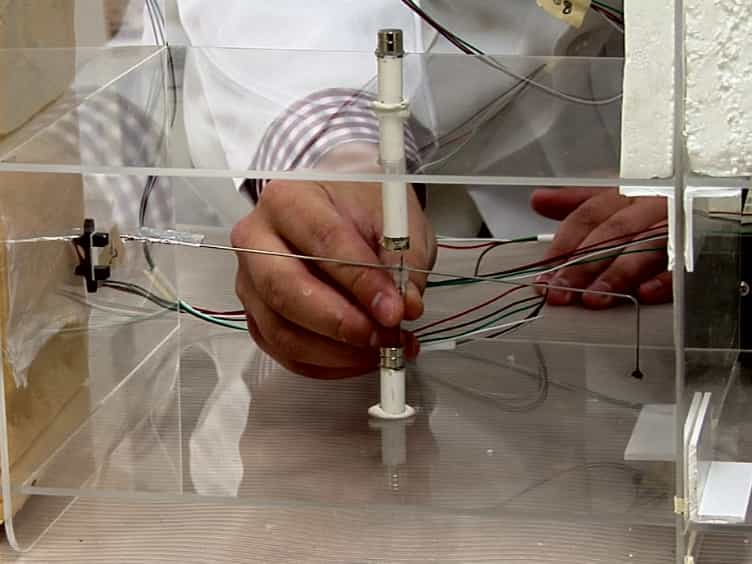

A Simple Flight Mill for the Study of Tethered Flight in Insects
Published on: December 10, 2015
Identification of optimal feedback control rules from micro-quadrotor and insect flight trajectories
Imraan A Faruque1, Florian T Muijres2, Kenneth M Macfarlane3
1School of Mechanical and Aerospace Engineering, Oklahoma State University, Stillwater, OK, USA. i.faruque@okstate.edu.

Abstract:
This paper presents "optimal identification," a framework for using experimental data to identify the optimality conditions associated with the feedback control law implemented in the measurements. The technique compares closed loop trajectory measurements against a reduced order model of the open loop dynamics, and uses linear matrix inequalities to solve an inverse optimal control problem as a convex optimization that estimates the controller optimality conditions. In this study, the optimal identification technique is applied to two examples, that of a millimeter-scale micro-quadrotor with an engineered controller on board, and the example of a population of freely flying Drosophila hydei maneuvering about forward flight. The micro-quadrotor results show that the performance indices used to design an optimal flight control law for a micro-quadrotor may be recovered from the closed loop simulated flight trajectories, and the Drosophila results indicate that the combined effect of the insect longitudinal flight control sensing and feedback acts principally to regulate pitch rate.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Orthogonal Trajectories
 00:46
Feedback Inhibition
 01:47
Osmoregulation in Insects
 02:55
Exceptions to the Octet Rule
 01:01
Feedback Loops