Related Experiment Video
Updated: Feb 15, 2026
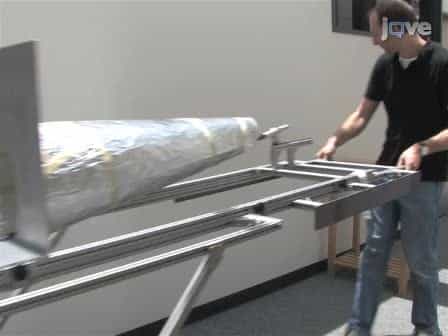

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Operator dynamics for stability condition in haptic and teleoperation system: A survey
Hongbing Li1, Lei Zhang2, Kenji Kawashima3
1Department of Instrument Science and Engineering, Shanghai Jiaotong University, and Shanghai Engineering Research Center for Intelligent Diagnosis and Treatment Instrument, Shanghai, China.

Background:
Currently, haptic systems ignore the varying impedance of the human hand with its countless configurations and thus cannot recreate the complex haptic interactions. The literature does not reveal a comprehensive survey on the methods proposed and this study is an attempt to bridge this gap.
Methods:
The paper includes an extensive review of human arm impedance modeling and control deployed to address inherent stability and transparency issues in haptic interaction and teleoperation systems.
Results:
Detailed classification and comparative study of various contributions in human arm modeling are presented and summarized in tables and diagrams.
Conclusion:
The main challenges in modeling human arm impedance for haptic robotic applications are identified. The possible future research directions are outlined based on the gaps identified in the survey.
More Related Videos

Related Concept Videos
 01:21
Operant Conditioning
Reinforcement in operant conditioning can be positive or negative, both of which serve to increase the likelihood of a behavior. Positive...
 02:16
Surveys
 01:24
Operant Conditioning Intervention
In operant conditioning, behaviors that are...
 01:19
Role of Shaping in Operant Conditioning
The steps involved in shaping begin with reinforcing any response that resembles the desired behavior. For example, parents might praise a child for picking up one toy. As...
 01:27
Introduction to Surveying, Plane Surveying and Geodetic Surveys
 01:19
Errors and Mistakes in Surveying