Related Experiment Video
Updated: Feb 15, 2026

Enactive Phenomenological Approach to the Trier Social Stress Test: A Mixed Methods Point of View
Published on: January 7, 2019
An Emic, Mixed Methods Approach to Defining and Measuring Positive Parenting Among Low-Income, Black Families
Christine McWayne1, Jacqueline S Mattis2, Linnie E Green Wright3
1Eliot-Pearson Department of Child Development, Tufts University.

Research Findings:
This within-group exploratory sequential mixed methods investigation sought to identify how ethnically diverse, urban-residing, low-income Black families conceptualize positive parenting. During the item development phase 119 primary caregivers from Head Start programs participated in focus groups and interviews. These qualitative data were content analyzed using a three-stage iterative process that resulted in the development of a final set of 72 items for a paper-and-pencil measure. In the measure validation phase of the study initial construct validity of the 72-item measure was assessed with an independent sample of 665 respondents. Common factor analyses revealed five dimensions of positive parenting on the Black Parenting Strengths in Context (BPSC) scale that related in expected ways with other parent self-report measures.
Practice And Policy:
BPSC dimensions provide initial support for a more nuanced operationalization of positive parenting than currently exists in any single scale for use with this group, and hold promise for better honoring the culture- and context-specific parenting goals and practices that low-income, Black parents subjectively view as important for producing healthy developmental outcomes for their children.
Related Concept Videos
 02:47
Protein Families
02:47Protein Families
 01:57
Gene Families
Occasionally these regions can be adapted to take on new roles within the organism, becoming novel genes...
01:57Gene Families
 00:55
Parental Care
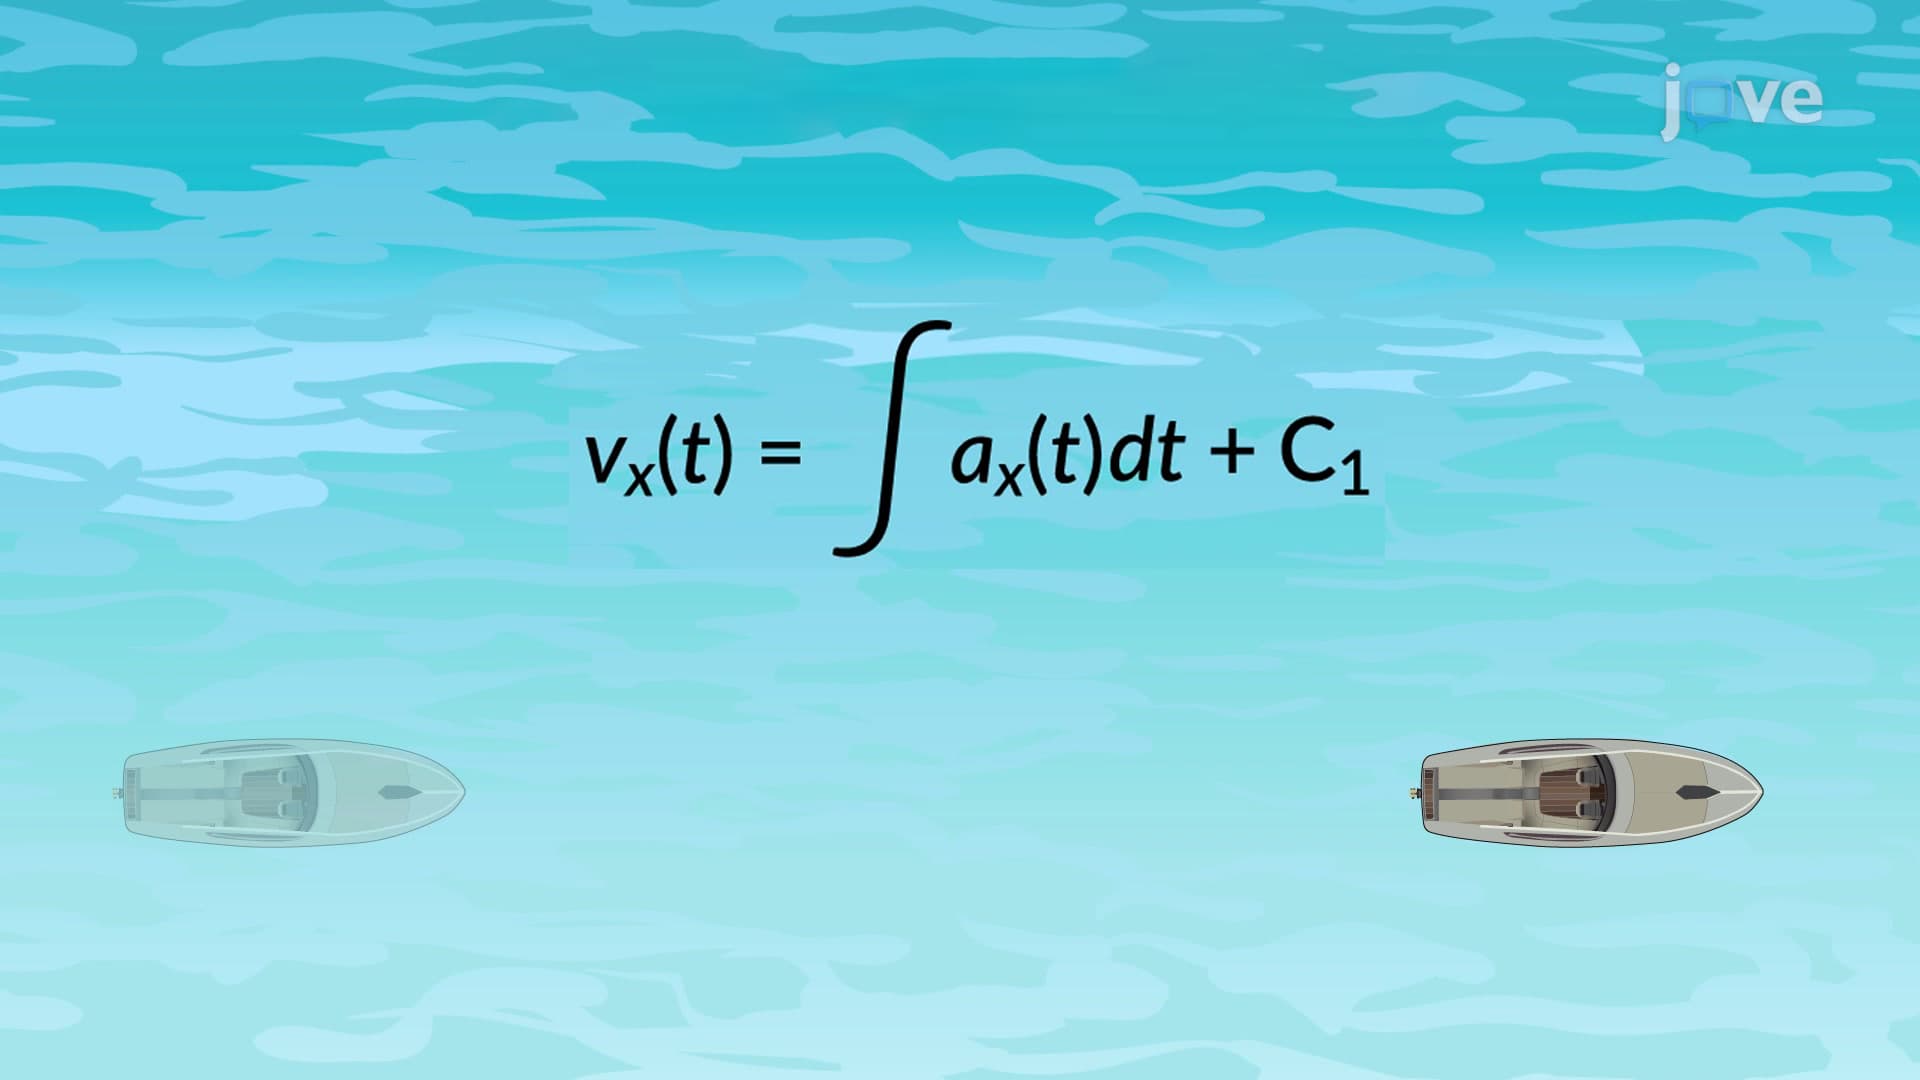 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...