Related Experiment Video
Updated: Feb 15, 2026
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Kinematics and Stability Analysis of a Novel Power Wheelchair When Traversing Architectural Barriers
Jorge Candiotti1,2, S Andrea Sundaram1,2, Brandon Daveler1,2
1Human Engineering Research Laboratories, VA Pittsburgh Healthcare System, Pittsburgh, Pennsylvania.

Abstract:
Background: Electric-powered wheelchairs (EPWs) are essential devices for people with disabilities for mobility and quality of life. However, the design of common EPWs makes it challenging for users to overcome architectural barriers, such as curbs and steep ramps. Current EPWs lack stability, which may lead to tipping the EPW causing injury to the user. An alternative Mobility Enhancement Robotic Wheelchair (MEBot), designed at the Human Engineering Research Laboratories (HERL), was designed to improve the mobility of, and accessibility for, EPW users in a wide variety of indoor and outdoor environments. Seat height and seat inclination can be adjusted using pneumatic actuators connected to MEBot's 6 wheels. Method: This article discusses the design and development of MEBot, including its kinematics, stability margin, and calculation of the center of mass location when performing its mobility applications of curb climbing/descending and attitude control. Motion capture cameras recorded the seat angle and joint motion of the 6 wheel arms during the curb climbing/descending process. The center of mass location was recorded over a force plate for different footprint configurations. Results: Results showed that the area of the footprint changed with the location of the wheels during the curb climbing/descending and attitude control applications. The location of the center of mass moved ±30 mm when the user leaned sideways, and the seat roll and pitch angle were 0° and ±4.0°, respectively, during curb climbing and descending. Conclusion: Despite the user movement and seat angle change, MEBot maintained its stability as the center of mass remained over the wheelchair footprint when performing its mobility applications.
More Related Videos
Related Concept Videos
 01:12
Adjusting a Traverse
 01:25
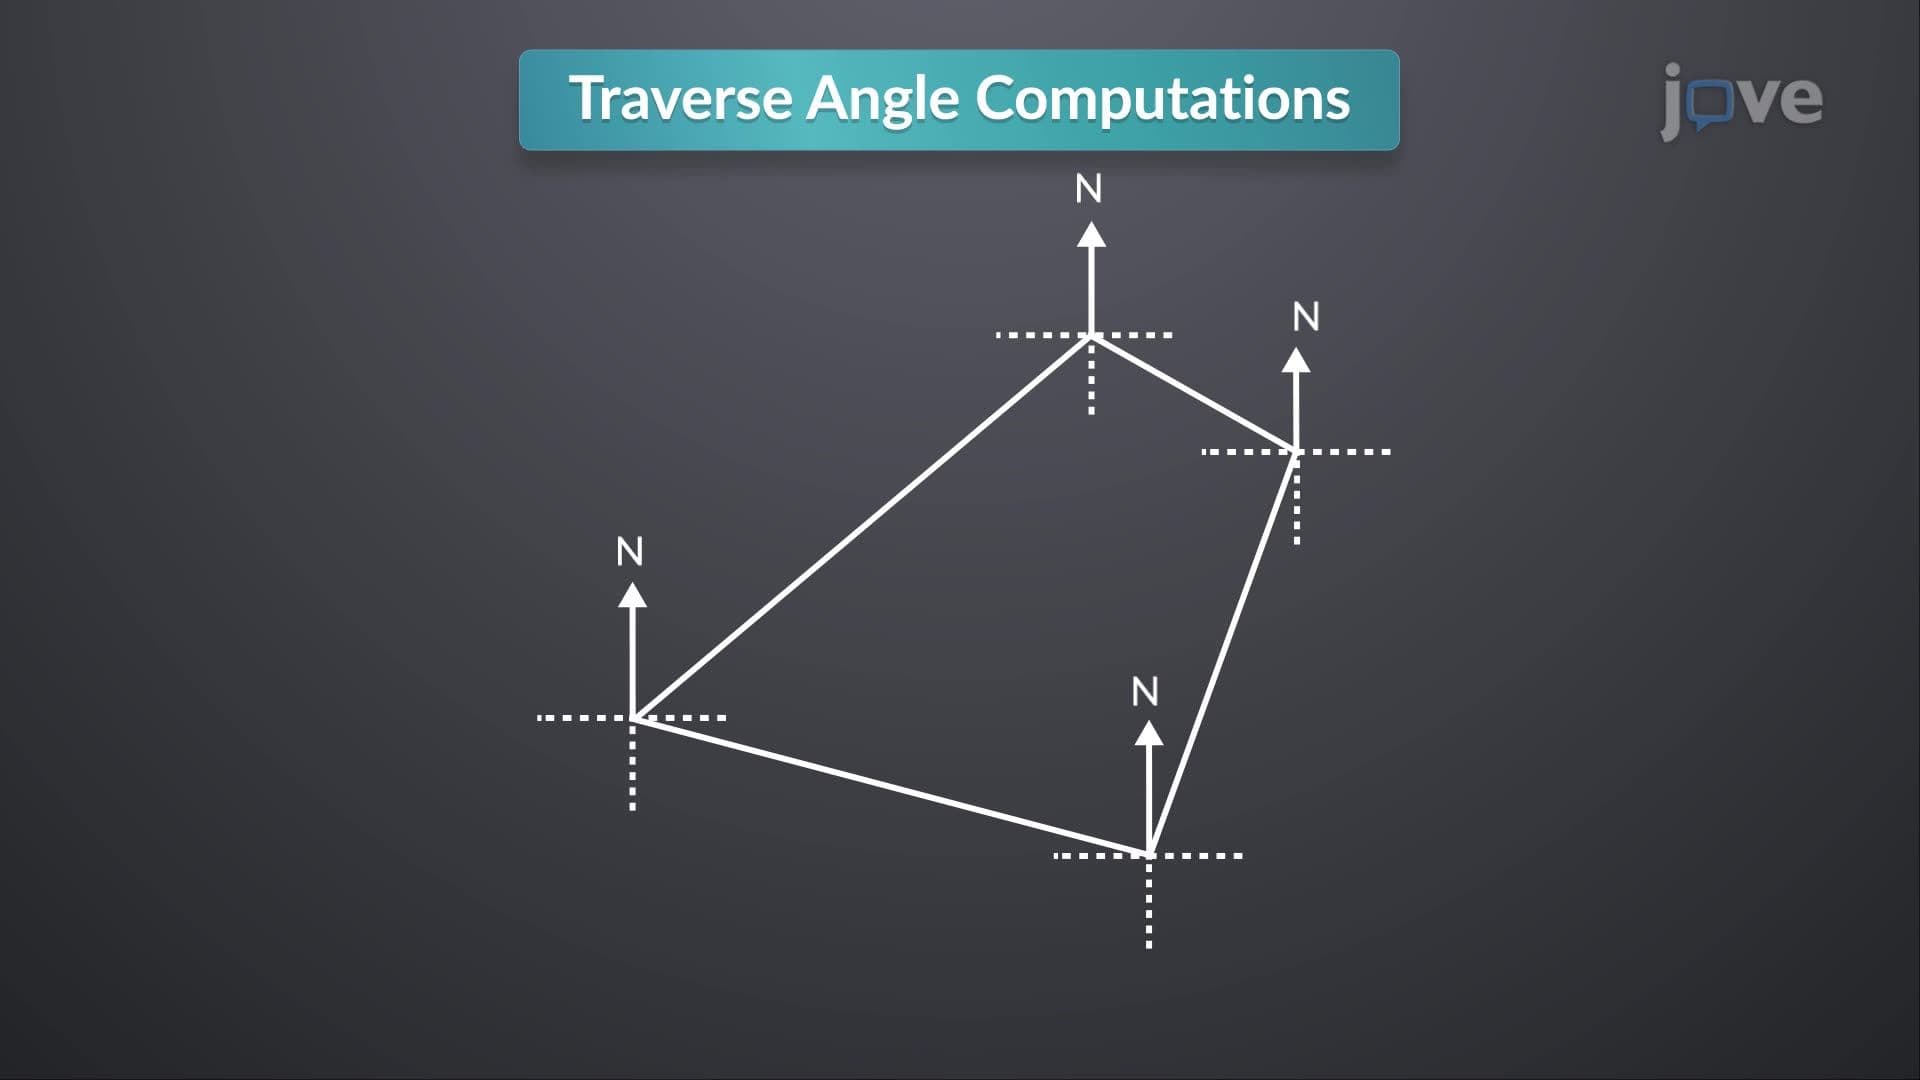
Design Example: Traverse Angle Computations
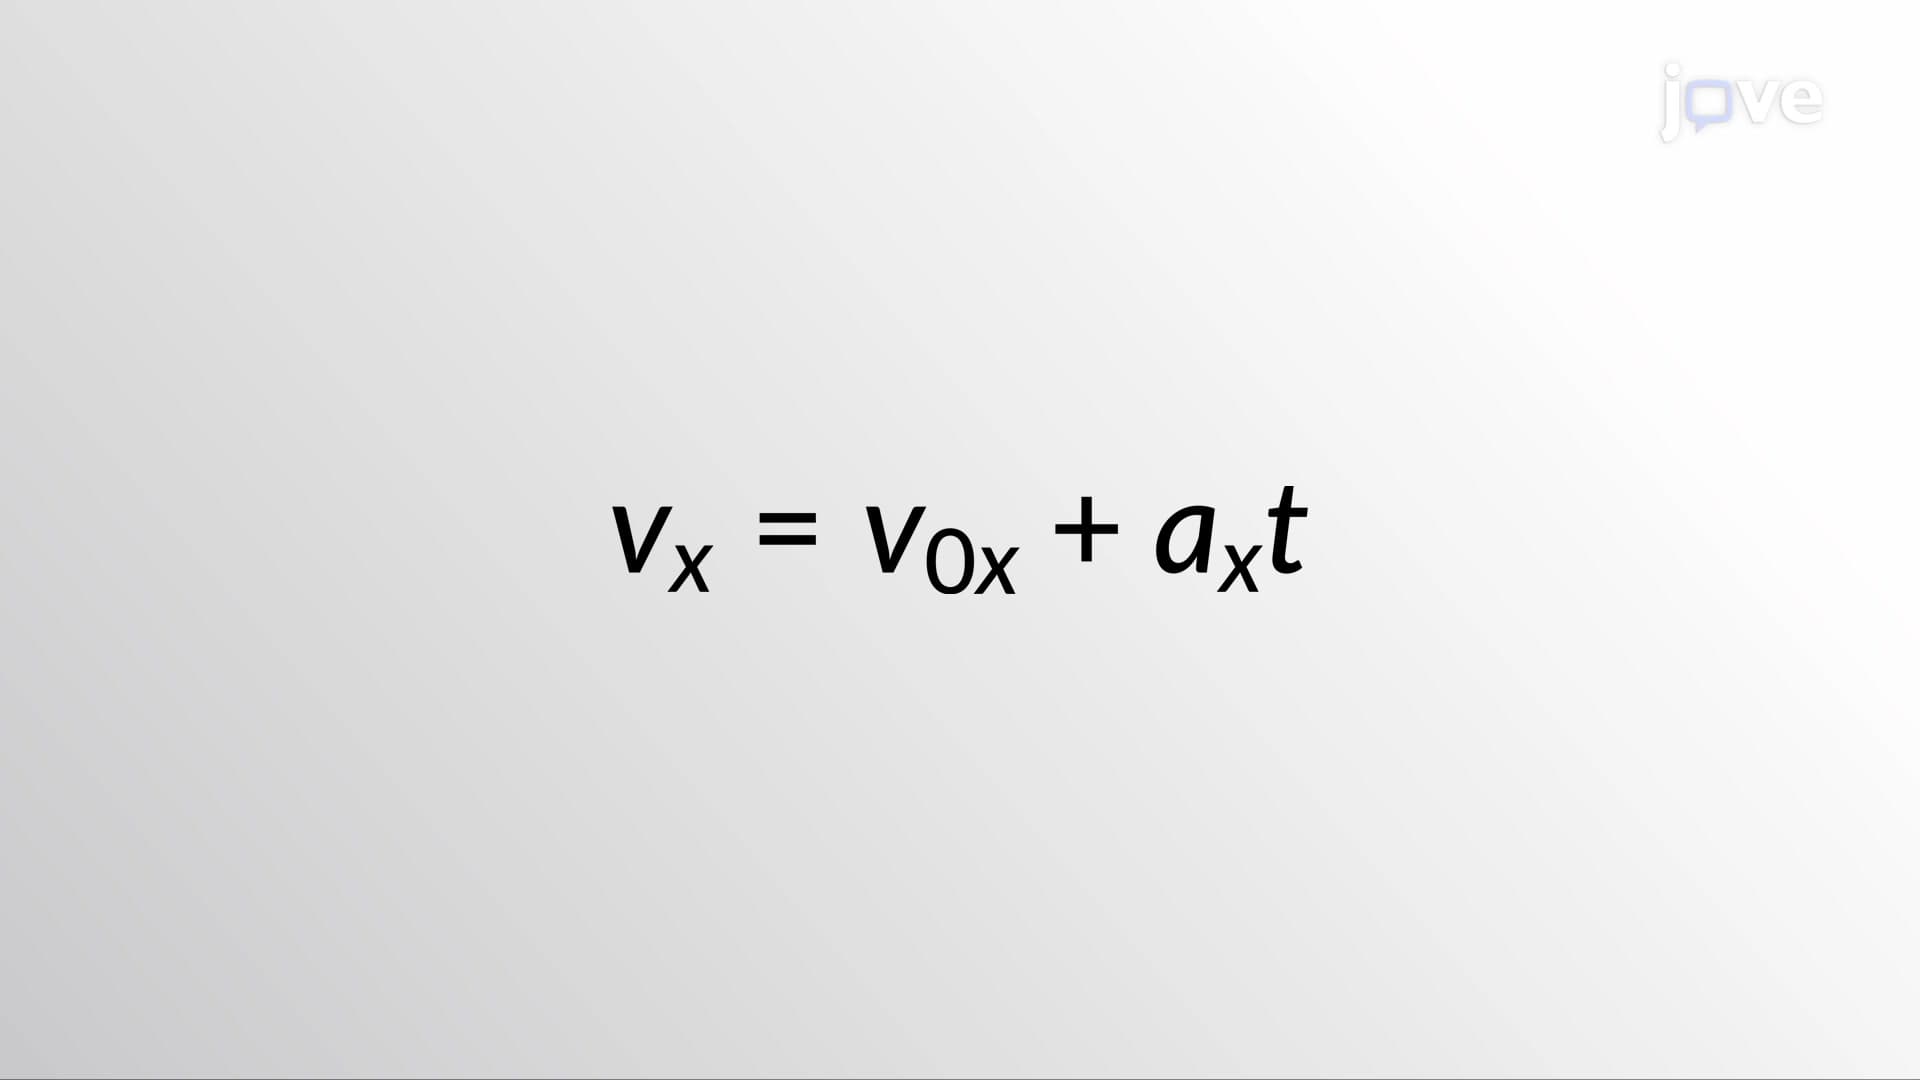 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 03:18
Nuclear Stability
To hold positively charged protons together...
 01:53
RNA Stability