Related Experiment Video
Updated: Feb 15, 2026

Stochastic Noise Application for the Assessment of Medial Vestibular Nucleus Neuron Sensitivity In Vitro
Published on: August 28, 2019
Adiabatic elimination of inertia of the stochastic microswimmer driven by α-stable noise
Joerg Noetel1, Igor M Sokolov1, Lutz Schimansky-Geier1,2
1Institute of Physics, Humboldt University at Berlin, Newtonstrasse 15, D-12489 Berlin, Germany.

Abstract:
We consider a microswimmer that moves in two dimensions at a constant speed and changes the direction of its motion due to a torque consisting of a constant and a fluctuating component. The latter will be modeled by a symmetric Lévy-stable (α-stable) noise. The purpose is to develop a kinetic approach to eliminate the angular component of the dynamics to find a coarse-grained description in the coordinate space. By defining the joint probability density function of the position and of the orientation of the particle through the Fokker-Planck equation, we derive transport equations for the position-dependent marginal density, the particle's mean velocity, and the velocity's variance. At time scales larger than the relaxation time of the torque τ_{ϕ}, the two higher moments follow the marginal density and can be adiabatically eliminated. As a result, a closed equation for the marginal density follows. This equation, which gives a coarse-grained description of the microswimmer's positions at time scales t≫τ_{ϕ}, is a diffusion equation with a constant diffusion coefficient depending on the properties of the noise. Hence, the long-time dynamics of a microswimmer can be described as a normal, diffusive, Brownian motion with Gaussian increments.
Related Concept Videos
 01:20
Work Done in an Adiabatic Process
 01:14
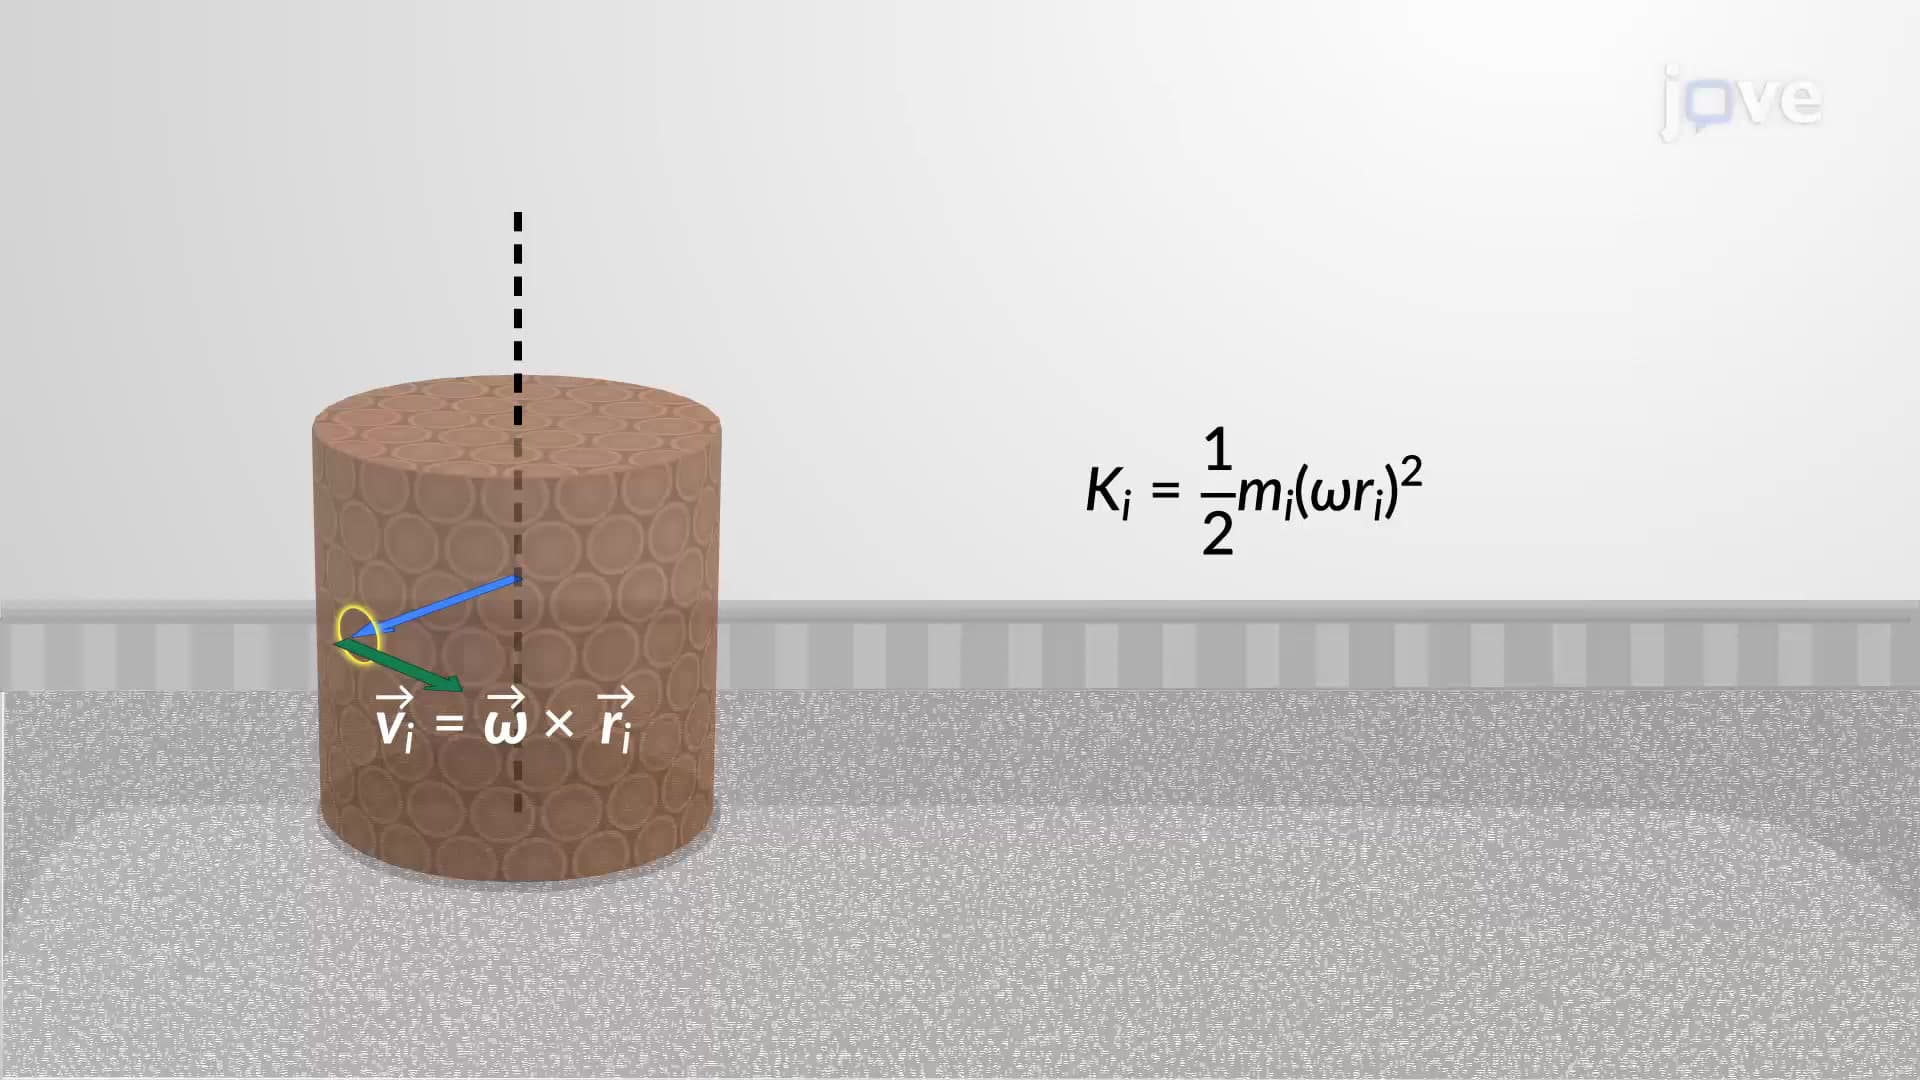
Moment of Inertia
If a rigid body is rotating about an axis but is not in translational motion, its translational kinetic energy is zero. However, since each particle undergoes rotational motion, it possesses non-zero velocity and kinetic energy. Thus, the kinetic energy of the rigid body, which is the sum of the...
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:17
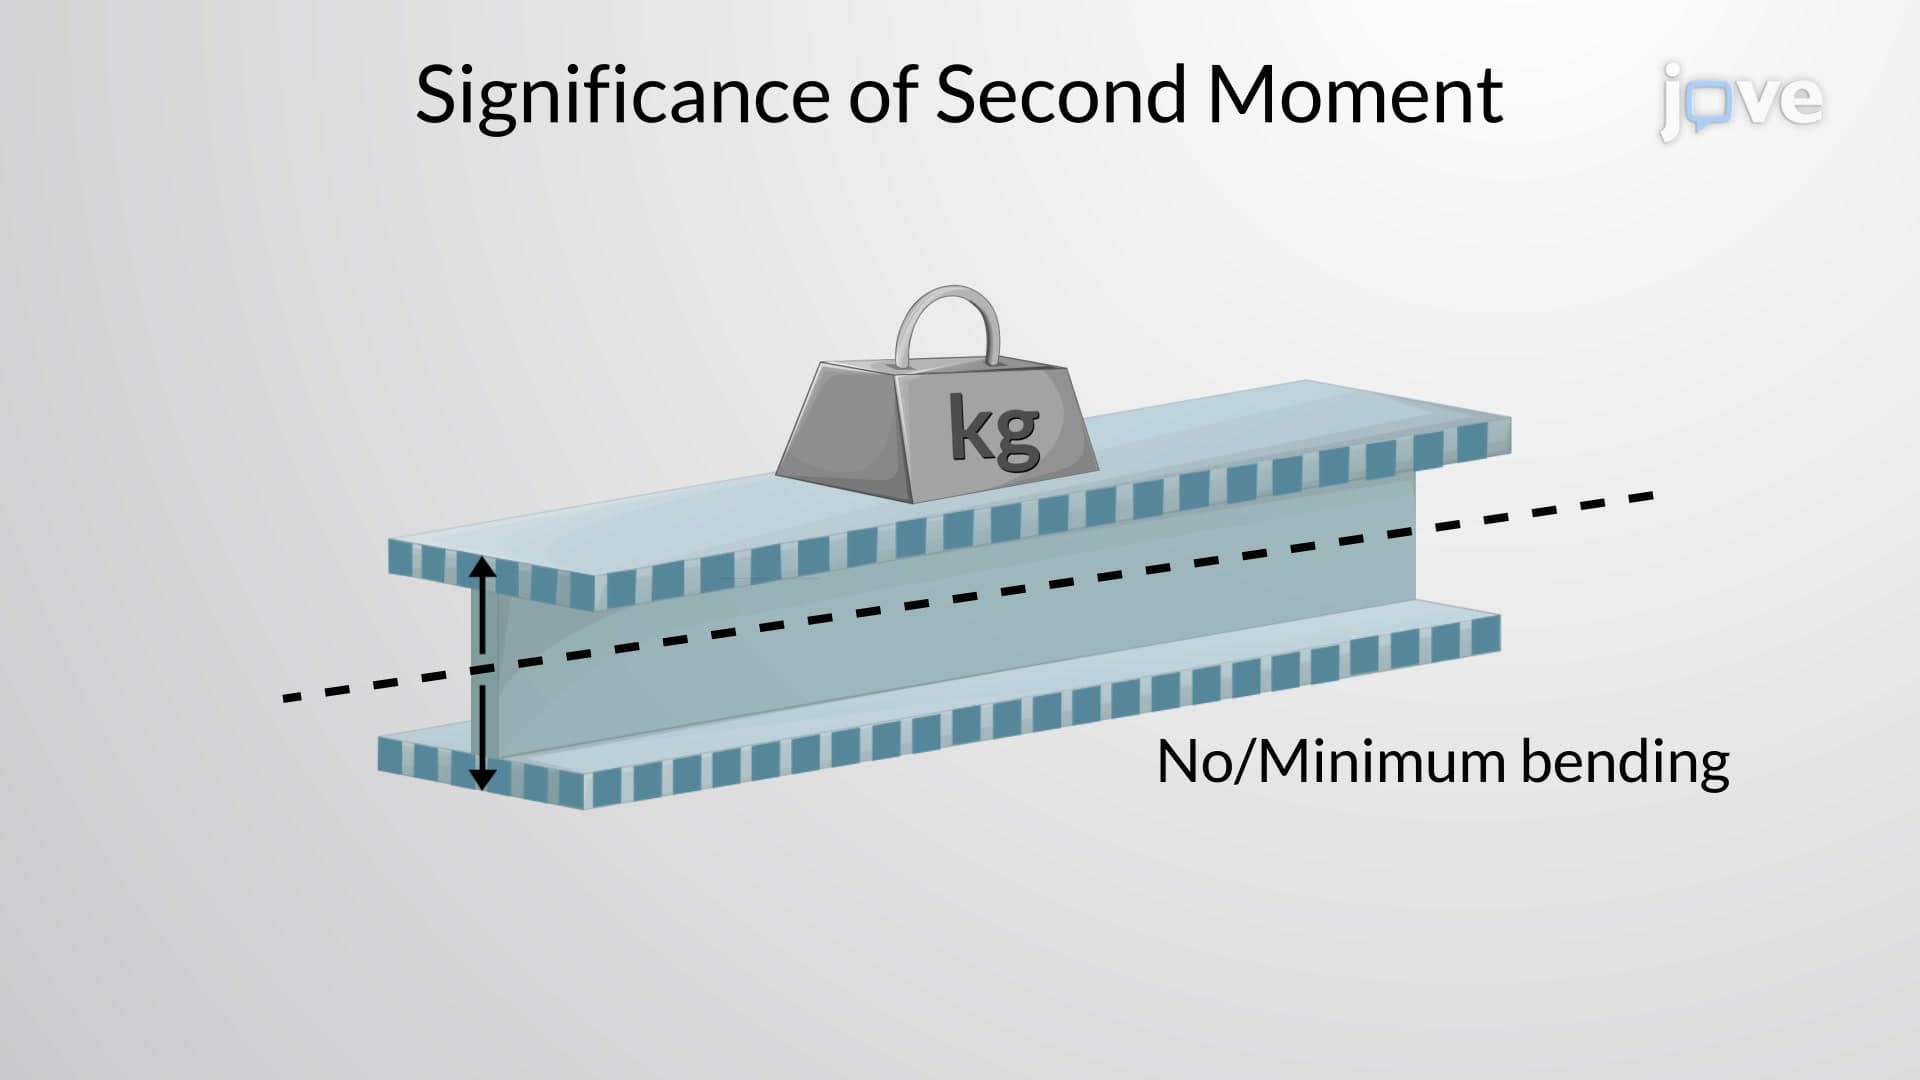
Moments of Inertia for Areas
 01:13
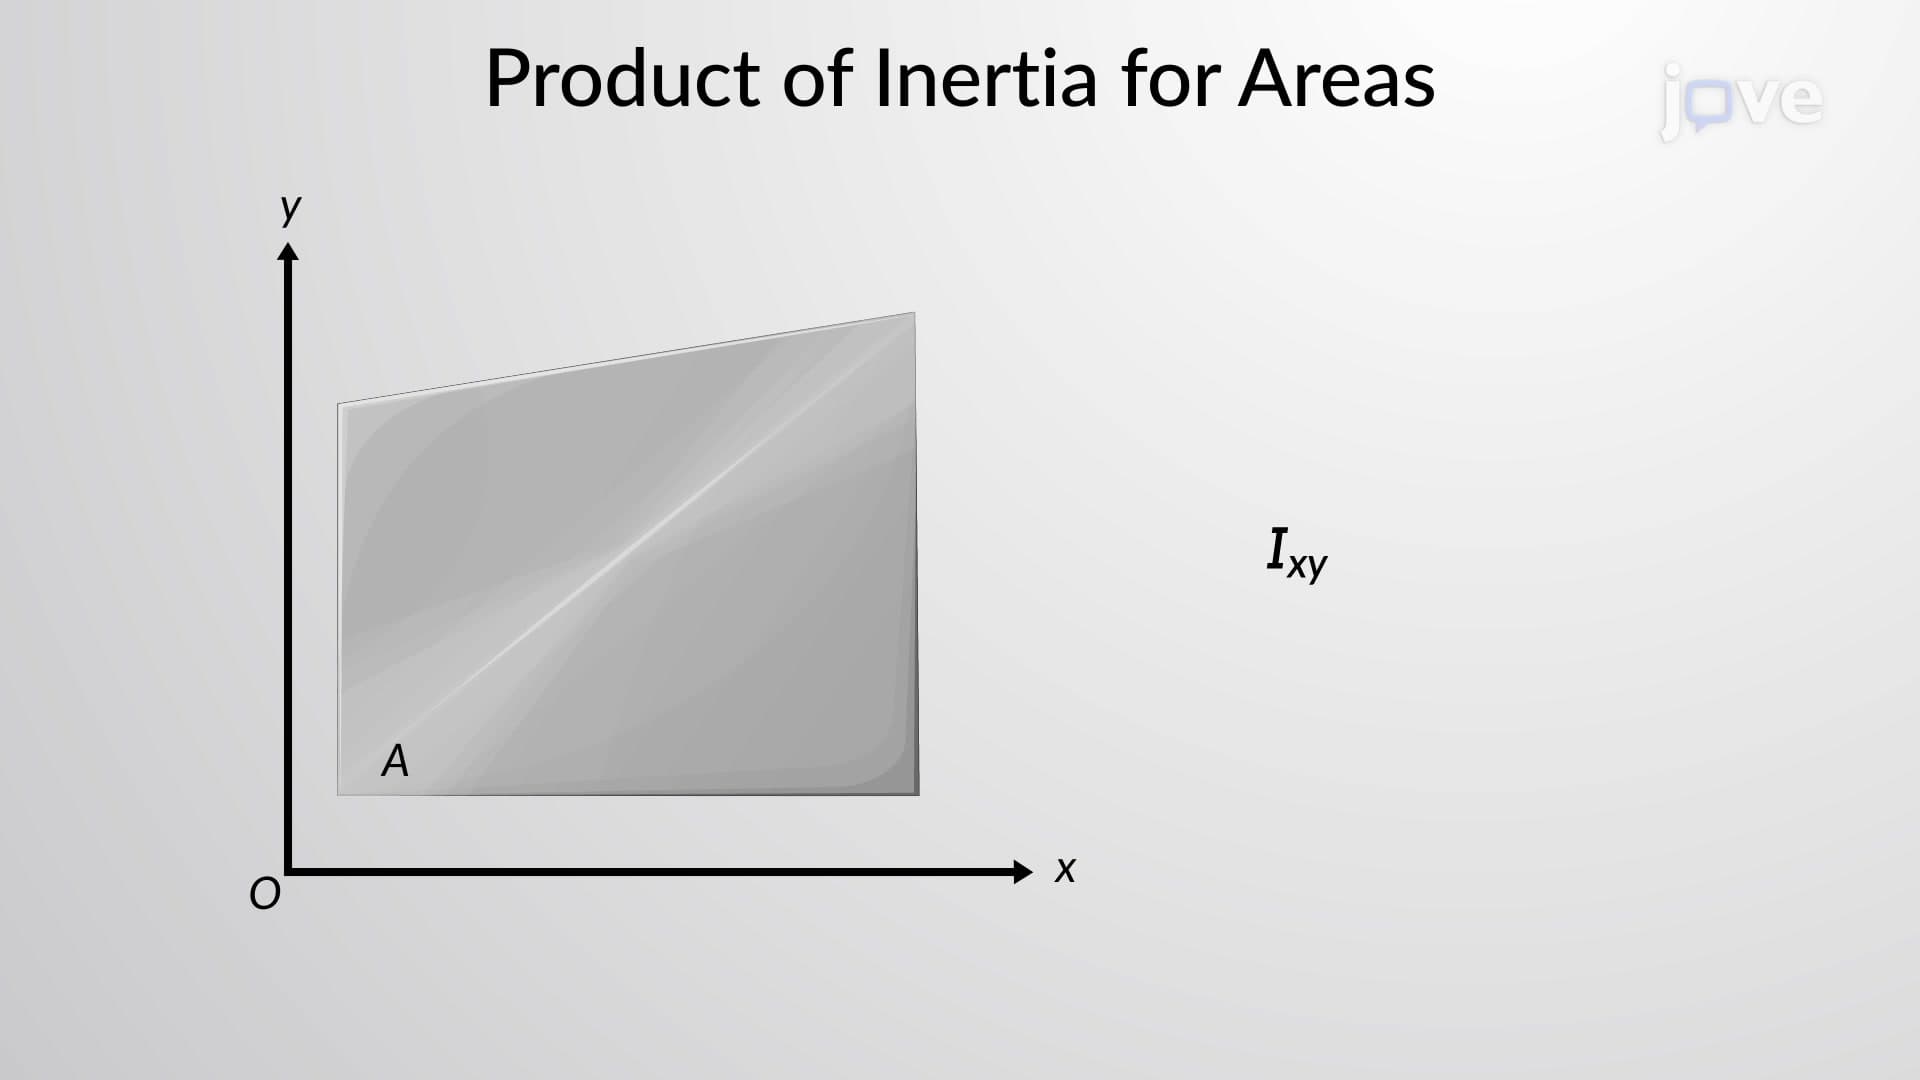
Product of Inertia for an Area
To calculate the product of inertia for any...
 01:18
Adiabatic Processes for an Ideal Gas