Related Experiment Video
Updated: Feb 15, 2026
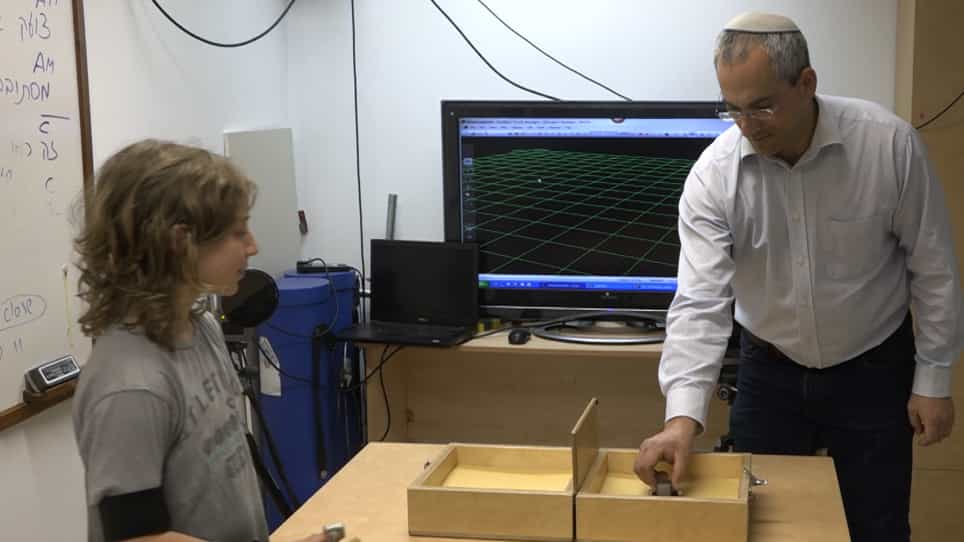

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
A Novel Inverse Solution of Contact Force Based on a Sparse Tactile Sensor Array
Weiting Liu1, Chunxin Gu2, Ruimin Zeng3
1The State Key Laboratory of Fluid Power & Mechatronic Systems, Department of Mechanical Engineering, Zhejiang University, Hangzhou 310027, Zhejiang, China. liuwt@zju.edu.cn.

Abstract:
High-density tactile sensing has been pursued for humanoid robotic hands to obtain contact force information while the elastomer skin cover is traditionally considered to impair the force discrimination. In this work, we try to utilize the diffusion effect of the elastomer cover to identify an arbitrary contact force load just based on a sparse tactile sensor array. By numerical analysis, we proved the monotonous relation between the Pearson's correlation coefficient and the relative distance of two single-force loads. Then, we meshed the elastomer surface and conducted the calibration load process to establish the calibration database of the sensing outputs. Afterwards, we applied the correlation method to the database and the sensing output of the unknown load to determine its location and intensity. For validation tests of the proposed method, we designed and fabricated a 3 × 3 sparse tactile sensor array with flat elastomer cover and established an automatic three-axis loading system. The validation tests were implemented including 100 random points with force intensity ranging from 0.1 to 1 N. The test results show that the method has good accuracy of detecting force load with the mean location error of 0.46 mm and the mean intensity error of 0.043 N, which meets the basic requirements of tactile sensing. Therefore, it is feasible for the sparse tactile sensor array to realize high-density load detection.
Related Concept Videos
 02:28
Intermolecular Forces in Solutions
When the strengths of the intermolecular forces of attraction between solute and solvent species in a solution are no different than those present in the separated components, the solution is formed with no accompanying energy change. Such a solution is called an ideal solution. A mixture of ideal gases (or gases such as helium and argon,...
 03:21
Weak Base Solutions
 03:22
Strong Acid and Base Solutions
 01:17
Transmission-based Precautions I: Contact, Enteric, and Droplets
Contact Precautions:
Contact precautions are the measures taken to prevent the transmission of infectious agents, especially epidemiologically important microorganisms such as MRSA or influenza, primarily transmitted through direct or indirect contact with an...
 01:27
Tactile and Chemical Senses
 02:11
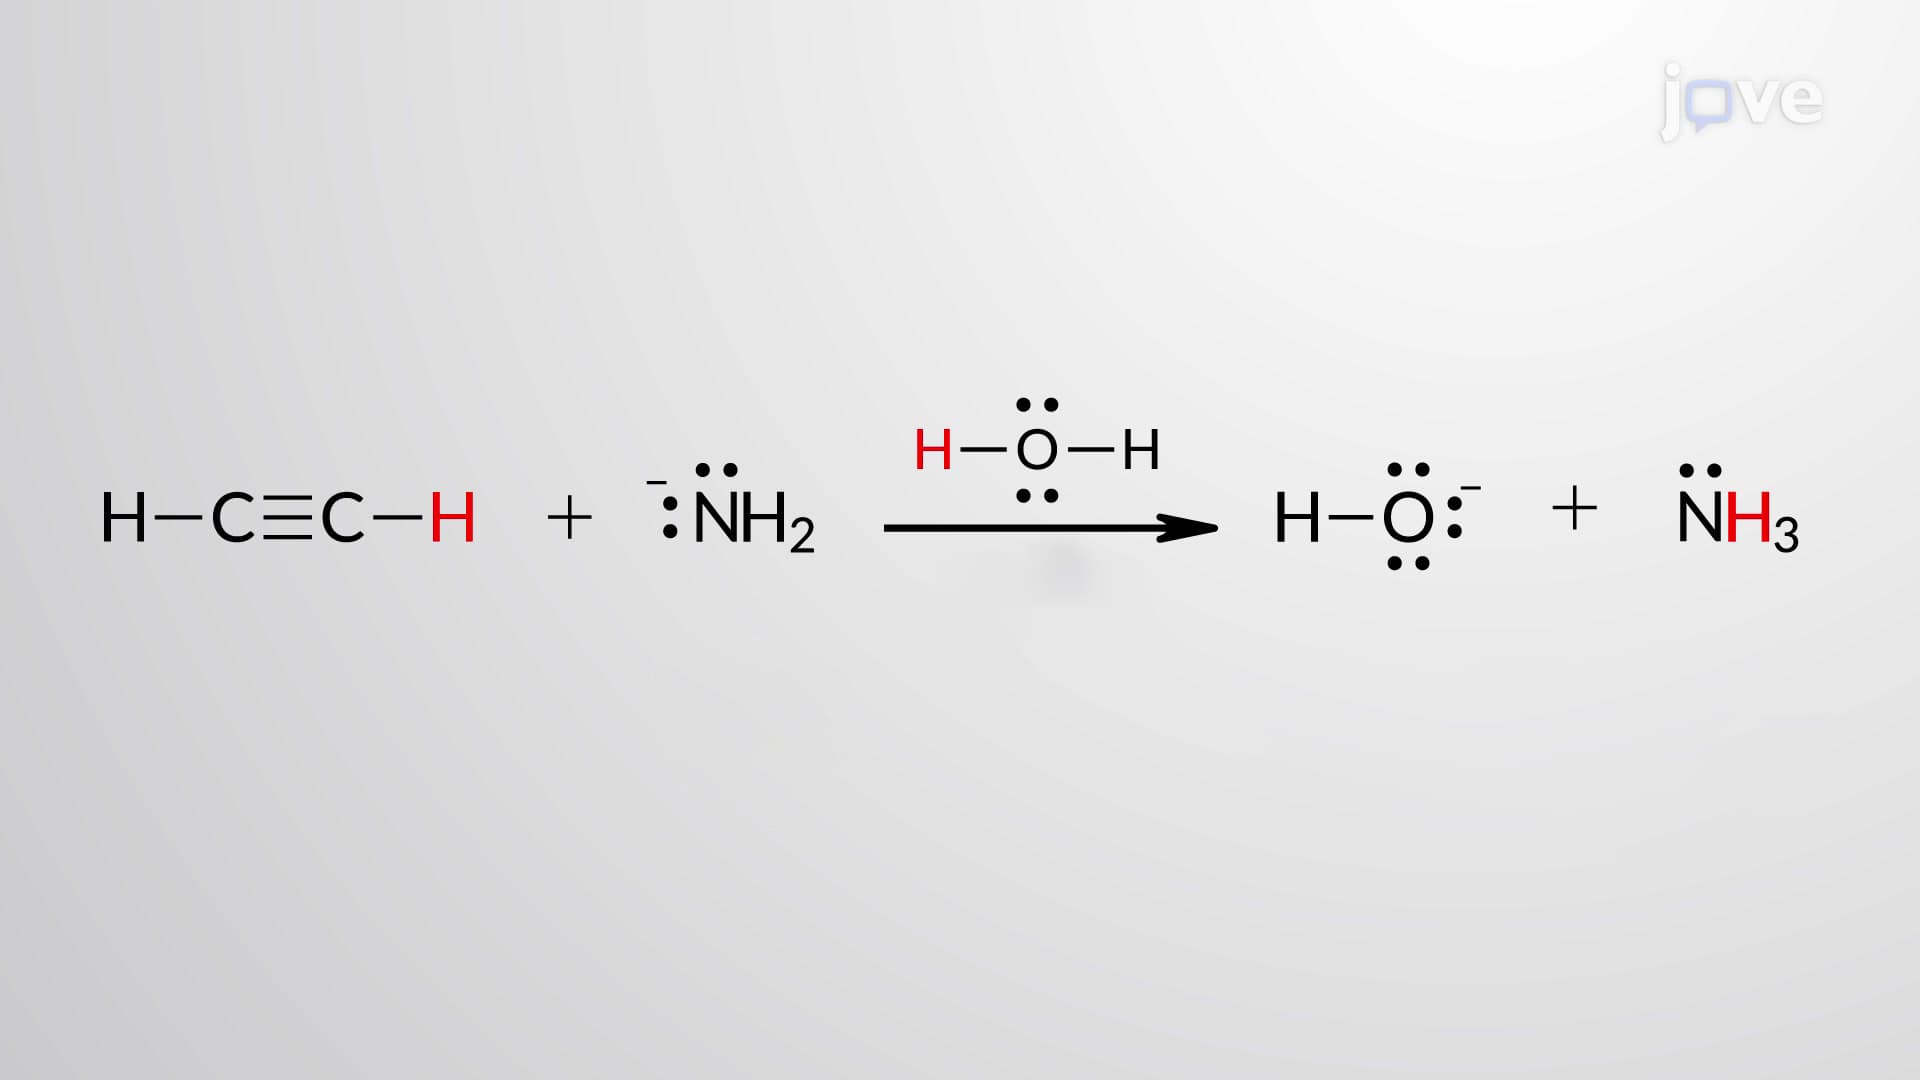
Leveling Effect and Non-Aqueous Acid-Base Solutions
The Leveling Effect of a Solvent
A generic acid (HA) reacts with the generic base (B-) to yield the corresponding conjugate base (A-) and conjugate acid (HB):