Related Experiment Video
Updated: Feb 15, 2026
Treatment of Osteochondral Defects in the Rabbit's Knee Joint by Implantation of Allogeneic Mesenchymal Stem Cells in Fibrin Clots
Published on: May 21, 2013
Midterm Results of a New Rotating Hinge Knee Implant: A 5-Year Follow-Up
Christoph Böhler1, Paul Kolbitsch1, Reinhard Schuh1
1Department of Orthopaedic Surgery, Medical University of Vienna, Waehringer Guertel 18-20, 1090 Vienna, Austria.

Background:
In the current study, we investigated midterm results of a new rotating hinge total knee arthroplasty (EnduRo prosthesis), which uses a new bearing material (CFR PEEK).
Methods:
We prospectively analysed data of 50 patients with a minimum follow-up of 5 years. In 24 (48%) patients, a primary implantation was performed and 26 (52%) were revision cases. Clinical and radiographic examinations were performed preoperatively as well as postoperatively after 3 and 12 months and annually thereafter. The Knee Society Score (KSS), WOMAC, Oxford Knee Score (OKS), and range of motion (ROM) were used for clinical assessment.
Results:
KSS, WOMAC, OKS, and ROM significantly improved between the preoperative and the follow-up investigations. The overall survival rate with revision for any reason as an endpoint was 77.9% after five years. The number of complications was significantly higher in the revision group (p = 0.003).
Conclusion:
The EnduRo prosthesis provides highly satisfying clinical and functional results in severe primary as well as in revision cases. Implant-associated complications were rare. However, in cases of revision surgery, the risk for complications was considerably high, mostly related to previous joint infections and poor soft tissue quality.
Related Concept Videos
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:04
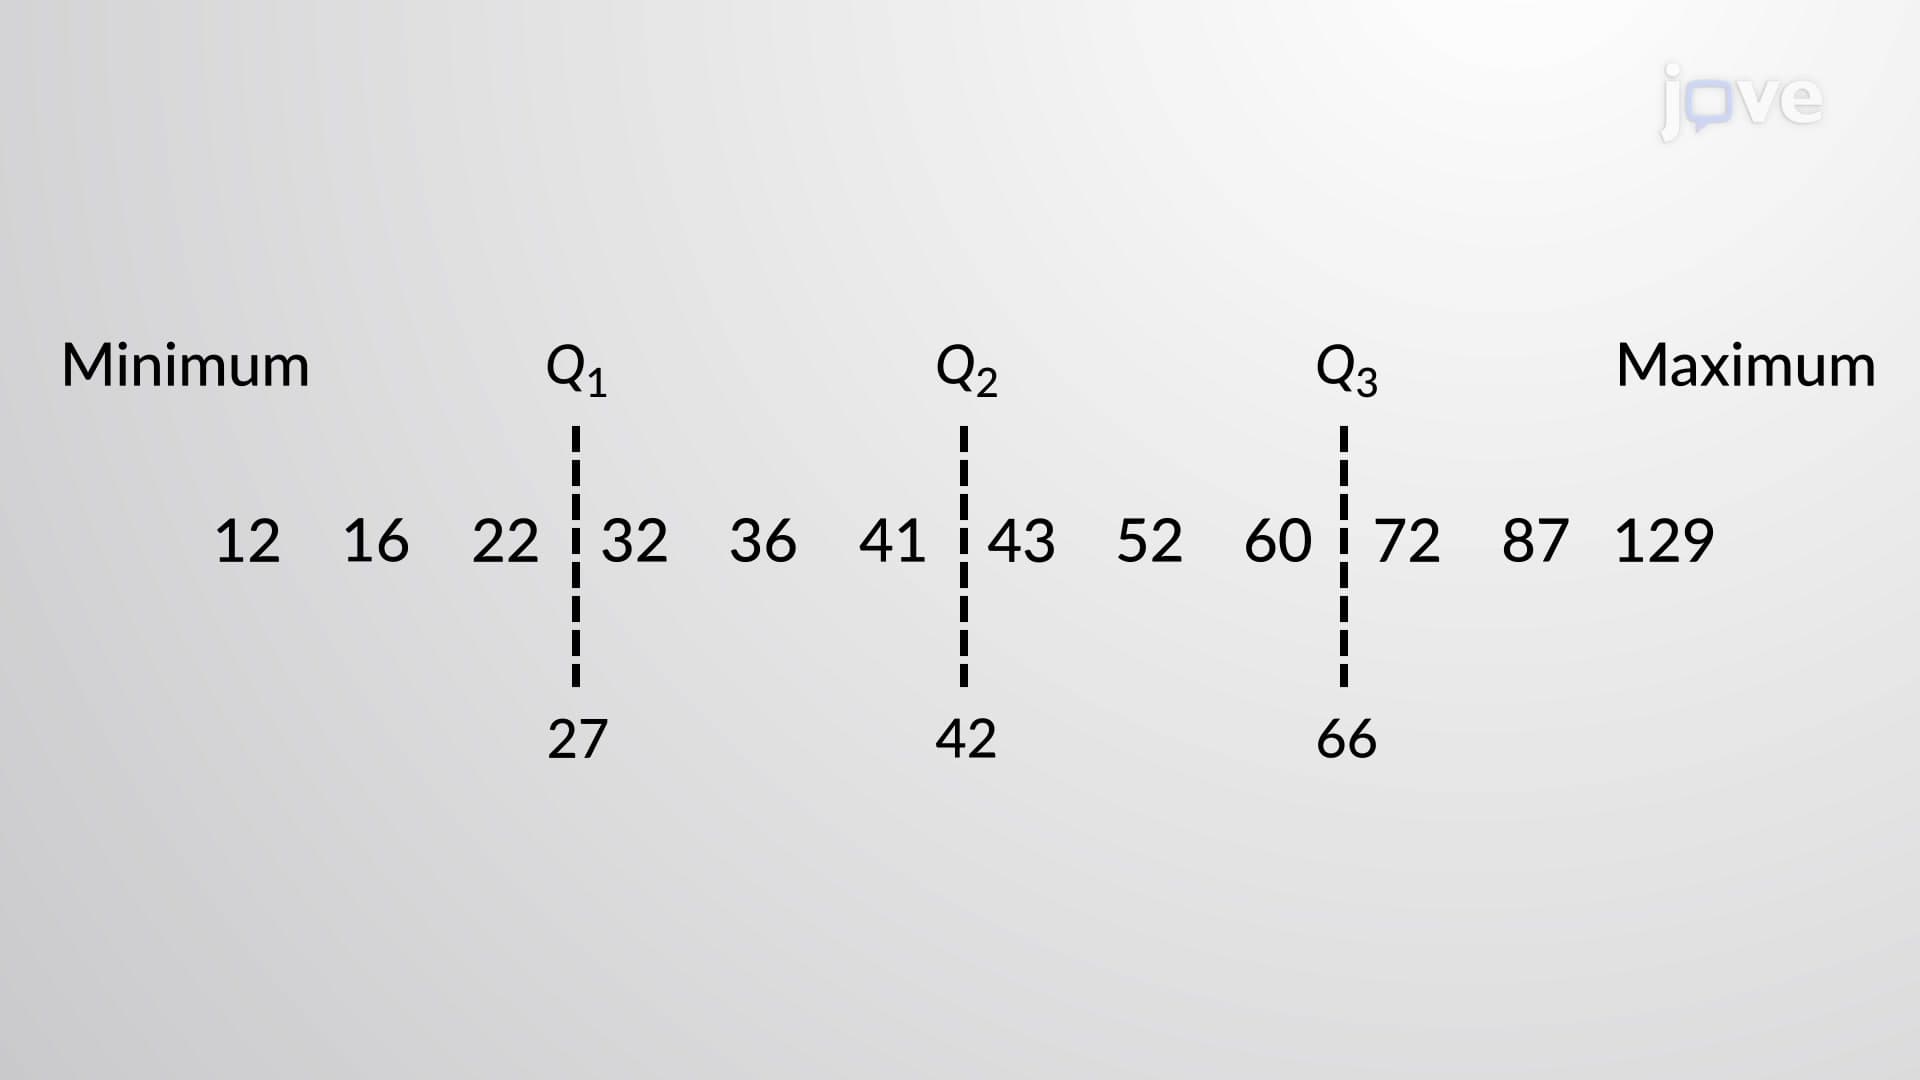
5-Number Summary
In a box plot, the minimum and maximum data values represent the lower and upper whiskers in the graph, and the median is designated as the center of the box in the chart. The first quartile and third...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:11
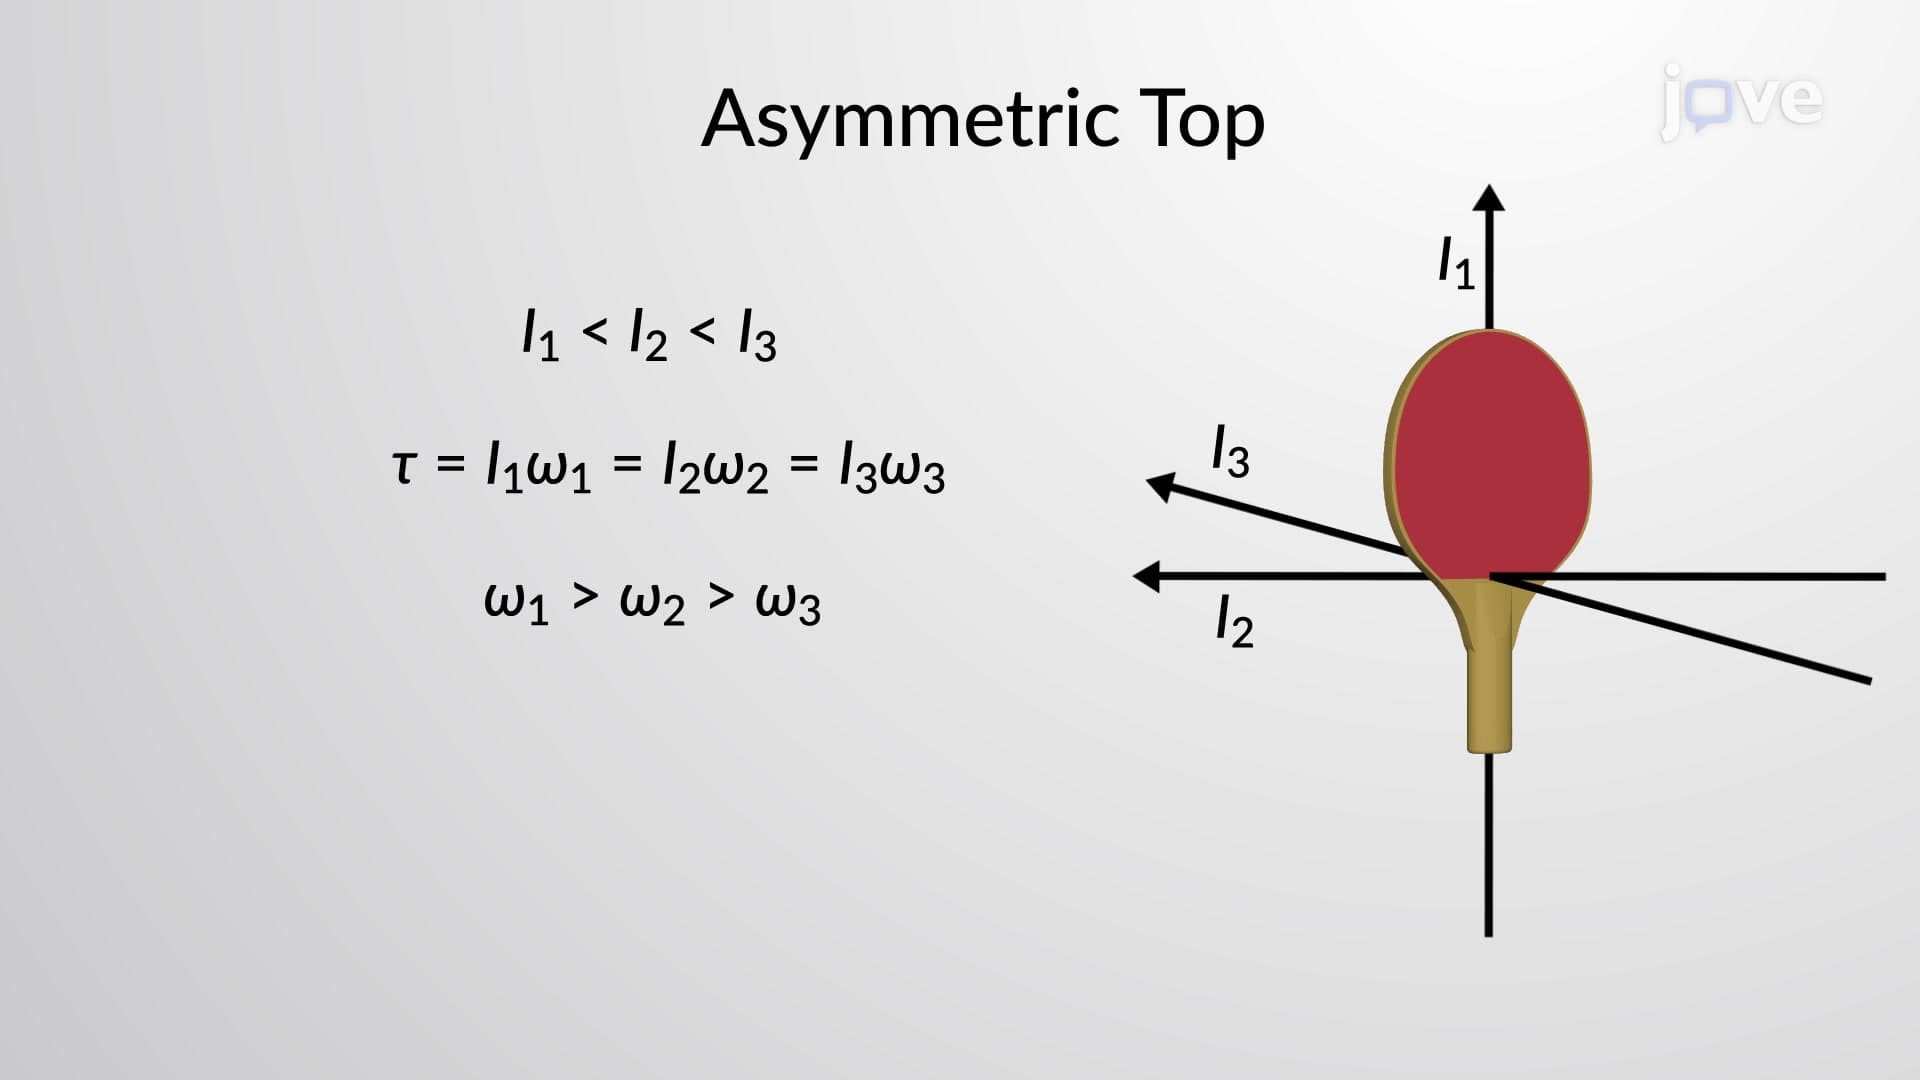
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:37
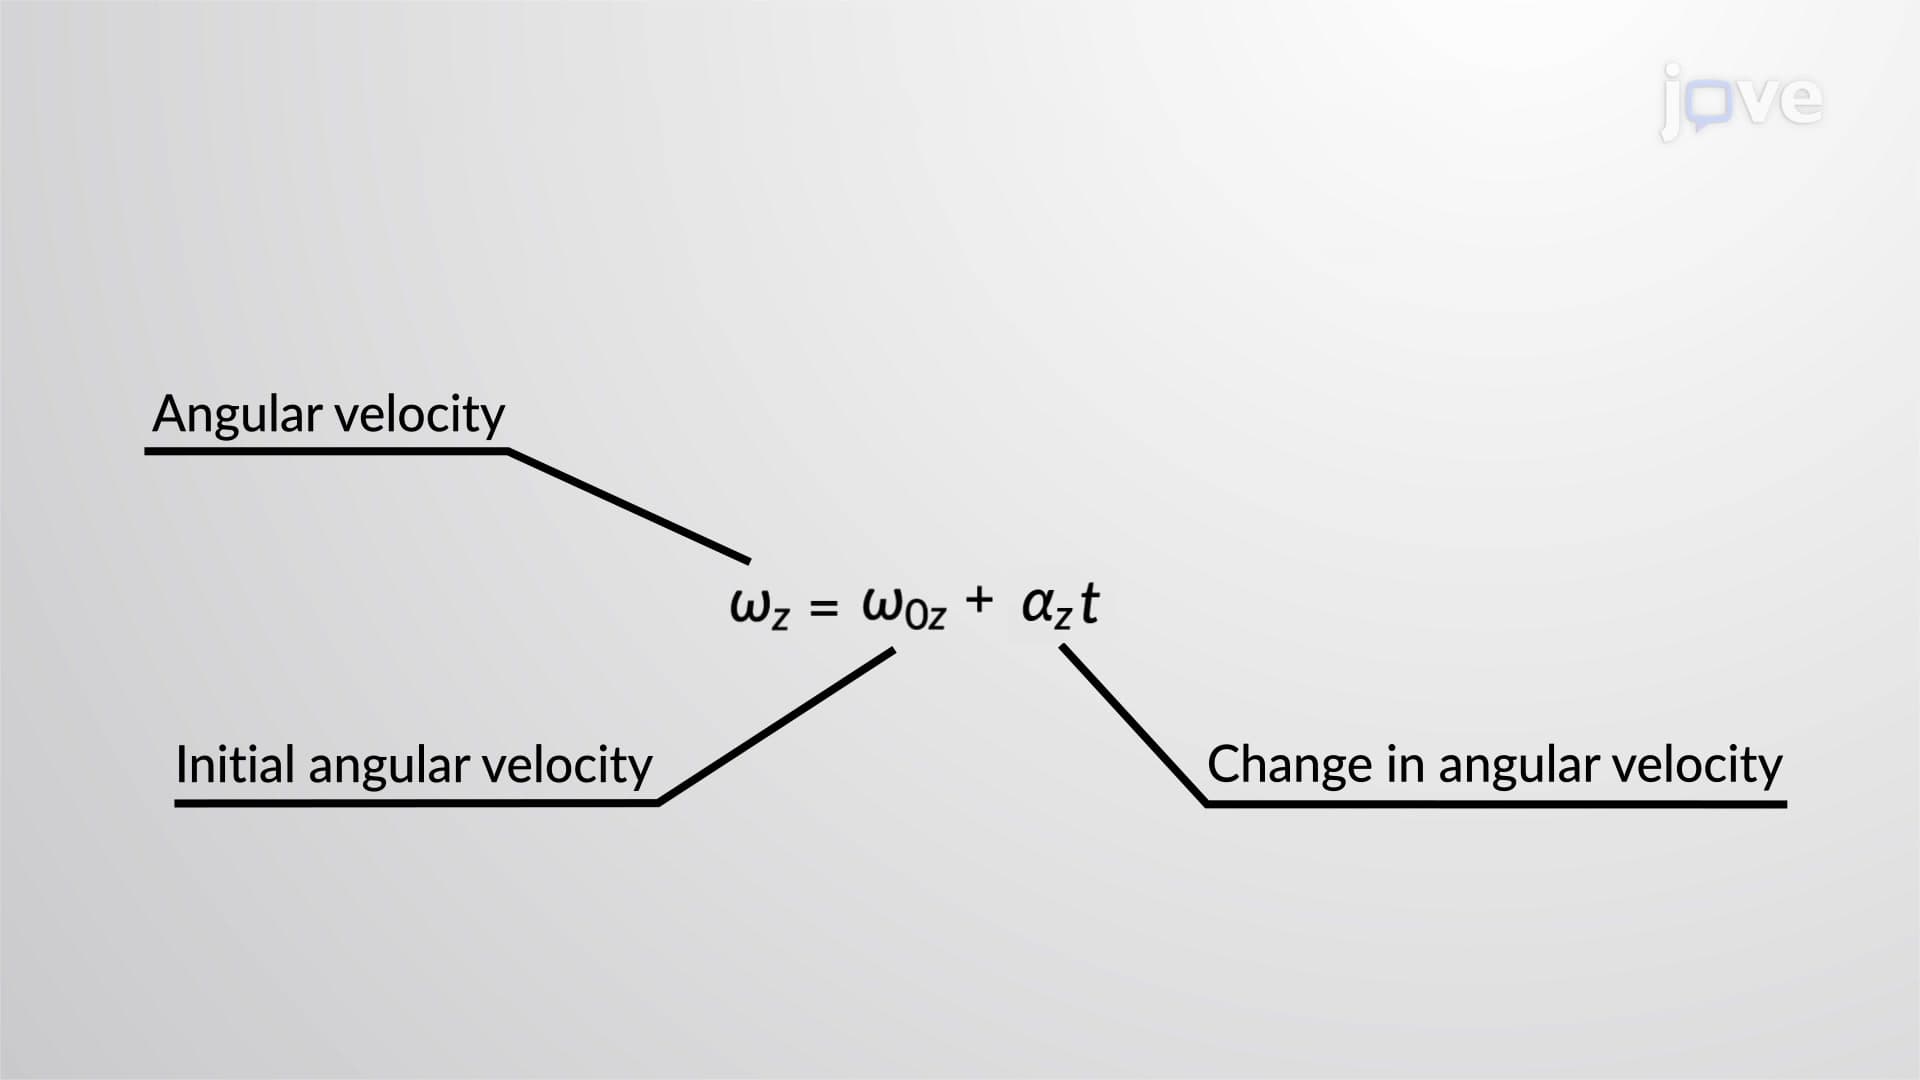
Rotation with Constant Angular Acceleration - I
Using our intuition, we can begin to see how rotational quantities such as angular displacement, angular velocity, angular acceleration, and time are related to one another. For example, if a flywheel...
 01:16
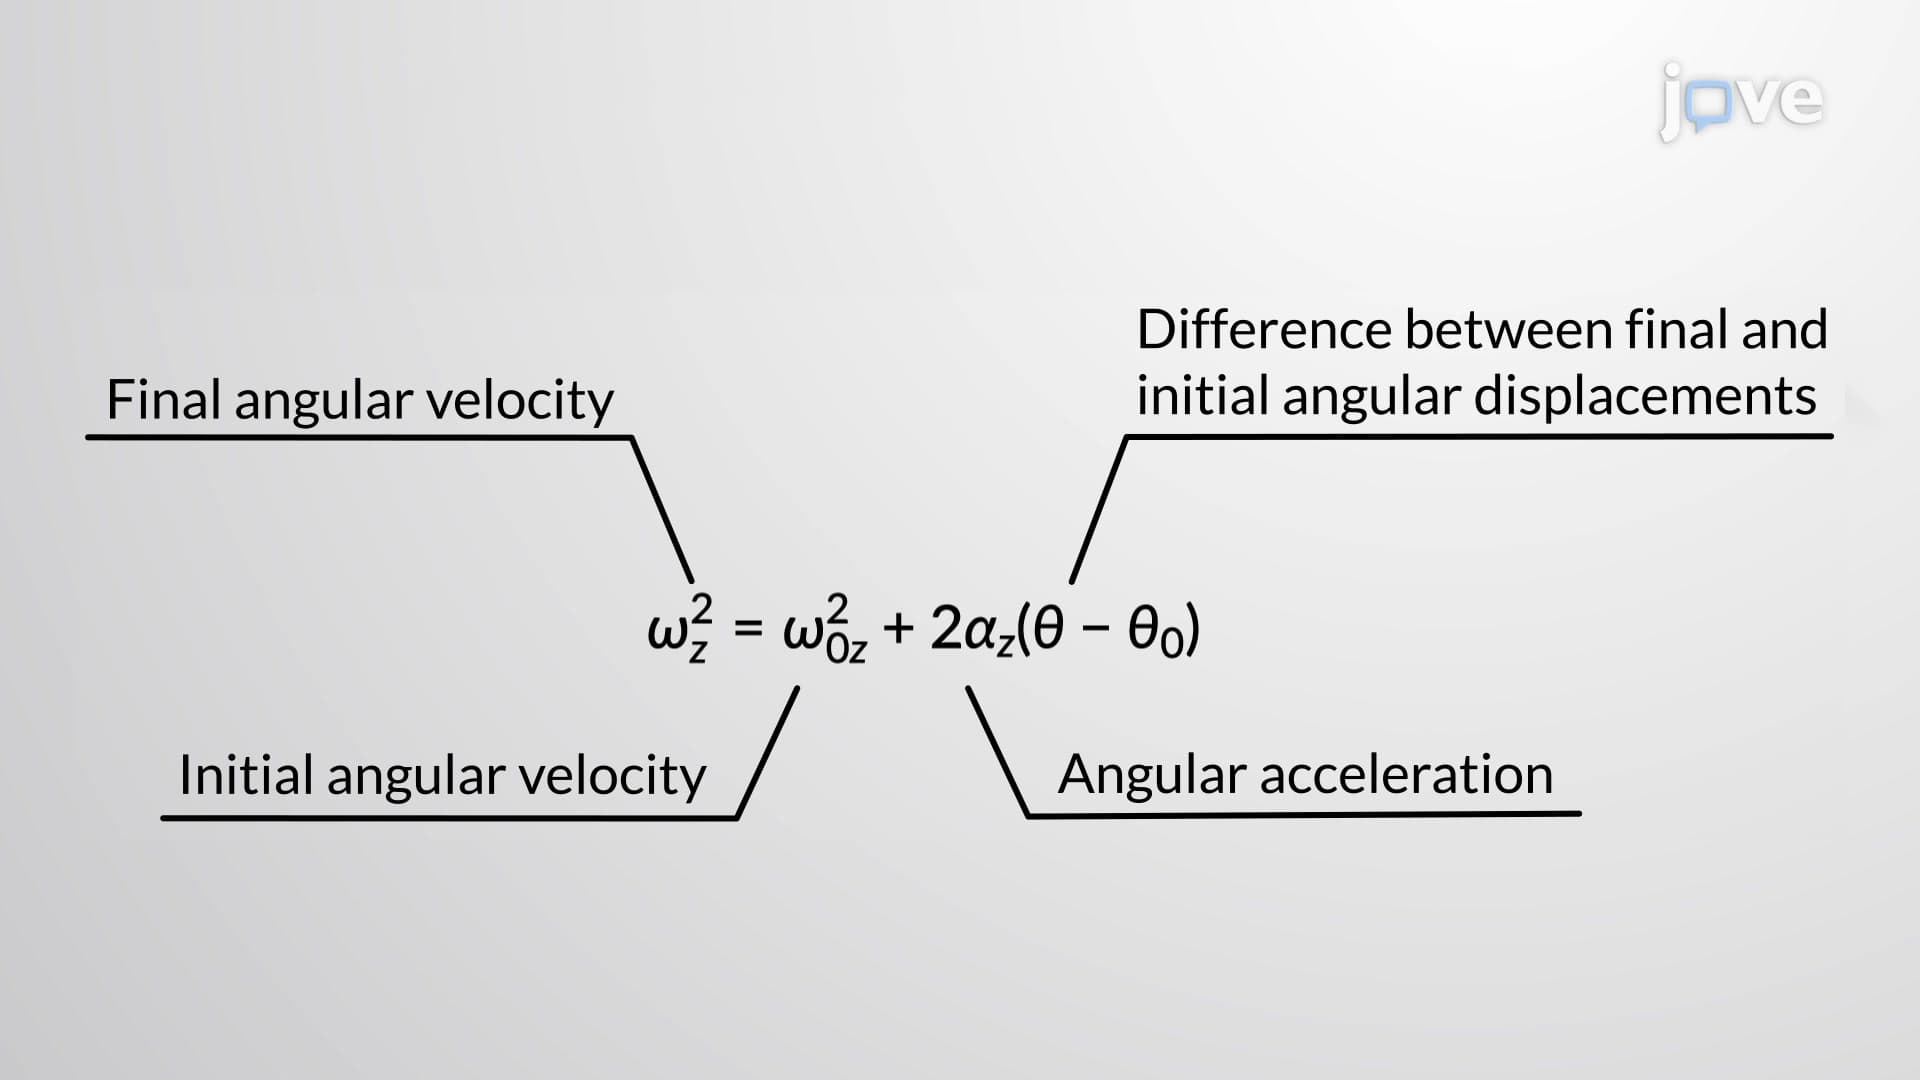
Rotation with Constant Angular Acceleration - II
The first...