A simple tuning method of fractional order PIλ-PDμ controllers for time delay systems
Related Experiment Video
Updated: Feb 15, 2026
A Simple Fractionated Extraction Method for the Comprehensive Analysis of Metabolites, Lipids, and Proteins from a Single Sample
Published on: June 1, 2017
1Dicle University, Department of Electrical and Electronics Engineering, 21280- Diyarbakir, Turkey.

Abstract:
In this paper, a practical tuning technique is presented to obtain all stabilizing fractional order PIλ-PDμ controller parameters ensuring stability for processes with time delay using the stability boundary locus and the weighted geometrical center (WGC) methods. The method is based on obtaining of stability regions plotted by using the stability boundary locus in the (kd,kf)-plane and (kp,ki)-plane, and then computing the weighted geometrical centers of these regions. After obtaining PDμ controller parameters using the WGC method from the stability region, desired PIλ controller parameters are computed by the same procedure. This paper provides a simple and efficient tuning method to obtain stabilizing parameters of PIλ-PDμ controller for time delay systems. The important advantages of the method are both calculating of controller parameters without using any complex solution methods and ensuring the stability of closed loop system. Illustrative examples are given to demonstrate the benefits and the simplicity of the proposed method.
Related Concept Videos
 01:11
Oral Drug Delivery Systems: Delayed-Release Systems
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
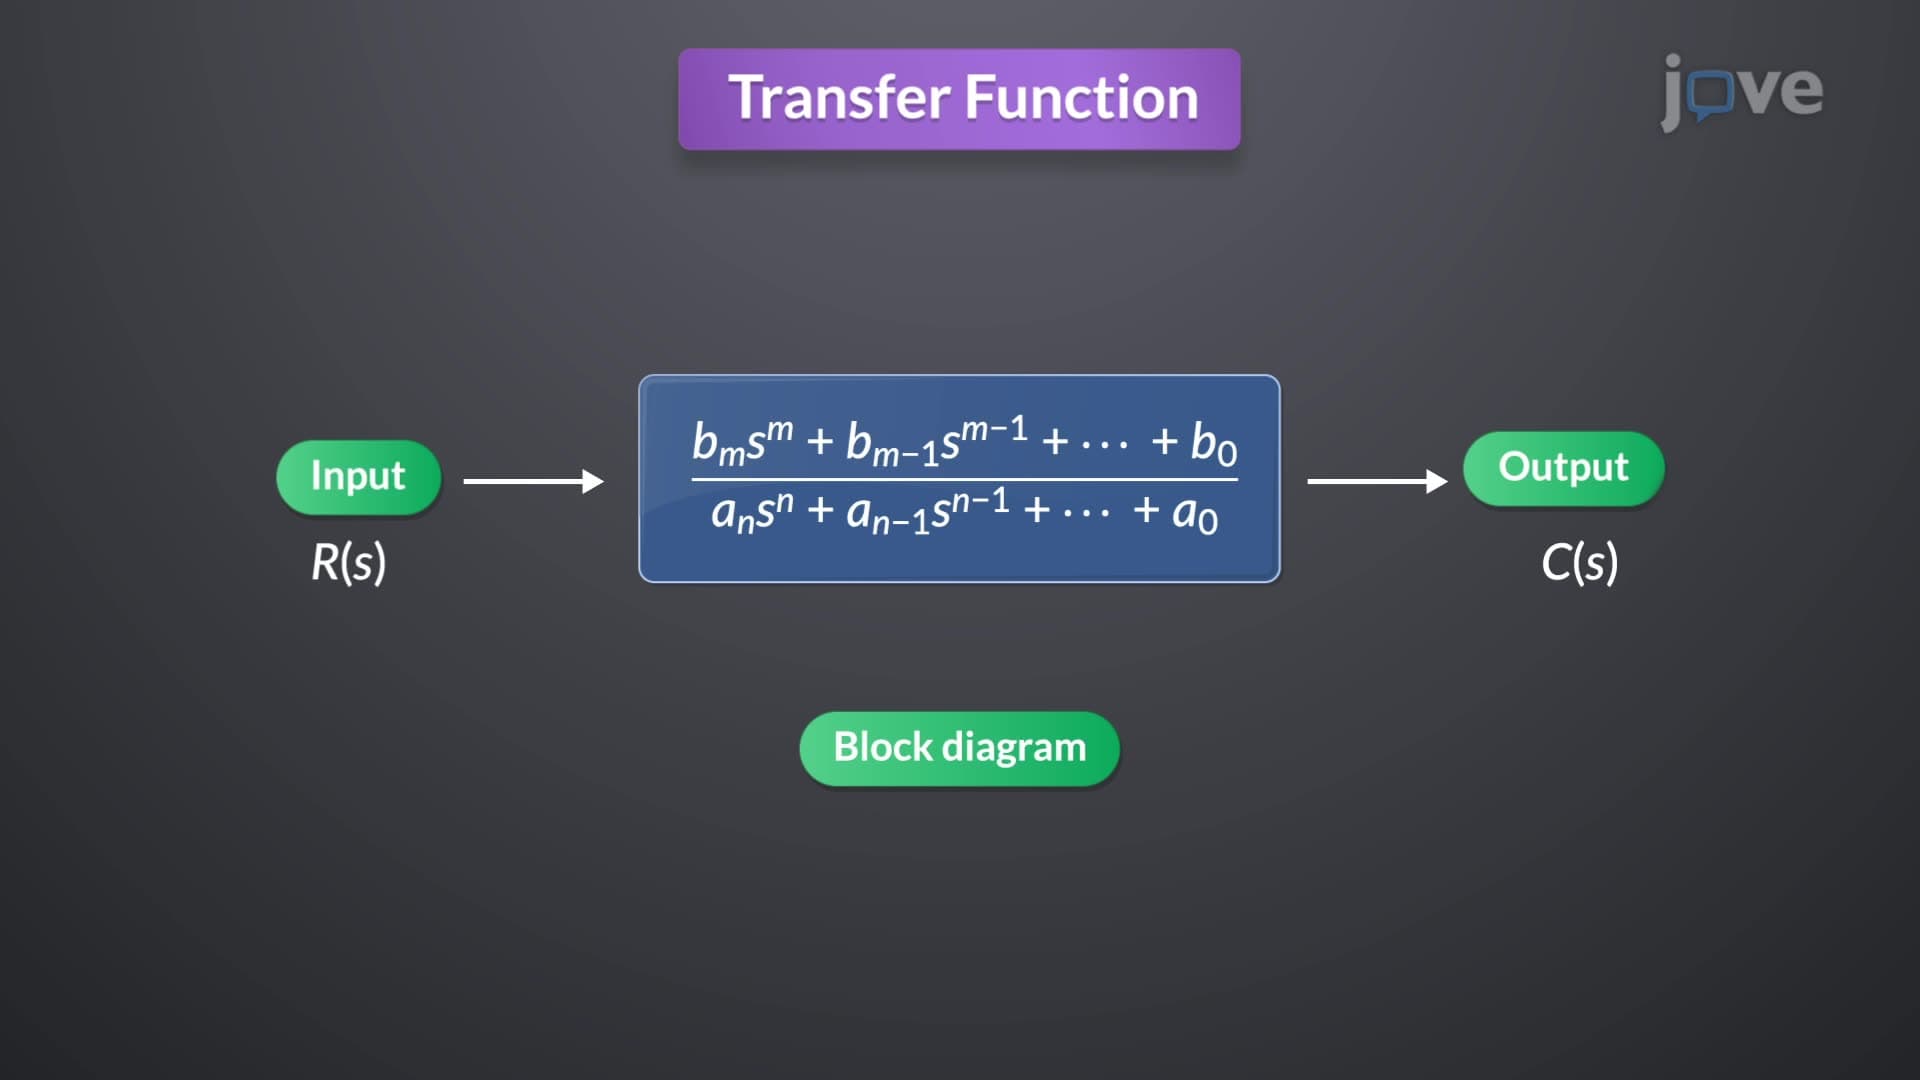
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...