Design-validation of a hand exoskeleton using musculoskeletal modeling
Related Experiment Video
Updated: Feb 14, 2026
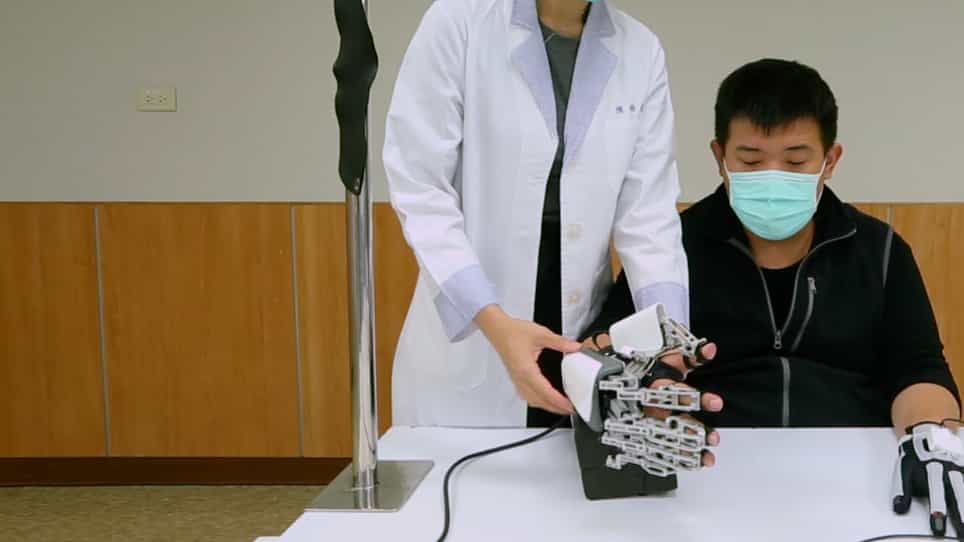
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Clint Hansen1, Florian Gosselin2, Khalil Ben Mansour3
1Sorbonne Universités, Université de Technologie de Compiègne, UMR CNRS 7338, Biomécanique et Bioingénierie, Centre de Recherche Royallieu, F-60203, Compiègne, France; Christian-Albrechts University of Kiel, Department of Neurology, 24105 Kiel, Germany.

Abstract:
Exoskeletons are progressively reaching homes and workplaces, allowing interaction with virtual environments, remote control of robots, or assisting human operators in carrying heavy loads. Their design is however still a challenge as these robots, being mechanically linked to the operators who wear them, have to meet ergonomic constraints besides usual robotic requirements in terms of workspace, speed, or efforts. They have in particular to fit the anthropometry and mobility of their users. This traditionally results in numerous prototypes which are progressively fitted to each individual person. In this paper, we propose instead to validate the design of a hand exoskeleton in a fully digital environment, without the need for a physical prototype. The purpose of this study is thus to examine whether finger kinematics are altered when using a given hand exoskeleton. Therefore, user specific musculoskeletal models were created and driven by a motion capture system to evaluate the fingers' joint kinematics when performing two industrial related tasks. The kinematic chain of the exoskeleton was added to the musculoskeletal models and its compliance with the hand movements was evaluated. Our results show that the proposed exoskeleton design does not influence fingers' joints angles, the coefficient of determination between the model with and without exoskeleton being consistently high (R2¯=0.93) and the nRMSE consistently low (nRMSE¯ = 5.42°). These results are promising and this approach combining musculoskeletal and robotic modeling driven by motion capture data could be a key factor in the ergonomics validation of the design of orthotic devices and exoskeletons prior to manufacturing.
Related Concept Videos
 01:29
Reliability and Validity
 01:23
Hand hygiene
Hand washing...
 02:01
Group Design
 02:01
Factorial Design
 01:15
Data Validation
Key parameters for method validation include:
 01:03
Data Validation
Nursing assessment guides are generally based on holistic models rather than medical...