Related Experiment Video
Updated: Feb 14, 2026

Multipronged Phenotyping Approaches to Characterize Sugarcane Root Systems
Published on: August 17, 2022
A Dynamic Approach to Rebalancing Bike-Sharing Systems
Federico Chiariotti1, Chiara Pielli2, Andrea Zanella3,4
1Department of Information Engineering, University of Padova, 35131 Padova PD, Italy. chiariot@dei.unipd.it.

Abstract:
Bike-sharing services are flourishing in Smart Cities worldwide. They provide a low-cost and environment-friendly transportation alternative and help reduce traffic congestion. However, these new services are still under development, and several challenges need to be solved. A major problem is the management of rebalancing trucks in order to ensure that bikes and stalls in the docking stations are always available when needed, despite the fluctuations in the service demand. In this work, we propose a dynamic rebalancing strategy that exploits historical data to predict the network conditions and promptly act in case of necessity. We use Birth-Death Processes to model the stations' occupancy and decide when to redistribute bikes, and graph theory to select the rebalancing path and the stations involved. We validate the proposed framework on the data provided by New York City's bike-sharing system. The numerical simulations show that a dynamic strategy able to adapt to the fluctuating nature of the network outperforms rebalancing schemes based on a static schedule.
More Related Videos
Related Concept Videos
 01:18
Second Order systems II
 02:20
Dynamic Equilibrium
 01:21
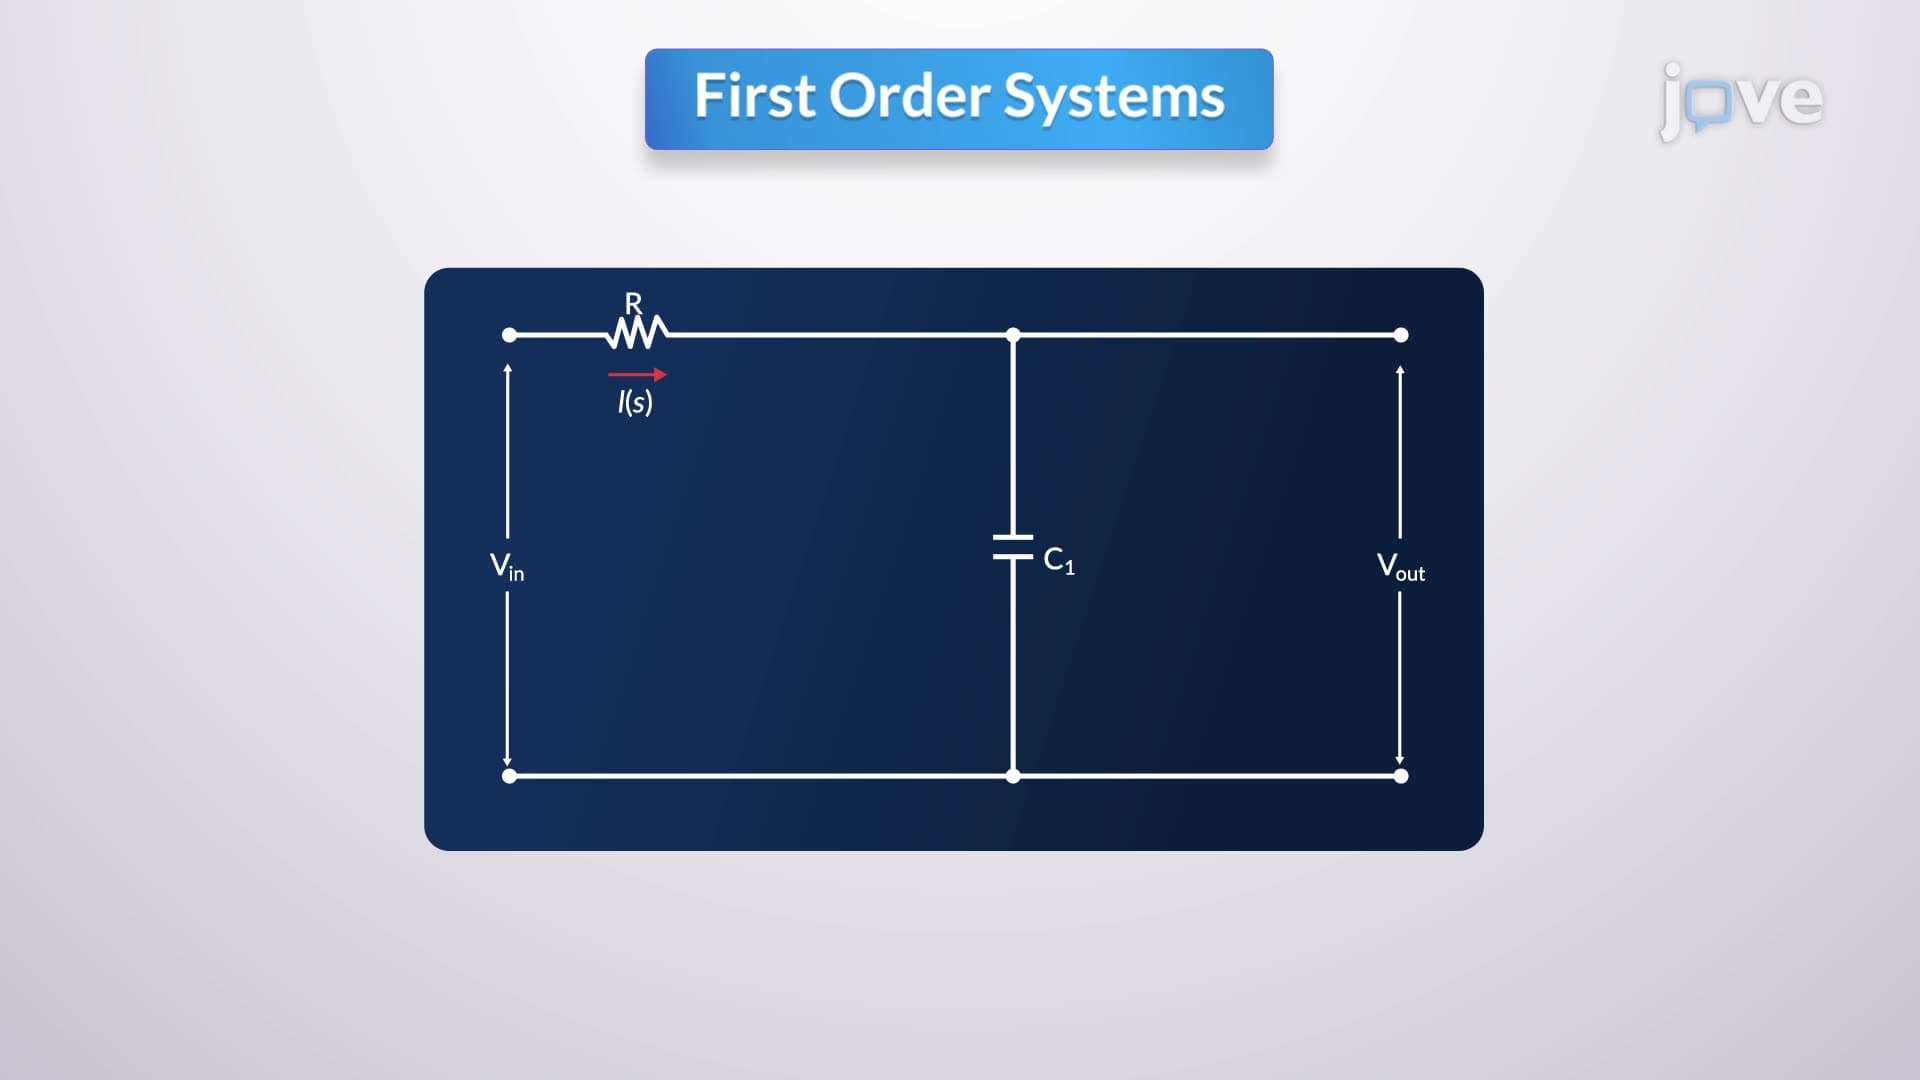
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
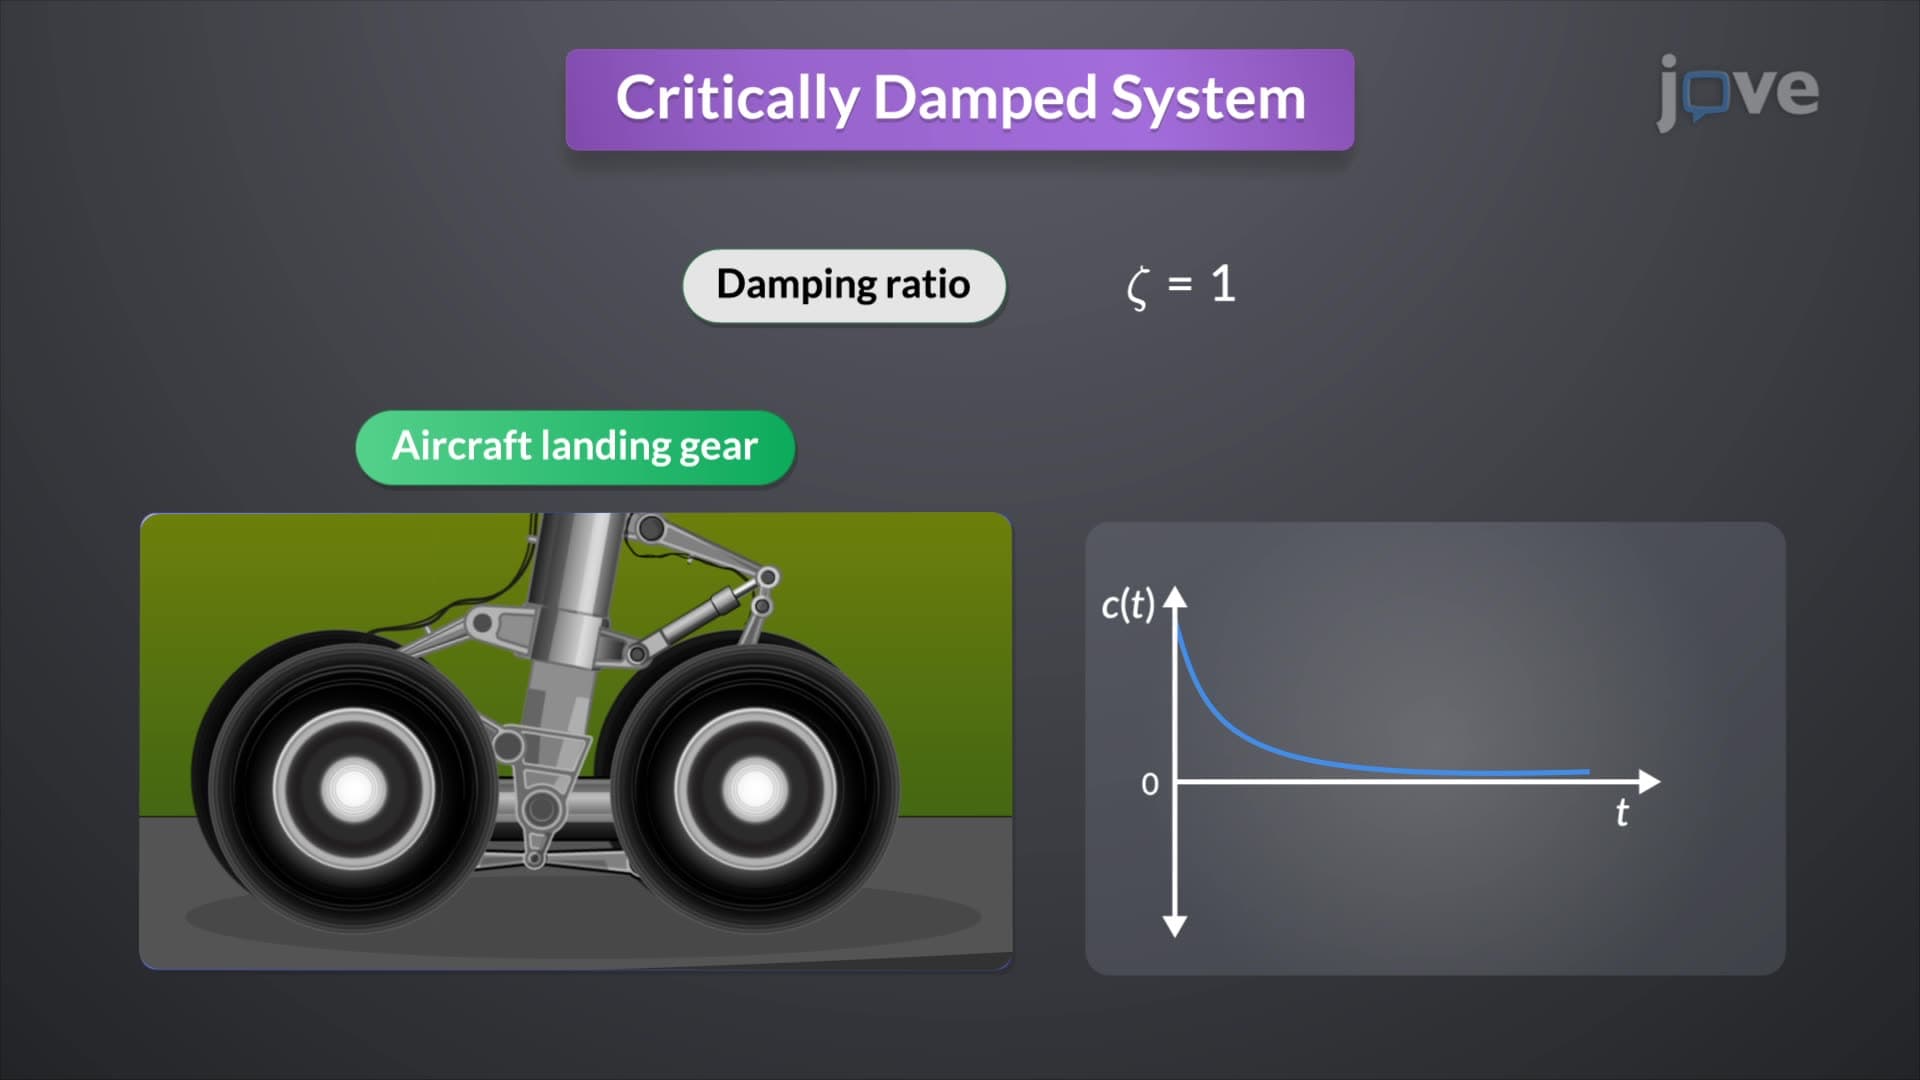
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:06
Thermodynamic Systems
Consider an example of tea boiling in a kettle. The...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as: