Related Experiment Video
Updated: Feb 14, 2026
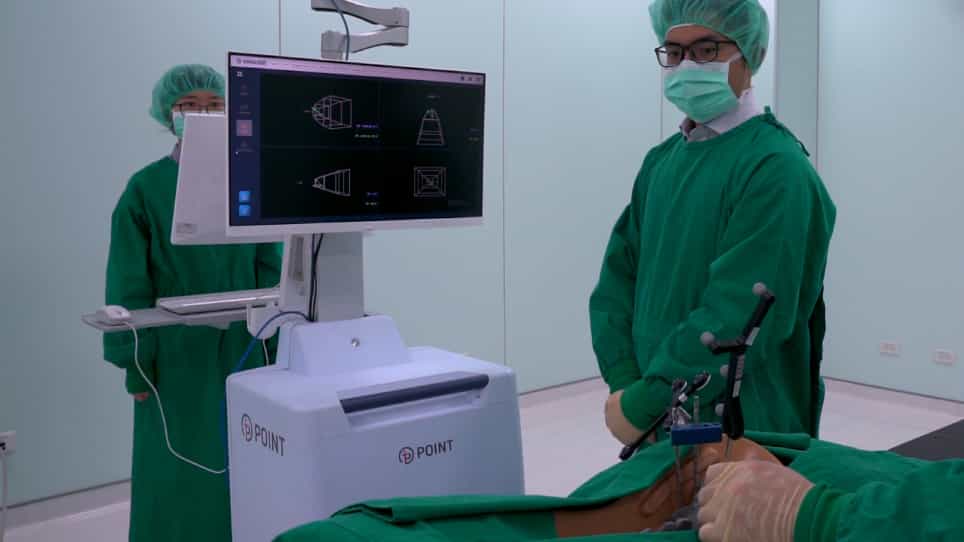

A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Feasibility and accuracy of computer-assisted individual drill guide template for minimally invasive lumbar pedicle
Hongwei Wang1, Yusheng Liu2, Yiwen Zhao3
1Department of Orthopedics, General Hospital of Shenyang Military Area Command of Chinese PLA, Shenyang, 110016, Liaoning, China; State Key Laboratory of Robotics, Shenyang Institute of Automation, Chinese Academy of Science, Shenyang, Liaoning, 110016, China; State Key Laboratory of Materials Processing and Die & Mould Technology, Huazhong University of Science and Technology, Wuhan, Hubei, 430074, China.

Objective:
To discuss the feasibility and accuracy of a specific computer-assisted individual drill guide template (CIDGT) for minimally invasive lumbar pedicle screw placement trajectory (MI-LPT) through a bovine cadaveric experimental study.
Design:
A 3-D reconstruction model, including lumbar vertebras (L1-L5), was generated, and the optimal MI-LPTs were determined. A drill guide template with a surface made of the antitemplate of the vertebral surface, including the spinous process and the entry point vertebral surface, was created by reverse engineering and rapid prototyping techniques. Then, MI-LPTs were determined by the drill guide templates, and the trajectories made by K-wires were observed by postoperative CT scan.
Setting:
General Hospital of Shenyang Military Area Command of Chinese PLA.
Results:
In total, 150 K-wires for MI-LPTs were successfully inserted into L1-L5. The required mean time and fluoroscopy times between fixation of the template to the spinous process, entry point vertebral surface, and insertion of the K-wires for minimally invasive lumbar pedicle screw placement trajectories into each vertebra were 79.4 ± 15.0 s and 2.1 ± 0.8 times. There were no significant differences between the preoperative plan and postoperative assessment in the distance from the puncture to the midline and inclination angles according to the different levels (P > 0.05, respectively). The mean deviation between the preoperative plan and postoperative assessment in the distance from the puncture to the midline and inclination angles were 0.8 ± 0.5 mm and 0.9 ± 0.5°, respectively.
Conclusions:
The potential use of the novel CIDGT, which was based on the unique morphology of the lumbar vertebra to place minimally invasive lumbar pedicle screws, is promising and could prevent too much radiation exposure intraoperatively.
Related Concept Videos
 01:26
Orthogonal Trajectories
 02:05
DNA as a Genetic Template
02:05DNA as a Genetic Template
 02:07
Improving Translational Accuracy
 01:21
Screw: Problem Solving
To evaluate the...
 01:16
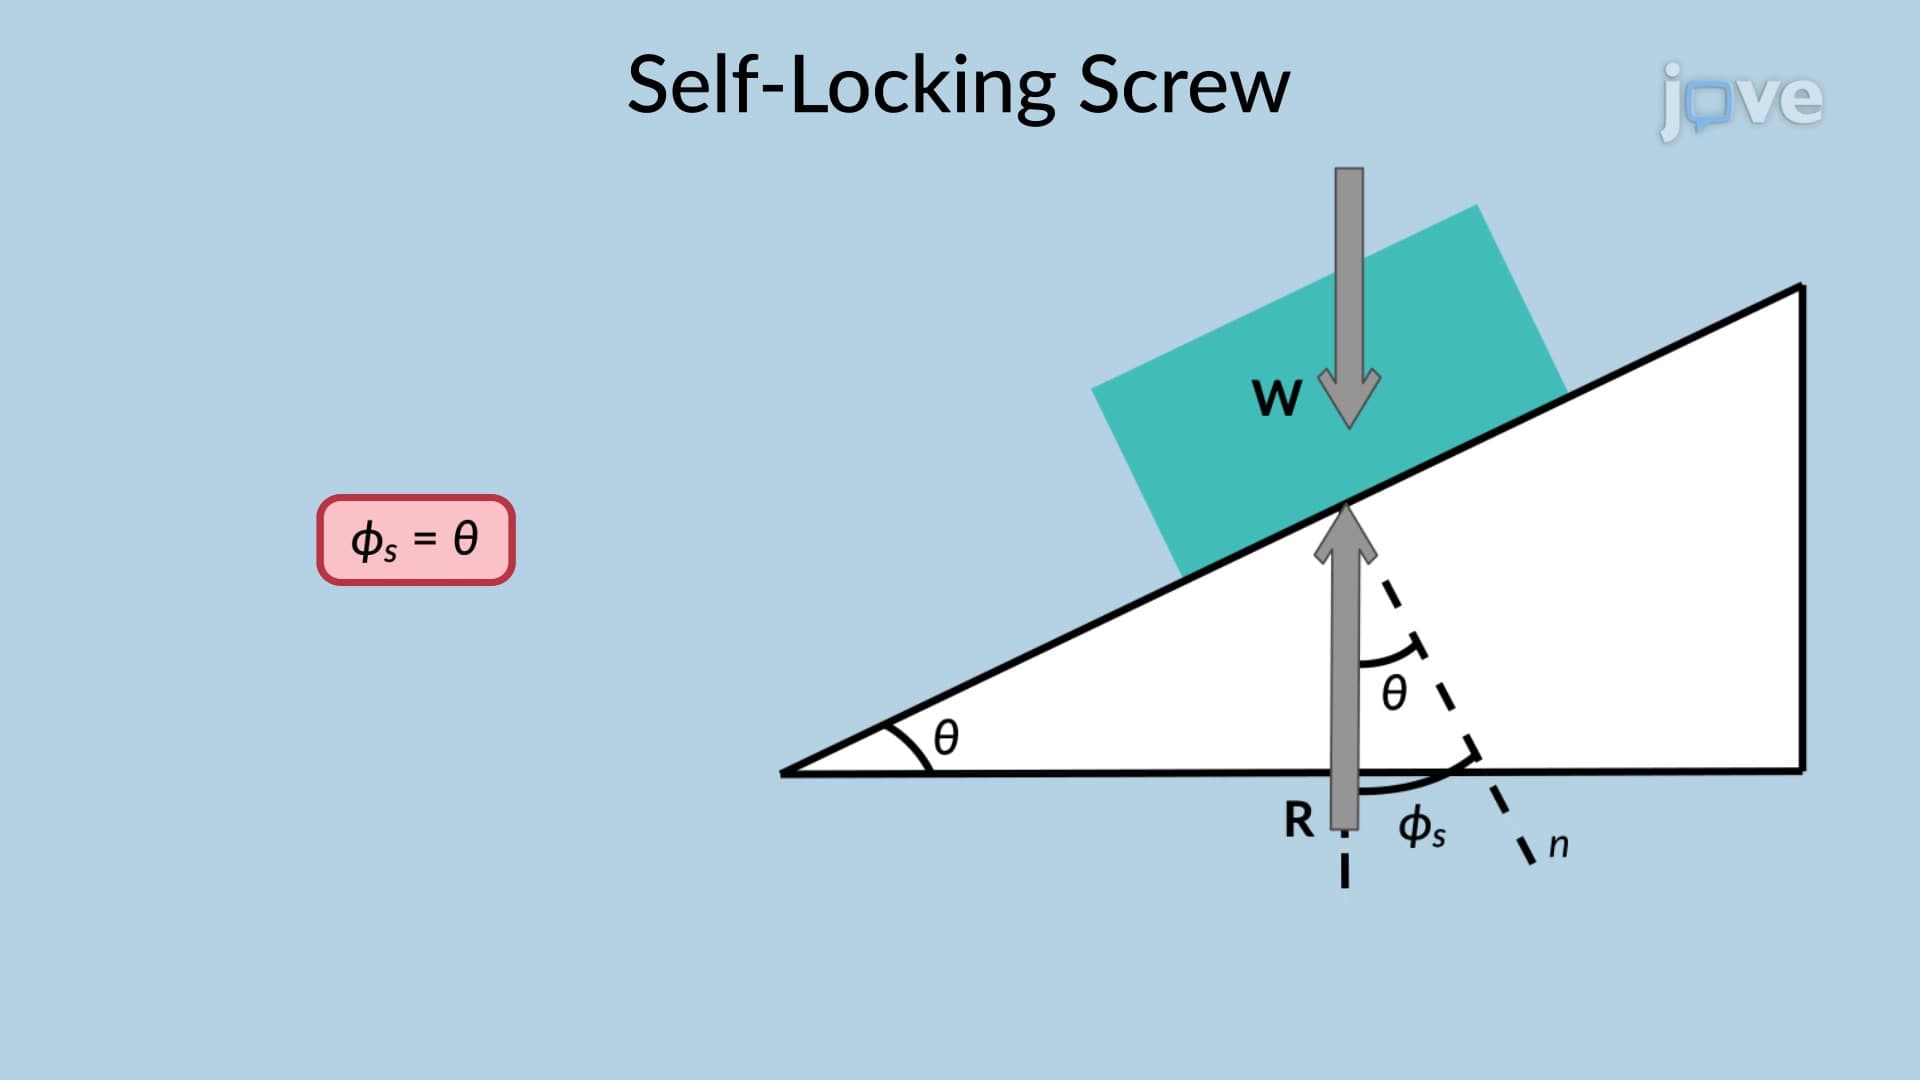
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.