Publisher's Note: Inverse Ising problem in continuous time: A latent variable approach [Phys. Rev. E 96, 062104 (2017)]
Related Experiment Video
Updated: Aug 15, 2026

10:46
A Method of Trigonometric Modelling of Seasonal Variation Demonstrated with Multiple Sclerosis Relapse Data
Published on: December 9, 2015
Physical Review. E
|February 17, 2018

Abstract:
This corrects the article DOI: 10.1103/PhysRevE.96.062104.
Related Concept Videos
 01:10
Entropy Change in Reversible Processes
In the Carnot engine, which achieves the maximum efficiency between two reservoirs of fixed temperatures, the total change in entropy is zero. The observation can be generalized by considering any reversible cyclic process consisting of many Carnot cycles. Thus, it can be stated that the total entropy change of any ideal reversible cycle is zero.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
 01:25
Poisson's And Laplace's Equation
The electric potential of the system can be calculated by relating it to the electric charge densities that give rise to the electric potential. The differential form of Gauss's law expresses the electric field's divergence in terms of the electric charge density.
 01:22
Basic Continuous Time Signals
Basic continuous-time signals include the unit step function, unit impulse function, and unit ramp function, collectively referred to as singularity functions. Singularity functions are characterized by discontinuities or discontinuous derivatives.
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:24
BIBO stability of continuous and discrete -time systems
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:29
Improper Integrals: Infinite Intervals
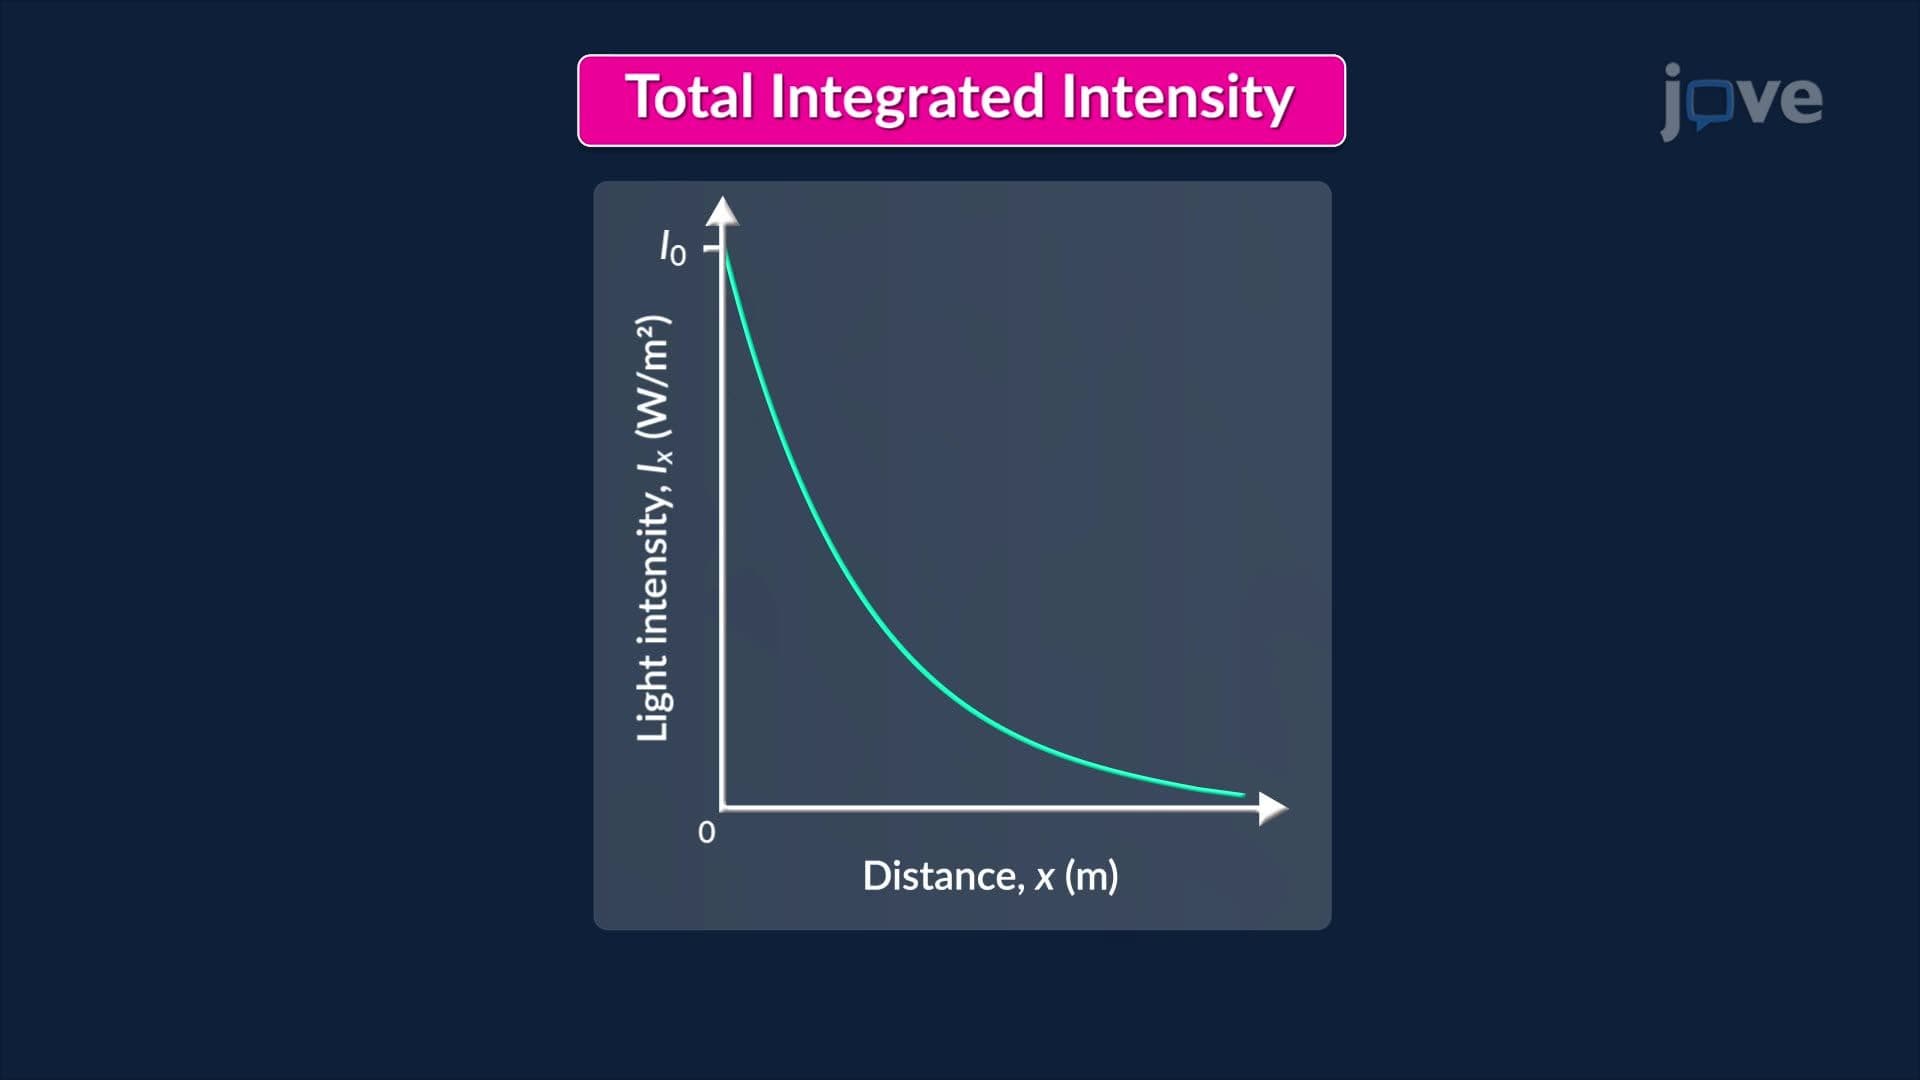
An integral is classified as improper due to an infinite interval when at least one of its limits of integration extends to positive or negative infinity. In such cases, the region under the curve is unbounded, and standard techniques for evaluating definite integrals are not directly applicable. Instead, the improper integral is defined through a limiting process that allows one to determine whether the accumulated area remains finite despite the infinite domain.Application to Exponential...
 01:21
Partial Differential Equations
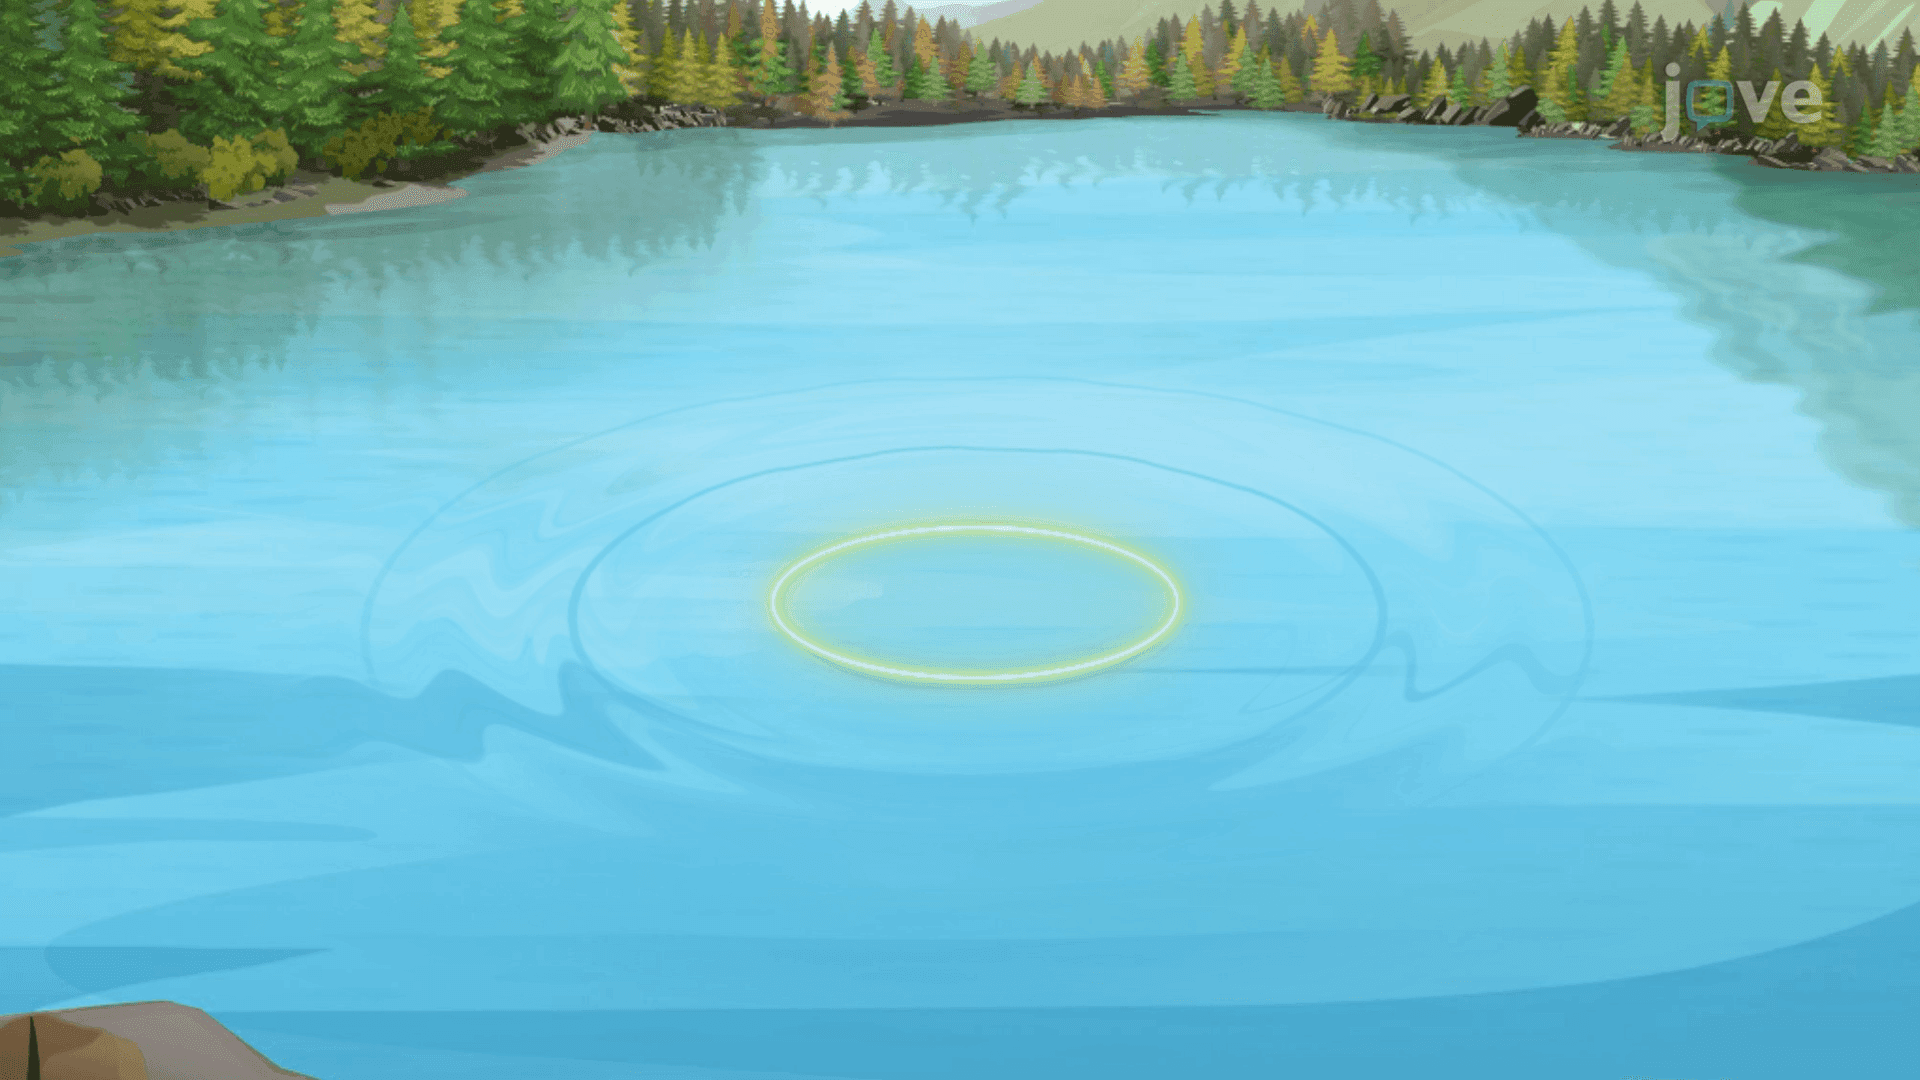
A stone dropped into a still pond generates waves that propagate outward in circular patterns, creating a dynamic surface whose elevation depends on both position and time. At any given location, the water level oscillates as the wave passes, while at any fixed moment, the surface exhibits smooth, curved structures extending across space. This dual dependence requires a mathematical description that accounts for variation in multiple variables simultaneously.At a fixed point on the water...