Related Experiment Video
Updated: Feb 13, 2026


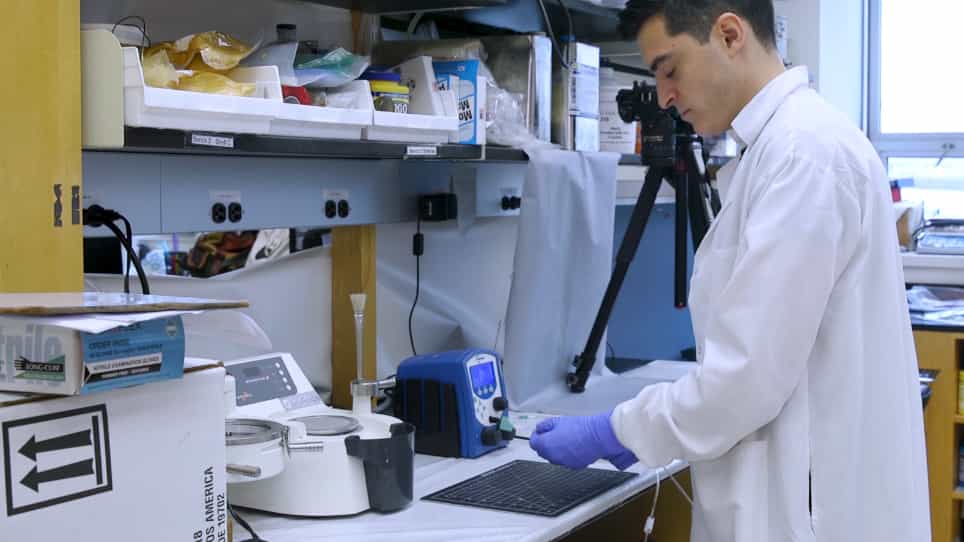
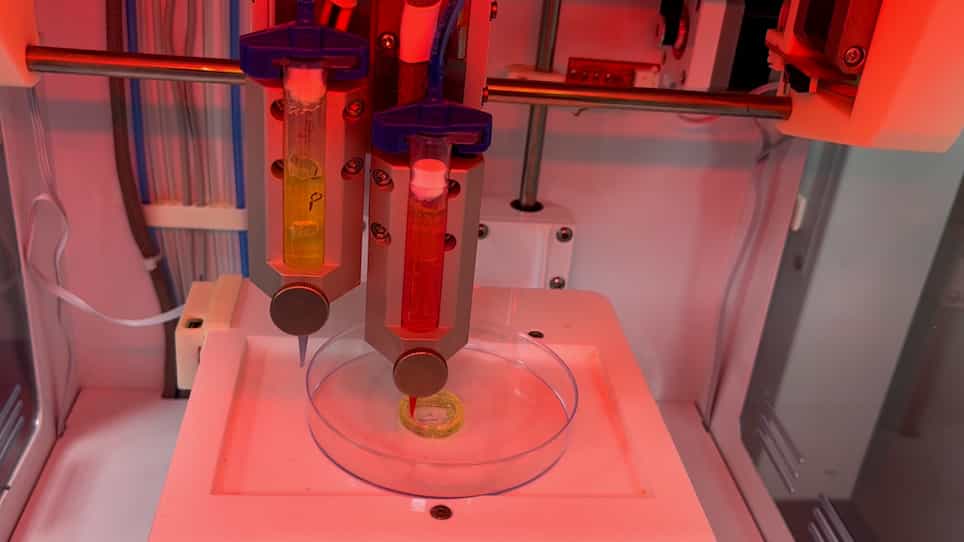
Bioinspired Soft Robot with Incorporated Microelectrodes
Published on: February 28, 2020
3D printing of robotic soft actuators with programmable bioinspired architectures
Manuel Schaffner1, Jakob A Faber2, Lucas Pianegonda1
1Complex Materials, Department of Materials, ETH Zürich, 8093, Zürich, Switzerland.

Abstract:
Soft actuation allows robots to interact safely with humans, other machines, and their surroundings. Full exploitation of the potential of soft actuators has, however, been hindered by the lack of simple manufacturing routes to generate multimaterial parts with intricate shapes and architectures. Here, we report a 3D printing platform for the seamless digital fabrication of pneumatic silicone actuators exhibiting programmable bioinspired architectures and motions. The actuators comprise an elastomeric body whose surface is decorated with reinforcing stripes at a well-defined lead angle. Similar to the fibrous architectures found in muscular hydrostats, the lead angle can be altered to achieve elongation, contraction, or twisting motions. Using a quantitative model based on lamination theory, we establish design principles for the digital fabrication of silicone-based soft actuators whose functional response is programmed within the material's properties and architecture. Exploring such programmability enables 3D printing of a broad range of soft morphing structures.
Related Concept Videos
 01:14
Polymer Classification: Architecture
 02:00
Molecular Models
 01:39
Keystone Species
 02:16
Light Acquisition
 02:35
Transcription Elongation Factors
The transcription elongation is regulated via pausing of RNA polymerase on several occasions during transcription. In bacteria, these halts are necessary because the transcription of DNA into mRNA is coupled to the translation of that mRNA...
 02:34
Water and Mineral Acquisition