Related Experiment Video
Updated: Feb 12, 2026

Intravital Imaging of Intraepithelial Lymphocytes in Murine Small Intestine
Published on: June 24, 2019
Intraepithelial corneal haemorrhage in a rigid contact lens wearer
James Simpson1, Stephen J Vincent2
1Simpson Optometry, Canberra, ACT, Australia.

Abstract:
Intracorneal haemorrhage is a rare complication of modern contact lens wear. While a limited number of reports have described intracorneal haemorrhages (typically stromal) associated with the extended wear of soft contact lenses with limited oxygen permeability for the correction of aphakia, this case report documents the management and resolution of a significant intraepithelial corneal haemorrhage associated with long-term rigid contact lens wear for keratoconus and high myopia.
Related Concept Videos
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 01:13
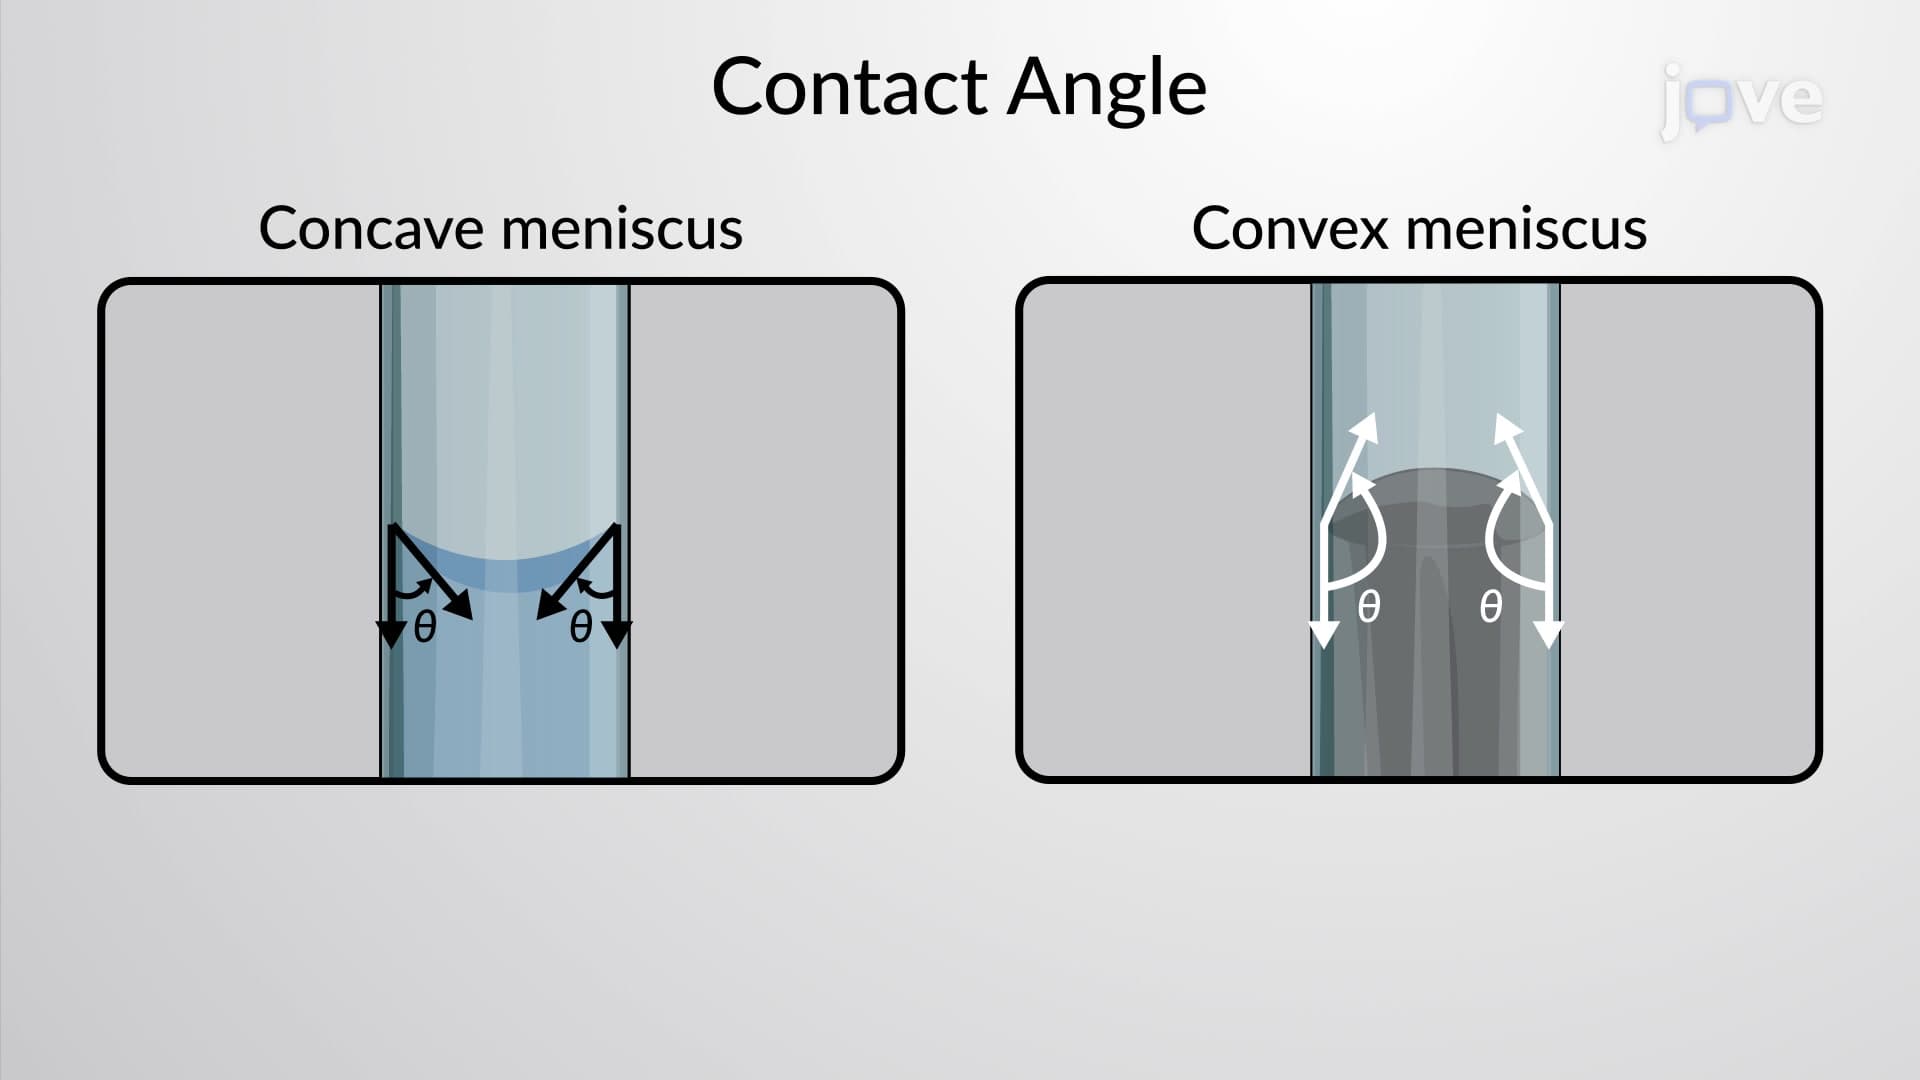
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:11
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...