Related Experiment Video
Updated: Feb 12, 2026
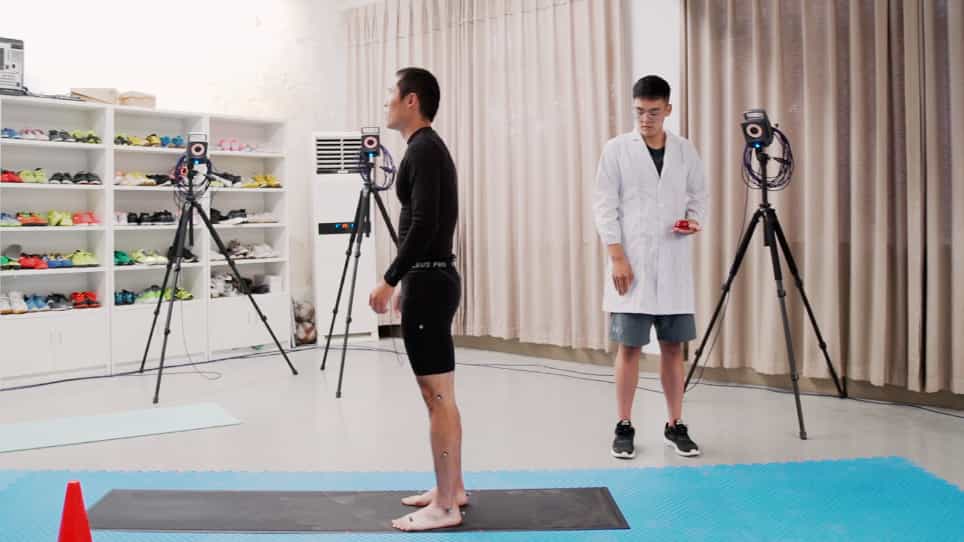
Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
A simple bipedal model for studying control of gait termination
Yasuyuki Suzuki1, Hartmut Geyer
1Robotics Institute, Carnegie Mellon University, Pittsburgh, PA, United States of America. Graduate School of Engineering Science, Osaka University, Osaka, Japan.

Abstract:
We study the control of human gait termination with a simple bipedal locomotion model. Several control strategies have been proposed for gait termination. However, the relative importance of these strategies has not been evaluated in models of human gait. Here we extend the bipedal spring mass walking model in a least parameter fashion and study three explicit control strategies for gait termination, including the shortening of the final step, braking at the ankle, and extending the knee. Applying the strategies separately, we find that only braking at the ankle reduces the propulsive force enough to transition into quiet standing. In combination with the other two strategies, we observe that the range of control parameters suitable for gait termination increases, especially when the ankle control is applied intermittently by taking advantage of passive stabilizing dynamics. We further show the resulting model behavior is compatible with several experimental observations about the human center of mass dynamics and leg forces during gait termination, and discuss model improvements to correct mismatches. The proposed model may serve as a starting point for more advanced models that can provide a deeper understanding of human control strategies during gait termination.
Related Concept Videos
 01:44
Termination of Translation
01:44Termination of Translation
 01:23
Types of Biopharmaceutical Studies: Controlled and Non-Controlled Approaches
Non-controlled studies, commonly employed for initial exploration, lack a control group, rendering them susceptible to biases and external influences. In contrast,...
 01:18
Drag Force and Terminal Speed
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:30
Typical Model Studies