An Enduring Dialogue between Computational and Empirical Vision

Susana Martinez-Conde1, Stephen L Macknik1, David J Heeger2

  • 1State University of New York, Downstate Medical Center, Brooklyn, NY 11203, USA.

Related Concept Videos

Vision01:24

Vision

Vision is the result of light being detected and transduced into neural signals by the retina of the eye. This information is then further analyzed and interpreted by the brain. First, light enters the front of the eye and is focused by the cornea and lens onto the retina—a thin sheet of neural tissue lining the back of the eye. Because of refraction through the convex lens of the eye, images are projected onto the retina upside-down and reversed.
60.3K
Empirical Method to Interpret Standard Deviation01:09

Empirical Method to Interpret Standard Deviation

The empirical rule, also known as the three-sigma rule, allows a statistician to interpret the standard deviation in a normally distributed dataset. The rule states that 68% of the data lies within one standard deviation from the mean, 95% lies within two standard deviations from the mean, and 99.7% lies within three standard deviations from the mean. Additionally, this rule is also called the 68-95-99.7 rule.
This rule is used widely in statistics to calculate the proportion of data values...
10.3K
Color Vision01:24

Color Vision

Color perception begins in the retina, the light-sensitive layer at the back of the eye. Two main theories explain how colors are seen: the trichromatic theory and the opponent-process theory. The trichromatic theory, proposed by Thomas Young in 1802 and extended by Hermann von Helmholtz in 1852, suggests that color vision is based on three types of cone receptors in the retina. These cones are sensitive to different but overlapping ranges of wavelengths corresponding to red, blue, and green.
1.5K
Depth Perception and Spatial Vision01:15

Depth Perception and Spatial Vision

Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
2.1K
Computed Tomography01:10

Computed Tomography

Tomography refers to imaging by sections. Computed tomography (CT) is a non-invasive imaging technique that uses computers to analyze several cross-sectional X-rays to reveal minute details about structures in the body.
The technique was invented in the 1970s and is based on the principle that as X-rays pass through the body, they are absorbed or reflected at different levels. In the technique, a patient lies on a motorized platform while a computerized axial tomography (CAT) scanner rotates...
8.9K
Design Example: Traverse Angle Computations01:25

Design Example: Traverse Angle Computations

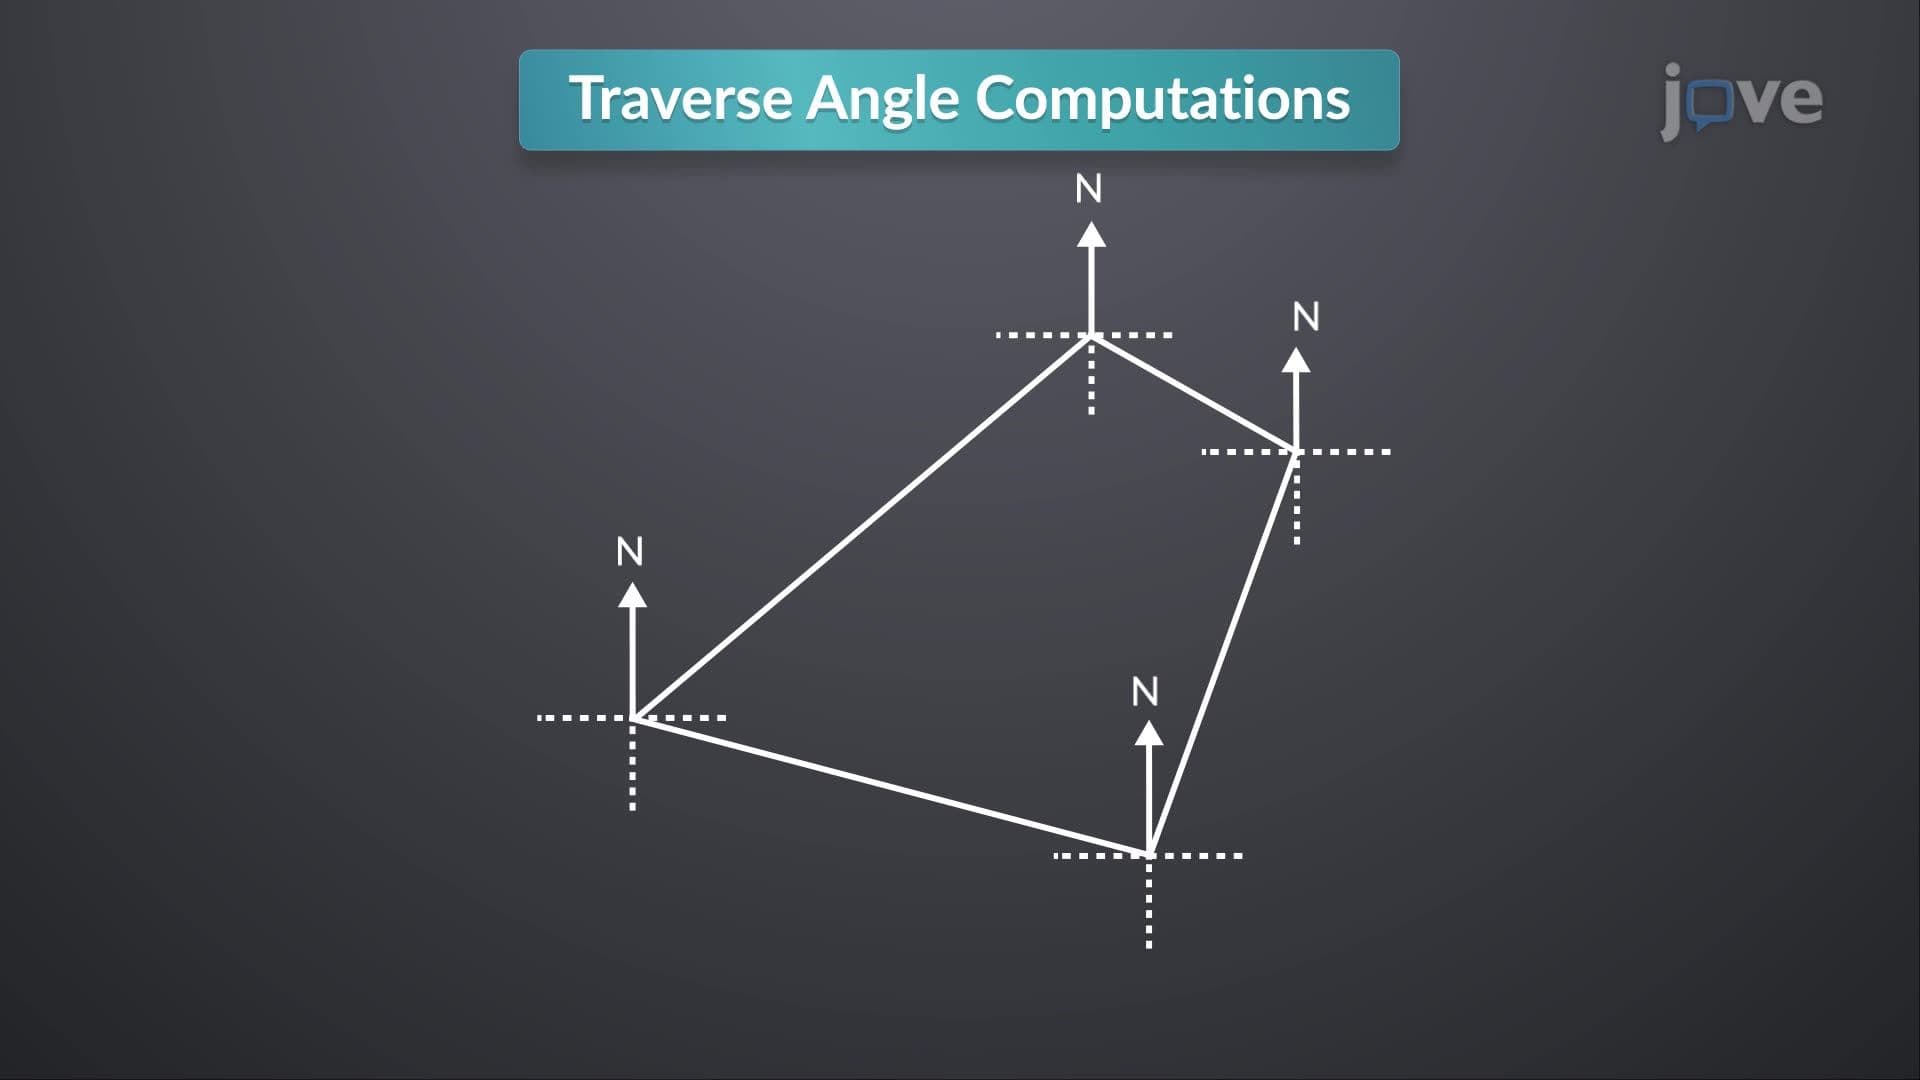
Traverse angle computations are a critical component of surveying, used to compute the internal angles within a closed traverse. A traverse consists of a series of connected lines forming a closed loop, often used for land boundary delineation or mapping. Calculating the internal angles ensures accuracy in the traverse geometry and is essential for checking survey data integrity.The process begins with known azimuths and bearings of the traverse sides. Internal angles at each vertex are...
344