Signal Quality Improvement Algorithms for MEMS Gyroscope-Based Human Motion Analysis Systems: A Systematic Review
Related Experiment Video
Updated: Feb 12, 2026
Fabrication of 3D Carbon Microelectromechanical Systems C-MEMS
Published on: June 17, 2017
Jiaying Du1,2, Christer Gerdtman3, Maria Lindén4
1School of Innovation, Design and Engineering, Mälardalen University, 721 23 Västerås, Sweden. jiaying.du@mdh.se.

Abstract:
Motion sensors such as MEMS gyroscopes and accelerometers are characterized by a small size, light weight, high sensitivity, and low cost. They are used in an increasing number of applications. However, they are easily influenced by environmental effects such as temperature change, shock, and vibration. Thus, signal processing is essential for minimizing errors and improving signal quality and system stability. The aim of this work is to investigate and present a systematic review of different signal error reduction algorithms that are used for MEMS gyroscope-based motion analysis systems for human motion analysis or have the potential to be used in this area. A systematic search was performed with the search engines/databases of the ACM Digital Library, IEEE Xplore, PubMed, and Scopus. Sixteen papers that focus on MEMS gyroscope-related signal processing and were published in journals or conference proceedings in the past 10 years were found and fully reviewed. Seventeen algorithms were categorized into four main groups: Kalman-filter-based algorithms, adaptive-based algorithms, simple filter algorithms, and compensation-based algorithms. The algorithms were analyzed and presented along with their characteristics such as advantages, disadvantages, and time limitations. A user guide to the most suitable signal processing algorithms within this area is presented.
Related Concept Videos
 01:02
Gyroscope
 01:24
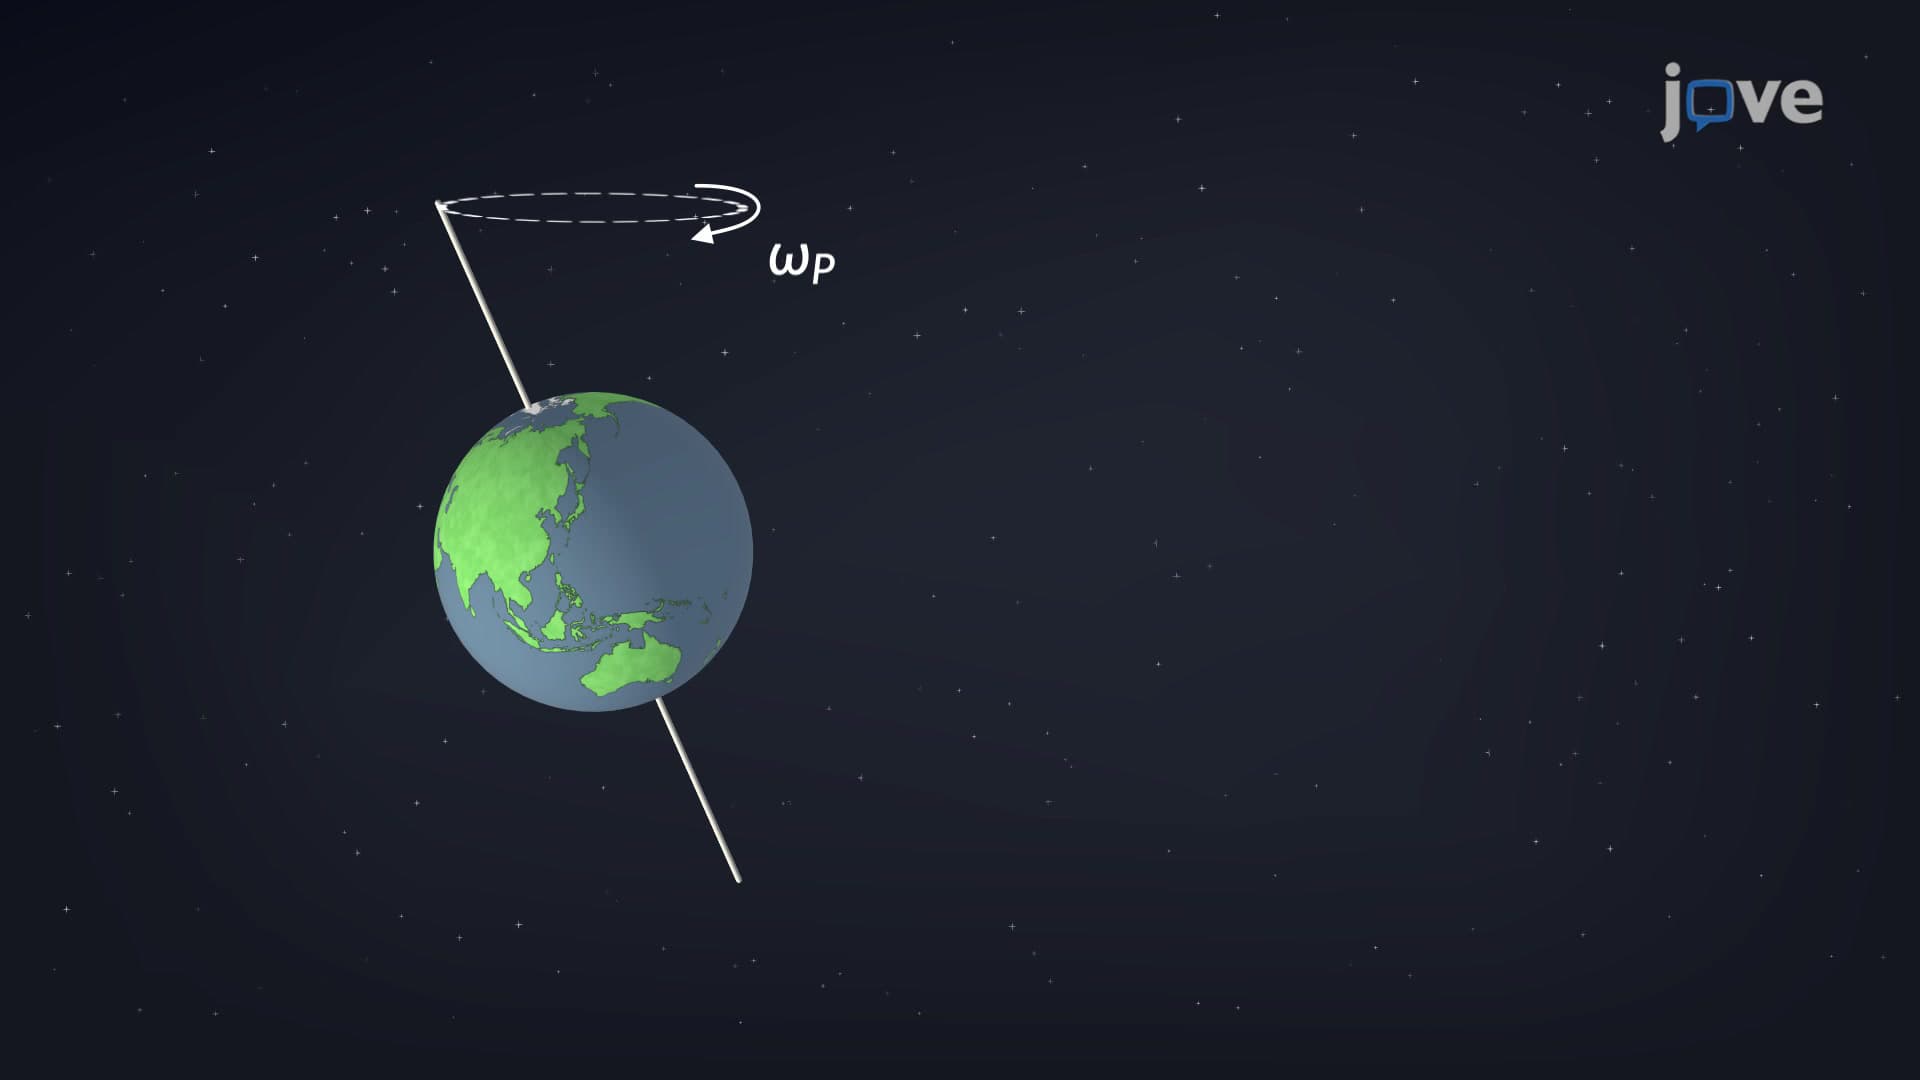
Gyroscope: Precession
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:10
Review and Preview
Percentiles are a type of fractile that partition data into...