Related Experiment Video
Updated: Feb 11, 2026
Cost-effective Method for Microbial Source Tracking Using Specific Human and Animal Viruses
Published on: December 3, 2011
Effective leg stiffness of animal running and the co-optimization of energetic cost and stability
1Mathworks, MA USA.

Abstract:
The relative leg stiffness of most running animals falls in a small range between 7 and 27. Here we present a theoretical study of an established running model, an actuated Spring Loaded Inverted Pendulum model, to determine if the energetic cost and stability of running might be co-optimized over this range of leg stiffness values. The energetic cost of the model is quantified as the energy spent to move a unit mass a unit distance. The stability of the model is based on the system response to perturbations with respect to periodic locomotion solutions, and uses the linearized dynamics of Poincaré return maps and the resulting maximum eigenvalue and singular value decomposition in order to analyze asymptotic stability and the overall system response to perturbations, respectively. We find that there exists a tradeoff between stability and energetic cost in the model with respect to variation in forcing (actuation) level: For a given leg stiffness, the energetic cost tends to be more optimal with smaller forcing, and the opposite for stability. We find that intermediate levels of forcing can achieve near asymptotic stability or complete asymptotic stability while remaining small enough to yield a relatively low energetic cost consistent with human-like values. We demonstrate that this outcome can be achieved in the model with a simple optimization function that balances stability and energetic cost. We then investigate the stability and energetic cost when both leg stiffness and forcing are varied. Overall, the analysis shows that leg stiffness values in or near the biological range offers a good chance of simultaneously achieving both reasonable energetic cost and stability in the model. The results of this study suggest that stability and energetic cost may be interacting factors that have a combined influence on the effective leg stiffness and actuation (forcing) used by running animals.
Related Concept Videos
 01:23
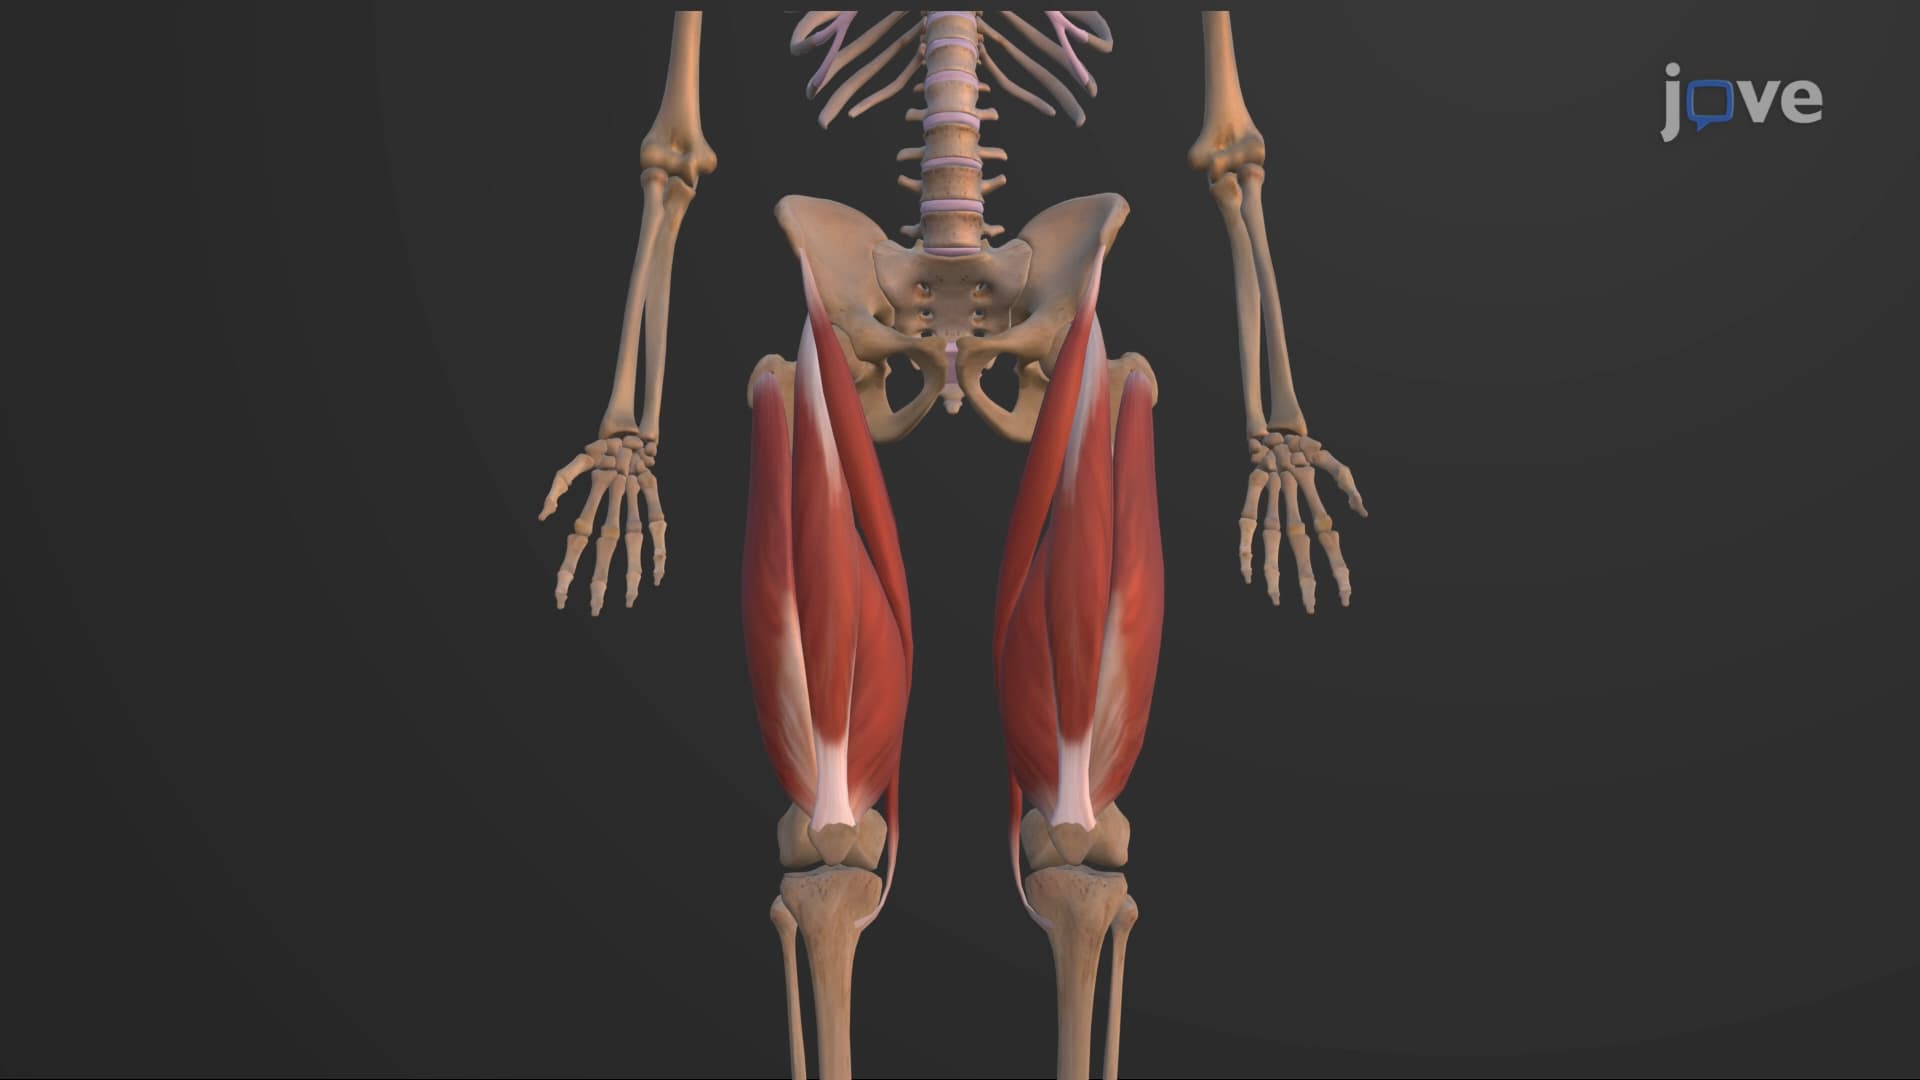
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 00:48
Optimal Foraging
 02:35
Energetics of Solution Formation
When the strengths of the intermolecular forces of attraction between solute and solvent species in a solution are no different than those present in the separated components, the solution is formed with no accompanying energy change. Formation of the solution requires the solute–solute and solvent–solvent...
 01:17
Wald-Wolfowitz Runs Test II
For binary data, runs are identified using symbols such as + and −, or equivalently, 1s and 0s. In...
 01:17
Wald-Wolfowitz Runs Test I
The test works...
 03:18
Nuclear Stability
To hold positively charged protons together...