Related Experiment Video
Updated: Feb 11, 2026

Measuring the Kinematics of Daily Living Movements with Motion Capture Systems in Virtual Reality
Published on: April 5, 2018
A canonical form of the equation of motion of linear dynamical systems
Daniel T Kawano1, Rubens Goncalves Salsa2, Fai Ma2
1Department of Mechanical Engineering, Rose-Hulman Institute of Technology, Terre Haute, IN 47803, USA.

Abstract:
The equation of motion of a discrete linear system has the form of a second-order ordinary differential equation with three real and square coefficient matrices. It is shown that, for almost all linear systems, such an equation can always be converted by an invertible transformation into a canonical form specified by two diagonal coefficient matrices associated with the generalized acceleration and displacement. This canonical form of the equation of motion is unique up to an equivalence class for non-defective systems. As an important by-product, a damped linear system that possesses three symmetric and positive definite coefficients can always be recast as an undamped and decoupled system.

Related Concept Videos
 01:25
Systems of Linear Equations in Two Variables
 01:27
Linear Equations
 01:27
Linear Differential Equations
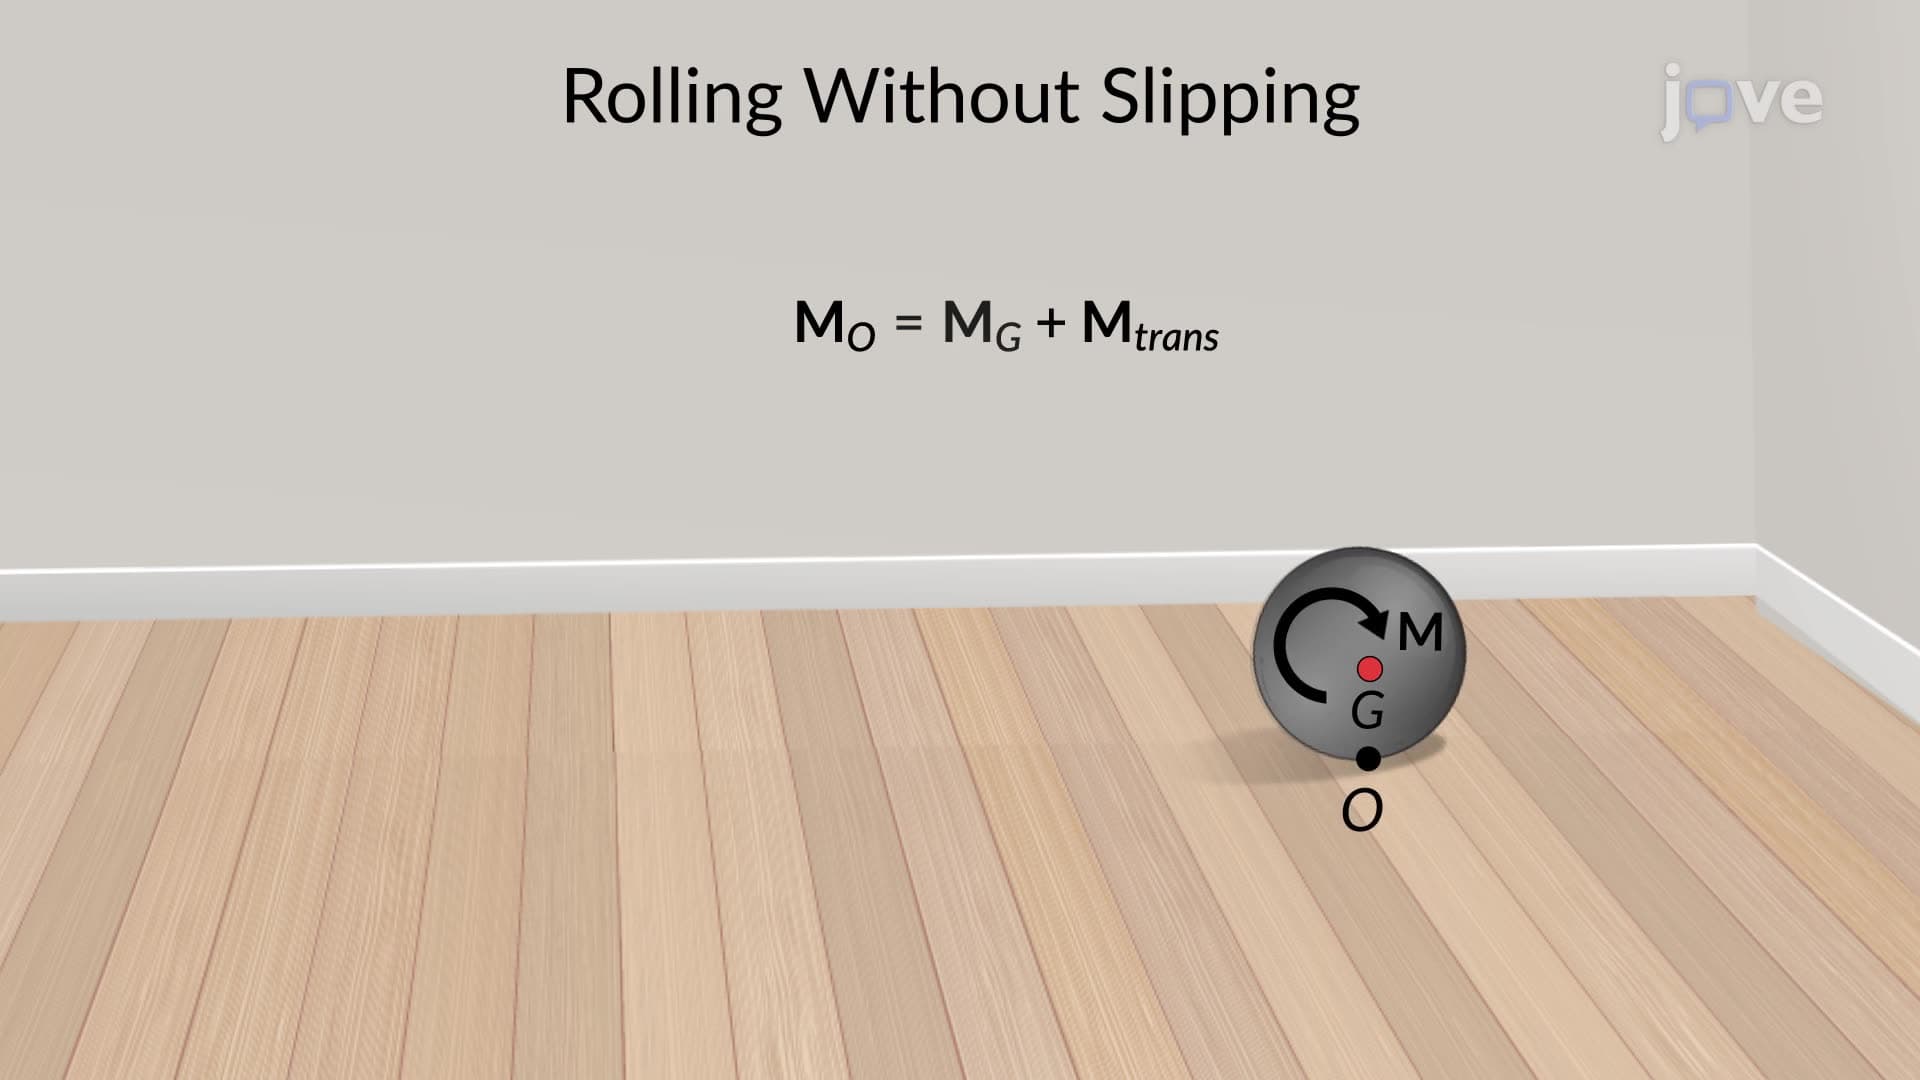 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:25
Systems of Equations
 01:15
Application of the Linear Momentum Equation
The goal is to determine the force components in the x and y directions to hold the pipe in place. Since...