Related Experiment Video
Updated: Feb 11, 2026
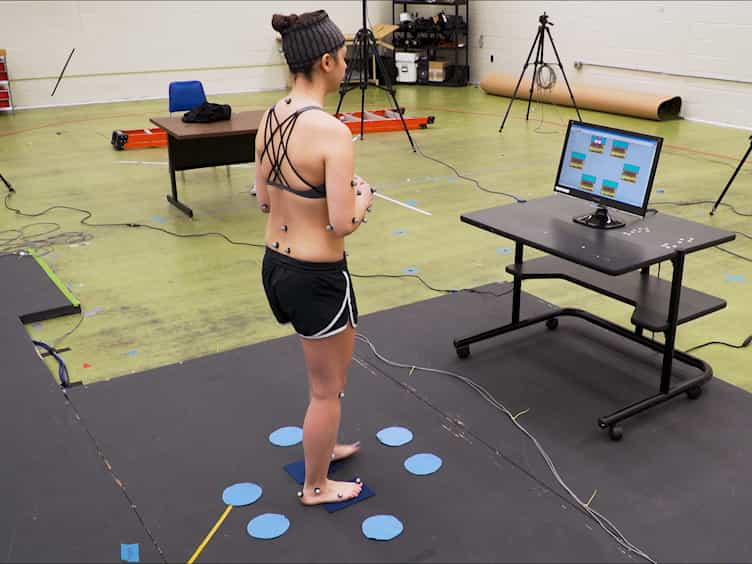

The "Motor" in Implicit Motor Sequence Learning: A Foot-stepping Serial Reaction Time Task
Published on: May 3, 2018
Dynamical Motor Control Learned with Deep Deterministic Policy Gradient
Haibo Shi1, Yaoru Sun1, Jie Li1
1Laboratory of Cognition & Intelligent Computing, Department of Computer Science, Tongji University, Shanghai, China.

Abstract:
Conventional models of motor control exploit the spatial representation of the controlled system to generate control commands. Typically, the control command is gained with the feedback state of a specific instant in time, which behaves like an optimal regulator or spatial filter to the feedback state. Yet, recent neuroscience studies found that the motor network may constitute an autonomous dynamical system and the temporal patterns of the control command can be contained in the dynamics of the motor network, that is, the dynamical system hypothesis (DSH). Inspired by these findings, here we propose a computational model that incorporates this neural mechanism, in which the control command could be unfolded from a dynamical controller whose initial state is specified with the task parameters. The model is trained in a trial-and-error manner in the framework of deep deterministic policy gradient (DDPG). The experimental results show that the dynamical controller successfully learns the control policy for arm reaching movements, while the analysis of the internal activities of the dynamical controller provides the computational evidence to the DSH of the neural coding in motor cortices.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:26
What is an Electrochemical Gradient?
The chemical gradient relies on differences in the abundance of a substance on the outside versus the inside of a cell and flows from areas of high to low ion concentration. In contrast, the electrical gradient revolves around an...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:27
Energy Line and Hydraulic Gradient Line
 01:14
Gradient and Del Operator
 02:20
Dynamic Equilibrium