Related Experiment Video
Updated: Feb 11, 2026
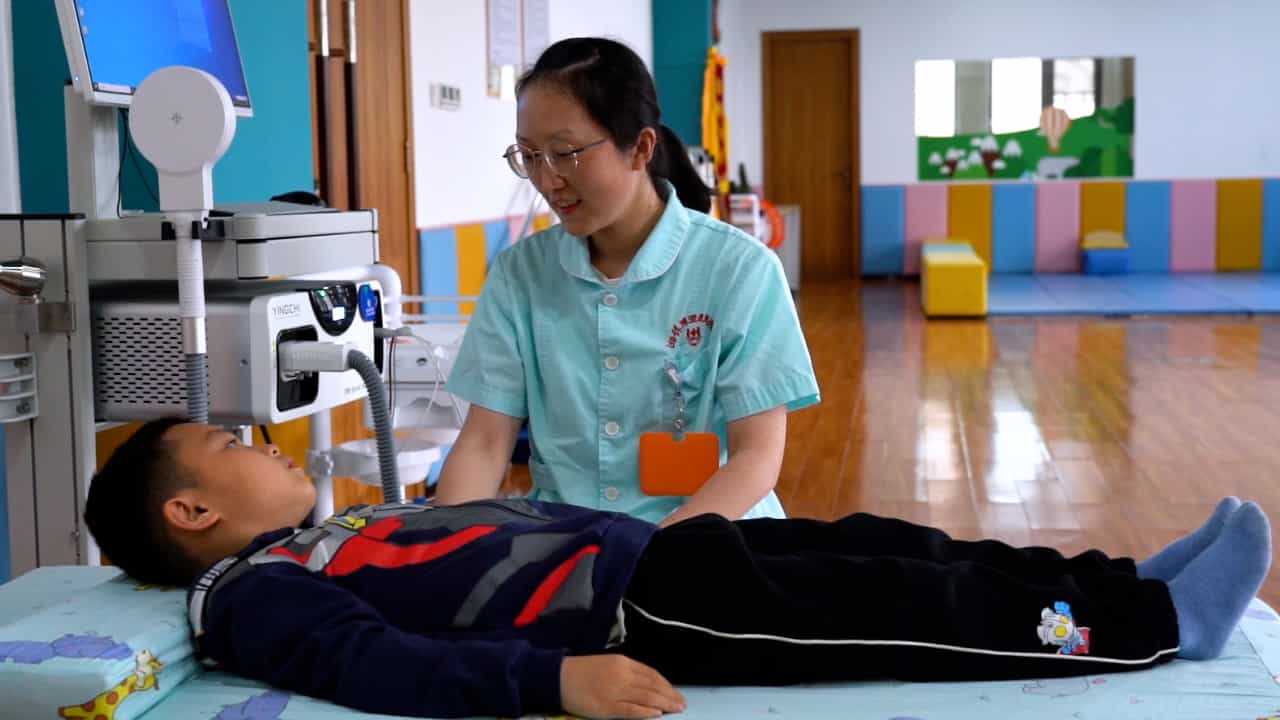

Author Spotlight: Repetitive Transcranial Magnetic Stimulation Combined with Movement Observation in Cerebral Palsy
Published on: August 9, 2024
Slip avoidance strategies in children with bilateral spastic cerebral palsy and crouch gait
Ana Francisca Rozin Kleiner1, Ilaria Pacifici2, Claudia Condoluci3
1Department of Electronics, Information and Bioengineering, Politecnico di Milano, Piazza Leonardo da Vinci 32, Milan, Italy; University Center of Anápolis - Uni Evangélica, Anápolis, Goiás, Brazil.

Insights
Children with bilateral spastic cerebral palsy (BSCP) and crouch gait exhibit higher required friction (RCOF) and lower gait velocity. They struggle to manage foot/floor forces, reducing speed to prevent falls.
Area of Science:
- Biomechanics
- Gait Analysis
- Pediatric Neurology
Background:
- Slips occur when required friction exceeds available friction at the foot/floor interface.
- Required friction depends on individual biomechanics and gait, while available friction depends on environmental factors.
- Altered gait biomechanics in individuals with crouch gait raise questions about their interaction with supporting surfaces.
Purpose of the Study:
- To quantify the required coefficient of friction (RCOF) in children with bilateral spastic cerebral palsy (BSCP) exhibiting crouch gait.
- To investigate the relationship between gait parameters and friction forces in children with BSCP and crouch gait.
Main Methods:
- 11 children with BSCP and crouch gait and 11 healthy controls walked barefoot over a force platform.
- Required coefficient of friction (RCOF) was calculated as the ratio of tangential to vertical ground reaction forces.
- RCOF, tangential forces (FT), and vertical ground reaction forces (FZ) were analyzed at loading response, midstance, and push-off.
Main Results:
- Children with BSCP demonstrated higher RCOF values throughout the support phase compared to healthy controls.
- Gait velocity was significantly lower in children with BSCP.
- No correlation between FT and FZ was observed in the BSCP group, indicating an inability to negotiate forces during the support phase.
Conclusions:
- Children with BSCP and crouch gait are unable to effectively manage ground reaction forces during the support phase.
- To mitigate the risk of falling, these children adopt a strategy of reducing their walking speed.
Background:
A slip occurs when the required friction (RCOF) to prevent slipping at the foot/floor interfaces exceeds the available friction. The RCOF is dependent upon the biomechanics features of individuals and their gait. On the other hand, the available friction depends on environmental features. Once individuals with crouch gait have their biomechanics of gait completely altered, how do they interact with a supporting surface? The aim was to quantify the RCOF in children with bilateral spastic cerebral palsy (BSCP) and crouch gait.
Methods:
11 children with crouch gait and 11 healthy age-matched children were instructed to walk barefoot at self-selected speed over a force platform. The RCOF curve was obtained as the ratio between the tangential forces (FT), and the vertical ground reaction force (FZ). Three points were extracted by the RCOF, FT and FZ curves at the loading response, midstance and push-off phases.
Findings:
Children with BSCP presented higher values of RCOF in all support phase and lower gait velocity relative to the healthy controls. For BSCP group no correlation between FT and FZ were found, indicating that this group is not able to negotiate the forces during the support phase.
Interpretation:
Children with BSCP and crouch gait are not able to negotiate the forces applied on the ground in support phase, so to avoid the fall, their strategy is to reduce the gait velocity.
More Related Videos
 08:24
Author Spotlight: Exploring the Potential of Massage Therapy in Cerebral Palsy Using Animal Models
Published on: August 11, 2023
 08:26
Event-related Potentials During Target-response Tasks to Study Cognitive Processes of Upper Limb Use in Children with Unilateral Cerebral Palsy
Published on: January 11, 2016
Related Concept Videos
 01:09
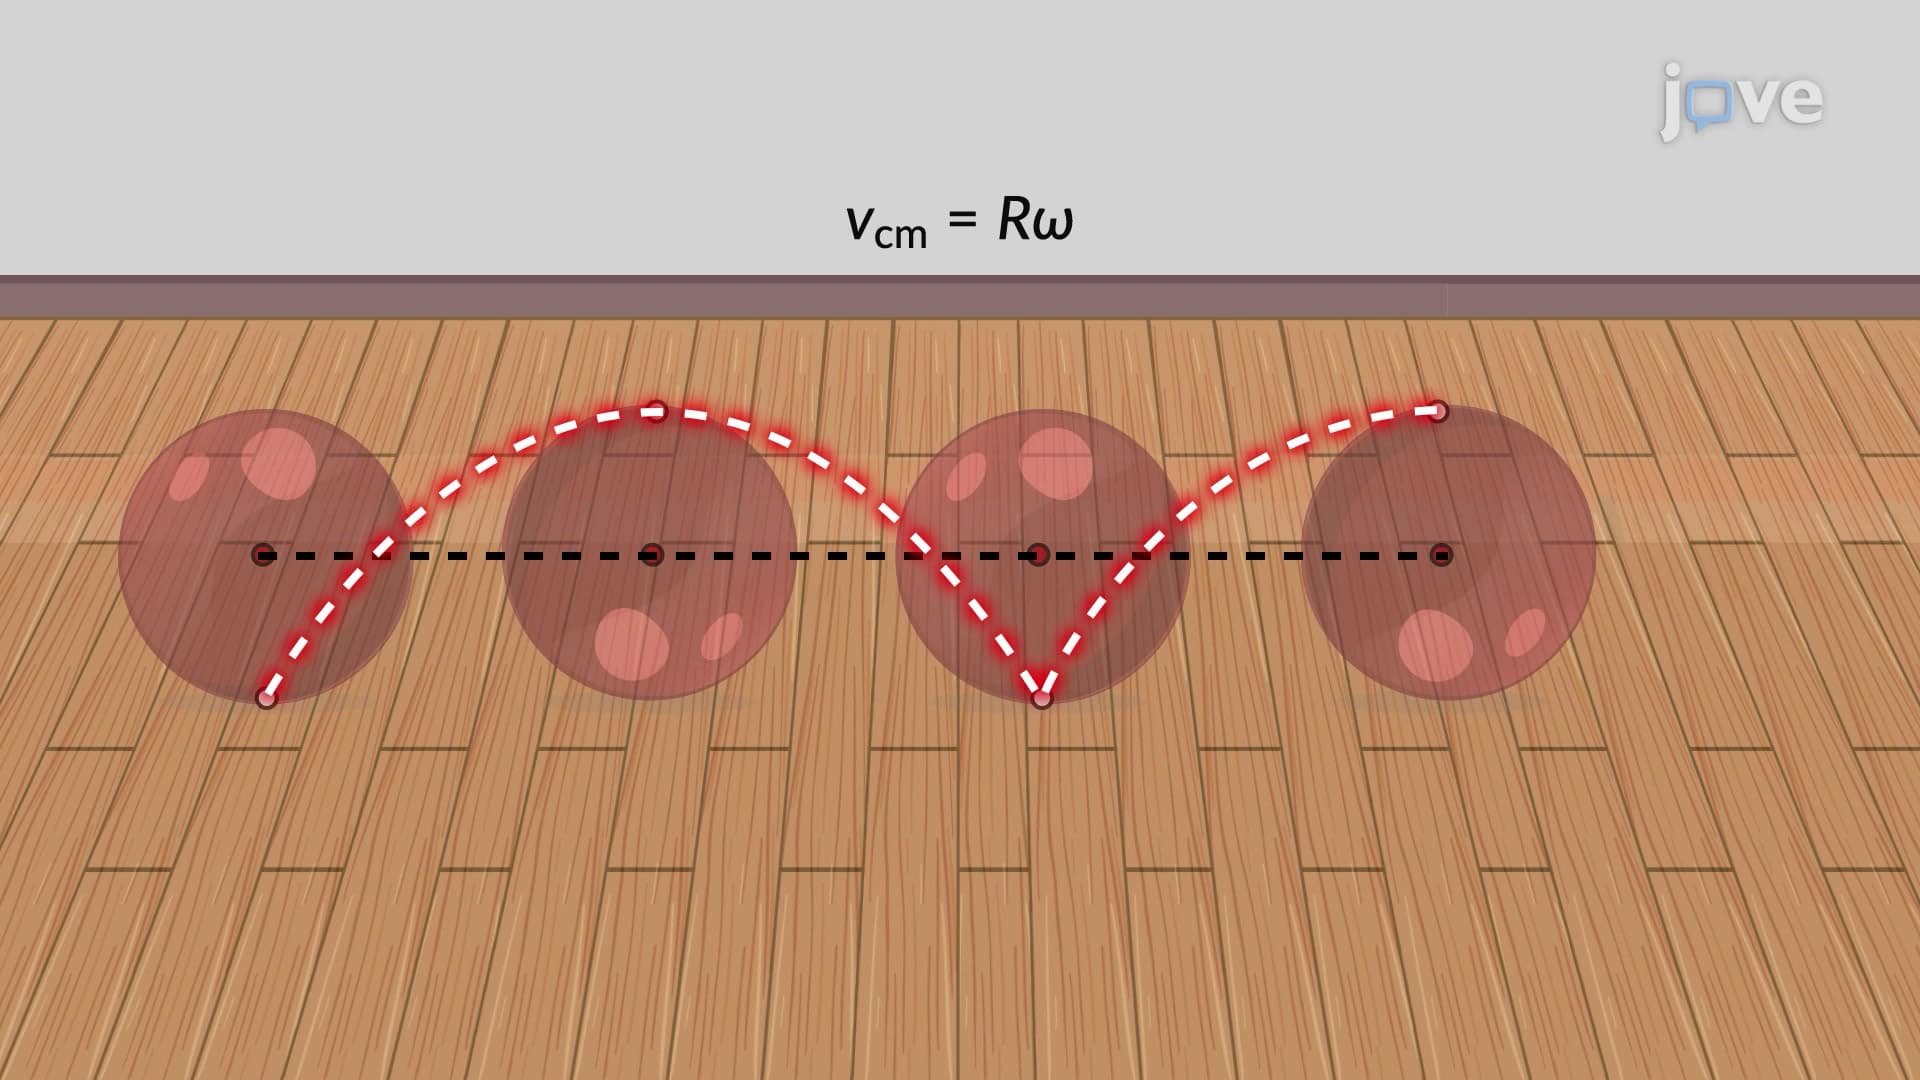
Rolling Without Slipping
 01:14
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance
 01:26
Personality Disorders: Narcissistic and Avoidant
Characteristics of Narcissistic Personality Disorder
Narcissistic individuals exhibit an inflated sense of self-importance and an excessive need for admiration. They are often...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:29
Drug Dosing: Infants and Children