Related Experiment Video
Updated: Feb 11, 2026
Identifying PD-1/PD-L1 Inhibitors with Surface Plasmon Resonance Technology
Published on: May 2, 2025
Statistical Optimization of 1,3-Propanediol (1,3-PD) Production from Crude Glycerol by Considering Four Objectives:
Pansuwan Supaporn1, Sung Ho Yeom2
1Department of Biochemical Engineering, Gangneung-Wonju National University, Gangneung, 25457, Republic of Korea.

Abstract:
This study investigated the biological conversion of crude glycerol generated from a commercial biodiesel production plant as a by-product to 1,3-propanediol (1,3-PD). Statistical analysis was employed to derive a statistical model for the individual and interactive effects of glycerol, (NH4)2SO4, trace elements, pH, and cultivation time on the four objectives: 1,3-PD concentration, yield, selectivity, and productivity. Optimum conditions for each objective with its maximum value were predicted by statistical optimization, and experiments under the optimum conditions verified the predictions. In addition, by systematic analysis of the values of four objectives, optimum conditions for 1,3-PD concentration (49.8 g/L initial glycerol, 4.0 g/L of (NH4)2SO4, 2.0 mL/L of trace element, pH 7.5, and 11.2 h of cultivation time) were determined to be the global optimum culture conditions for 1,3-PD production. Under these conditions, we could achieve high 1,3-PD yield (47.4%), 1,3-PD selectivity (88.8%), and 1,3-PD productivity (2.1/g/L/h) as well as high 1,3-PD concentration (23.6 g/L).
More Related Videos
 07:43
Using 22C3 Anti-PD-L1 Antibody Concentrate on Biopsy and Cytology Samples from Non-small Cell Lung Cancer Patients
Published on: September 25, 2018
 03:59
Production and Optimization of LTE, a Leishmania tarentolae Derived Cell-Free Protein Expression System for Recombinant Protein Production
Published on: November 8, 2024
Related Concept Videos
 01:24
π Molecular Orbitals of 1,3-Butadiene
The simplest conjugated diene is 1,3-butadiene: a four-carbon system where each carbon is sp2-hybridized and has an unhybridized p orbital that contains an unpaired electron. According to molecular orbital theory, atomic orbitals combine to form molecular orbitals such that the number...
 01:17
Electrophilic 1,2- and 1,4-Addition of HX to 1,3-Butadiene
 01:14
Electrophilic 1,2- and 1,4-Addition of X2 to 1,3-Butadiene
 01:23
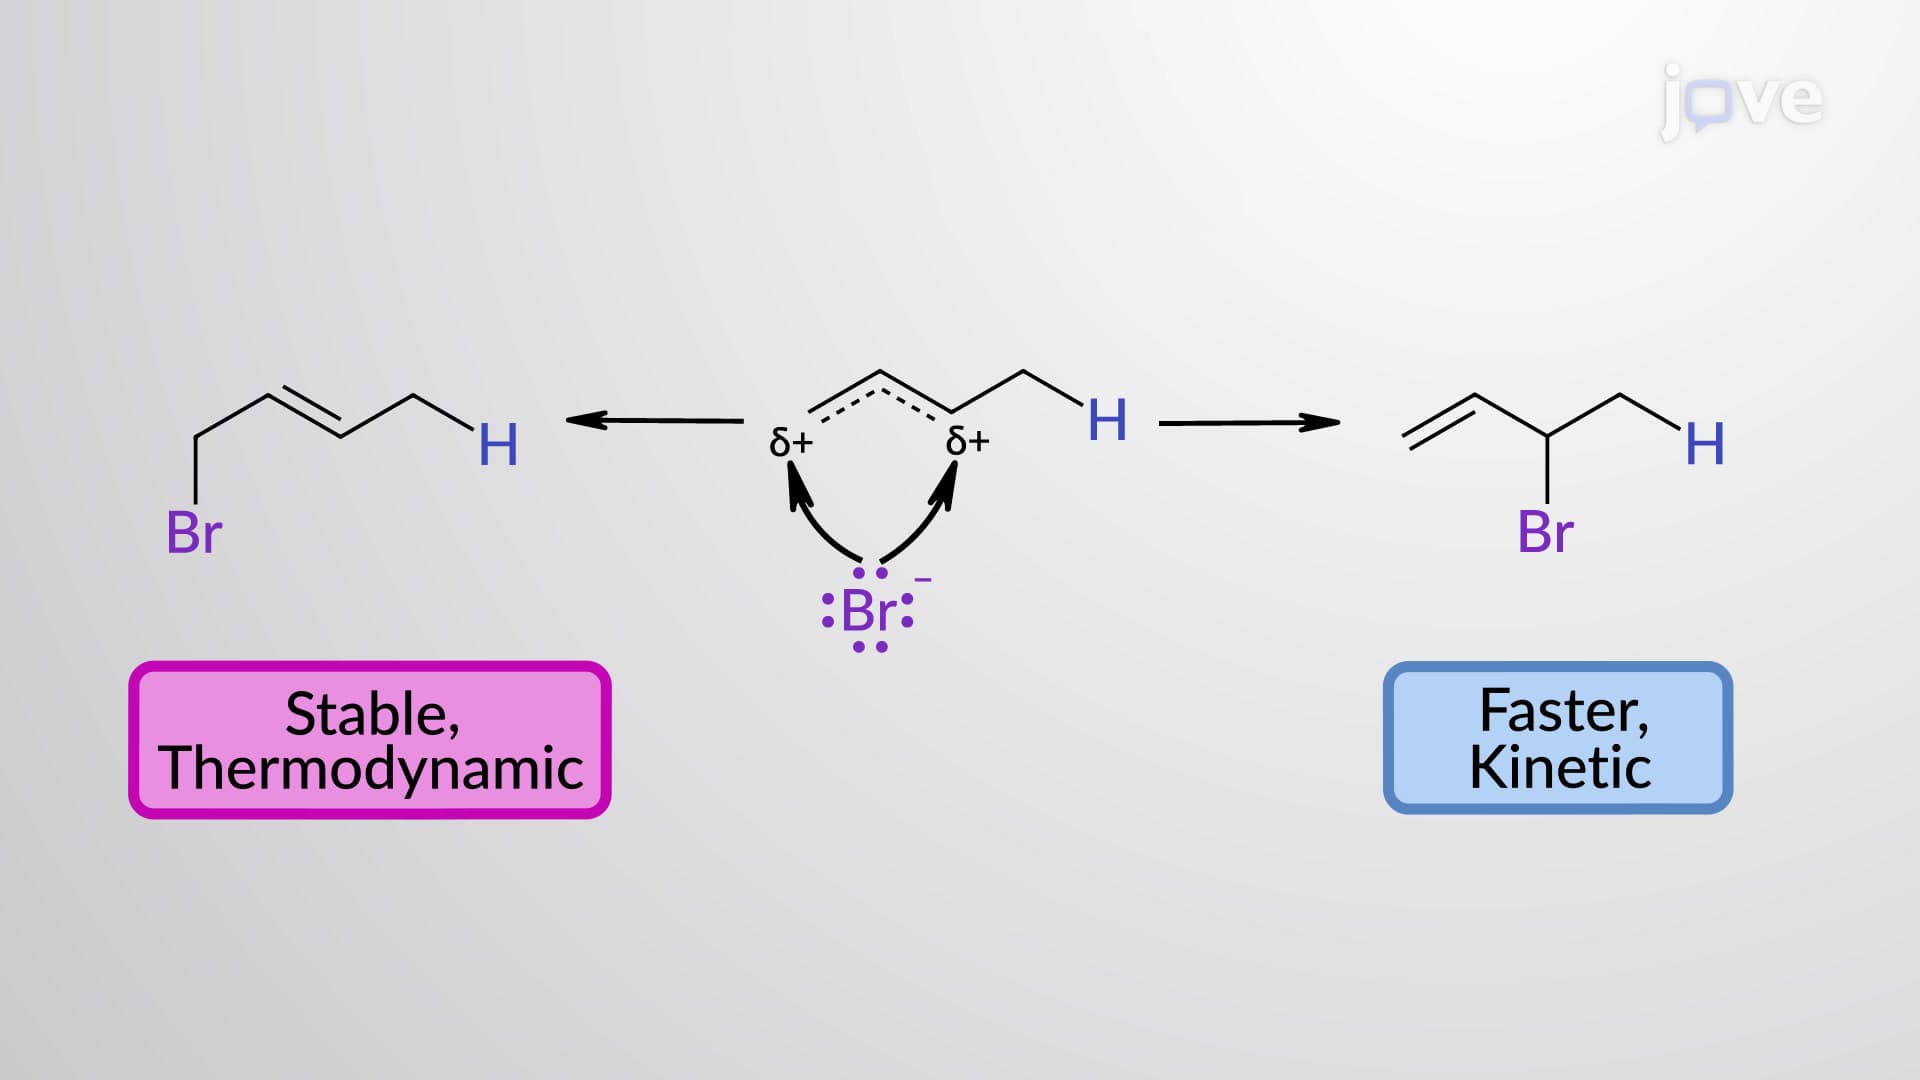
Electrophilic Addition of HX to 1,3-Butadiene: Thermodynamic vs Kinetic Control
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...