Related Experiment Video
Updated: Feb 10, 2026
Using Generative Art to Convey Past and Future Climate Transitions
Published on: March 31, 2023
Towards Optimal Platform-Based Robot Design for Ankle Rehabilitation: The State of the Art and Future Prospects
Qing Miao1, Mingming Zhang2,3, Congzhe Wang4
1School of Mechanical and Electrical Engineering, Wuhan University of Technology, Wuhan, China.

Abstract:
This review aims to compare existing robot-assisted ankle rehabilitation techniques in terms of robot design. Included studies mainly consist of selected papers in two published reviews involving a variety of robot-assisted ankle rehabilitation techniques. A free search was also made in Google Scholar and Scopus by using keywords "ankle∗," and "robot∗," and ("rehabilitat∗" or "treat∗"). The search is limited to English-language articles published between January 1980 and September 2016. Results show that existing robot-assisted ankle rehabilitation techniques can be classified into wearable exoskeleton and platform-based devices. Platform-based devices are mostly developed for the treatment of a variety of ankle musculoskeletal and neurological injuries, while wearable ones focus more on ankle-related gait training. In terms of robot design, comparative analysis indicates that an ideal ankle rehabilitation robot should have aligned rotation center as the ankle joint, appropriate workspace, and actuation torque, no matter how many degrees of freedom (DOFs) it has. Single-DOF ankle robots are mostly developed for specific applications, while multi-DOF devices are more suitable for comprehensive ankle rehabilitation exercises. Other factors including posture adjustability and sensing functions should also be considered to promote related clinical applications. An ankle rehabilitation robot with reconfigurability to maximize its functions will be a new research point towards optimal design, especially on parallel mechanisms.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 04:24
A Novel Digital Platform for a Monitored Home-based Cardiac Rehabilitation Program
Published on: April 19, 2019
Related Concept Videos
 01:10
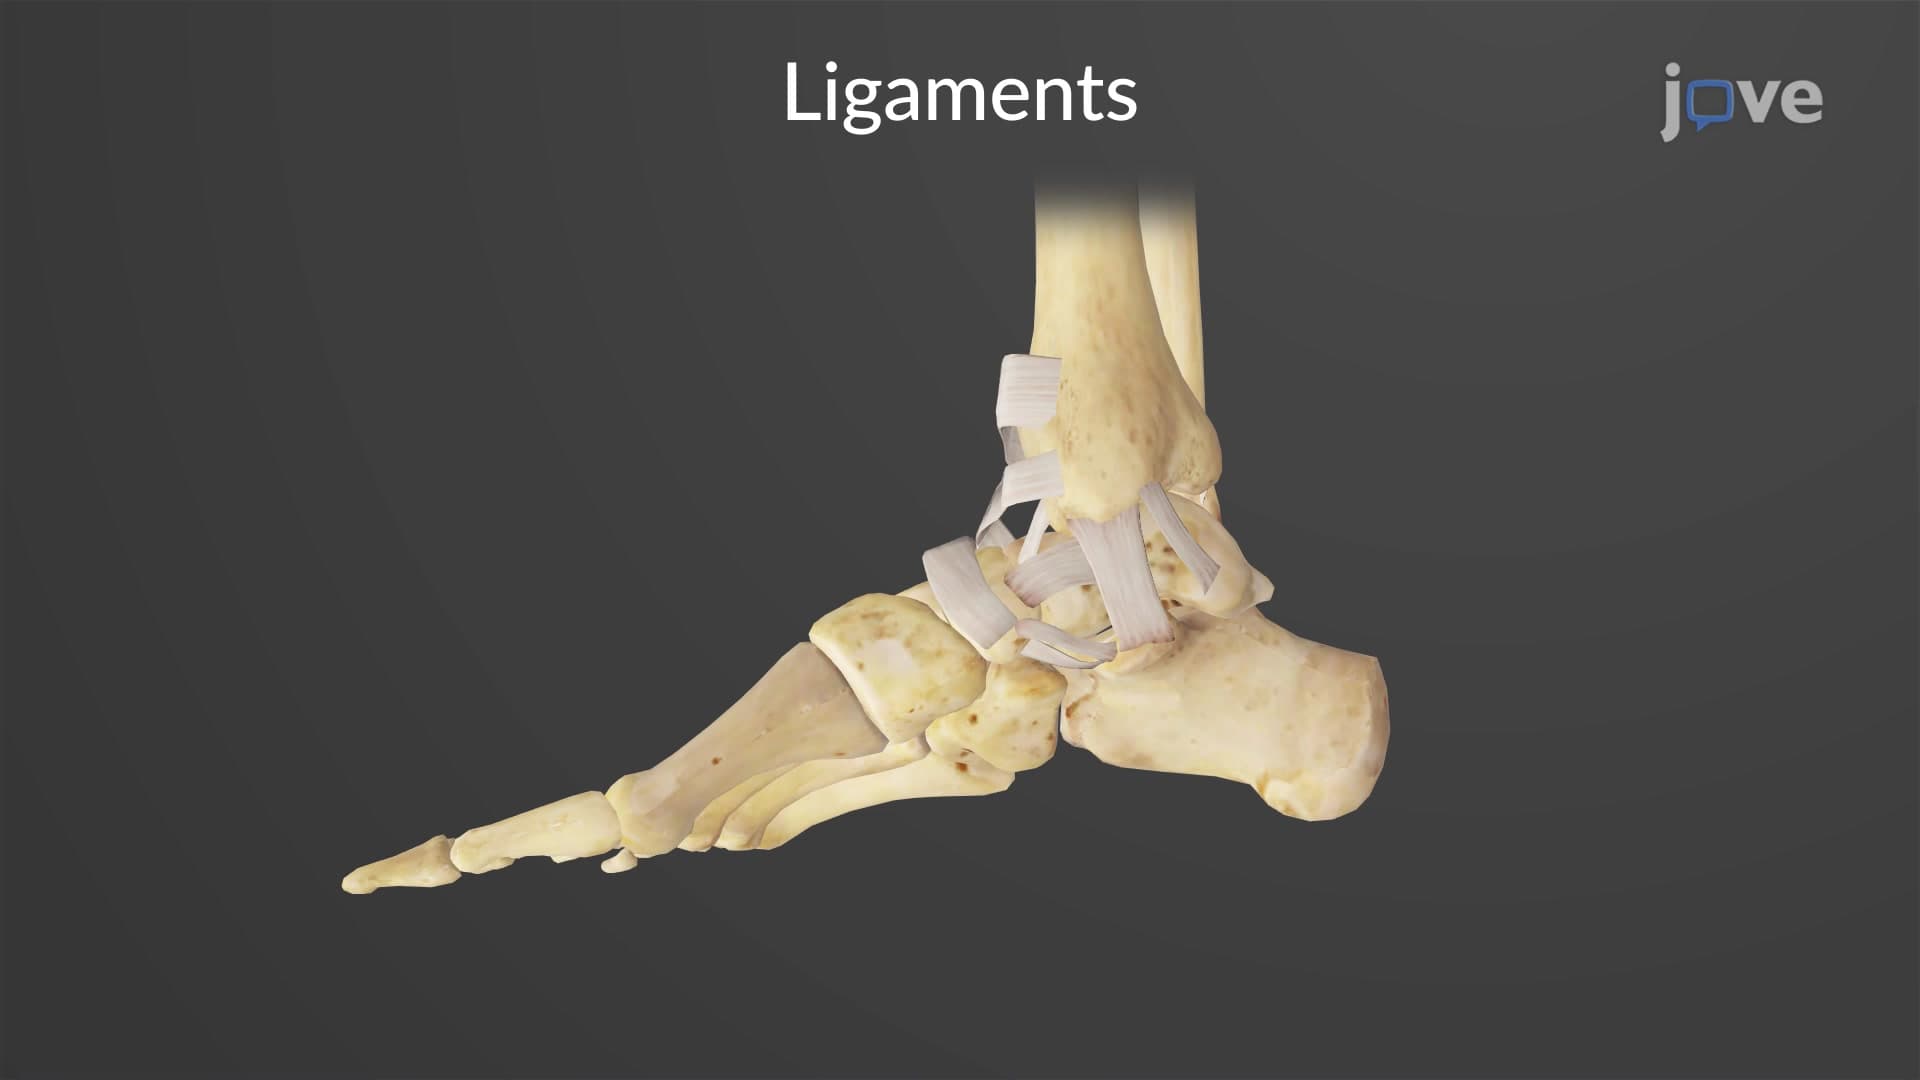
Ankle Joint
 02:01
Group Design
 00:48
Optimal Foraging
 02:01
Factorial Design
 01:26
Optimization Problems
 01:25
Design Example: Designing a Residential Plumbing System