Related Experiment Video
Updated: Feb 10, 2026

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
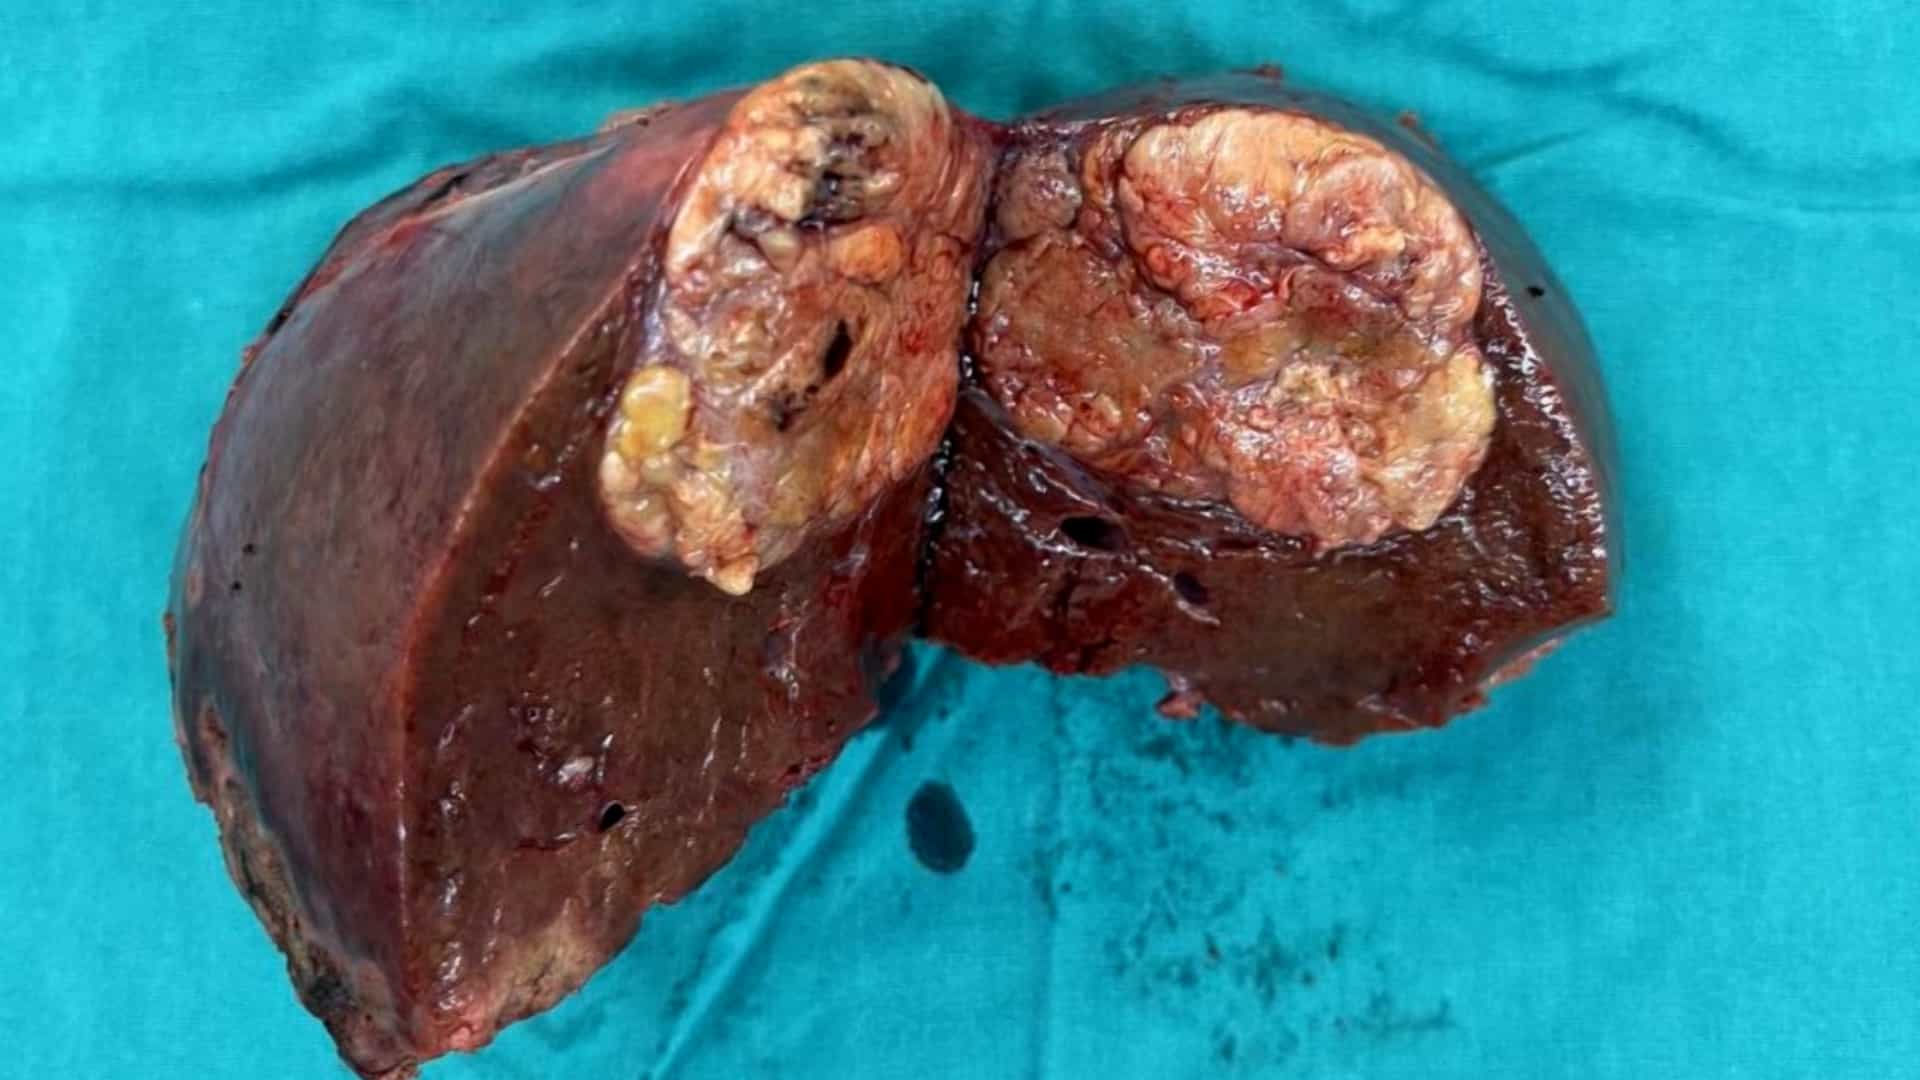
Global rigid registration of CT to video in laparoscopic liver surgery
Maria R Robu1,2, João Ramalhinho3,4, Stephen Thompson3,4
1Wellcome/EPSRC Centre for Interventional and Surgical Sciences, University College London, London, UK. maria.robu.14@ucl.ac.uk.

Purpose:
Image-guidance systems have the potential to aid in laparoscopic interventions by providing sub-surface structure information and tumour localisation. The registration of a preoperative 3D image with the intraoperative laparoscopic video feed is an important component of image guidance, which should be fast, robust and cause minimal disruption to the surgical procedure. Most methods for rigid and non-rigid registration require a good initial alignment. However, in most research systems for abdominal surgery, the user has to manually rotate and translate the models, which is usually difficult to perform quickly and intuitively.
Methods:
We propose a fast, global method for the initial rigid alignment between a 3D mesh derived from a preoperative CT of the liver and a surface reconstruction of the intraoperative scene. We formulate the shape matching problem as a quadratic assignment problem which minimises the dissimilarity between feature descriptors while enforcing geometrical consistency between all the feature points. We incorporate a novel constraint based on the liver contours which deals specifically with the challenges introduced by laparoscopic data.
Results:
We validate our proposed method on synthetic data, on a liver phantom and on retrospective clinical data acquired during a laparoscopic liver resection. We show robustness over reduced partial size and increasing levels of deformation. Our results on the phantom and on the real data show good initial alignment, which can successfully converge to the correct position using fine alignment techniques. Furthermore, since we can pre-process the CT scan before surgery, the proposed method runs faster than current algorithms.
Conclusion:
The proposed shape matching method can provide a fast, global initial registration, which can be further refined by fine alignment methods. This approach will lead to a more usable and intuitive image-guidance system for laparoscopic liver surgery.
Related Concept Videos
 01:50
Global Climate Change
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:11
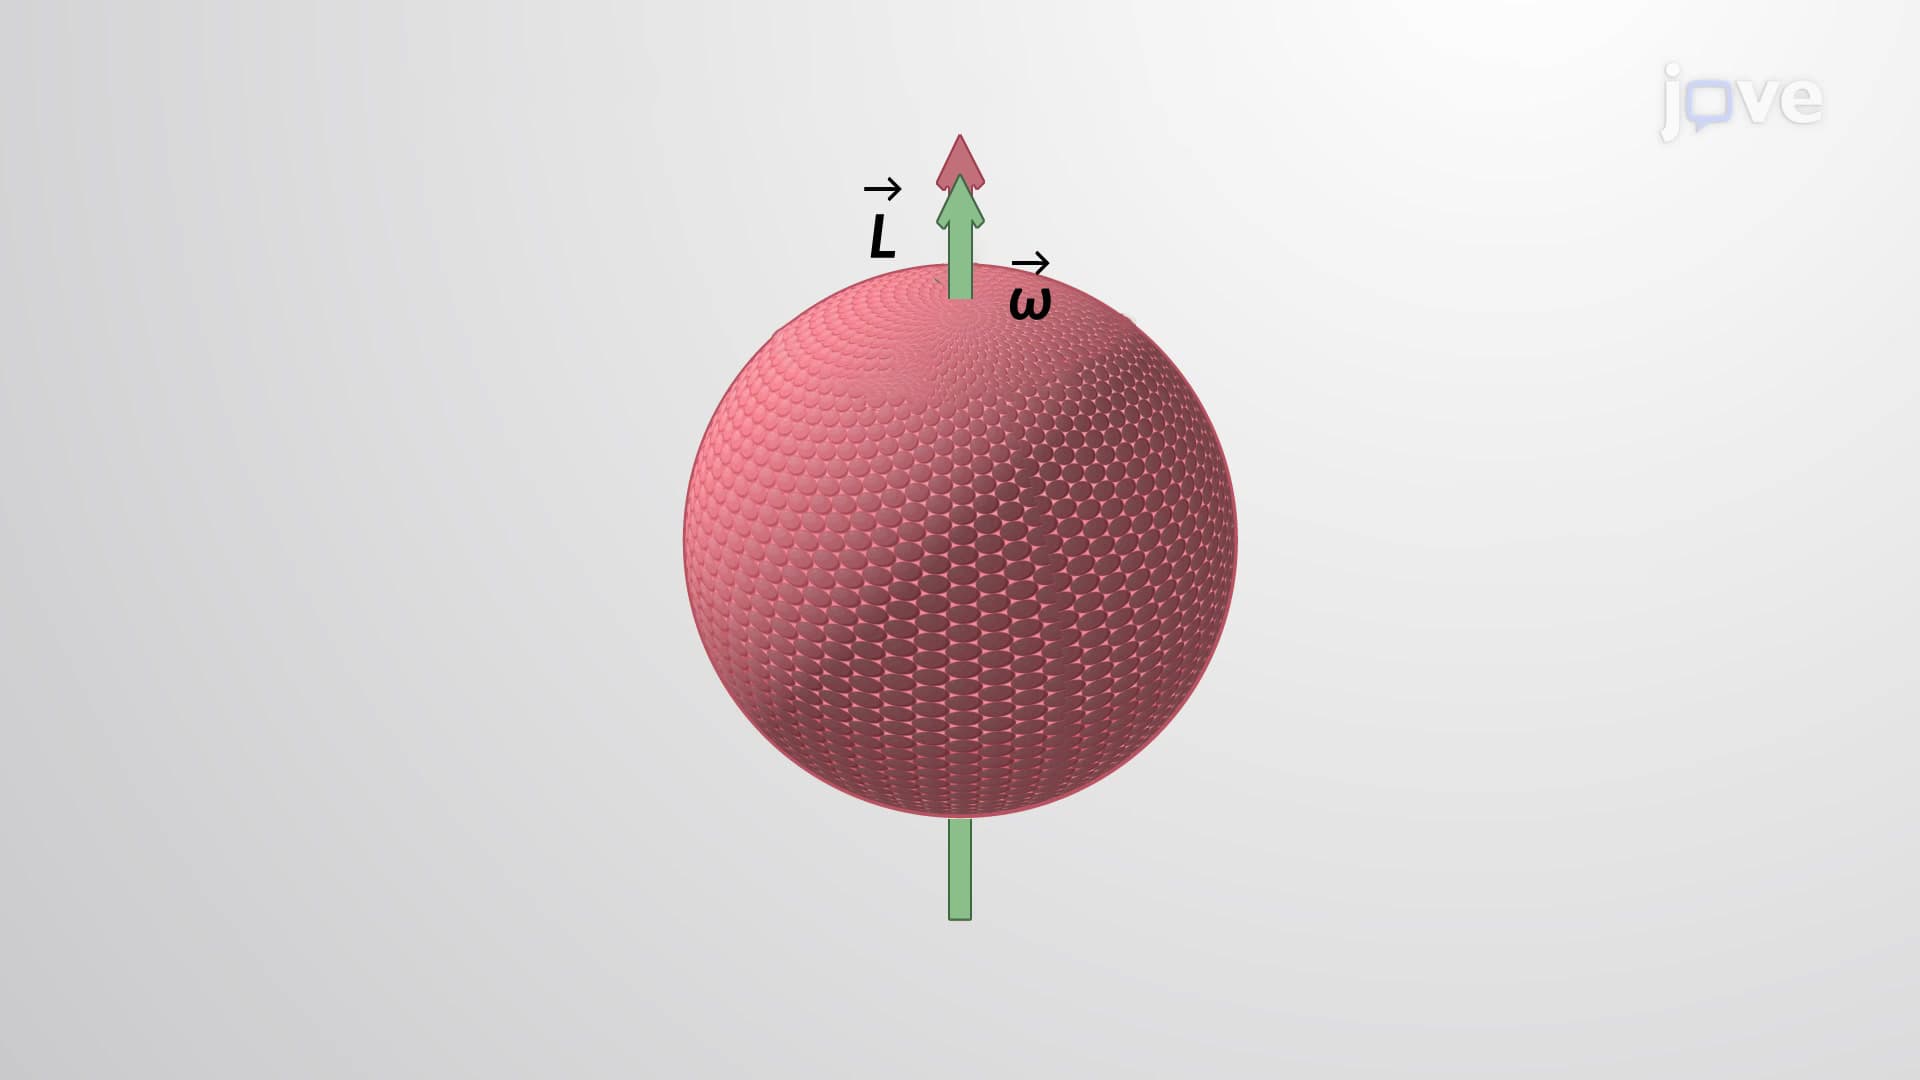
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:13
Kinetic Energy for a Rigid Body