Related Experiment Video
Updated: Feb 9, 2026
A Label-free Technique for the Spatio-temporal Imaging of Single Cell Secretions
Published on: November 23, 2015
Spatio-Temporal Field Estimation Using Kriged Kalman Filter (KKF) with Sparsity-Enforcing Sensor Placement
Venkat Roy1, Andrea Simonetto2, Geert Leus3
1NXP Semiconductors, High Tech Campus 46, 5656 AE Eindhoven, The Netherlands. venkat.roy@nxp.com.

Abstract:
We propose a sensor placement method for spatio-temporal field estimation based on a kriged Kalman filter (KKF) using a network of static or mobile sensors. The developed framework dynamically designs the optimal constellation to place the sensors. We combine the estimation error (for the stationary as well as non-stationary component of the field) minimization problem with a sparsity-enforcing penalty to design the optimal sensor constellation in an economic manner. The developed sensor placement method can be directly used for a general class of covariance matrices (ill-conditioned or well-conditioned) modelling the spatial variability of the stationary component of the field, which acts as a correlated observation noise, while estimating the non-stationary component of the field. Finally, a KKF estimator is used to estimate the field using the measurements from the selected sensing locations. Numerical results are provided to exhibit the feasibility of the proposed dynamic sensor placement followed by the KKF estimation method.
More Related Videos
 09:34
Applications of Spatio-temporal Mapping and Particle Analysis Techniques to Quantify Intracellular Ca2+ Signaling In Situ
Published on: January 7, 2019
 10:27
Spatio-Temporal Manipulation of Small GTPase Activity at Subcellular Level and on Timescale of Seconds in Living Cells
Published on: March 9, 2012
Related Concept Videos
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:25
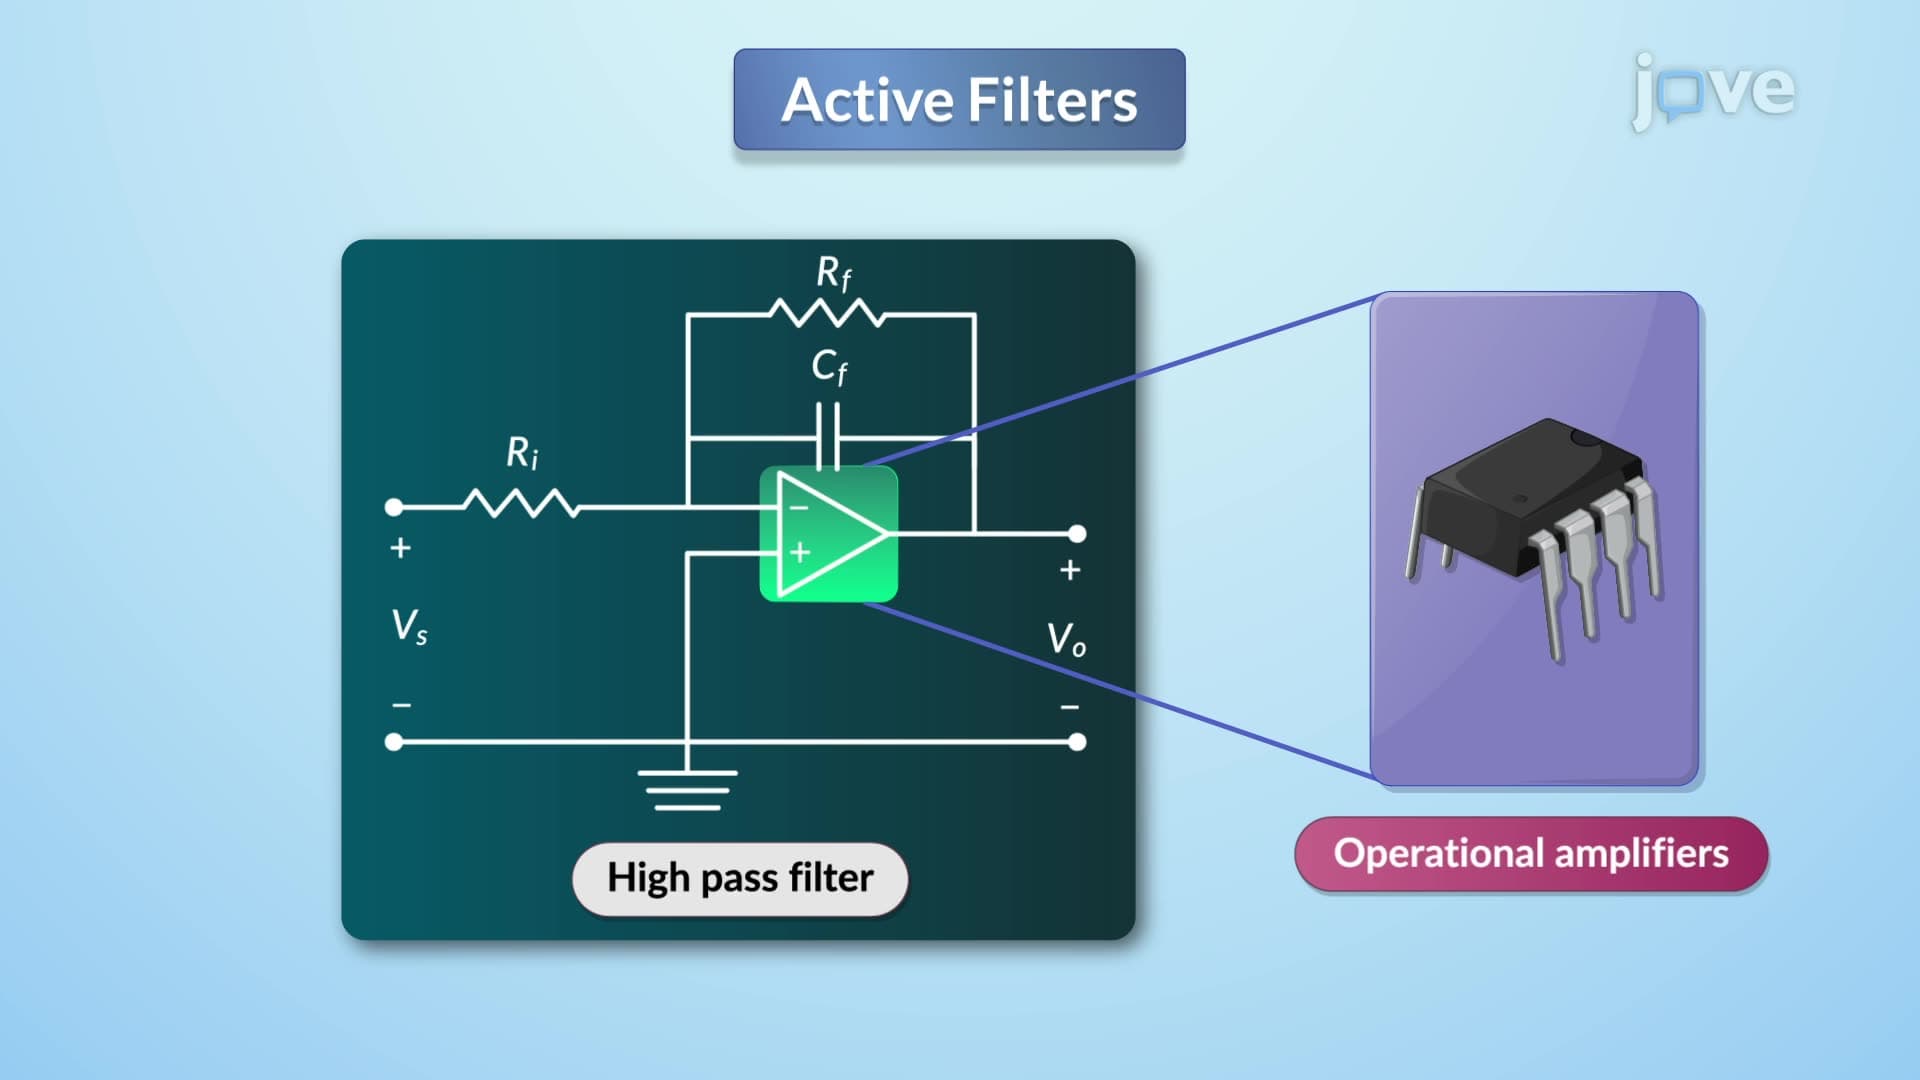
Active Filters
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:20
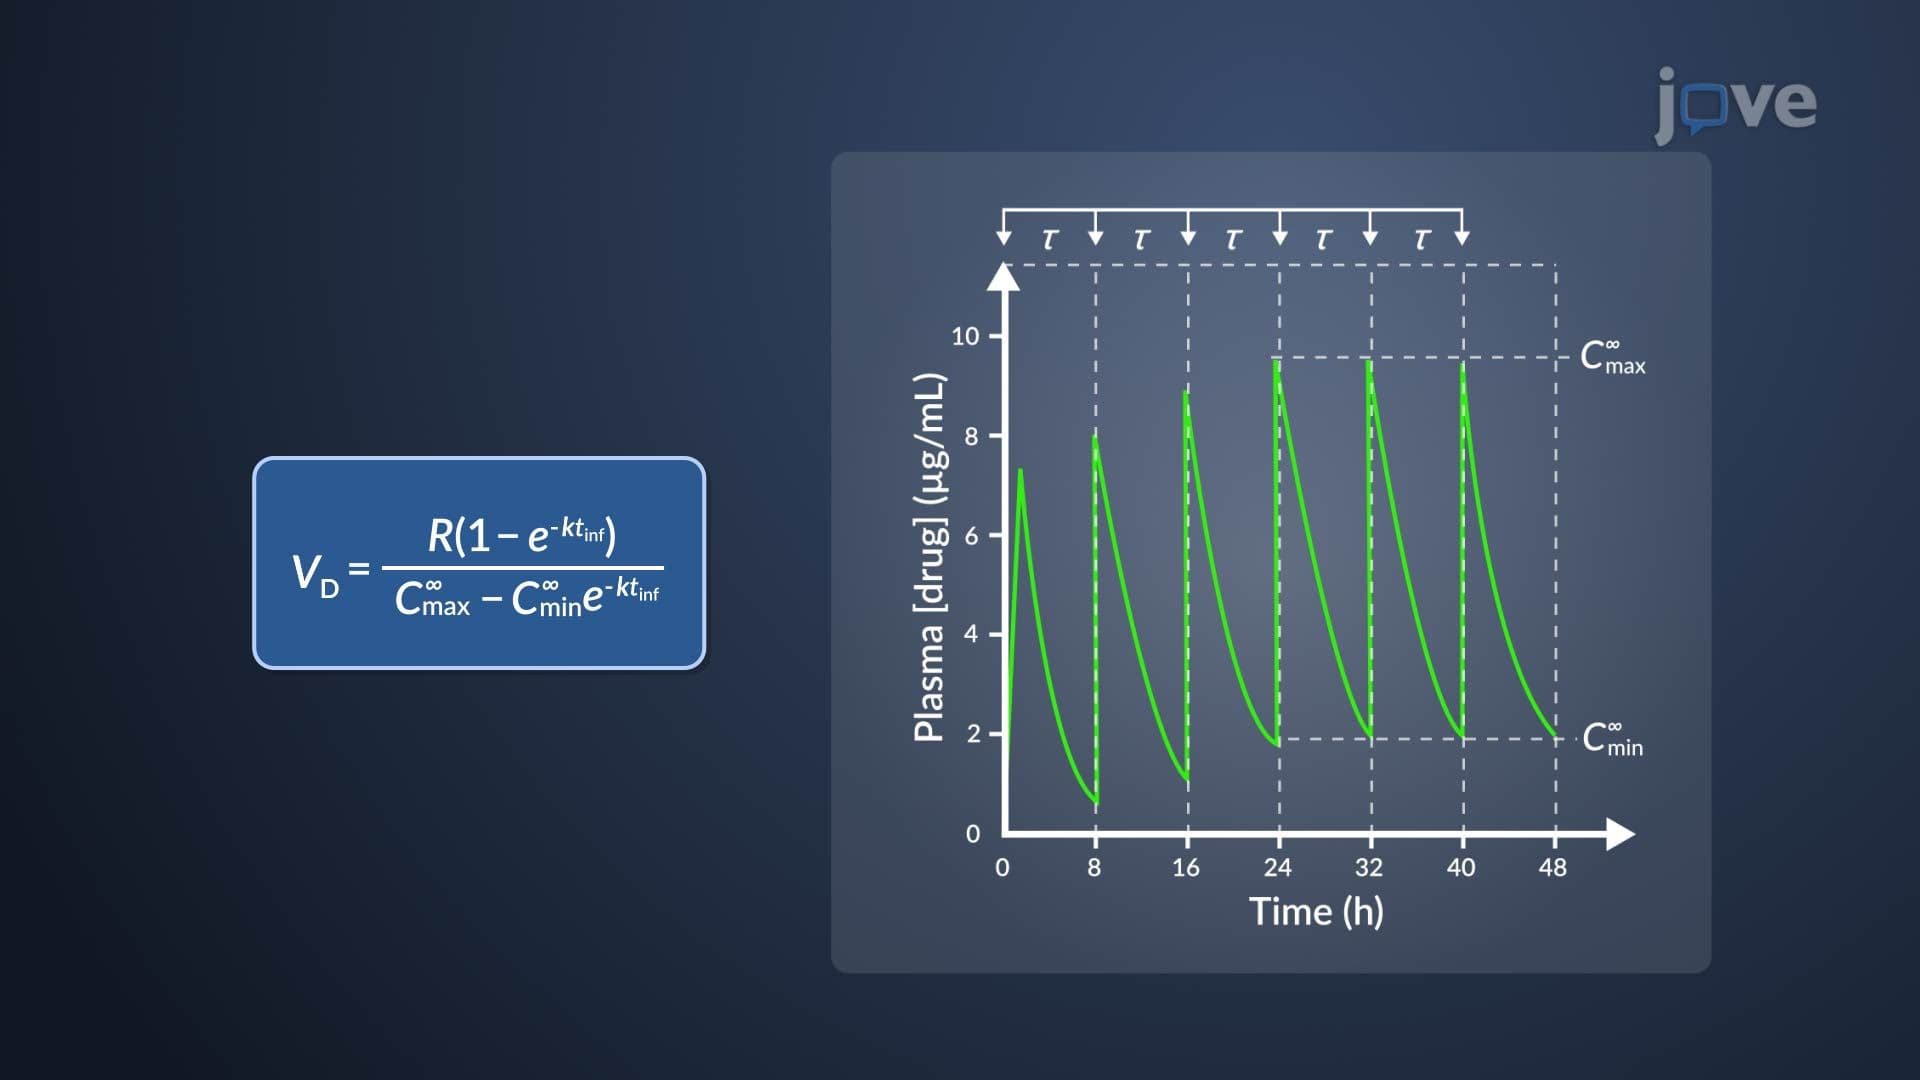
Estimation of k and VD of Aminoglycosides
 01:05
Estimation of the Physical Quantities
 01:10
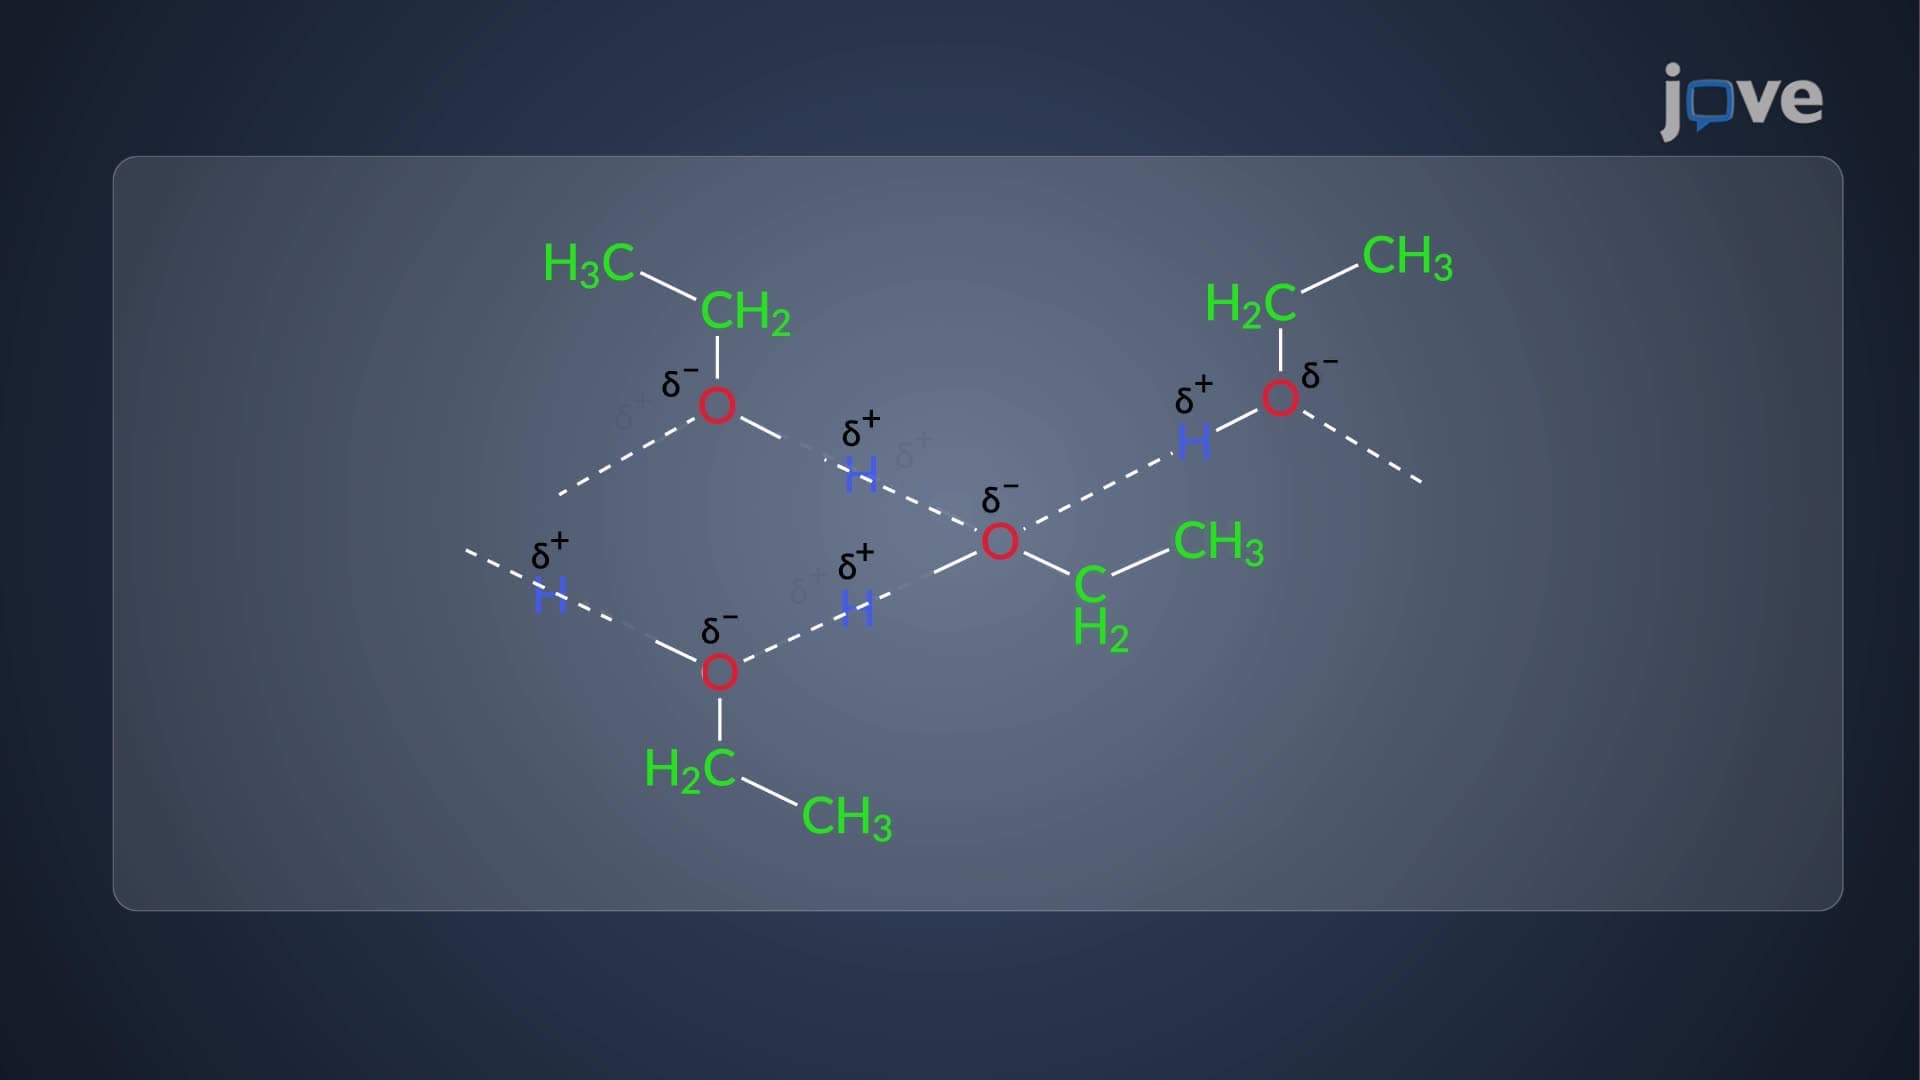
¹H NMR of Labile Protons: Temporal Resolution
The –OH proton in alcohols typically appears in the range of δ 2 to 5 ppm but can vary depending on the specific...