
Space Subdivision in Indoor Mobile Laser Scanning Point Clouds Based on Scanline Analysis
Yi Zheng1,2, Michael Peter3, Ruofei Zhong4
1Beijing Advanced Innovation Center for Imaging Technology, College of Resource Environment and Tourism, Capital Normal University, Beijing 100048, China. 2150902027@cnu.edu.cn.

Abstract:
Indoor space subdivision is an important aspect of scene analysis that provides essential information for many applications, such as indoor navigation and evacuation route planning. Until now, most proposed scene understanding algorithms have been based on whole point clouds, which has led to complicated operations, high computational loads and low processing speed. This paper presents novel methods to efficiently extract the location of openings (e.g., doors and windows) and to subdivide space by analyzing scanlines. An opening detection method is demonstrated that analyses the local geometric regularity in scanlines to refine the extracted opening. Moreover, a space subdivision method based on the extracted openings and the scanning system trajectory is described. Finally, the opening detection and space subdivision results are saved as point cloud labels which will be used for further investigations. The method has been tested on a real dataset collected by ZEB-REVO. The experimental results validate the completeness and correctness of the proposed method for different indoor environment and scanning paths.
More Related Videos
 07:35
Laser Microdissection-Based Protocol for the LC-MS/MS Analysis of the Proteomic Profile of Neuromelanin Granules
Published on: December 16, 2021
 15:01
Confocal Laser Scanning Microscopy-Based Quantitative Analysis of Aspergillus fumigatus Conidia Distribution in Whole-Mount Optically Cleared Mouse Lung
Published on: September 18, 2021
Related Concept Videos
 02:28
Leaky Scanning
 01:25
Space Trusses
At the core of a space truss lies the fundamental unit known as the tetrahedron. This structure is composed of six members that form a three-dimensional shape...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:23
Transfer Function to State Space
In an RLC...
 01:21
State Space to Transfer Function
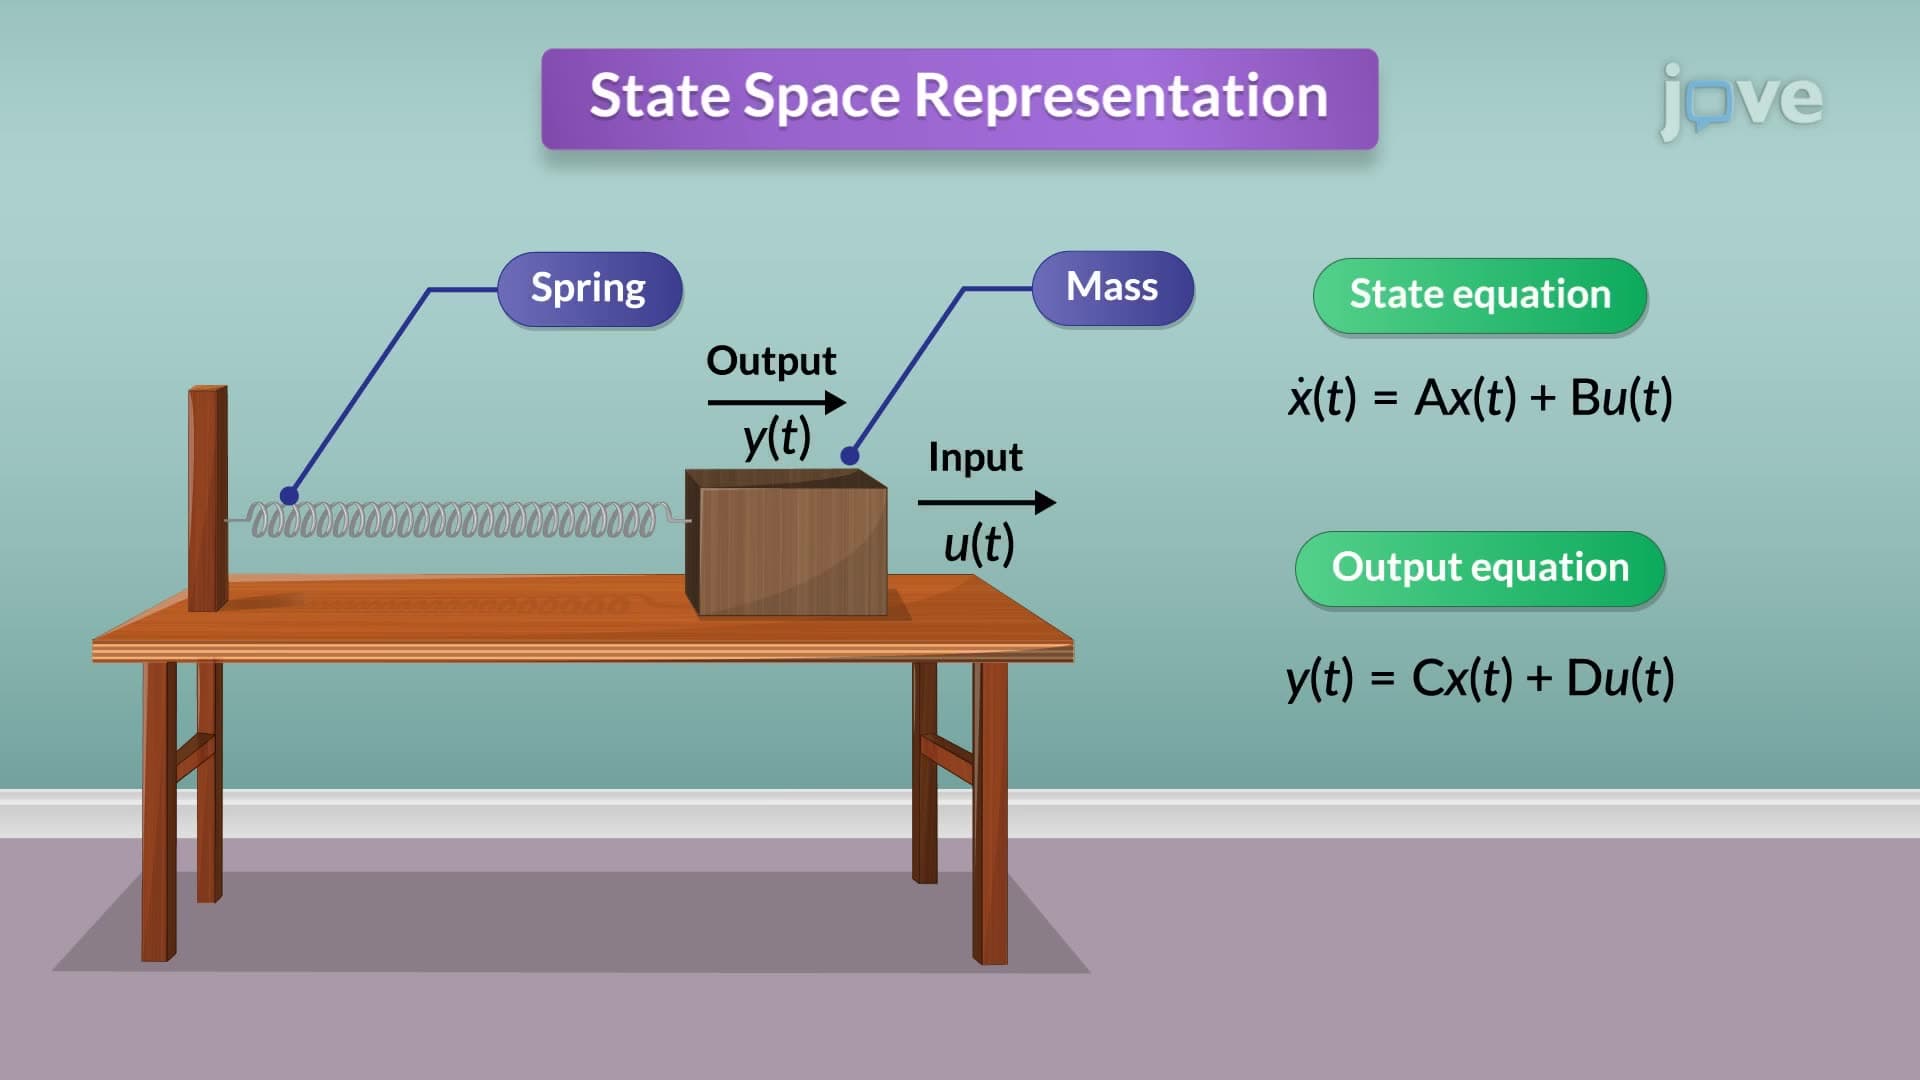
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: