Related Experiment Video
Updated: Feb 8, 2026

Rapid Manufacturing of Thin Soft Pneumatic Actuators and Robots
Published on: November 8, 2019
Precharged Pneumatic Soft Actuators and Their Applications to Untethered Soft Robots
Yunquan Li1, Yonghua Chen1, Tao Ren2
11 Department of Mechanical Engineering, The University of Hong Kong , Pokfulam Road, Hong Kong .

Abstract:
The past decade has witnessed tremendous progress in soft robotics. Unlike most pneumatic-based methods, we present a new approach to soft robot design based on precharged pneumatics (PCP). We propose a PCP soft bending actuator, which is actuated by precharged air pressure and retracted by inextensible tendons. By pulling or releasing the tendons, the air pressure in the soft actuator is modulated, and hence, its bending angle. The tendons serve in a way similar to pressure-regulating valves that are used in typical pneumatic systems. The linear motion of tendons is transduced into complex motion via the prepressurized bent soft actuator. Furthermore, since a PCP actuator does not need any gas supply, complicated pneumatic control systems used in traditional soft robotics are eliminated. This facilitates the development of compact untethered autonomous soft robots for various applications. Both theoretical modeling and experimental validation have been conducted on a sample PCP soft actuator design. A fully untethered autonomous quadrupedal soft robot and a soft gripper have been developed to demonstrate the superiority of the proposed approach over traditional pneumatic-driven soft robots.


Related Concept Videos
 01:14
Photoluminescence: Applications
 01:17
Radiation: Applications
The average...
 01:28
Applications of Logarithms
 01:04
Applications of Stress
The...
 01:22
Applications of RC Circuits
 01:17
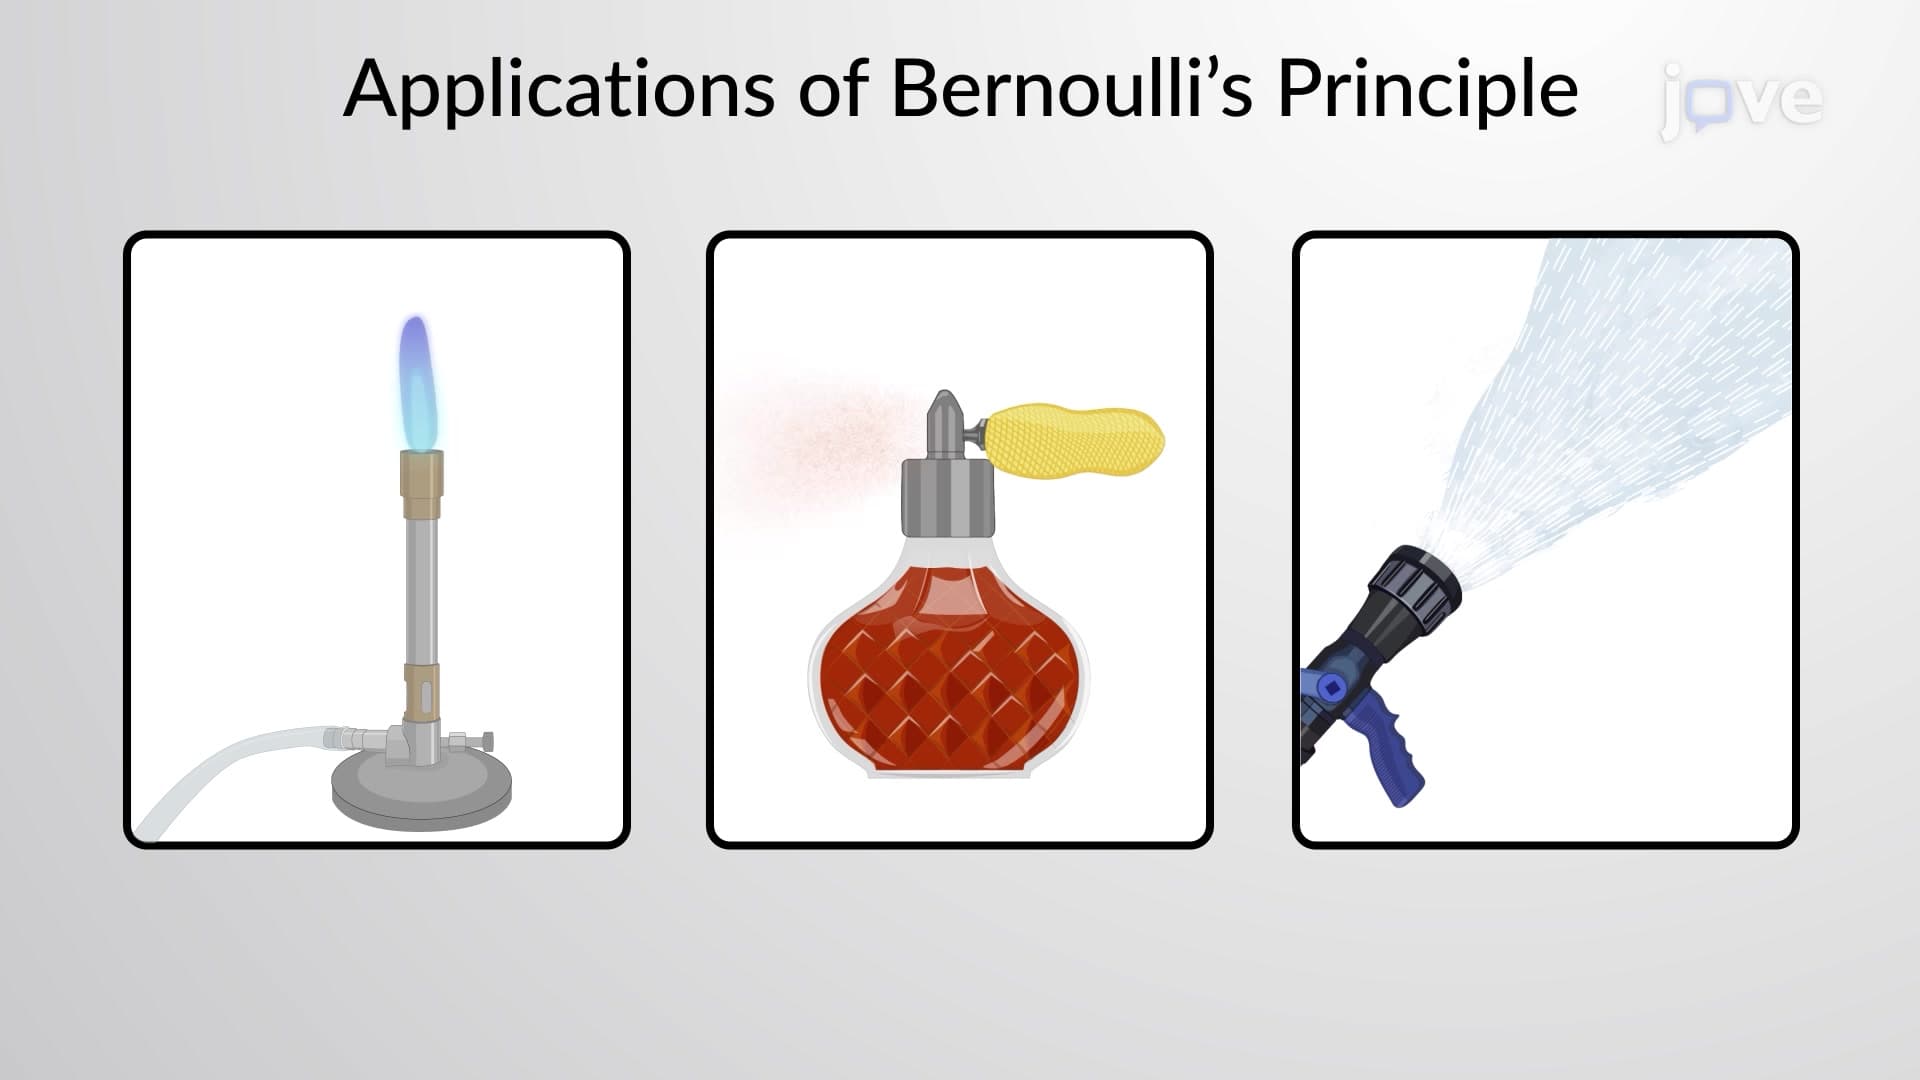
Bernoulli's Principle: Applications
Entrainment devices use a high fluid speed to create low pressures and, thus, entrain one fluid into another. Some examples of these devices are given below: