Related Experiment Video
Updated: Feb 8, 2026
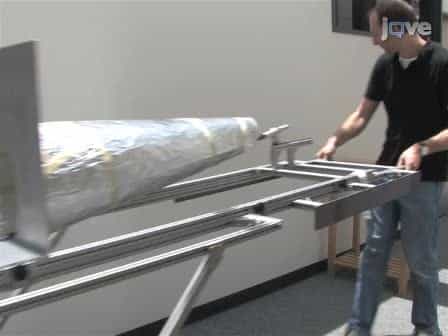

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Shape Localization and Recognition Using a Magnetorheological-Fluid Haptic Display

Abstract:
Smart materials such as magnetorheological fluids (MRF) offer an interesting technology for use in haptic displays as changes in the magnetic field are rapid, reversible, and controllable. These interfaces have been evaluated in a number of medical and surgical simulators where they can provide cues regarding the viscoelastic properties of tissues. The objective of the present set of experiments was first to determine whether a shape embedded in the MRF could be precisely localized and second whether 10 shapes rendered in a MRF haptic display could be accurately identified. It was also of interest to determine how the information transfer associated with this type of haptic display compares to that achieved using other haptic channels of communication. The overall performance of participants at identifying the shapes rendered in the MRF was good with a mean score of 73 percent correct and an Information Transfer (IT) of 2.2 bits. Participants could also localize a rigid object in the display accurately. These findings indicate that this technology has potential for use in training manual palpation skills and in exploring haptic shape perception in dynamic environments.
More Related Videos

Related Concept Videos
 03:37
Molecular Shape and Polarity
 02:52
VSEPR Theory and the Basic Shapes
 01:18
Molecular Shapes
Two regions of electron density in a diatomic...
 01:22
First Derivatives and the Shape of a Graph
 01:29
Second Derivatives and the Shape of a Graph
 01:34
The Fluid Mosaic Model