Related Experiment Video
Updated: Feb 8, 2026

Dynamic Navigation in Endodontics: Guided Access Cavity Preparation by Means of a Miniaturized Navigation System
Published on: May 5, 2022
Real-time dynamic torque values and axial forces during preparation of straight root canals using three different
S Bürklein1, J P Stüber1, E Schäfer1
1Central Interdisciplinary Ambulance in the School of Dentistry, University of Münster, Münster, Germany.

Aim:
To assess the real-time dynamic torque values and axial forces during preparation of straight root canals using three different endodontic motors and hand preparation.
Methodology:
Sixty maxillary incisors were divided into four homogeneous groups (n = 15). After glide path establishment (size 20) the root canals were prepared to an apical size 40 using the rotary NiTi system F6 SkyTaper. Motors (DentaPort ZX OTR, EndoPilot and VDW.silver) were set to 'auto-torque-reverse' mode and DentaPort ZX was set to its specific OTR mode (optimum torque reverse). One group served as a control using manual balanced-force canal preparation with K-Flexofiles. Teeth were embedded in resin and fixed in a multi-component sensor measuring axial and torsional load during active instrumentation with 50 Hz. Preparation time was also recorded. Data were statistically analysed using the Kruskal-Wallis test.
Results:
The maximum axial forces (peak) and both peaks of dynamic clockwise and counter-clockwise torque did not differ significantly when using the three different motors despite different gear ratios and pre-settings. Only the VDW.silver motor exceeded the torque values during the use of 30 instruments (3.3%). The Morita OTR motor exceeded the maximum intrinsic torque set at 1.0 Ncm in approximately 53% of cases. The larger tapered F6 SkyTaper instruments (size 20, .06 taper and size 30, .06 taper) created significantly higher torque values (P < 0.0001). Manual instrumentation created significantly lower torque levels and higher axial values compared to rotary instrumentation (P < 0.0001) and was significantly more time consuming (P < 0.0001).
Conclusions:
Manual preparation was associated with significantly lower torque peaks compared to rotary instrumentation. The three motors remained well within the safety torque values of the instruments.
More Related Videos
Related Concept Videos
 01:24
Biodiversity and Human Values
 01:10
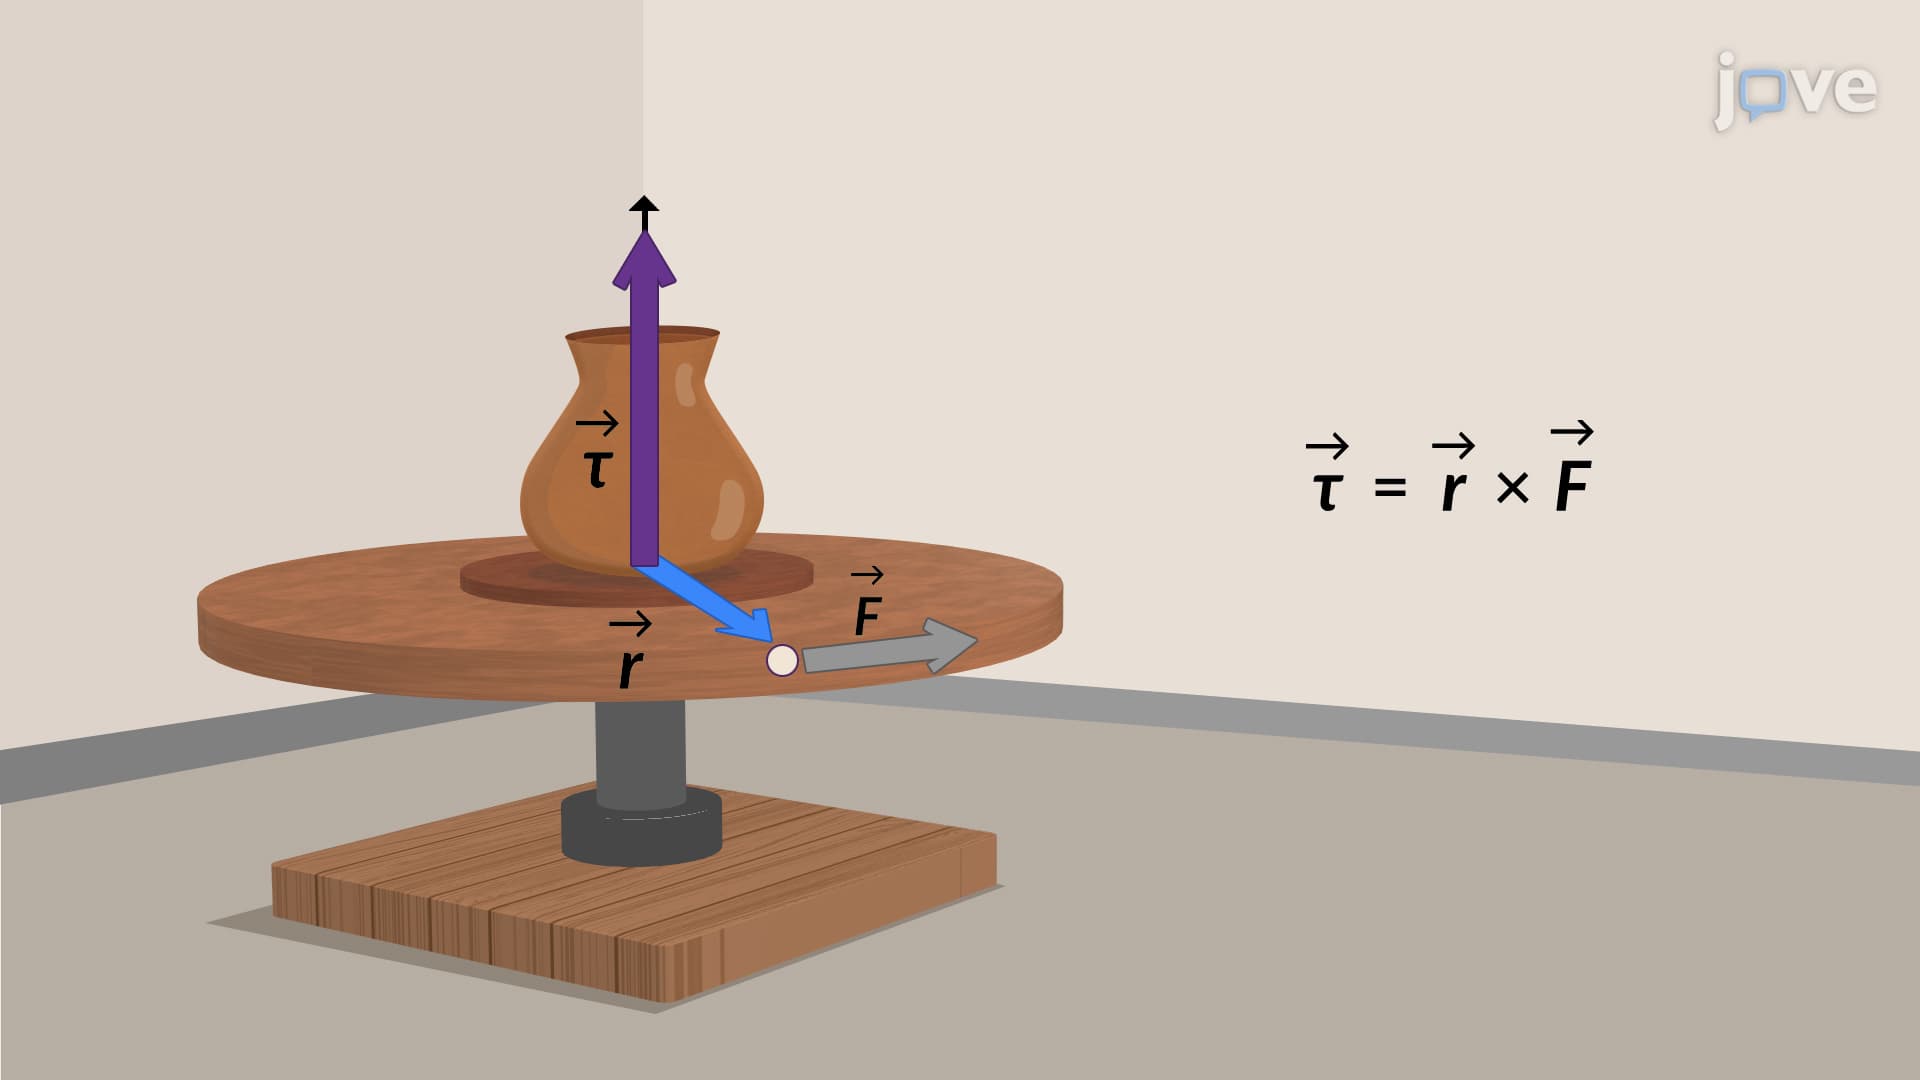
Torque
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 03:00
Preparation of Epoxides
Epoxides result from alkene oxidation, which can be achieved by a) air, b) peroxy acids, c) hypochlorous acids, and d) halohydrin cyclization.
Epoxidation with Peroxy Acids
Epoxidation of alkenes via oxidation with peroxy acids involves the conversion of a carbon–carbon double bond to an epoxide using the oxidizing agent meta-chloroperoxybenzoic acid, commonly known as MCPBA. Since the O–O bond of peroxy acids is very weak, the addition of electrophilic oxygen of peroxy acids to...
 01:29
Preparation of Amides
The DCC-promoted synthesis of amides begins with the protonation of DCC by carboxylic acid. The protonation makes it a better acceptor. Next, the addition of carboxylate to the protonated carbodiimide gives a reactive acylating agent.
Subsequently, the amine acts as a nucleophile that attacks the acylating agent to form a tetrahedral intermediate. In the...
 01:12
Preparation of Nitriles
 01:15
Torque Free Motion