Related Experiment Video
Updated: Feb 8, 2026
Optimized Sealing Process and Real-Time Monitoring of Glass-to-Metal Seal Structures
Published on: September 2, 2019
Robust and Globally Optimal Manhattan Frame Estimation in Near Real Time

Abstract:
Most man-made environments, such as urban and indoor scenes, consist of a set of parallel and orthogonal planar structures. These structures are approximated by the Manhattan world assumption, in which notion can be represented as a Manhattan frame (MF). Given a set of inputs such as surface normals or vanishing points, we pose an MF estimation problem as a consensus set maximization that maximizes the number of inliers over the rotation search space. Conventionally, this problem can be solved by a branch-and-bound framework, which mathematically guarantees global optimality. However, the computational time of the conventional branch-and-bound algorithms is rather far from real-time. In this paper, we propose a novel bound computation method on an efficient measurement domain for MF estimation, i.e., the extended Gaussian image (EGI). By relaxing the original problem, we can compute the bound with a constant complexity, while preserving global optimality. Furthermore, we quantitatively and qualitatively demonstrate the performance of the proposed method for various synthetic and real-world data. We also show the versatility of our approach through three different applications: extension to multiple MF estimation, 3D rotation based video stabilization, and vanishing point estimation (line clustering).
Related Concept Videos
 03:26
Framing Effects
 01:30
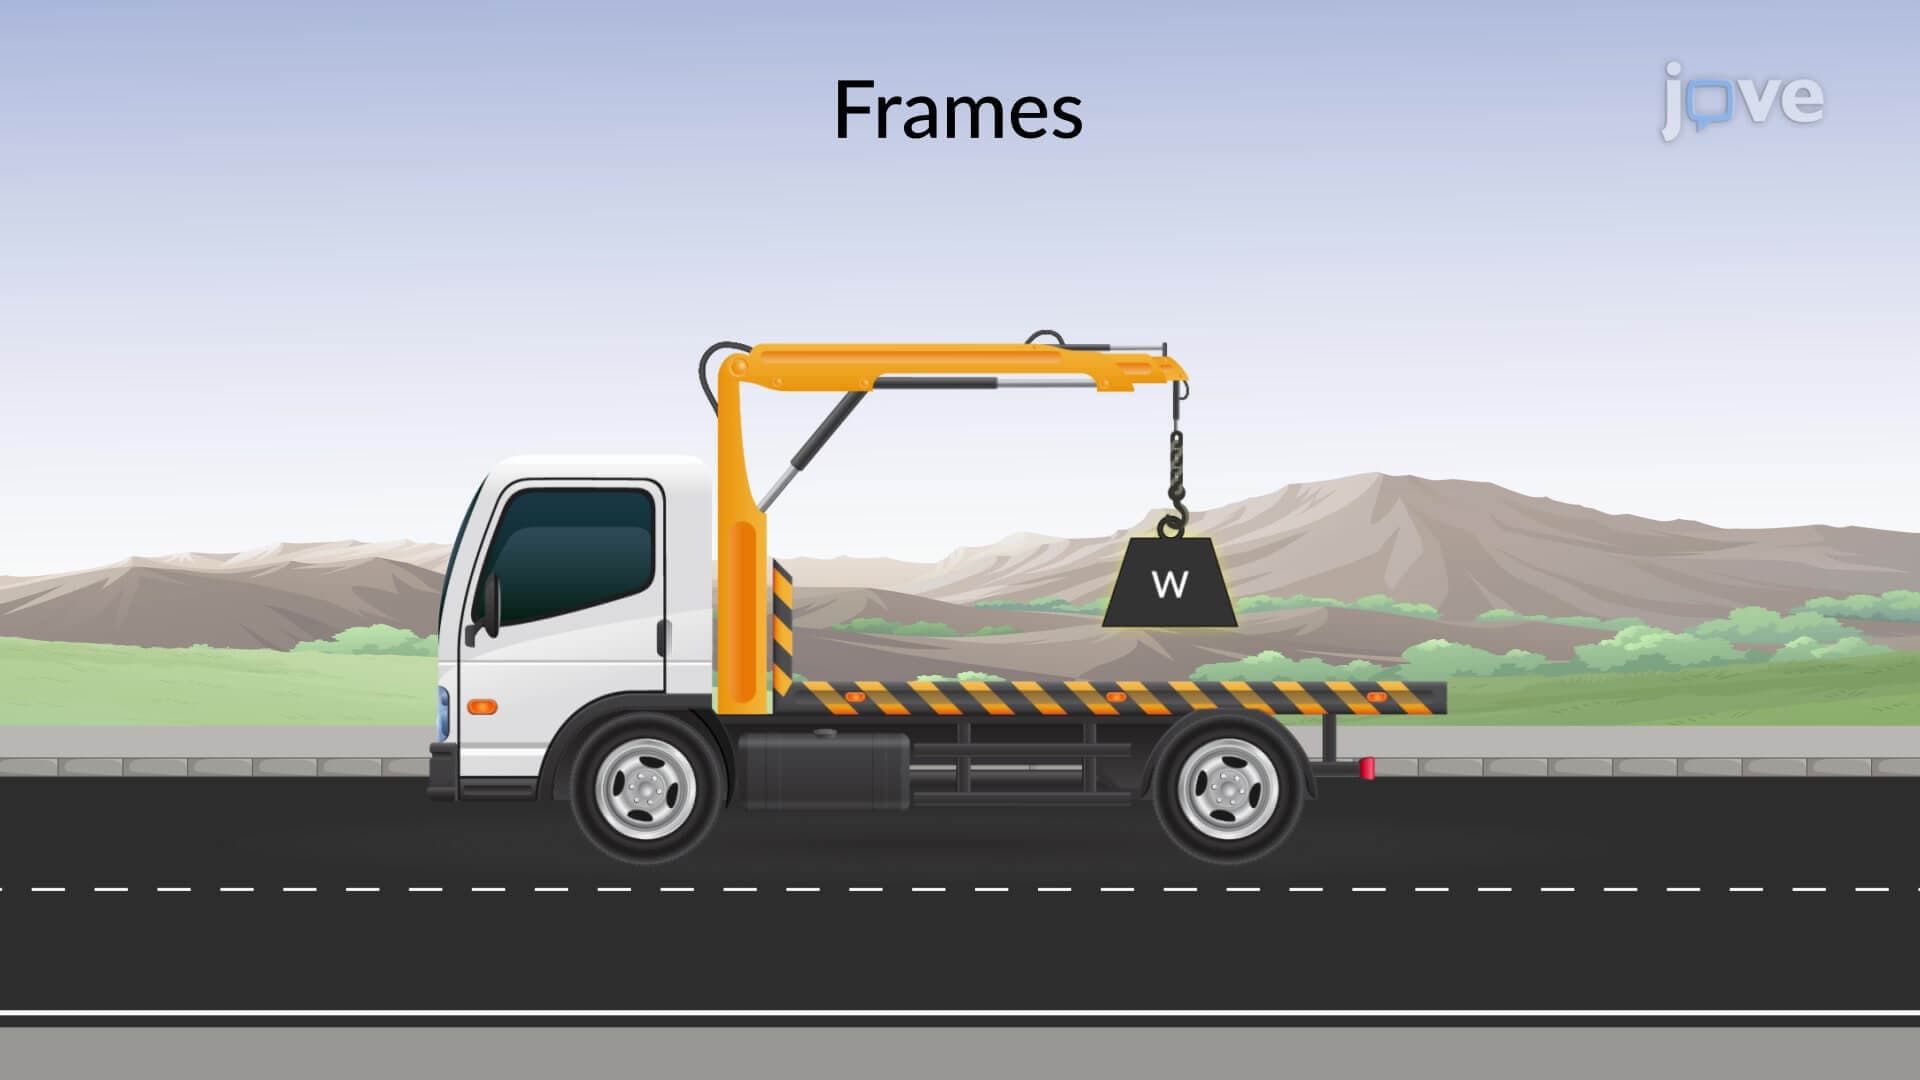
Frames
Frames are versatile and widely used in various applications such as structural supports for beams and columns, automobile chassis construction, and in the construction...
 01:50
Global Climate Change
 02:57
Real Time RT-PCR
The real-time quantification of the number of amplified products is...
 01:26
Frames: Problem Solving II
 01:24
Frames: Problem Solving I