Related Experiment Video
Updated: Feb 7, 2026
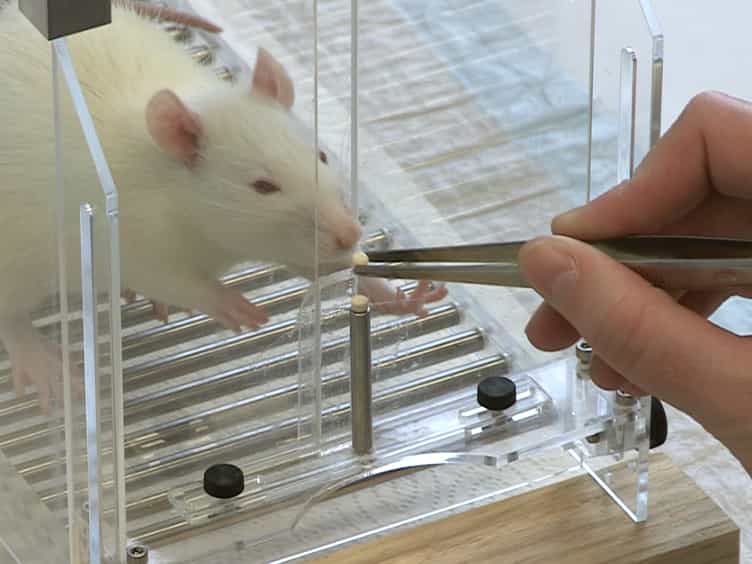
Acquisition of a High-precision Skilled Forelimb Reaching Task in Rats
Published on: June 22, 2015
The role of intersegmental dynamics in coordination of the forelimb joints during unperturbed and perturbed skilled
Humza N Zubair1,2, Erik E Stout1, Natalia Dounskaia2
1Barrow Neurological Institute, St. Joseph's Hospital and Medical Center , Phoenix, Arizona.

Abstract:
Joint coordination during locomotion and how this coordination changes in response to perturbations remains poorly understood. We investigated coordination among forelimb joints during the swing phase of skilled locomotion in the cat. While cats walked on a horizontal ladder, one of the cross-pieces moved before the cat reached it, requiring the cat to alter step size. Direction and timing of the cross-piece displacement were manipulated. We found that the paw was transported in space through body translation and shoulder and elbow rotations, whereas the wrist provided paw orientation required to step on cross-pieces. Kinetic analysis revealed a consistent joint control pattern in all conditions. Although passive interaction and gravitational torques were the main sources of shoulder and elbow motions for most of the movement time, shoulder muscle torque influenced movement of the entire limb at the end of the swing phase, accelerating the shoulder and causing interaction torque that determined elbow motion. At the wrist, muscle and passive torques predominantly compensated for each other. In all perturbed conditions, although all joints and the body slightly contributed to changes in the step length throughout the entire movement, the major adjustment was produced by the shoulder at the movement end. We conclude that joint coordination during the swing phase is produced mainly passively, by exploiting gravity and the limb's intersegmental dynamics, which may simplify the neural control of locomotion. The use of shoulder musculature at the movement end enables flexible responses to environmental disturbances. NEW & NOTEWORTHY This is the first study to investigate joint control during the swing phase of skilled, accuracy-dependent locomotion in the cat and how this control is altered to adapt to known and unexpected perturbations. We demonstrate that a pattern of joint control that exploits gravitational and interaction torques is used in all conditions and that movement modifications are produced mainly by shoulder muscle torque during the last portion of the movement.
Related Concept Videos
 02:57
Coordination Number and Geometry
 02:54
Coordination Compounds and Nomenclature
 02:33
Lattice Centering and Coordination Number
Types of Unit Cells
Imagine taking a large number of identical...
 01:16
Structural Joints: Synovial Joints
 01:03
Structural Joints: Fibrous Joints
Suture
All the bones of the skull, except for the mandible, are joined to each other by a fibrous joint called a suture. The fibrous connective tissue found at a suture strongly unites the adjacent skull bones and thus helps to protect the brain and form the face. In...
 01:17
Structural Joints: Cartilaginous Joints
There are two types of cartilaginous joints:
Synchondrosis
A synchondrosis ("joined by cartilage") is a cartilaginous joint where bones are connected by hyaline cartilage. Synchondrosis may be temporary...