Related Experiment Video
Updated: Feb 7, 2026

Customizing a Cryolite Glass Prosthetic Eye
Published on: October 31, 2019
A mechanical hand for prosthetic applications: multibody model and contact simulation
Chiara Cosenza1, Vincenzo Niola1, Sergio Savino1
1Department of Industrial Engineering, University of Naples Federico II, Napoli, Italy.

Abstract:
The dynamical behavior study of a mechanical hand is a fundamental issue to verify its possible application as a prosthetic hand. Simulation approaches are widely used to predict the dynamics of mechanical components. In the context of mechanical hands, the multibody model represents a useful tool to predict the finger dynamics and therefore the phalanx rotations before the prototyping. The phalanx rotations drive the finger closure sequence and, consequently, influence the grasping ability of the whole mechanical hand. This article discusses the main theoretical aspects dealing with the design of a mechanical hand for prosthetic application and the solutions offered by multiple simulation approaches.

Related Concept Videos
 02:45
The Quantum-Mechanical Model of an Atom
 01:13
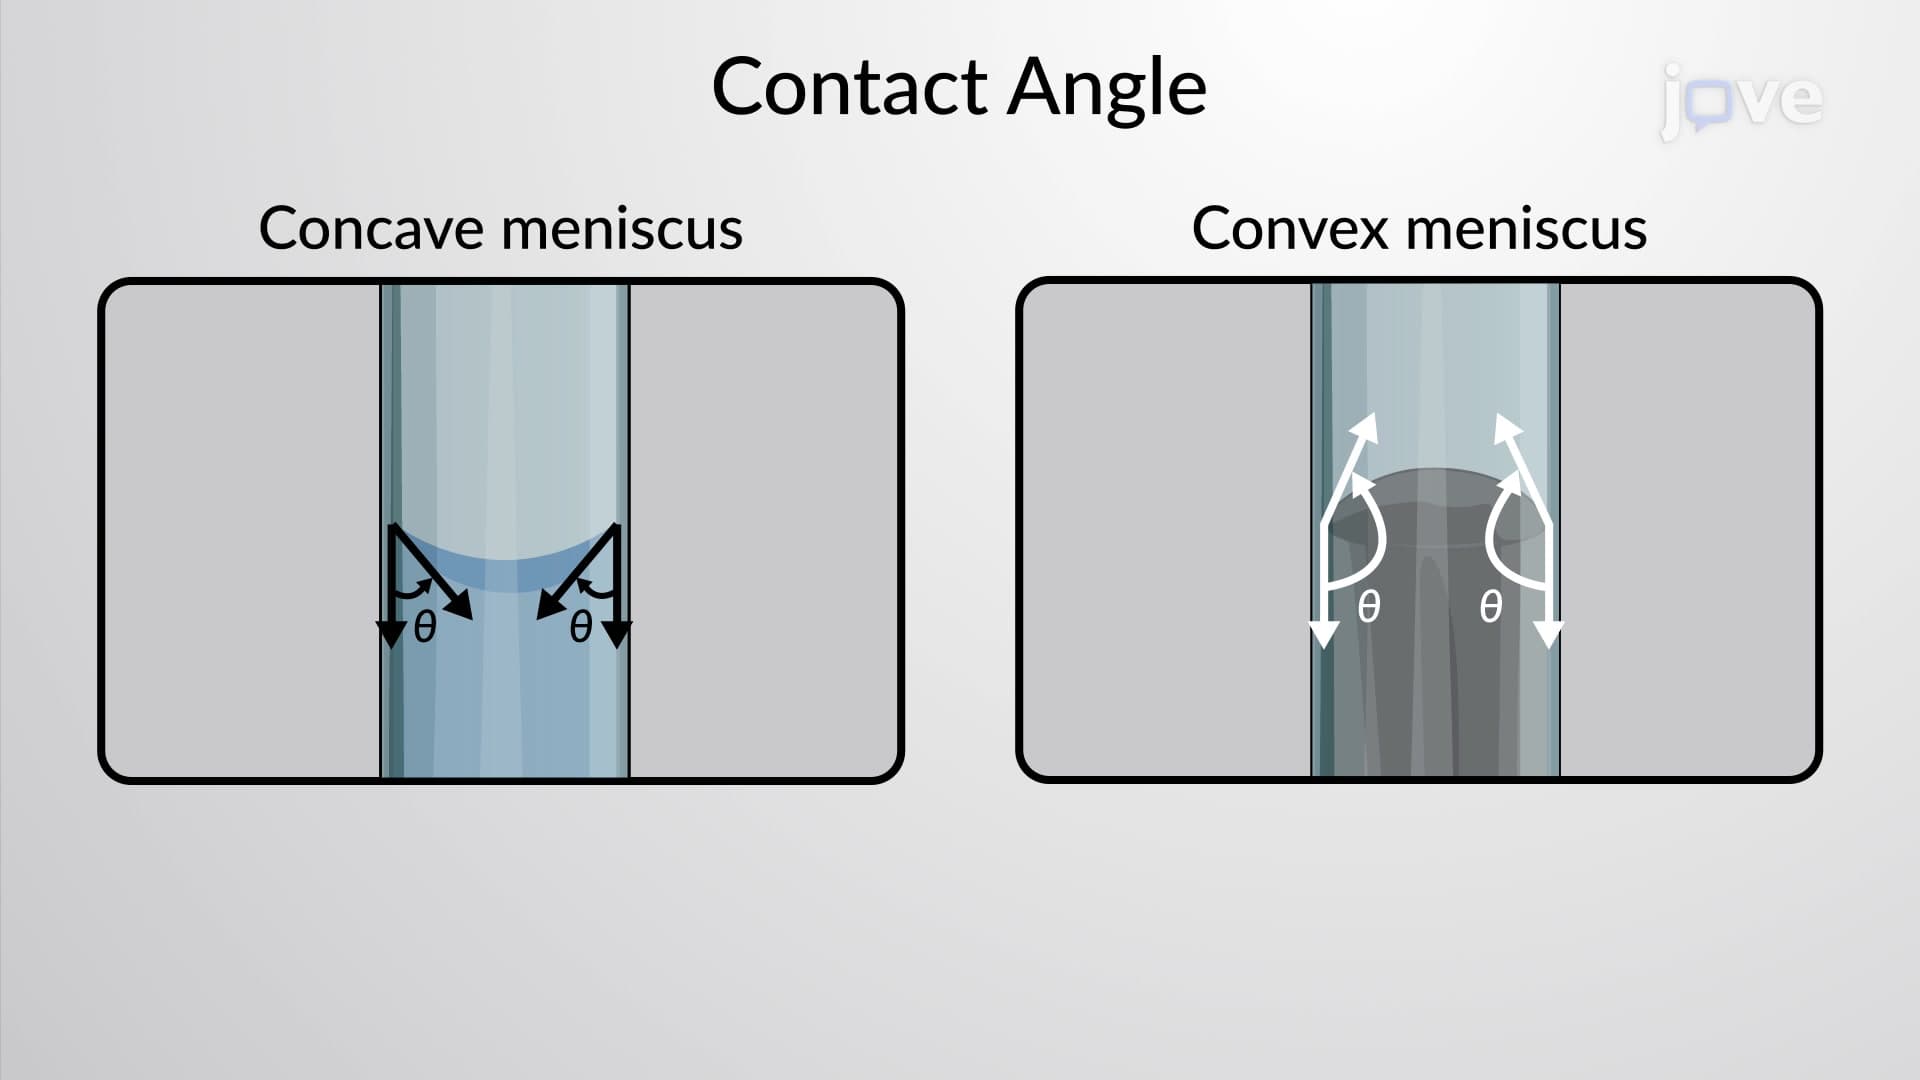
Contact Angle
The adhesive force is the molecular force between molecules of different materials, that is, between the molecules of the solid and the liquid. The cohesive...
 01:19
Contact-dependent Signaling
Gap Junctions
In animal cells, gap junctions are formed...
 01:23
Hand hygiene
Hand washing...
 01:25
Types of Reports I: Hands-off Report
Following are the key components and categories of hand-off reports:
Purpose and Process:
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...