Related Experiment Video
Updated: Feb 7, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Exoskeleton robot control for synchronous walking assistance in repetitive manual handling works based on dual
Fatai Sado1, Hwa Jen Yap1, Raja Ariffin Raja Ghazilla1
1Department of Mechanical Engineering, Faculty of Engineering, University of Malaya, Kuala Lumpur, Malaysia.

Abstract:
Prolong walking is a notable risk factor for work-related lower-limb disorders (WRLLD) in industries such as agriculture, construction, service profession, healthcare and retail works. It is one of the common causes of lower limb fatigue or muscular exhaustion leading to poor balance and fall. Exoskeleton technology is seen as a modern strategy to assist worker's in these professions to minimize or eliminate the risk of WRLLDs. Exoskeleton has potentials to benefit workers in prolong walking (amongst others) by augmenting their strength, increasing their endurance, and minimizing high muscular activation, resulting in overall work efficiency and productivity. Controlling exoskeleton to achieve this purpose for able-bodied personnel without impeding their natural movement is, however, challenging. In this study, we propose a control strategy that integrates a Dual Unscented Kalman Filter (DUKF) for trajectory generation/prediction of the spatio-temporal features of human walking (i.e. joint position, and velocity, and acceleration) and an impedance cum supervisory controller to enable the exoskeleton to follow this trajectory to synchronize with the human walking. Experiment is conducted with four subjects carrying a load and walking at their normal speed- a typical scenario in industries. EMG signals taken at two muscles: Right Vastus Intermedius (on the thigh) and Right Gastrocnemius (on the calf) indicated reduction in muscular activation during the experiment. The results also show the ability of the control system to predict spatio-temporal features of the pilots' walking and to enable the exoskeleton to move in concert with the pilot.
More Related Videos
Related Concept Videos
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
 01:25
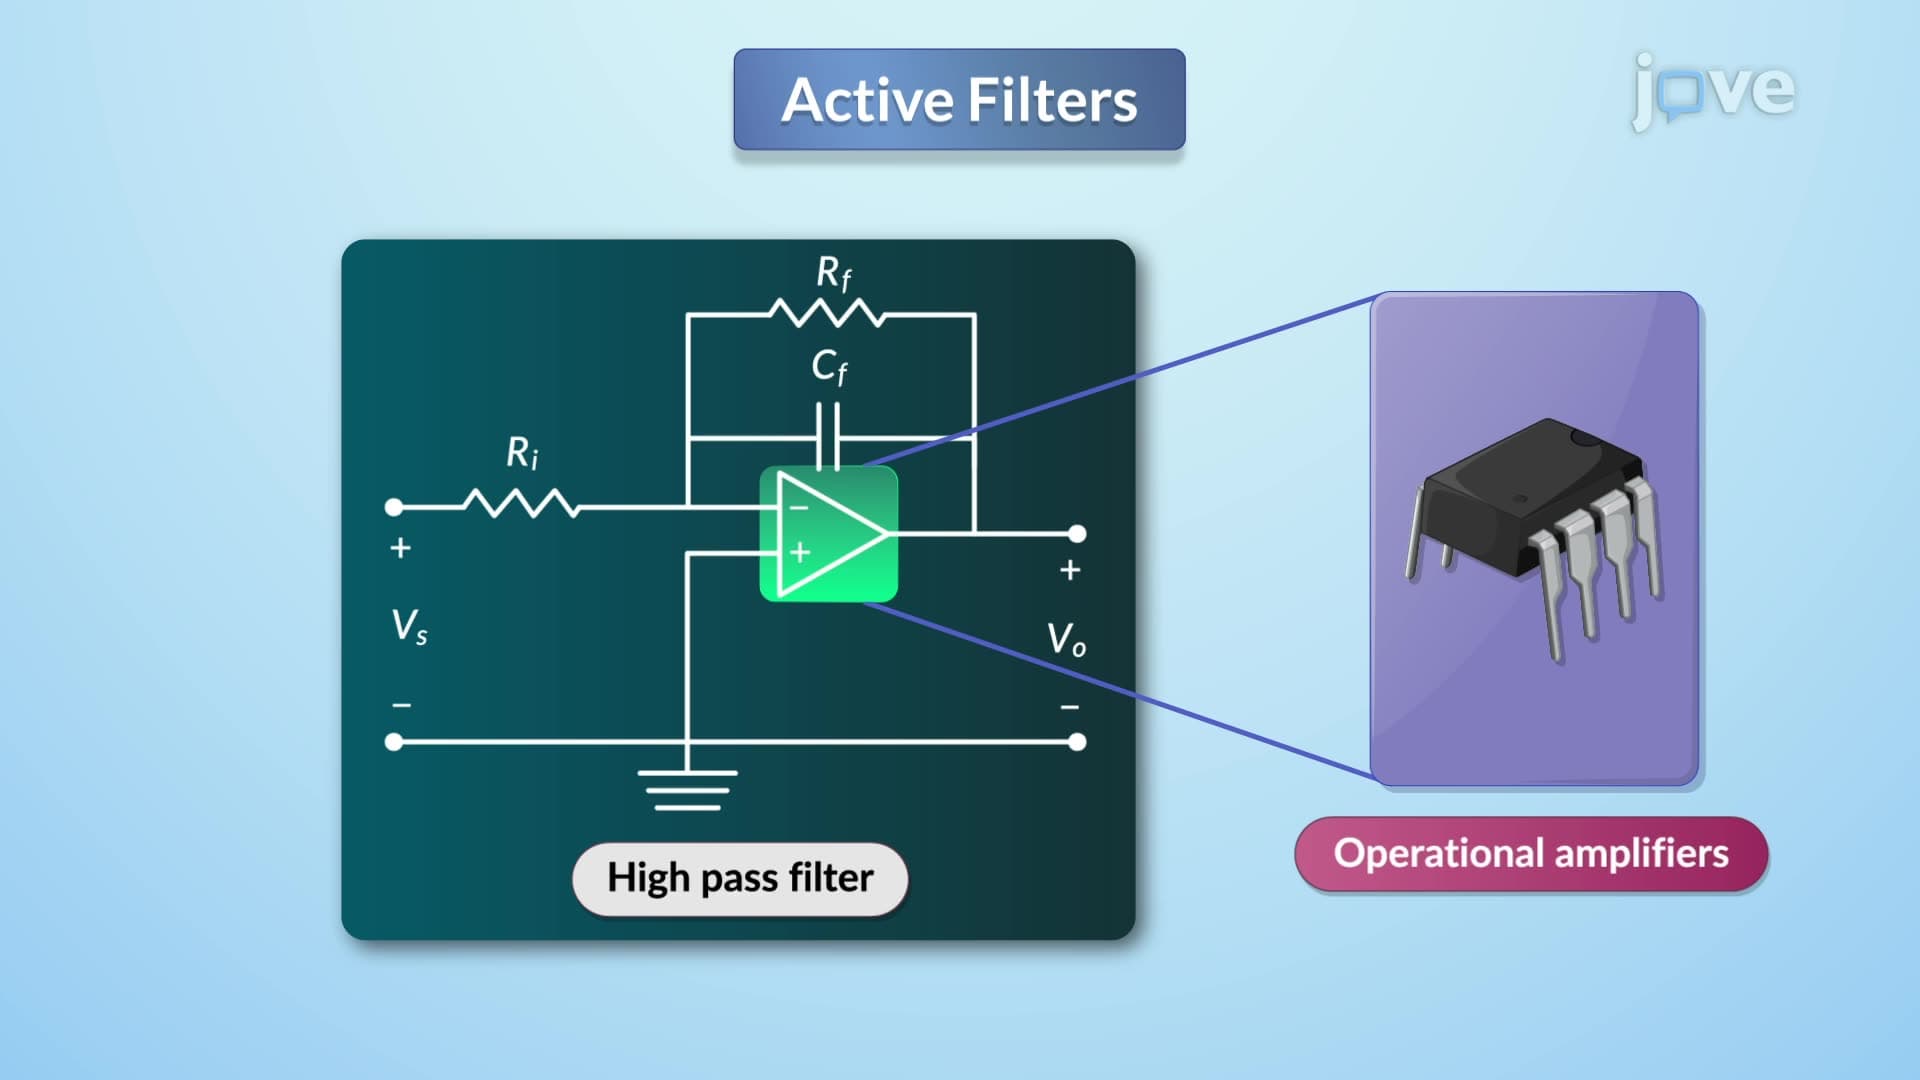
Active Filters
 01:02
Sample Handling
Samples should be transported carefully from collection points to the laboratory. They should be properly sealed and clearly labeled to prevent cross-contamination. To preserve the sample integrity, optimal temperature conditions during transport are essential. This could involve using...
 01:30
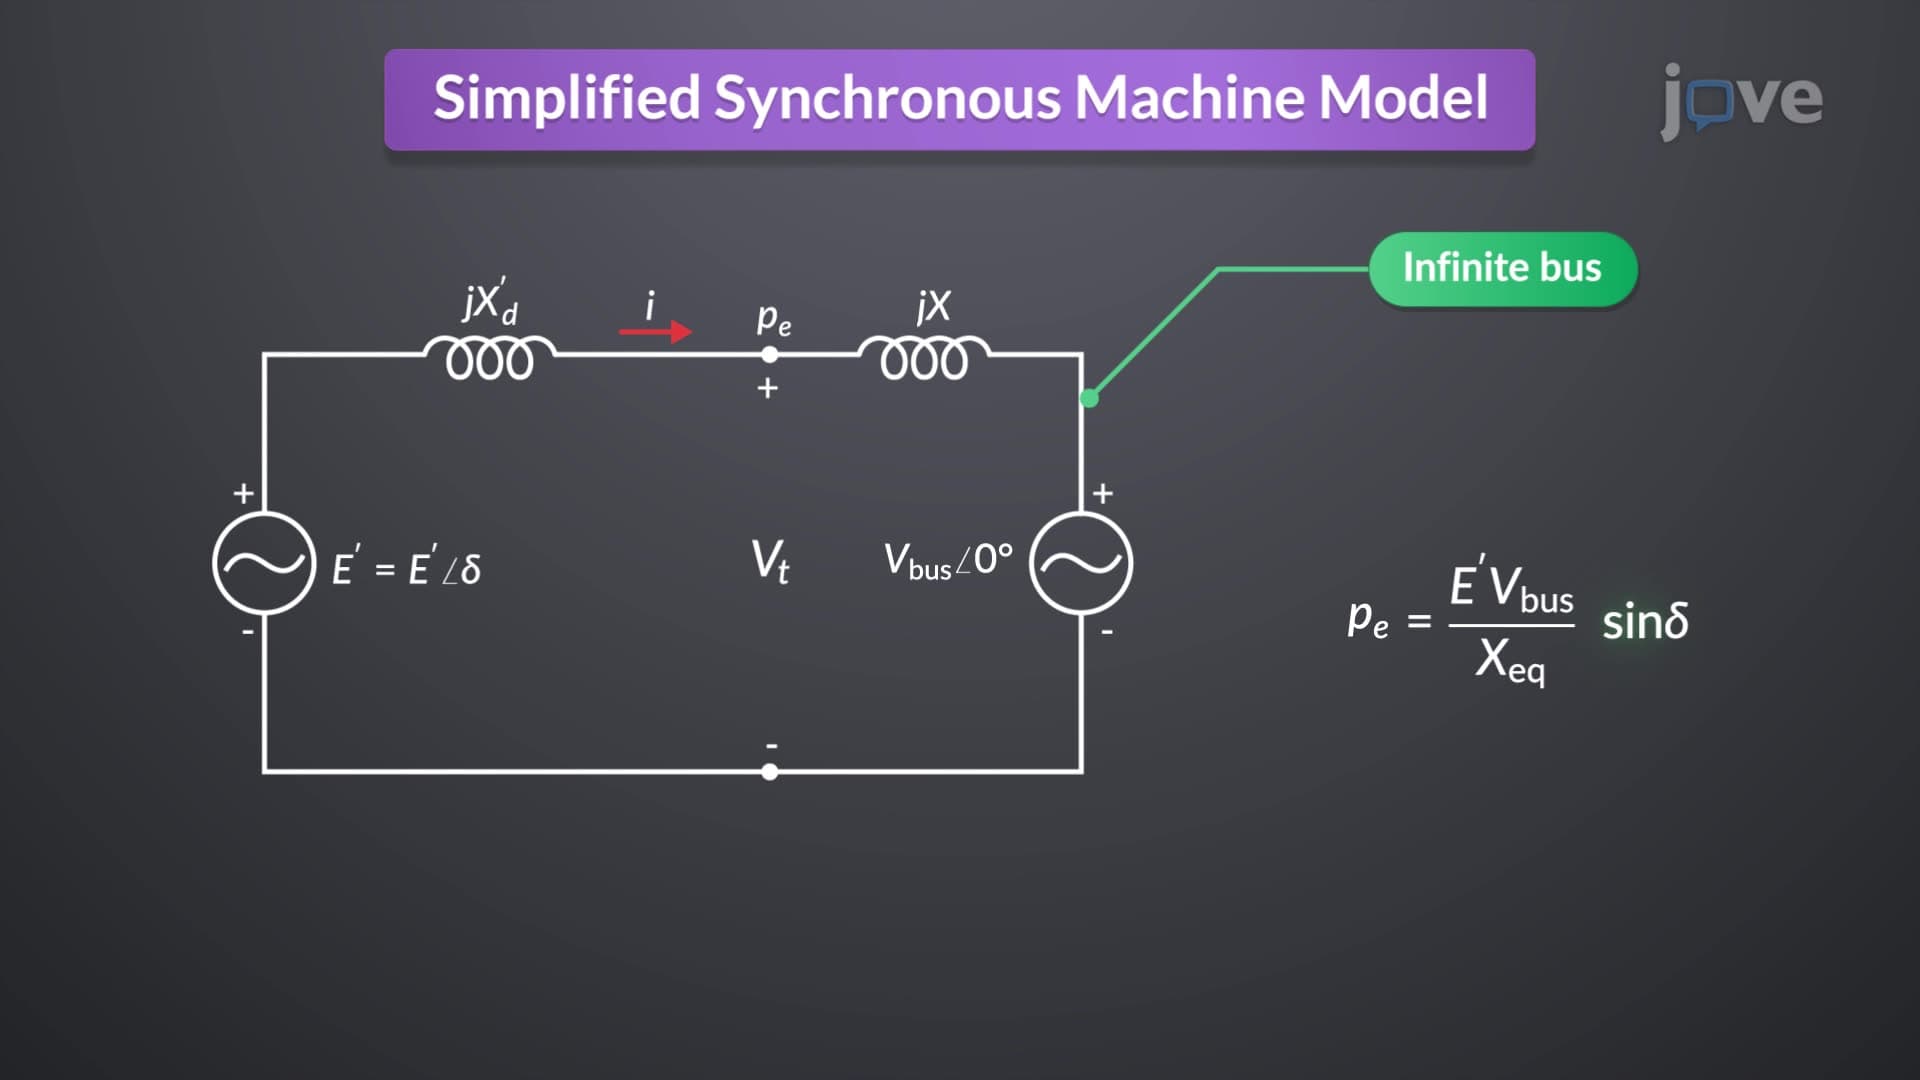
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:21
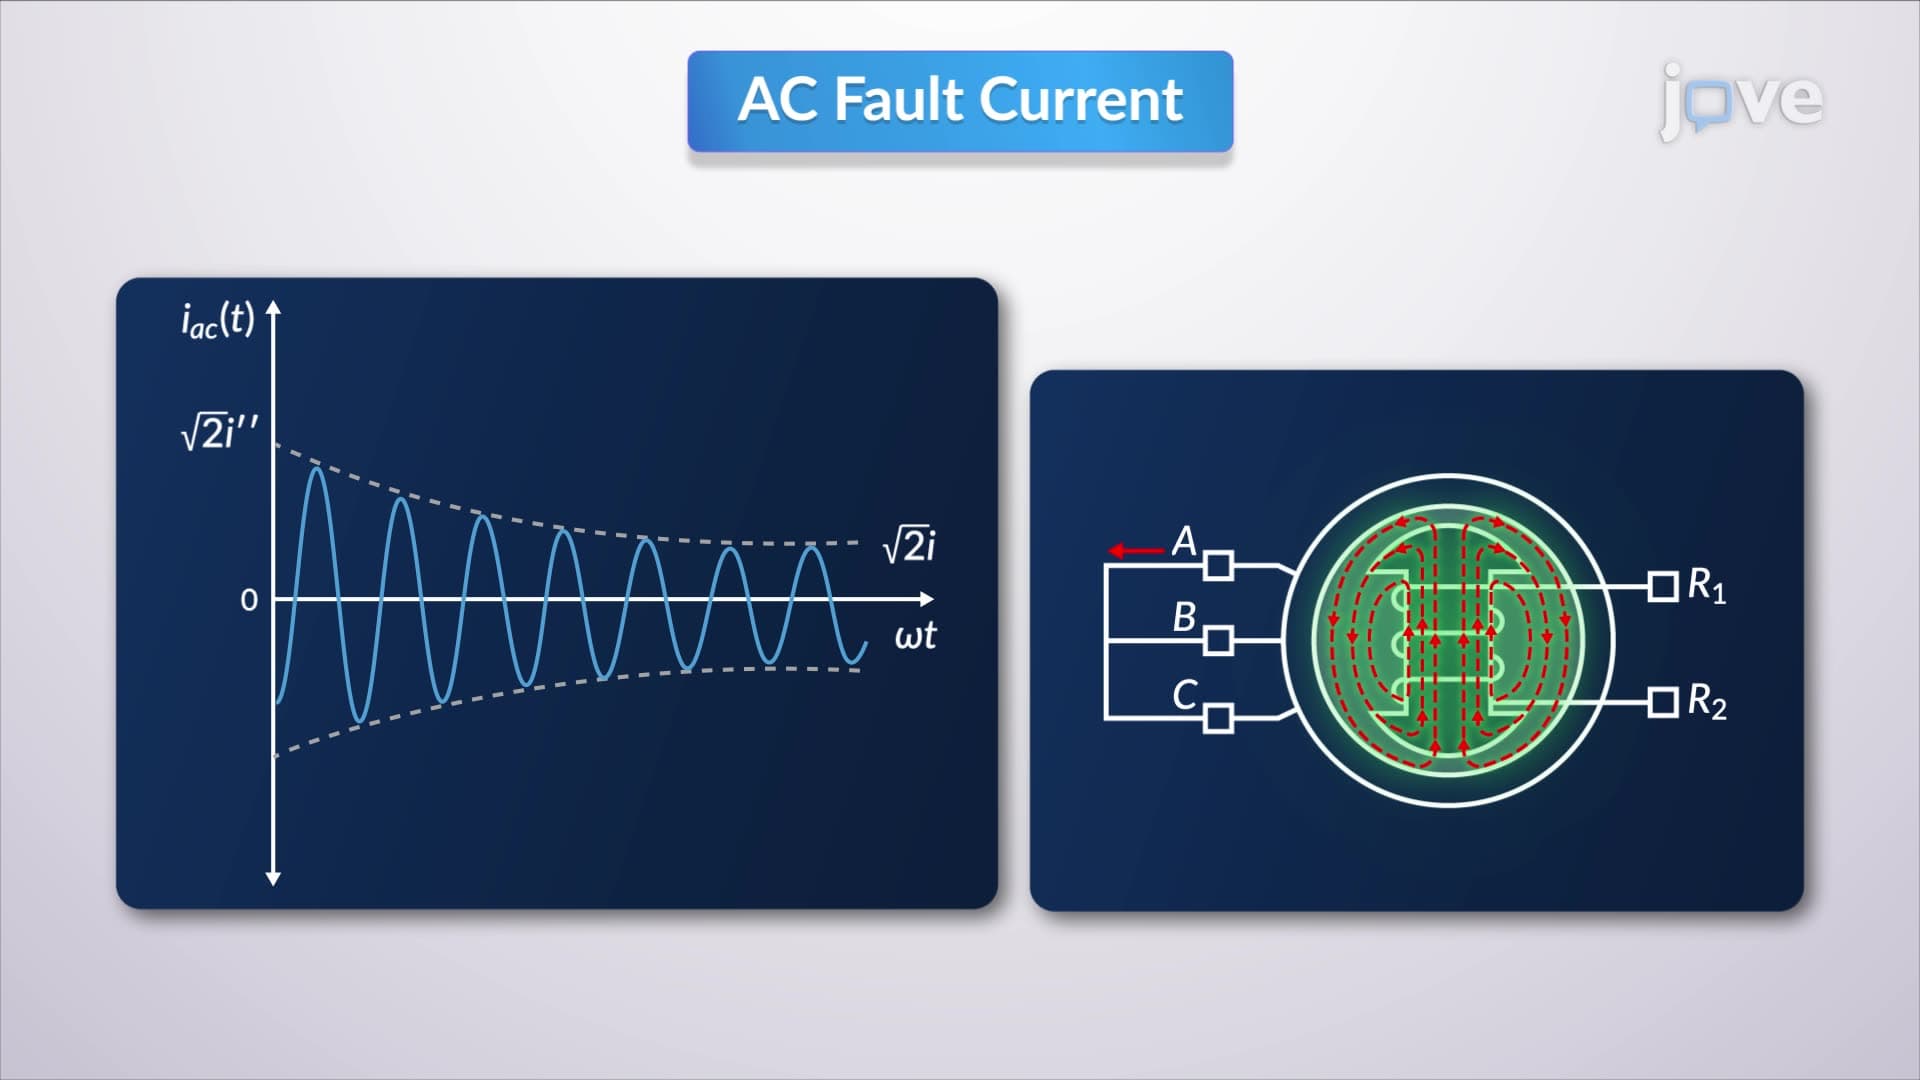
Three-Phase Short Circuit—Unloaded Synchronous Machine
This behavior occurs due to the magnetic flux produced by the short-circuit armature currents. Initially, these currents follow high-reluctance paths but eventually shift to...
 01:27
Diagnostic and Statistical Manual of Mental Disorders (DSM)