Dense RGB-D SLAM with Multiple Cameras
Related Experiment Video
Updated: Feb 7, 2026
Author Spotlight: An Alternative Approach to Protein Quantification by Bradford Assay Using a Smartphone
Published on: September 8, 2023
Xinrui Meng1,2, Wei Gao3,4, Zhanyi Hu5,6
1National Laboratory of Pattern Recognition (NLPR), Institute of Automation, Chinese Academy of Sciences, Beijing 100190, China. xinrui.meng@nlpr.ia.ac.cn.

Abstract:
A multi-camera dense RGB-D SLAM (simultaneous localization and mapping) system has the potential both to speed up scene reconstruction and to improve localization accuracy, thanks to multiple mounted sensors and an enlarged effective field of view. To effectively tap the potential of the system, two issues must be understood: first, how to calibrate the system where sensors usually shares small or no common field of view to maximally increase the effective field of view; second, how to fuse the location information from different sensors. In this work, a three-Kinect system is reported. For system calibration, two kinds of calibration methods are proposed, one is suitable for system with inertial measurement unit (IMU) using an improved hand⁻eye calibration method, the other for pure visual SLAM without any other auxiliary sensors. In the RGB-D SLAM stage, we extend and improve a state-of-art single RGB-D SLAM method to multi-camera system. We track the multiple cameras' poses independently and select the one with the pose minimal-error as the reference pose at each moment to correct other cameras' poses. To optimize the initial estimated pose, we improve the deformation graph by adding an attribute of device number to distinguish surfels built by different cameras and do deformations according to the device number. We verify the accuracy of our extrinsic calibration methods in the experiment section and show the satisfactory reconstructed models by our multi-camera dense RGB-D SLAM. The RMSE (root-mean-square error) of the lengths measured in our reconstructed mode is 1.55 cm (similar to the state-of-art single camera RGB-D SLAM systems).
Related Concept Videos
 01:13
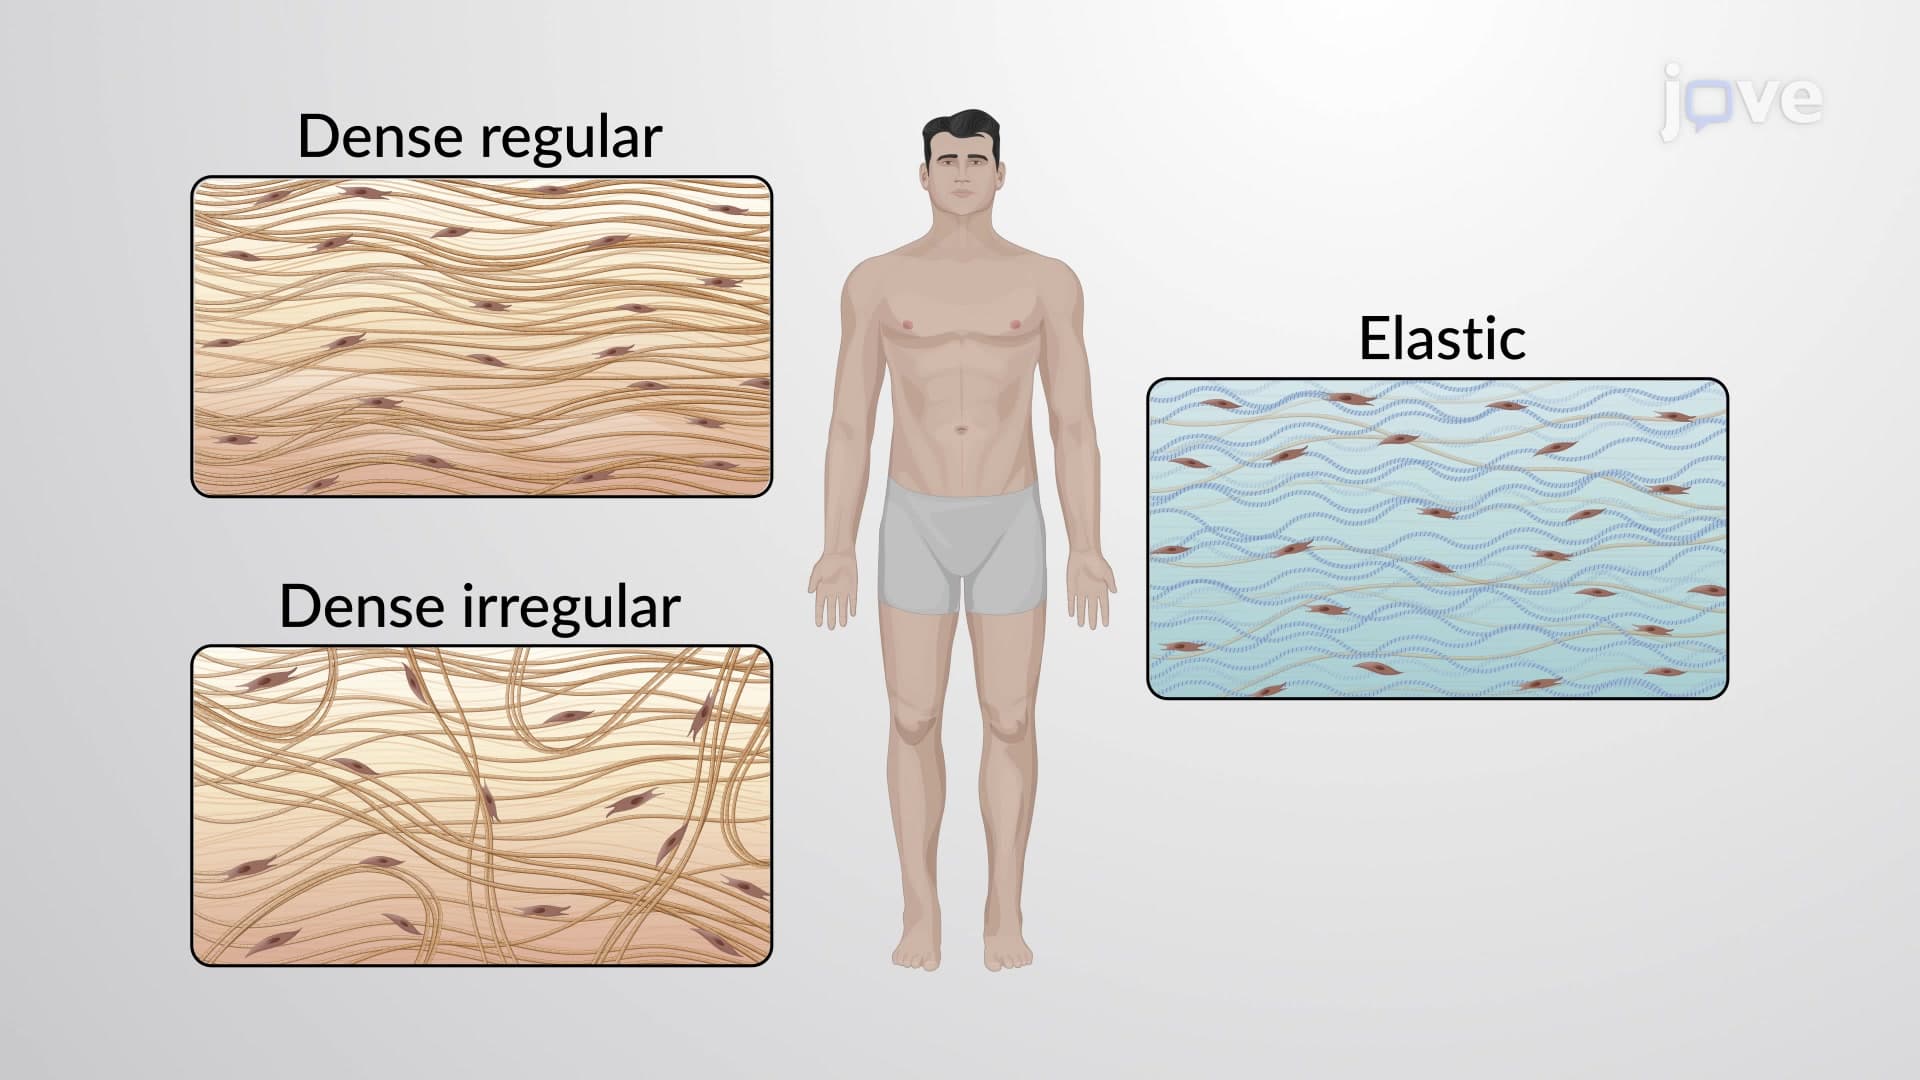
Dense Connective Tissue
Dense Regular Connective Tissue
In dense regular connective tissue, fibers are arranged parallel to each other, enhancing its tensile strength and resistance to stretching in the direction of the fiber orientations. Ligaments and tendons are made of dense regular...
 01:49
Multiple Allele Traits
 01:25
Multiple Regression
Farmers can use multiple regression to determine the crop yield based on more than one factor, such as water availability, fertilizer, soil properties, etc. Here, the crop yield is the response or dependent variable as it depends on the other independent variables. The analysis requires the construction of a scatter plot...
 01:25
Multiple Voltage Sources
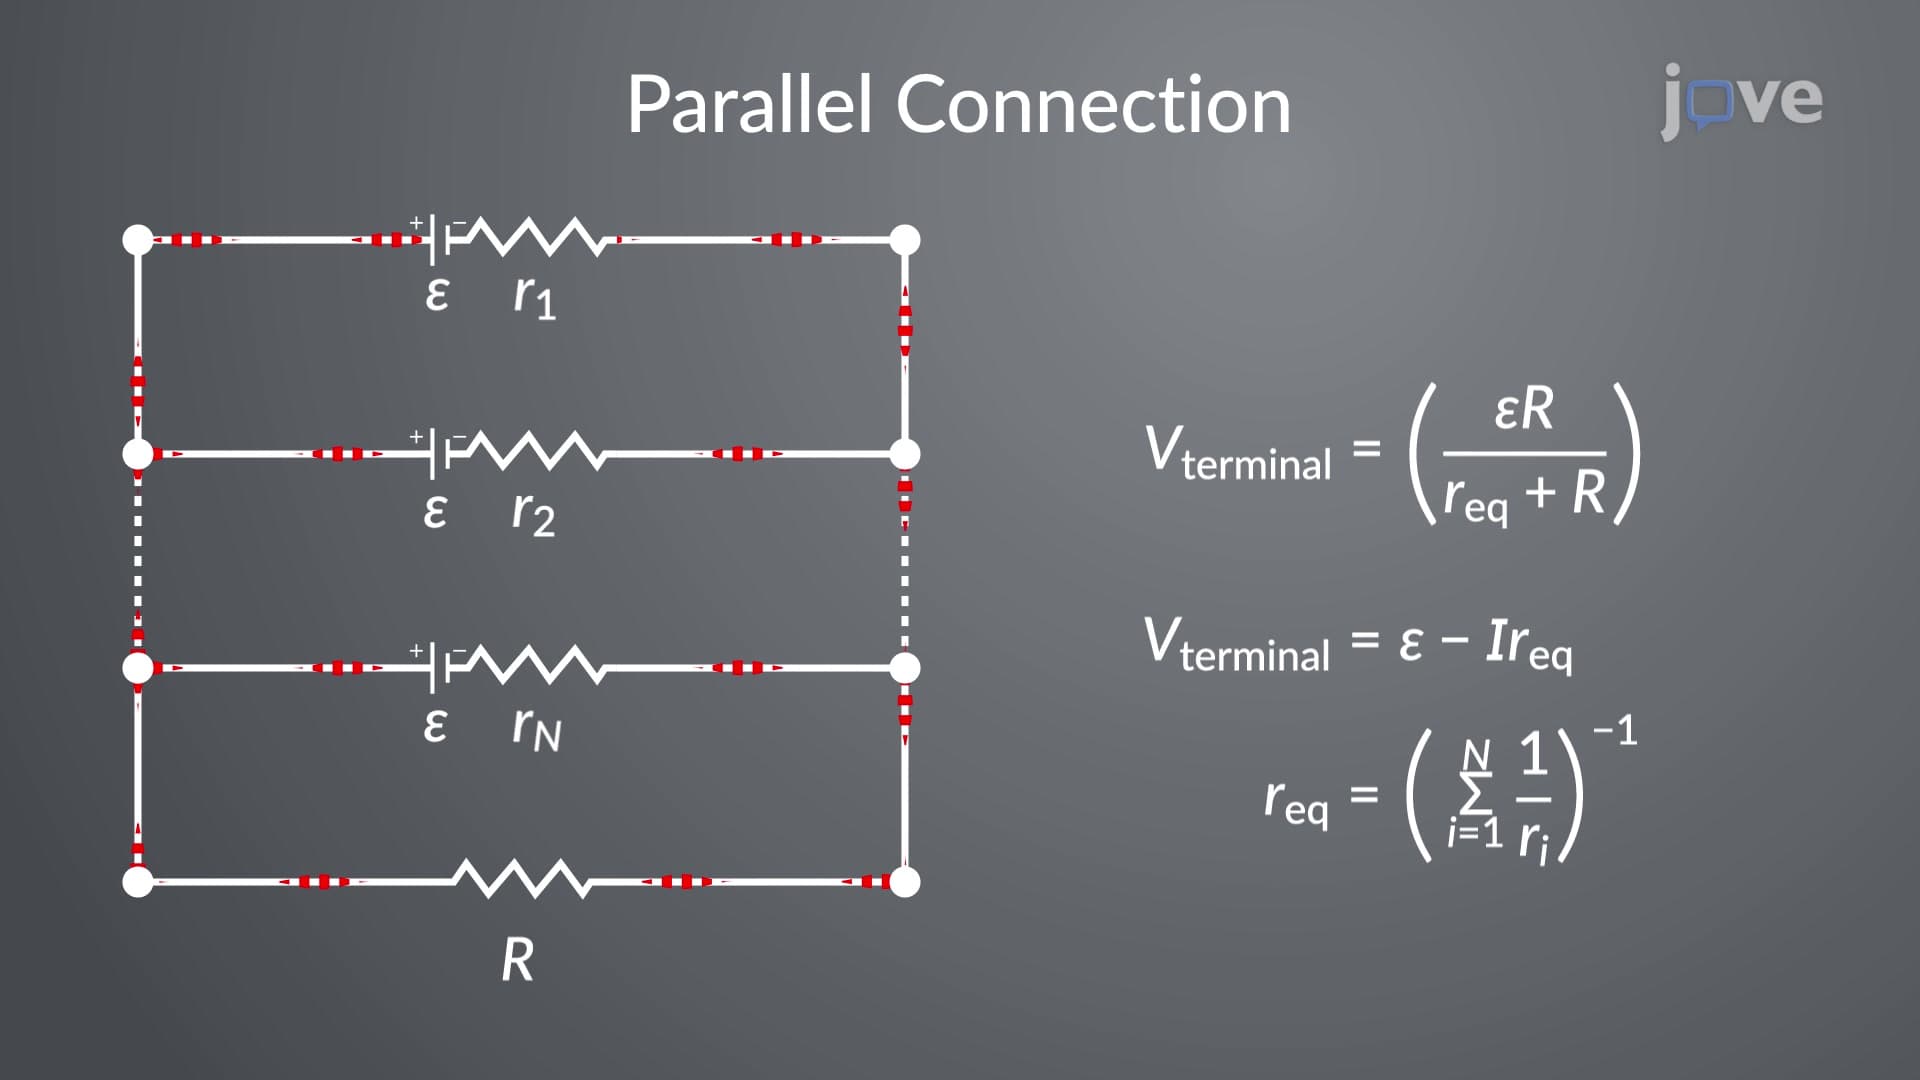
In series, the positive terminal of one battery is connected to the negative terminal of another battery. Hence, the voltage of each battery is added to give the net voltage, which is increased because each battery boosts the electrons that enter it. The same current flows through each battery because they are connected in series.
Batteries are...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:07
Multiple Bar Graph
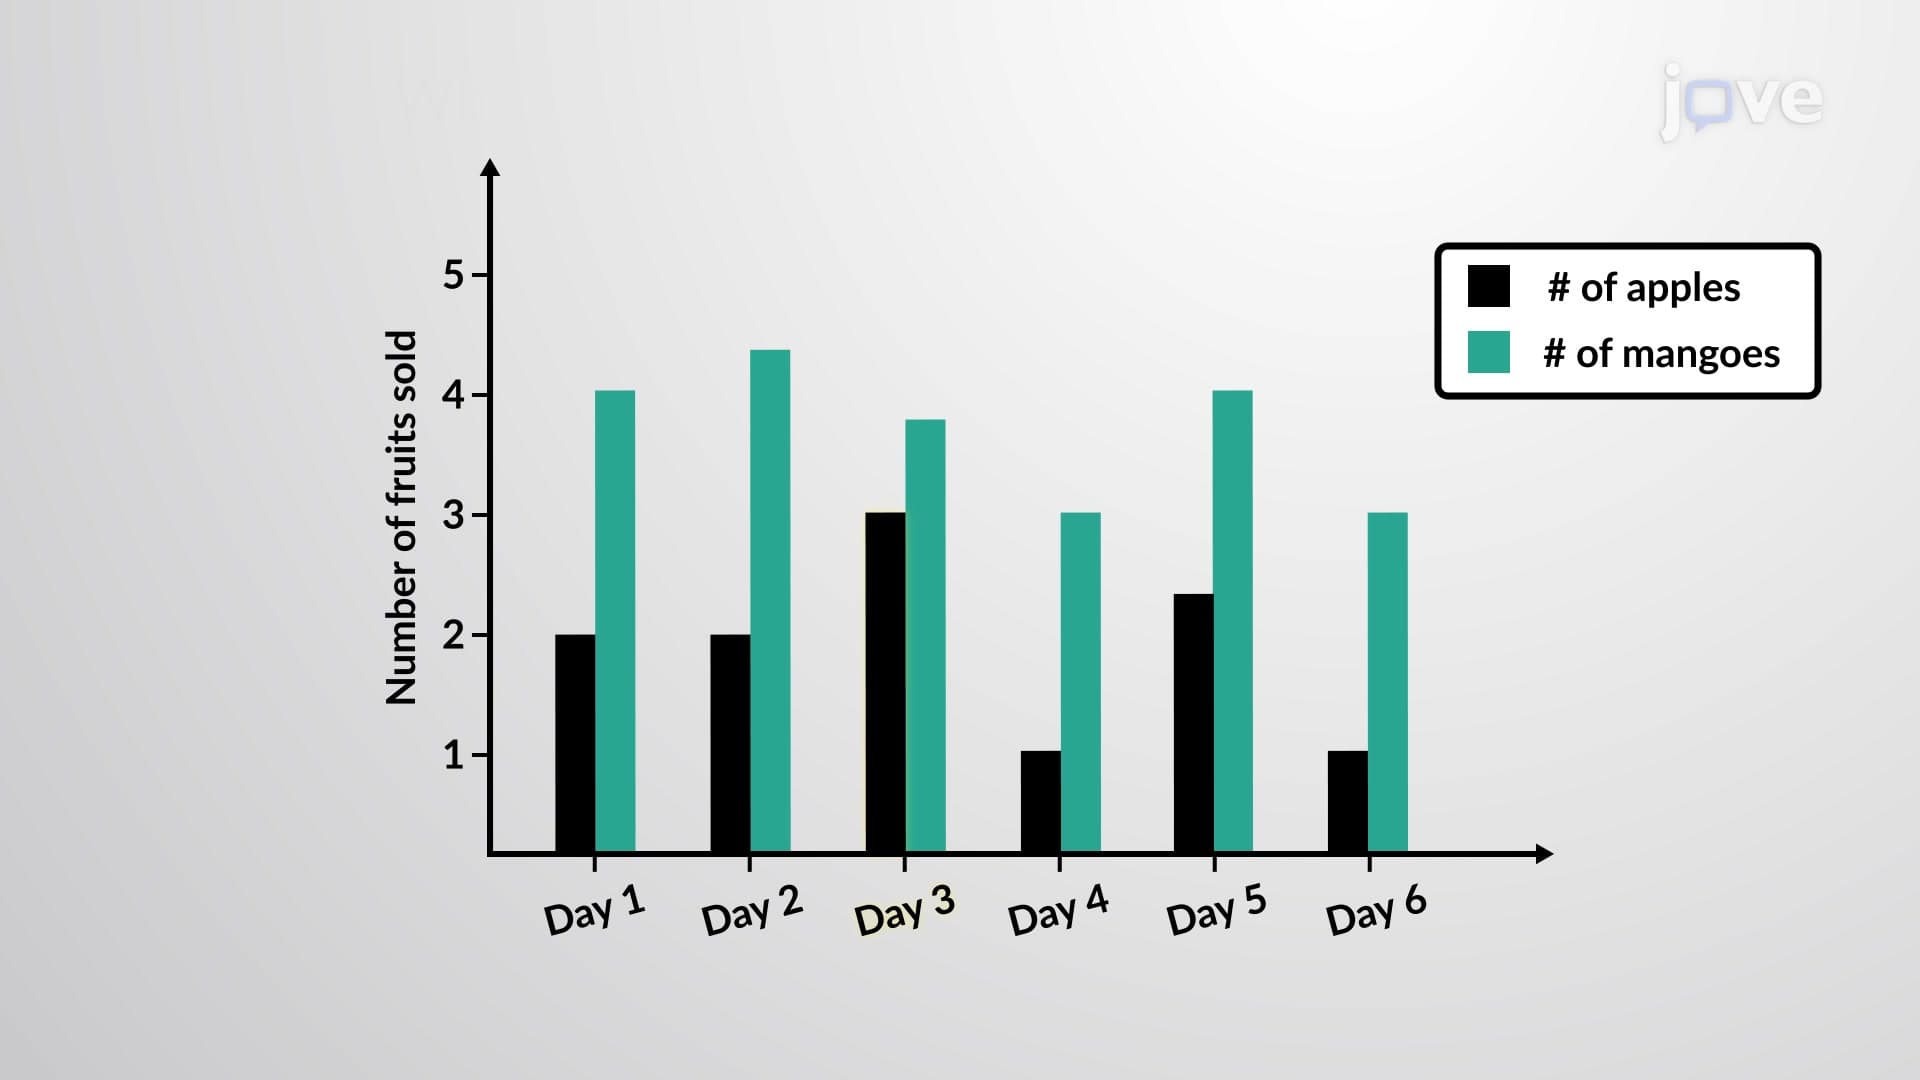
Each bar or column in the multiple bar graph represents a data value. These graphs are used primarily in interrelating two or more sets of data. The categories of different kinds of data are listed along the horizontal or x-axis, whereas...