Related Experiment Video
Updated: Feb 7, 2026
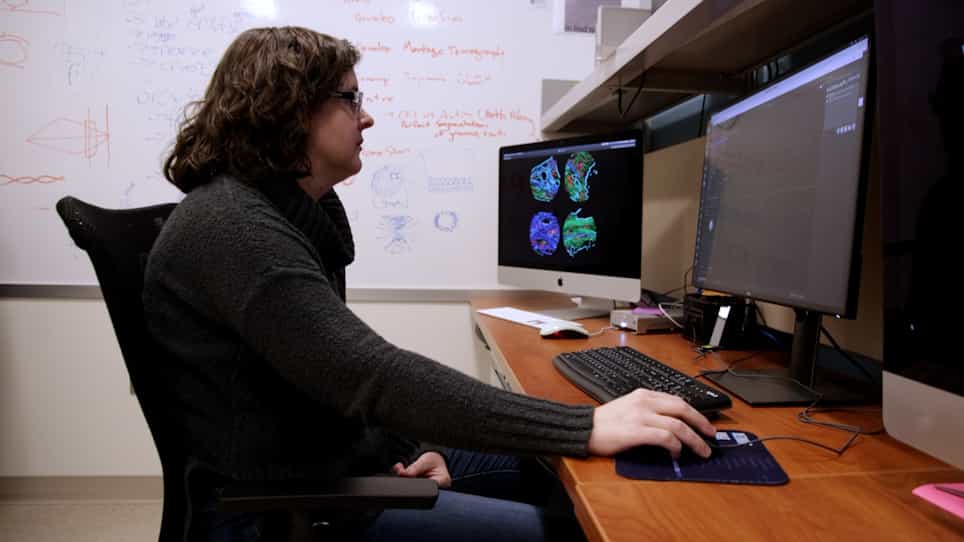

Deep Learning-Based Segmentation of Cryo-Electron Tomograms
Published on: November 11, 2022
Control of neural systems at multiple scales using model-free, deep reinforcement learning
B A Mitchell1, L R Petzold2,3
1Department of Computer Science, University of California, Santa Barbara, USA. brian_a_mitchell@engineering.ucsb.edu.

Abstract:
Recent improvements in hardware and data collection have lowered the barrier to practical neural control. Most of the current contributions to the field have focus on model-based control, however, models of neural systems are quite complex and difficult to design. To circumvent these issues, we adapt a model-free method from the reinforcement learning literature, Deep Deterministic Policy Gradients (DDPG). Model-free reinforcement learning presents an attractive framework because of the flexibility it offers, allowing the user to avoid modeling system dynamics. We make use of this feature by applying DDPG to models of low-level and high-level neural dynamics. We show that while model-free, DDPG is able to solve more difficult problems than can be solved by current methods. These problems include the induction of global synchrony by entrainment of weakly coupled oscillators and the control of trajectories through a latent phase space of an underactuated network of neurons. While this work has been performed on simulated systems, it suggests that advances in modern reinforcement learning may enable the solution of fundamental problems in neural control and movement towards more complex objectives in real systems.
Related Concept Videos
 01:21
Multiple Pipe Systems
Series Configuration
In a series configuration, fluid flows sequentially from one pipe...
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...